Ertificate Of Original Authorship
I, Vu An Le declare that this thesis, is submitted in fulfillment of the requirements for the award of Doctor of Philosophy, in the School of Civil and Environmental of Technology Sydney.
This thesis is wholly my own work unless otherwise referenced or acknowledged. In addition, I certify that all information sources and literature used are indicated in the thesis.
This document has not been submitted for qualifications at any other academic institution. Scholarship.
Ii
This work would not have been possible without the support of my colleagues, friends and family and I owe all of them my most profound thanks. I am sincerely grateful to all my supervisors, Dr Emre Erkmen, Dr Sardar Malek, Dr Rijun Shrestha, Dr Sanjay Nimbalkar and Dr Navid Zobeiry for their invaluable Dr Sardar Malek when he was about to leave UTS and still providing me with his supervision remotely. Great appreciation for the excellent inspiration and continuous support from Dr Sardar Malek is expressed. His constructive criticisms and encouragement constantly motivated me. Particular gratitude is given to Dr Sanjay acknowledge and thank Dr Navid Zobeiry who was always willing to provide me with important advice for achieving my major milestones during my 4-year study. Without his advice, detailed comments and constructive feedback, my work would not have been possible.
IT, especially Prof Hadi Khabbaz, Dr Nadarajah Gowripalan and Mrs Van Le for their like to acknowledge the financial support provided by International Research Scholarship and UTS-VIED scholarship. I also truly value the friendship of several close friends who I met in Sydney. I appreciate their time for listening, sharing and encouraging me during Lastly, I would like to thank my family without whom this work would not have been accomplished. I would like to thank my beloved parents for their endless and unconditional love throughout my life. I would like to thank my dear sisters and brothers for standing at my side and encouraging me to follow my passion. Special thanks go to my parents-in-law for taking care of my lovely son, as this helped me to accomplish my
Ist Of Publications
Le, A., Zobeiry, N., Erkmen, E. & Malek, S. 2019, 'Buckling analysis of multilayered beams with soft and rigid interfaces', ICCM22, Engineers Australia, Melbourne, Vic, pp. 204-12.
Le, V.A., Zobeiry, N., Erkmen, E. & Malek, S. 2021, 'Buckling behaviour of laminated viscoelastic composites under axial loads', Mechanics of Materials, 159, 103897.
Le, V.A., Nimbalkar, S., Zobeiry, N. & Malek, S. 2022, ' An efficient multi-scale approach for viscoelastic analysis of woven composites under bending', Composite Structures, 292, 115698.
Le, V.A., Nimbalkar, S., Zobeiry, N. & Malek, S. 2022, ' Multi-scale viscoelastic bending analysis of laminated composites with soft interfaces', Full paper submitted to ECCM20, Lausanne- Switzerland.
Table Of Content
Title Page ...................................................................................................................... i Declaration ................................................................................................................... i Acknowledgements ..................................................................................................... ii List of publications ..................................................................................................... iii Table of content.......................................................................................................... iv List of figures ............................................................................................................ vii List of tables ............................................................................................................... xi Abstract .................................................................................................................... xiv Chapter 1. Introduction .............................................................................................. 1 1.1. Laminated composites .......................................................................................... 1 1.2. Textile composites ................................................................................................ 3 1.3. Overview of composite manufacturing techniques ............................................. 5 1.4. Applications and challenges ................................................................................. 6 1.5. Knowledge gaps .................................................................................................... 9 1.6. Research objectives ............................................................................................ 10 1.7. Thesis structure .................................................................................................. 12 Chapter 2. Literature review .................................................................................... 17 2.1. Micro-mechanical modelling of circular fibre composites ............................... 17 2.1.1. Analytical micromechanics equations for predicting properties of solid unidirectional composites ............................................................................................ 17 2.1.2. Predicting the viscoelastic properties of composites during cure ........................ 20 2.2. Meso-mechanical modelling of textile composites ............................................. 21 2.3. Buckling behaviour of laminated viscoelastic composites ................................ 28 2.4. Bending behaviour of woven composites during forming processes ................ 32 2.4.1. Bending properties of uncured thin laminates .................................................... 33 Chapter 3. Research methodology ........................................................................... 39
V
3.1. Micro- and meso-scale model............................................................................. 40 3.1.1. Micro-mechanical modelling of UD composites ................................................ 41 3.1.2. Analytical procedure for predicting elastic engineering constants of woven composites at the meso-scale ...................................................................................... 41 3.1.2.1. Geometric modelling of 5HS satin weave ....................................................... 42 3.1.2.2. Discretisation technique of yarns and determination of three-dimensional effective stiffnesses ..................................................................................................... 44 3.2. Macro-scale (structural) modelling of viscoelastic composites ......................... 46 3.2.1. Numerical approach using Abaqus built-in viscoelastic model (IF) .................... 46 3.2.2. Numerical approach using orthotropic viscoelastic user material model (UMAT) ................................................................................................................................... 47 Chapter 4. Buckling analysis of multilayered elastic beams with soft and rigid interfaces ................................................................................................................... 49 4.1. Introduction........................................................................................................ 49 4.2. Method ................................................................................................................ 50 4.3. Multilayered cantilever beam under bending (Case I) ..................................... 51 4.4. Flat laminate under compressive load (Case II) ............................................... 53 4.4.1. Two pinned ends ............................................................................................... 54 4.4.2. Four fixed edges ................................................................................................ 57 4.5. Summary and conclusions ................................................................................. 59 Chapter 5. Buckling behaviour of laminated viscoelastic composites under axial loads ........................................................................................................................... 60 5.1. 60 5.2. 61 5.3. Model verification .............................................................................................. 62 5.3.1. Geometry and input parameters ......................................................................... 62 5.3.2. FE analysis ........................................................................................................ 64 5.4. Model validation and comparison with experiments ........................................ 68 5.4.1. Isotropic viscoelastic material ........................................................................... 69 5.4.2. Orthotropic viscoelastic material ....................................................................... 76 5.5. 82 Chapter 6. Bending behviour of viscoelatic woven composite plates ...................... 84
Vi
6.1. Introduction........................................................................................................ 84 6.2. Method ................................................................................................................ 84 6.2.1. Micro- and meso-scale properties ...................................................................... 85 6.2.2. Macro-scale analysis ......................................................................................... 86 6.2.2.1. Analytical method .......................................................................................... 87 6.2.2.2. Numerical method .......................................................................................... 89 6.3. Results and model validation ............................................................................. 91 6.3.1. Elastic material .................................................................................................. 91 6.3.1.1. Micro-scale results ......................................................................................... 91 6.3.1.2. Meso-scale properties ..................................................................................... 93 6.3.2. Viscoelastic material ......................................................................................... 94 6.4. Discussion ......................................................................................................... 108 6.5. Summary and conclusions ............................................................................... 110 Chapter 7: Bending behaviour of multilayered viscoelastic plates with thin and soft interfaces ................................................................................................................. 113 7.1. Introduction...................................................................................................... 113 7.2. Method .............................................................................................................. 114 7.3. Macro-scale model ........................................................................................... 115 7.4. Results and model validation ........................................................................... 117 7.4.1. Elastic material ................................................................................................ 117 7.4.2. Viscoelastic material ....................................................................................... 119 7.5. 124 Chapter 8. Conclusions and recommendations ..................................................... 126 8.1. Summary .......................................................................................................... 126 8.2. Contributions and Key findings ...................................................................... 127 8.3. Limitations and recommendations for future studies ..................................... 128 Appendices .............................................................................................................. 130 A.1. Transformation matrix used in Eq. (3.7) ........................................................ 130 A.2. Differential approach to modelling generally orthotropic materials............. 130 A.3. Implementation ............................................................................................... 133 References ............................................................................................................... 134
Ist Of Figures
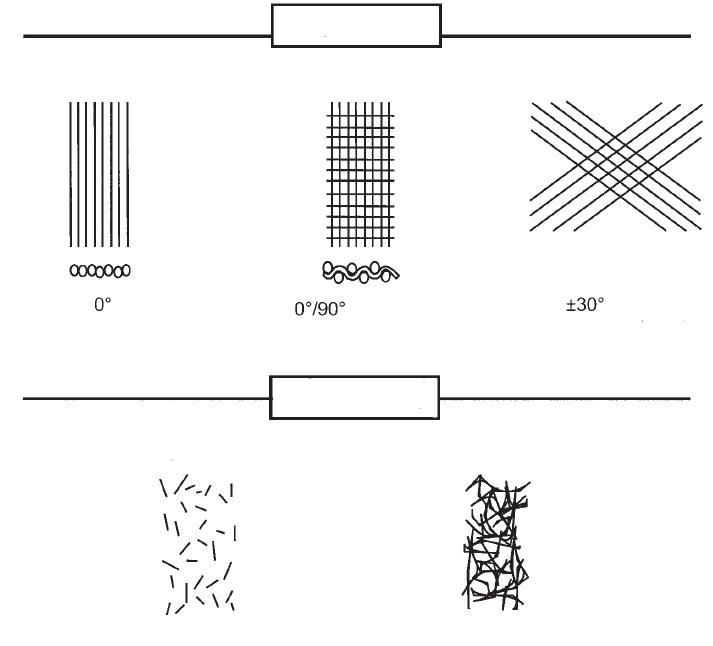
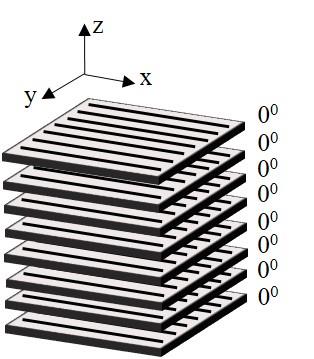
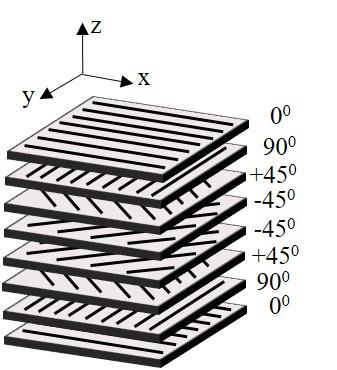
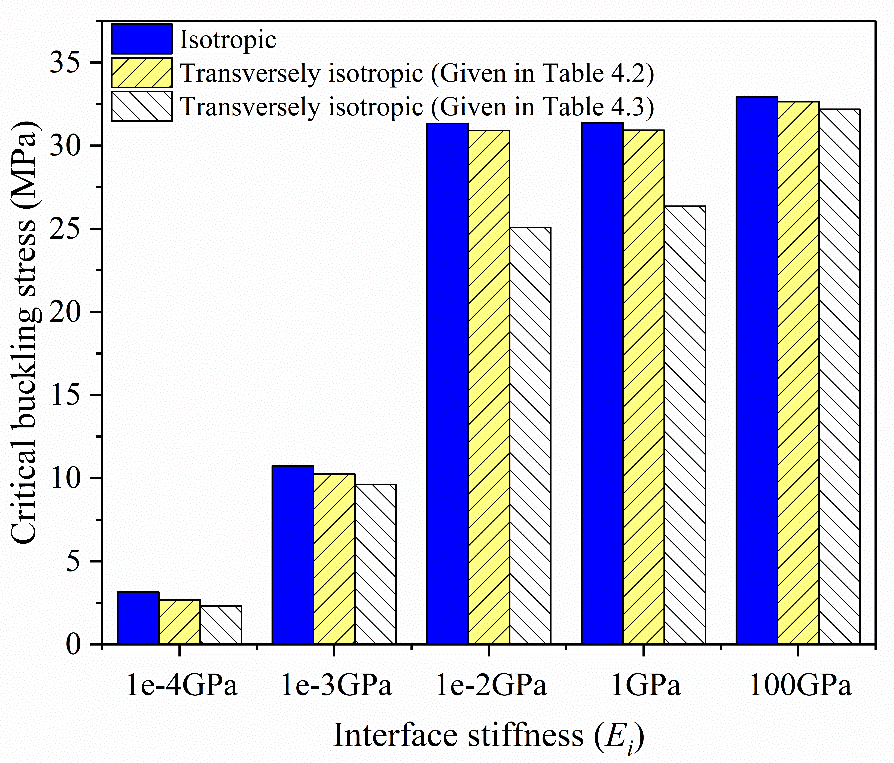
Figure 1.1: Typical reinforcement types ........................................................................ 2 Figure 1.2: Arrangement of plies in (a) a unidirectional (UD) layup (b) a quasi-isotropic layup ............................................................................................................................. 3 Figure 1.3: Classification of textile composites. ............................................................ 4 (Dixit & Singh 2013) .................................................................................................... 4 Figure 1.4: Schematic of the common weaves. (a) Plain weave. (b) Twill weave. (c) 5- harness (5HS) satin weave ............................................................................................ 5 Figure 1.5: Principle of autoclave curing ....................................................................... 6 Figure 1.6: Buckling of the plies due to the excess length with fixed ends during consolidation (Adapted from Belnoue et al. (2018)) ...................................................... 8 Figure 1.7: Thesis structure ......................................................................................... 16 Figure 2.1: Composite Cylindrical Assemblage (Malek 2014) ..................................... 18 Figure 2.2: Fibre bed deforms under shear stress. (a) Fibre bed deforms together with resin. (b) Fibre deforms under the overall shear stress. (c) Analog representation ............................ 21 (Malek, Thorpe & Poursartip 2011). ............................................................................... 21 Figure 2.3: Schematic of (a) mosaic model; (b) undulation model and (c) bridging model proposed by Ishikawa & Chou (1982) ......................................................................... 24 Figure 2.4: Unit cell of plain weave composite improved by Naik & Shembekar (1992) ................................................................................................................................... 25 Figure 2.5: Schematic of (a) “X model”; (b) “Y model” and (c) “Z model” developed by Tan, Tong & Steven (1999) ......................................................................................... 26 Figure 2.6: Schematic of (a) the representative unit cell in a 3D orthotropic laminated composite; (b) the discretised stripes of layer l; (c) global and local coordinate systems for stripe 1 (Wu, Brown & Davies 2002). .................................................................... 27 Figure 2.7: Schematic of 3 Stage Homogenisation Method (3SHM) developed by Hallal et al. (2012)................................................................................................................. 28 Figure 3.1: Schematic of the multi-scale modelling framework for viscoelastic modelling of orthotropic composites (Adopted from Malek (2014))............................................. 40 Figure 3.2: (a) The RUC geometry and notation for a 5-harness satin weave composite; (b)Yarn cross-sectional shape (c) Orientation angles ................................................... 44 Figure 4.1: Two types of analysis model employed for this study. ............................... 49 Figure 4.2: Composite layup ....................................................................................... 50 Figure 4.3: The role of interface stiffness and ply anisotropy on the multilayered cantilever beam rigidity............................................................................................... 53
Viii
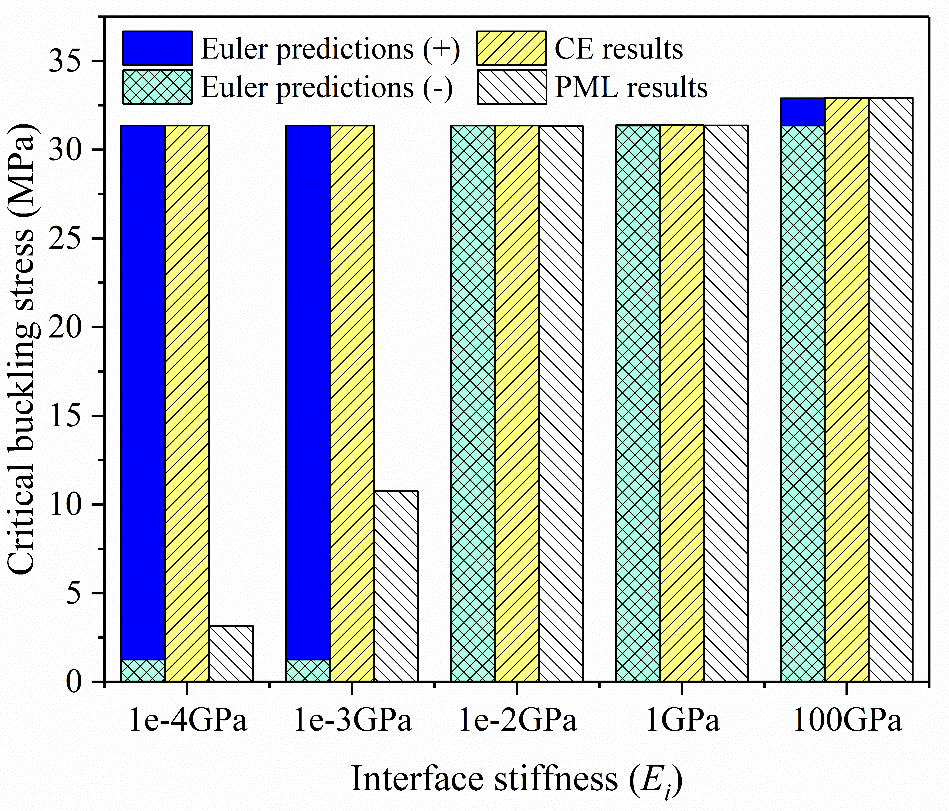
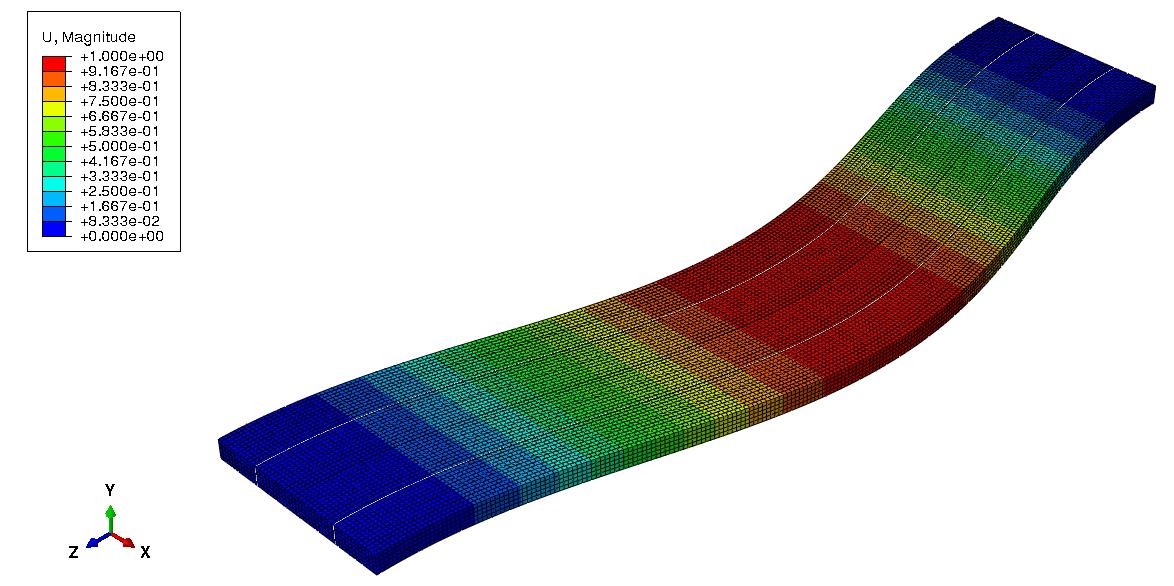
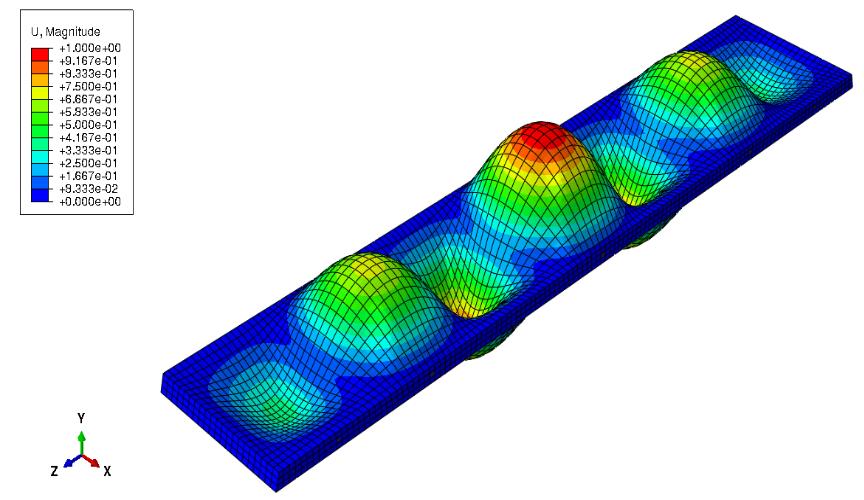
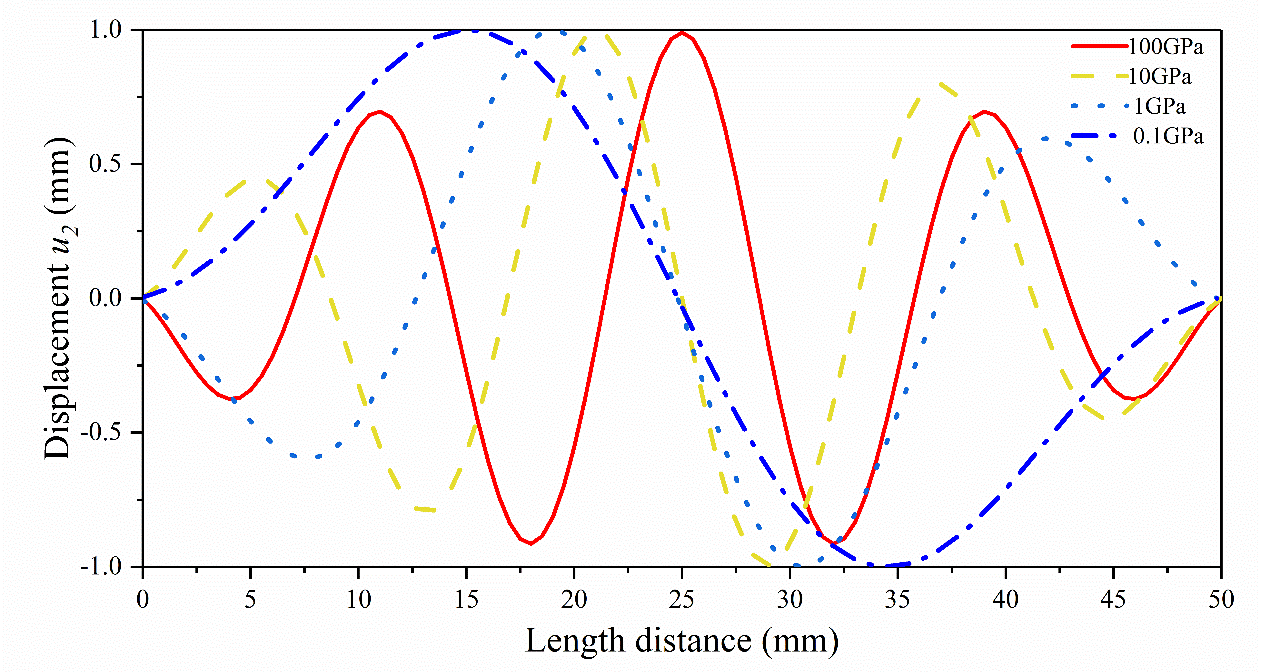
Figure 4.4: Comparisons of FE results with Euler predictions for isotropic plies (Ep= 100 GPa) bonded with a range of interfaces. ....................................................................... 54 Figure 4.5: Buckling mode shape for flat laminates with stiff interfaces (Ei = 100 GPa) using PML approach. The beam cross section is depicted on the right side. ................. 55 Figure 4.6: Buckling mode shape for flat laminates with stiff interfaces (Ei = 100 GPa) using Abaqus CE. The laminate layup is depicted on the right side for clarity. ............ 55 Figure 4.7: Buckling mode shape for flat laminates with soft interfaces (Ei = 100 kPa) using PML approach. ........................................................................................ 56 Figure 4.8: The influence of ply elastic constants on the buckling response of flat laminates using PML approach. .................................................................................. 57 Figure 4.9: Magnitude displacement (in mm) at critical buckling load – Composite element model – Ei = 100 GPa. ................................................................................... 58 Figure 4.10: Internal buckling wavelength along the beam length – Physically modelling layers. ......................................................................................................................... 59 Figure 5.1: Detail of the 3D model under axial displacement....................................... 64 (According to Wang, Long & Clifford (2009)) ............................................................ 64 Figure 5.2: FE mesh of the buckled laminated composite under axial loading ............. 66 Figure 5.3: Comparison of deformed shape and Mises effective stress (in MPa) at ultimate state for cured isotropic laminates with different mesh sizes: (a) Mesh 1 (b) Mesh 2 (c) Mesh 3 (d) Mesh 4 under uniform axial displacement. ................................................ 67 Figure 5.4: Comparison of the deformed shape (mode shape 1) obtained from the eigenvalue for the cured composite assuming: (a) isotropic (b) transversely isotropic material behaviour under uniform axial displacement. ................................................. 68 Figure 5.5: Effect of loading rate on force vs displacement relationship using IF (Case 2a). The resin viscoelastic properties are taken from Section 3.1.1 in Abaqus Benchmarks Guide. The material properties are listed in Table 5.5. 72 Figure 5.6: Comparison between IF (Case 2a) and DF (Case 2b) approaches for two presentative cases. The viscoelastic properties of the resin are provided in Section 3.1.1 in Abaqus Benchmarks Guide. .................................................................................... 73 Figure 5.7: Effect of Prony series constants on force vs displacement relationship using IF (Case 2a and 3a) and DF (Case 2b and 3b) viscoelastic model compare to isotropic model (Case 1). The same loading rate of 4.4 mm/min has been used in all cases. .................... 74 Figure 5.8: Stress relaxation response under tensile load calculated using: (a) a single- term Prony series (b) twelve-term Prony series............................................................ 75 Figure 5.9: Effect of Eo on the buckling behaviour of the isotropic viscoelastic laminates using IF. The resin viscoelastic properties are taken from Section 3.1.1 in Abaqus Benchmarks Guide (Case 2a) at rate of 10 mm/min. .................................................... 76
Ix
Figure 5.10: Effect of ply anisotropy on the buckling response of viscoelastic composites. Various resin viscoelastic properties are assumed as listed in Table 5.5 and the same loading rate of 4.4 mm/min is considered for all cases. ................................................ 79 Figure 5.11: Results of parametric studies: Effect of (a) increasing Eo (Case 5), (b) increasing E∞ (Case 6) and (c) higher Eo and E∞ (Case 7) on the buckling behaviour of the uncured orthotropic viscoelastic laminates using DF. The resin viscoelastic properties are provided in Table 5.4 (wi and τi) and Table 5.10 (Eo and E∞). The loading rate is 4.4 mm/min in all cases. ................................................................................................... 81 Figure 6.1: (a) Schematic of the multi-scale modelling approach for bending behaviour of 5-harness satin weave composites from micro-scale to macro-scale; (b) Flow chart depicting the analytical and numerical models utilized in the multi-scale analysis. ......... 85 Figure 6.2: Bending of a cantilever beam: (a) beam with load; (b) deflection curve; (c) cross-section of beam showing the x-axis as the neutral axis of the cross-section ........ 89 Figure 6.3: (a) Bending profile with tip displacement of 10 mm ...................................... 90 (b) Bending moment – curvature relation in the isotropic elastic beam (E = 500 MPa, υ = 0.2) .. 90 Figure 6.4: Detail of the 3D model under bending .......................................................... 97 (According to Alshahrani & Hojjati (2017b)) ................................................................. 97 Figure 6.5: Deformed sample at tip displacement of 50 mm (U3 in mm) .......................... 97 Figure 6.6: Bending moment versus curvature based on isotropic elastic material assumption. . 98 Figure 6.7: Bending moment versus curvature of uncured 5HS prepreg with different values of fibre stiffness (E1). A loading rate of 3 mm/s is considered for all cases. .... 107 Figure 6.8: Effect of loading rate on bending moment versus curvature of 5HS prepreg.
Fibre stiffness is assumed to be E1 = 1.5 GPa in all cases. ......................................... 107 Figure 6.9: Comparison between IF and DF approaches for the validation case (effective fibre modulus E1 = 1.5 GPa). The viscoelastic properties of the resin are provided in Table 6.9. ........................................................................................................................... 108 Figure 6.10: Comparision between prepreg and dry 5HS behaviour according to different assumed values for fibre stiffness, E1. ....................................................................... 110 Figure 7.1: Schematic of the multi-scale modelling approach for bending behaviour of 5- harness satin weave multilayered composites from micro-scale to macro-scale. ........ 115 Figure 7.2: Bending model of a three-layer plate. Each layer is separated by a thin interface of 0.01 mm (According to Alshahrani & Hojjati (2017a)) ........................... 116 Figure 7.3: FE mesh of the three-layer plate used in this study. Numbers of mesh are 30 × 75 × 24 in X, Y and Z respectively. ........................................................................ 117 Figure 7.4: Deformed sample at tip displacement of 30 mm (U3 in mm) under bending.
The top end is is restrained from all displacements in a length of 30 mm. .................. 117
X
Figure 7.5: The effect of interface properties on the bending loads. Required loads to reach a tip displacement of 30 mm at room temperature are compared using various material models. Resin viscoelastic properties selected for the orthotropic viscoelastic material model are provided in (Thorpe 2012). The model has the length of 150 mm, the width of 50 mm and the thickness of 1.67 mm. ......................................................... 121 Figure 7.6: The effect of interface properties on the bending loads in a thick laminate.
Required loads to reach a tip displacement of 30 mm at room temperature are compared using various material models. The model has the length of 80 mm, the width of 50 mm and the thickness of 3.91 mm. ................................................................................... 122 Figure 7.7: Stacking sequences of three-layer plate (a) Stacking 1 [0o/0o/0o]; (b) Stacking 2 [0o/45o/0 o]; (c) Stacking 3 [0o/45o/45o]; (d) Stacking 4 [45o/45o/0 o]. ...................... 123 Figure 7.8: Moment vs curvature for all selected stacking sequences at room temperature.
A loading rate of 3 mm/s is considered and the interface modulus, Ei, is assumed 7 MPa for all cases. Resin viscoelastic properties selected for the orthotropic viscoelastic material model are provided in (Thorpe 2012). ........................................................................ 124
Ist Of Tables
Table 2.1: List of experimental studies on deformation of uncured composites and calibrated material properties for the corresponding FE simulations. ........................... 37 Table 4.1: Comparisons between current FE predictions, Dodwell (2015)’s FE results, and the analytical model based on Euler-Bernoulli kinematics (Eq. 4.1) for a multilayered cantilever beam (Case I). ............................................................................................. 52 Table 4.2: Input properties of the transversely isotropic plies. ..................................... 52 Table 4.3: Input properties of the transversely isotropic plies. 56 Table 4.4: Comparisons of FE results between composite element models and models layered physically – Ep = 100 GPa for all cases ........................................................... 57 Table 5.1: Input properties according to Wang, Long & Clifford (2009) for the cured sample ........................................................................................................................ 64 Table 5.2: Mesh convergence study results ................................................................. 66 Table 5.3: Comparisons of critical buckling loads between theoretical result and eigenvalue and large deformation analyses for the cured composite assuming isotropic and transversely isotropic input parameters. ................................................................ 68 Table 5.4: Prony series parameters for MTM45-1 epoxy as reported in Thorpe (2012) 70 Table 5.5: Summary of case studies considered in Section 5.3..................................... 70 Table 5.6: The shear moduli Gi associated with the specific relaxation time, τi used for Case 3b. ...................................................................................................................... 73 Table 5.7: Material properties of fibre, resin and fibre bed used in the buckling simulation of composite laminates. ............................................................................................... 77 Table 5.8: Relaxed and unrelaxed values of components of the composite relaxation matrix. ........................................................................................................................ 78 Table 5.9: Prony series parameters for each component of the relaxation matrix of the composite material obtained from micromechanics equations following the approach presented in Malek (2014). .......................................................................................... 79 Table 5.10: Parametric case studies conducted for determining the effect of resin properties on the post buckling response of uncured laminates. ................................... 80 Table 6.1: Constituent material properties used for cured and uncured UD thermoset composite according to Ersoy et al. (2010). ................................................................. 92 Table 6.2: Comparison of the UD composite material properties obtained by the present analysis (Malek 2014) and data available in the literature (Ersoy et al. ............ 93 Table 6.3: Yarn and resin properties used in validation model for woven composite properties according to Naik (1994). ........................................................................... 94 Table 6.4: Comparison of results for cured woven composites. 94
Xii
Table 6.5: Mesh convergence study results (isotropic elastic case (E = 700 MPa, ν = 0.4)). ................................................................................................................................... 98 Table 6.6a: Input material properties of fibre, resin and fibre bed used in the bending simulation of textile prepregs. The compressive properties have been assigned to the bending model. ........................................................................................................... 99 Table 6.6b: Input material properties of fibre, resin and fibre bed used in the bending simulation of textile prepregs. The tensile properties have been assigned to the bending model. ....................................................................................................................... 100 Table 6.6c: Input material properties of fibre, resin and fibre bed used in the bending simulation of textile prepregs. The effective bending properties have been assigned to the model. 100 Table 6.7a: Micro-scale predictions of UD mechanical properties using micromechanics equations with fibre-bed effect (Malek 2014) under compressive load. ..................... 101 Table 6.7b: Micro-scale predictions of UD mechanical properties using micromechanics equations with fibre-bed effect (Malek 2014) under tensile load. ............................... 102 Table 6.7c: Micro-scale predictions of UD mechanical properties using micromechanics equations with fibre-bed effect (Malek 2014) under bending load. ............................ 102 Table 6.8a: Meso-scale predictions of 5HS prepreg mechanical properties under compression using the analytical technique of Naik (1994). ...................................... 103 Table 6.8b: Meso-scale predictions of 5HS prepreg mechanical properties under tension using the analytical technique of Naik (1994). ........................................................... 103 Table 6.8c: Meso-scale predictions of 5HS prepreg mechanical properties under bending using the analytical technique of Naik (1994). 103 Table 6.9: Prony series parameters for MTM45-1 epoxy as reported in Thorpe’s thesis (Thorpe 2012). .......................................................................................................... 104 Table 6.10: Relaxed and unrelaxed values of components of the composite relaxation matrix. The effective bending properties have been assigned to the model at micro-scale.
................................................................................................................................. 105 Table 6.11: Prony series parameters for each component of the relaxation matrix of the composite material obtained from micromechanics equations following the approach presented in Malek et al. (2018). The effective bending properties have been assigned to the model at micro-scale. .......................................................................................... 105 Table 6.12: Summary of composite properties for UD and 5HS prepregs, as well as dry UD and 5HS according to different values of fibre stiffness, E1. ................................ 109 Table 7.1: Comparisons between current FE predictions and the analytical model (Warren & Richard 2002) ....................................................................................................... 118 Table 7.2: Input properties of the plies ...................................................................... 119
Xiii
Table 7.3: Input material properties of fibre, resin and fibre bed used in the bending simulation of textile prepregs (Le et al. 2022). .......................................................... 120 Table 7.4: Meso-scale predictions of 5HS prepreg mechanical properties under bending using the analytical technique of Naik (1994). ........................................................... 120
Abstract
Carbon fibre is known for its high strength, light weight and durability. The aerospace and automotive industries have demonstrated a strong interest in utilising carbon fibre when designing their structural parts. However, there are still barriers preventing other industries from realising the full potential of such advanced laminated composites. Among these challenges are the formation of wrinkles and defects throughout the manufacturing process. Currently, manufacturing composite parts with mitigation of defects greatly relies on the designers’ experience and the outcomes of trial-and-error procedures. Due to the high cost of experiments and a large number of process parameters involved in composite manufacturing, an improved understanding of wrinkle formation is desirable for industries. Therefore, predictive modelling to aid design engineers in their understanding of the wrinkling phenomenon has become vital over the past two decades.
According to a few recent studies, fibre waviness, misalignment and the complex viscoelastic behaviour of a composite’s layered structure during cure are the primary causes of defects, wrinkle formation, and eventual rejection of large composite components. However, the relationship between these factors and the wrinkling of plies caused by micro-buckling has not been investigated quantitatively. Furthermore, these efficient strategy for analysing the multi-scale mechanisms of wrinkling due to buckling of plies during the composite consolidation process. A multi-scale approach that can be incorporated into current process models is proposed for this purpose. Using the suggested approach, the wrinkling response of plies under compressive and bending loads are predicted numerically. Wrinkling wavelengths and critical buckling strength of flat laminates are compared with wrinkling profiles and the strength values reported in the literature. Unlike previous studies, the viscoelastic contribution of resin as well as fibre stiffness and fabric architecture (for woven composites) are taken into account. The effect of these parameters on the buckling behaviour of fibres and the orthotropic nature of plies are also investigated at different scales, quantitatively. Results highlight that the viscoelastic properties of the resin have a considerable effect on the buckling response of woven composites and thus on wrinkle formation during the early stage of cure.
Experimental studies are suggested for characterizing the viscoelastic behaviour of resins and its effect on the micro-buckling response of fibres during cure.
Aminated Composites
A composite material is composed of at least two materials or constituents. Often, the resulting material exhibits improved properties over its constituents. The two constituents are often a reinforcement fibre and a bonding matrix. Fibre reinforcements may include glass, aramid, natural fibres (e.g. wood or flax) and carbon, which may be continuous or discontinuous. Three examples of continuous fibre reinforcements are unidirectional (UD), woven fabric and helical winding fibres, as shown in Fig. 1.1a.
Examples of discontinuous reinforcements include glass fibres and wood strands (mat) (Fig. 1.1b). The primary role of fibres is to provide strength and stiffness. Fibres carry longitudinal loads while the matrix secures them in place and distributes the loads among the tensioned fibres. The matrix is also the primary load carrier for shear between the layers and in the transverse direction. Although unreinforced fibres are incapable of carrying compressive loads, reinforced composites can do so via this shear transfer mechanism between matrix and fibre. Polymers, metal or ceramics can all be used as matrix materials. Thermoset-based or thermoplastic-based matrices can be used to manufacture polymeric composites. Under elevated temperatures, uncured thermosets have low viscosities such that fibre reinforced thermoset composites can be consolidated and cured under low pressure, forming an intractable solid. In contrast, a thermoplastic forms a high-viscosity polymer melt if heated above its melting temperature during processing and requires higher pressures for consolidation. Unlike thermosets, thermoplastics can be reheated for additional processing and recycling. In this study, only thermoset composites are considered.
Laminated composites are made by stacking composite sheets (i.e. lamina) in different orientations to obtain the desired strength and stiffness properties. Unidirectional (0o) layup as depicted in Fig. 1.2a is extremely strong and stiff in the 0o direction, yet it is a lot more compliant and brittle in the 90o direction because the load must be carried by the much weaker polymeric matrix. For some structural applications, it is necessary to balance the load-carrying ability in a number of different directions, for instance 0o, +45o, -45o and 90o. The quasi-isotropic laminate illustrated in Fig. 1.2b is often preferred in practice since its stiffness is independent of loading direction.
(B)
Figure 1.2: Arrangement of plies in (a) a unidirectional (UD) layup (b) a quasi-isotropic
Textile Composites
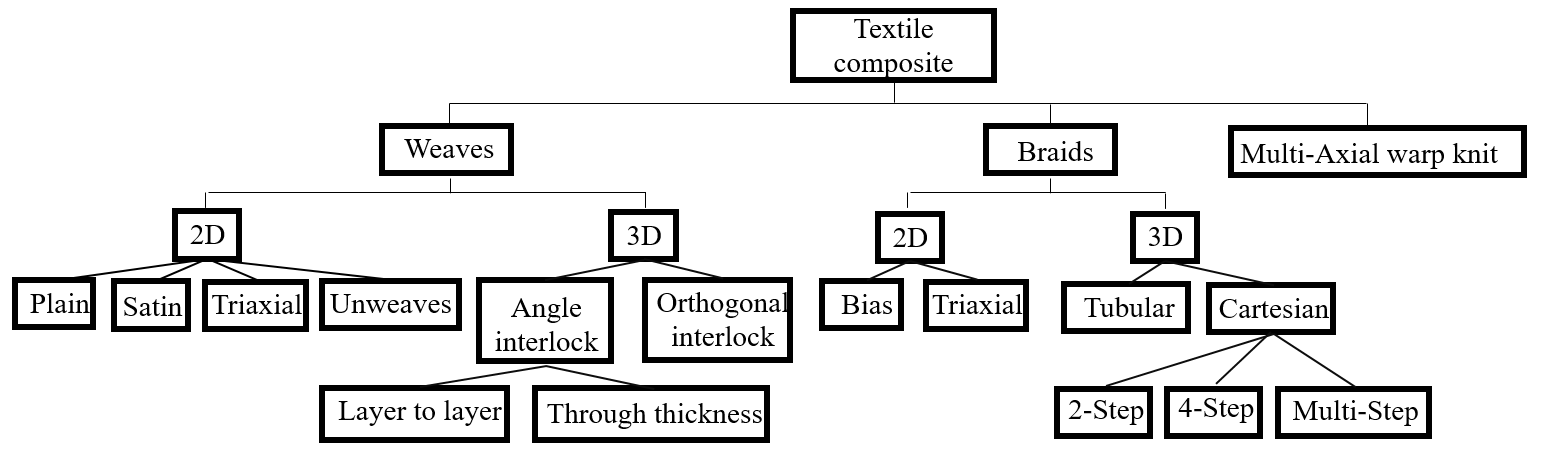
Textile composites provide an attractive alternative to unidirectional composites (UD) because they offer superior forming capabilities to produce complex shapes. Several scales are evident on the internal structure of textile composites. During the manufacturing process of textile composites, four important levels are usually categorised (Dixit & Singh 2013). Firstly, fibres are assembled into yarns. A yarn has a large length and a relatively small cross-section, with and without twist. The fibres are then arranged into a sheet, which is referred to as a fabric. Finally, composite part is consolidated by the infiltration of resin and curing in a mould. Textile composites can be classified into three categories as shown in Fig. 1.3, based on textile techniques used, such as weaving, braiding and knitting (Long 2005).
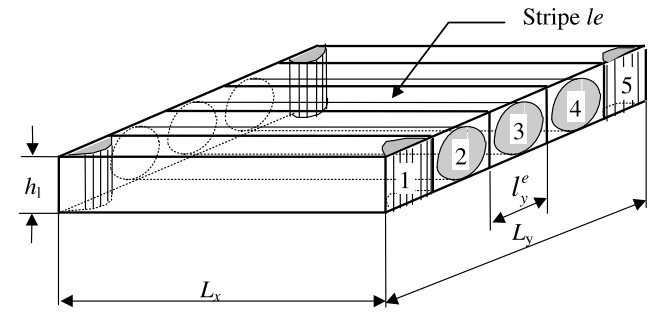
Figure 1.3: Classification of textile composites.
(Dixit & Singh 2013)
Woven fabric textile composites are created by the interlacing of warp fibre tows and weft fibre tows in a regular pattern or weave style. Fig. 1.4 shows the most common weave styles that present how the warp and weft tows are interwoven. Three-dimensional (3D) woven fabrics have additional yarns placed in through-the-thickness direction.
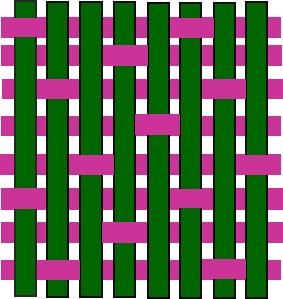
Currently, most of the woven fabrics used in textiles are simple 2D fundamental weaves, i.e., plain, twill and satin weaves, which are identified by the repeating patterns of the interlaced regions in warp and weft directions (Alshahrani 2017). Plain weave is the most commonly used basis reinforcement for woven composites. In a plain weaving structure, one warp yarn is repetitively woven over and under weft yarns as shown in Fig. 1.4a.
Such frequent undulation of yarn reduces the composite’s strength and stiffness. Twill weave has a looser interlacing and the weave is characterised by a diagonal line. Satin weave has a good drapability (Alshahrani 2017) with a smooth surface and minimum thickness. In a satin weave (seen in Fig. 1.4c), one warp yarn is woven over ng (ng > 2) successive weft yarns, and then under one weft yarn. This weave structure which features disconnected interlaced regions, is referred to as (ng + 1) – harness satin weave. The selected weave style used in Chapter 6 is 5HS satin weave as shown in Fig. 1.4c.
Weft Yarn
Figure 1.4: Schematic of the common weaves. (a) Plain weave. (b) Twill weave. (c) 5-
Harness (5Hs) Satin Weave
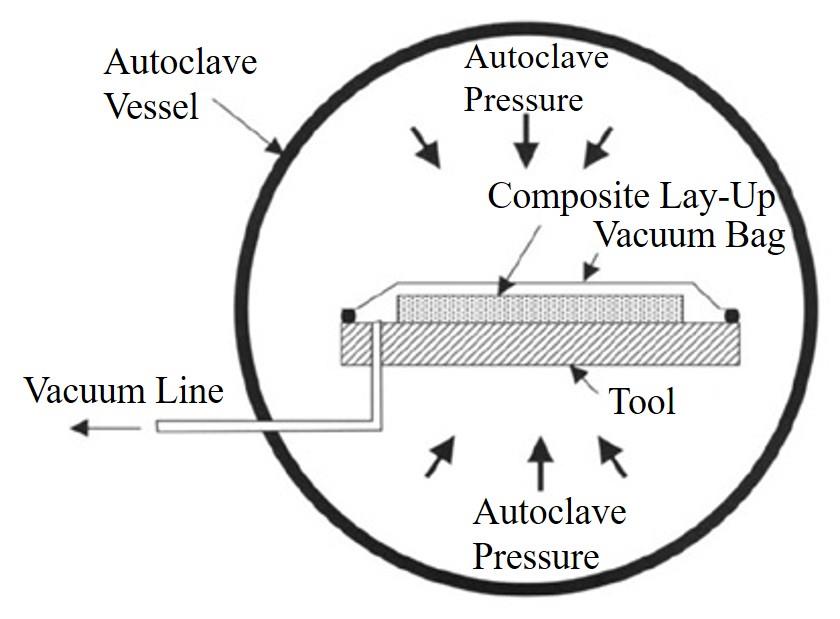
1.3. Overview of composite manufacturing techniques Fibre reinforced plastics (FRP) can be manufactured in a variety of ways. While recognise the profound effect that the manufacturing routes and processes have on the final properties of composite materials due to their effect on the microstructure and internal stresses. Autoclave processing is commonly employed for aerospace applications. In this process, composite components are fabricated by laying up multiple layers, usually pre-impregnated fibre sheets with B-stage cured resin (i.e. prepregs), on the mould surfaces in specified orientations until the appropriate thickness is achieved.
They are then sealed in a flexible bag and consolidated using a vacuum or pressure bag in an autoclave vessel at the required curing temperature and pressure. The autoclave curing process is demonstrated in Fig. 1.5.
Applications And Challenges
Carbon fibre-reinforced plastics (CFRPs) have been widely used in engineering applications in recent years due to their excellent characteristics relative to their weight (Friedrich & Almajid 2012). This rapid growth has been achieved mainly by the substitution of traditional materials, primarily metals in structural members. If only strength or stiffness is compared with those of metal alloys, fibre-reinforced composite materials do not provide a clear advantage. However, the strength and stiffness per unit weight of composite materials, also known as specific strength and specific modulus respectively, are factors of great importance in engineering design (Hilburger & Starnes Jr 2002; Leissa 1987). Moreover, composite materials can be tailored to generate different directional properties which potentially can contribute to reducing structural weight.
Apart from inheriting high strength and stiffness of the fibres, the composite materials maintain the chemical resistance of the plastic. The cost savings associated with routine maintenance constitute an important factor for the preference of these advanced materials in deep-water applications (Beyle et al. 1997).
In civil infrastructure, application of CFRPs in strengthening structural elements has been explored in recent decades. Compared to conventional reinforcing materials (i.e. steel), the lightweight CFRPs are easy to handle and do not need any heavy lifting and handling equipment. Such advantages make CFRPs more widely accepted for the repair and rehabilitation of steel buildings (Danilov 2016; Täljsten, Hansen & Schmidt 2009).
Additionally, due to durability under cyclic loading conditions and corrosion resistance, CFRP plates have been employed extensively for the maintenance or repair of old bridges and infrastructure (Bocciarelli et al. 2009). Furthermore, the use of composites for electrical towers, light poles or the blades of large wind turbines has also increased markedly.
Advanced composites are also replacing steel and aluminium parts in aircraft and road vehicles. In fact, the primary structural elements of the Boeing 787 Dreamliner and the Airbus A350 XMW including the wing and fuselage are built mostly from composite materials. It was reported by Soutis (2005) that in the twenty-first century, CFRPs can and will contribute to more than 50% of the structural mass of an aircraft. More recently, automobile manufacturers like BMW, Mercedes-Benz and Lamborghini have been moving towards increased carbon fibre usage in their vehicles. With automakers putting a priority on fuel economy, it is predicted that CFRPs will soon be the preferred material for the bodies of future cars. Due to the fact that corrosion is a significant issue and expense for the maritime industry, the hulls of boats ranging in size from small fishing boats to huge racing yachts have consistently been constructed using composite materials comprised of glass fibres and polyester or vinyl ester resins. Masts and scuba tanks are other applicants of composites improving the marine industry.
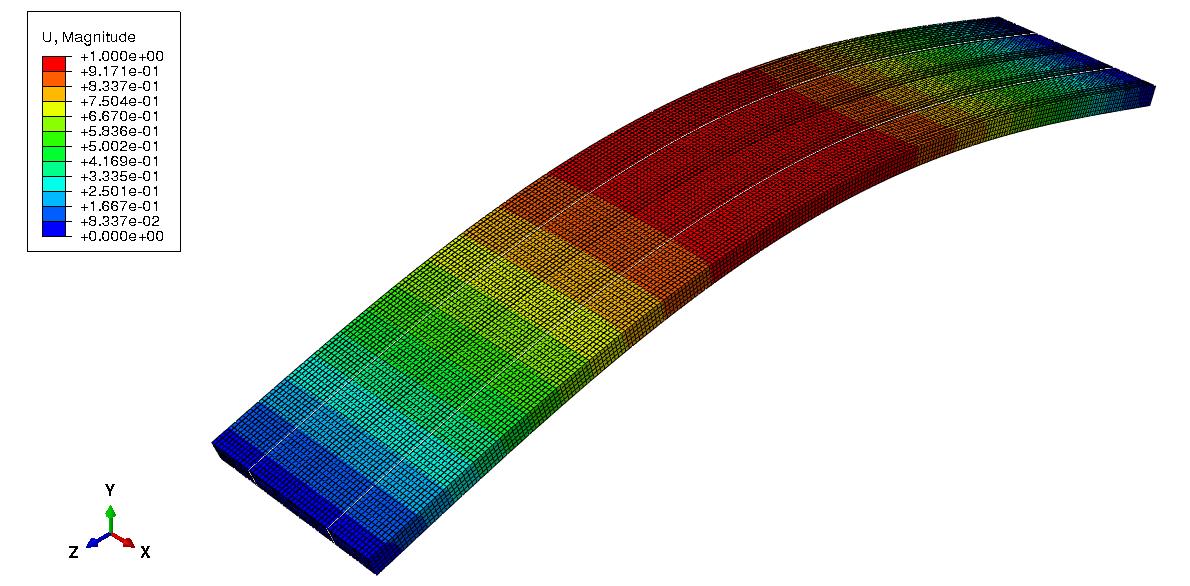
Despite their great benefits, the uncured composite prepreg materials are susceptible to defects in the course of the manufacturing process (Belnoue et al. 2018; Bloom, Wang & Potter 2013; Boisse, Huang & Guzman-Maldonado 2021; Hallander, Sjölander & Åkermo 2015; Johnson et al. 2019; Rashidi et al. 2021). For example, under a predefined heat and pressure cycle in an autoclave, the resin changes from a liquid to a solid. The major transformation in terms of physical and mechanical properties contributes to the change in thickness and subsequent formation of defects (often referred to as wrinkles). When forming quasi-isotropic, multilayer unidirectional (UD) prepreg over a double curved geometry, out-of-plane wrinkling is a general problem (Hallander et al. 2013).
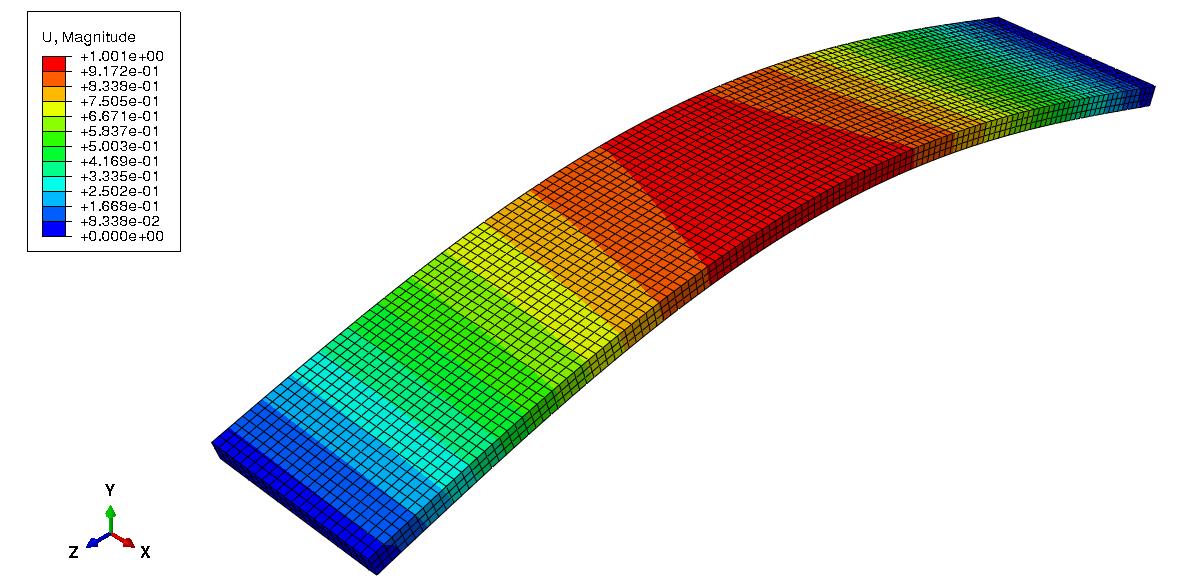
Furthermore, the components commonly used for aerospace applications consist of multiple thin sheets (plies) of unidirectional (UD) carbon or glass fibres. When they are subjected to compressive stresses that usually occur during various curing processes, out-of-plane misalignment of the fibre paths, generally known as wrinkling is a relatively common phenomenon (Alshahrani & Hojjati 2017c; Wang, Long & Clifford 2009; Weber et al. 2019). Based on an experimental study, Wang et al. (2011) developed three fabrication techniques to generate fibre waviness within flat laminates. These techniques were aimed at creating similar wrinkling patterns to those usually observed in industrial that out-of-plane defects also occur in a recess area where a tensile force is applied globally. This is due to the development of local compressive forces in some areas during the forming process.
Wrinkles are more likely to be formed when composite plies have excess length and restrained from slipping over one another due to friction or fixed ends (Dodwell, Butler & Hunt 2014; Weber et al. 2019). As shown in Fig. 1.6, under the applied debulk pressure during the consolidation of the uncured curved laminate, the reduction of the thickness results in a diminished length from lbefore to lafter. Meanwhile, the applied boundary constraints prevent plies from moving with respect to another. Therefore, buckling of the plies is the only way to accommodate that excess length. Lightfoot, Wisnom & Potter (2013) proposed a mechanism for the formation of ply wrinkles due to shear forces between plies. Such forces were the result of mismatches in the coefficient of thermal expansion between composite and tool or ply slippage during consolidation.
Figure 1.6: Buckling of the plies due to the excess length with fixed ends during consolidation (Adapted from Belnoue et al. (2018)) The presence of wrinkled fibre compromises the service life of the components as it can lead to a very significant reduction in mechanical performance such as compressive strength (Lightfoot, Wisnom & Potter 2013; Varkonyi et al. 2019). In comparison with stresses at initial failure stage of samples without defects, out-of-plane wrinkles with all plies affected and in-plane wrinkles with 50% of plies affected made significant reductions to about 25% and 50% of the corresponding stresses (Potter et al. 2008).
Lbefore
Therefore, the wrinkle formation mechanisms need to be better understood in order to mitigate them in the manufacturing process (Alshahrani & Hojjati 2017c). Specific material properties of prepregs or their constituents may affect wrinkle formation differently. A mere 5% variation in the thickness of a tapered laminate can result in a dramatic difference in the severity of wrinkles (Belnoue et al. 2018). Forming temperature, consolidation pressure and layup sequence were found to be important contributors to the fibre misalignment in hot drape forming process of a C-shaped part (Farnand et al. 2017). Furthermore, although process simulation has advanced significantly in recent years, currently, mitigating defects during composite manufacturing relies heavily on the designers’ experience and trial-and-error methods (Belnoue et al. Proceeding with trials is very expensive and a large number of process parameters is required. For this reason, predictive modelling and improved understanding of the involved wrinkling phenomena are now of paramount importance to the industrial and scientific community.
Previous results have shown that the forming behaviour of a composite was influenced by the uncured material properties of its plies such as their stiffness as well as their geometrical characteristics (Larberg & Åkermo 2011), resin compound, degree of impregnation and level of consolidation (Hubert & Poursartip 2001; Lukaszewicz & Potter 2011). Moreover, viscous composite materials generally exhibit non-linear bending behaviour. The fibres in a composite are assumed to be rigid and inextensible.
Due to the mobility of polymer matrix, these fibres are free to move relative to one another. This imparts some flexibility to the composite and reduces its bending rigidity in comparison to solid composites (Boisse et al. 2018). A computational tool which is able to relate the flexibility of plies to the wrinkle formation is still missing. With this in mind, it is envisioned that a multi-scale model should be developed for analysing the wrinkling response of plies during the consolidation process.
Knowledge Gaps
Some knowledge gaps in predicting the wrinkle formation during consolidation
Of Thermoset Composites Are Identified Below:
▪ There is a lack of validated and efficient FE models capable of predicting wrinkle formation during processing. ▪ Some existing models (Belnoue et al. 2018; Hallander et al. 2013; Johnson et al. 2019) have been developed for specific curved part geometries and processes such as draping or autoclave. However, the wrinkle formation in flat laminates (i.e. those used in the construction industry) at the early stage of manufacturing has not been investigated in detail.
▪ The accuracy range of commercial tools such as Abaqus built-in composite element for predicting the response of composites with soft interfaces which is relevant to the early stage of cure has not been assessed.
▪ Despite some experimental evidence (Alshahrani & Hojjati 2017b; Larberg & Åkermo 2014; Wang, Long & Clifford 2009), the effects of ply anisotropy, fibre bed and viscoelasticity on the buckling behaviour of composites are not well understood.
▪ Although out-of-plane bending has been well known as one of the deformation mechanisms governing wrinkle formation during composite manufacturing, predictions of the out-of-plane properties of viscoelastic composites with various fibre architecture have not been examined comprehensively.
▪ Multi-scale modelling that accounts for micro-structural effects on the macro- structural response during cure has not been investigated experimentally and numerically.
▪ The properties of the uncured composites that should be used to represent bending behaviour in the finite element model for forming simulation are still not well understood.
▪ Contribution of complex deformation mechanisms such as in-plane shear, out- of-plane bending and inter-ply slippage during forming process of laminated composites has not been investigated comprehensively.
Research Objectives
one is to investigate the buckling response as well as load-displacement curves of viscoelastic composite laminates under compression for a better understanding of the ply wrinkling behaviour at the early stage of thermoset composite manufacturing. The second one is to develop a multi-scale model for predicting efficiently the effect of various parameters on wrinkle formation such as fibre stiffness, loading rates, ply anisotropy, resin properties and yarn’s architecture on the bending behaviour of viscoelastic
Laminates. Specific Research Tasks Are To:
▪ Examine the ability of commercial FE tools, e.g. Abaqus in simulating the buckling behaviour of laminated composites with many numbers of layers and soft thin interfaces.
▪ Perform nonlinear FE analysis to investigate the ultimate compressive strength and the post-buckling behaviour of UD thermoset carbon/epoxy prepreg sheets during the manufacturing process.
▪ Employ various material models (e.g. isotropic elastic, transversely isotropic and orthotropic viscoelastic) to demonstrate the importance of consideration of the rate dependence in describing the behaviour of prepreg materials.
▪ Incorporate viscoelastic micromechanical models proposed by Malek et al. (2014) in a commercial FE software Abaqus to determine the effective time- dependent response of large composite parts.
▪ Compare the buckling behaviour as well as load-displacement curves obtained from the present multi-scale analysis with the experimental results available in the literature for validation purposes.
▪ Conduct a mesh convergence study to determine the efficient mesh size that should be used throughout this study. ▪ Conduct parametric studies on the effect of viscoelastic parameters of the resin such as assumed unrelaxed/ relaxed moduli, relaxation times and weight factors on the post-buckling response of uncured laminated composites.
▪ Predict the effective mechanical properties and structural responses such as buckling and bending behaviours depending on constituent property (e.g. fibre stiffness), different fabric architectures and loading conditions.
▪ Determine the overall stiffness of elastic/viscoelastic woven composites using micromechanical equations developed by Naik (1994) and implement in MATLAB. The analytical procedure is verified/validated wherever experimental data are available.
▪ Investigate deformation mechanisms that may occur simultaneously during the formation of woven composites such as in-plane shear, out-of-plane bending or inter-ply slippage.
Thesis Structure
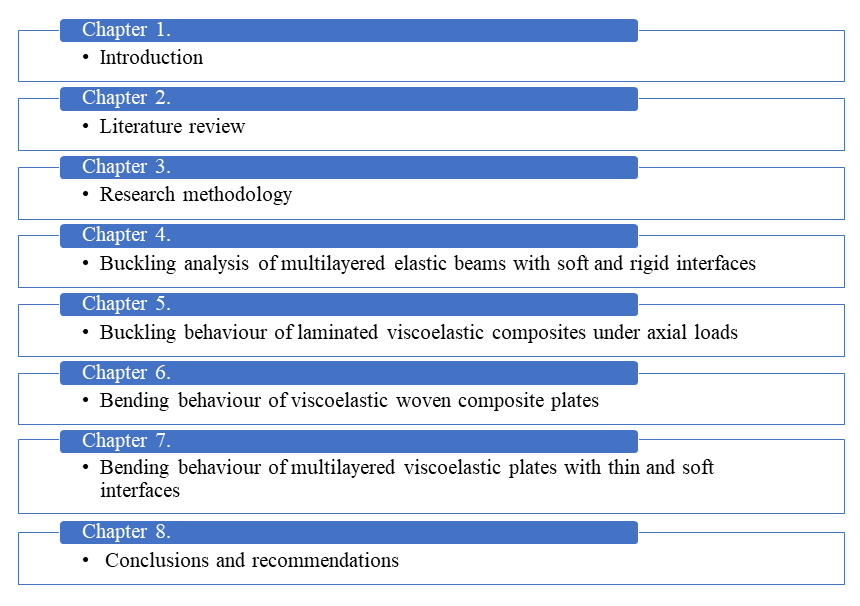
Based on these objectives, the thesis is organised as shown in Fig.1.1 and the chapter progression of the thesis is illustrated as follows:
Hapter 1: Introduction
This chapter presents a brief introduction to composite materials such as unidirectional (UD) and woven prepregs so that their buckling and bending behaviours during the forming process are later investigated in Chapter 5 and Chapter 6 respectively.
Recent engineering applications in different sectors and challenges relating to wrinkling formation during the manufacturing process are also stated to highlight the significance detail.
Hapter 2: Literature Review
A review of micromechanical models for estimating the elastic properties of unidirectional composites is first carried out. However, a comprehensive study had already been done in the literature (Malek 2014). Therefore, only analytical micromechanics equations selected in the current proposed multi-scale modelling framework are shown for clarification purpose. In addition, for thermoset composites during cure, fibre bed referring to the slight waviness of the fibres in prepregs is believed to play a significant part in carrying the load in the transverse fibre orientation. Hence, how to consider such an effect on the viscoelastic properties of composites during cure using an appropriate analogue representation is also revisited for later application in predicting the effective mechanical properties of composites and presented in this chapter.
Secondly, a review of meso-mechanical models for elastic analysis of textile composites is conducted. Both analytical and numerical models in the literature have been presented for estimating the effective mechanical properties of specific composites in terms of geometry modelling and homogenisation techniques. After considering applicability of the reviewed approaches for the current multi-scale modelling framework, the analytical technique proposed by (Naik 1994) for calculating the homogenised material properties of 5HS satin weave is selected and shown in Chapter 3.
Thirdly, as a first step in providing a better understanding of wrinkle formation, the buckling behaviour of laminated viscoelastic composites under axial loads is reviewed. Subsequently, the bending behaviour of viscoelastic woven composite is studied because the bending properties of uncured thin laminates have been known to govern the appearance of wrinkles, particularly in determining the shape of wrinkles.
Finally, to create a reliable forming simulation, the properties of the uncured material must be known and properly represented in the finite element model. A review in detail of experimental studies on uncured composites and calibrated material properties for the corresponding FE simulations is also undertaken. This is done to better understand the mechanical properties of such composites and their constituents under bending.
Hapter 3: Methodology
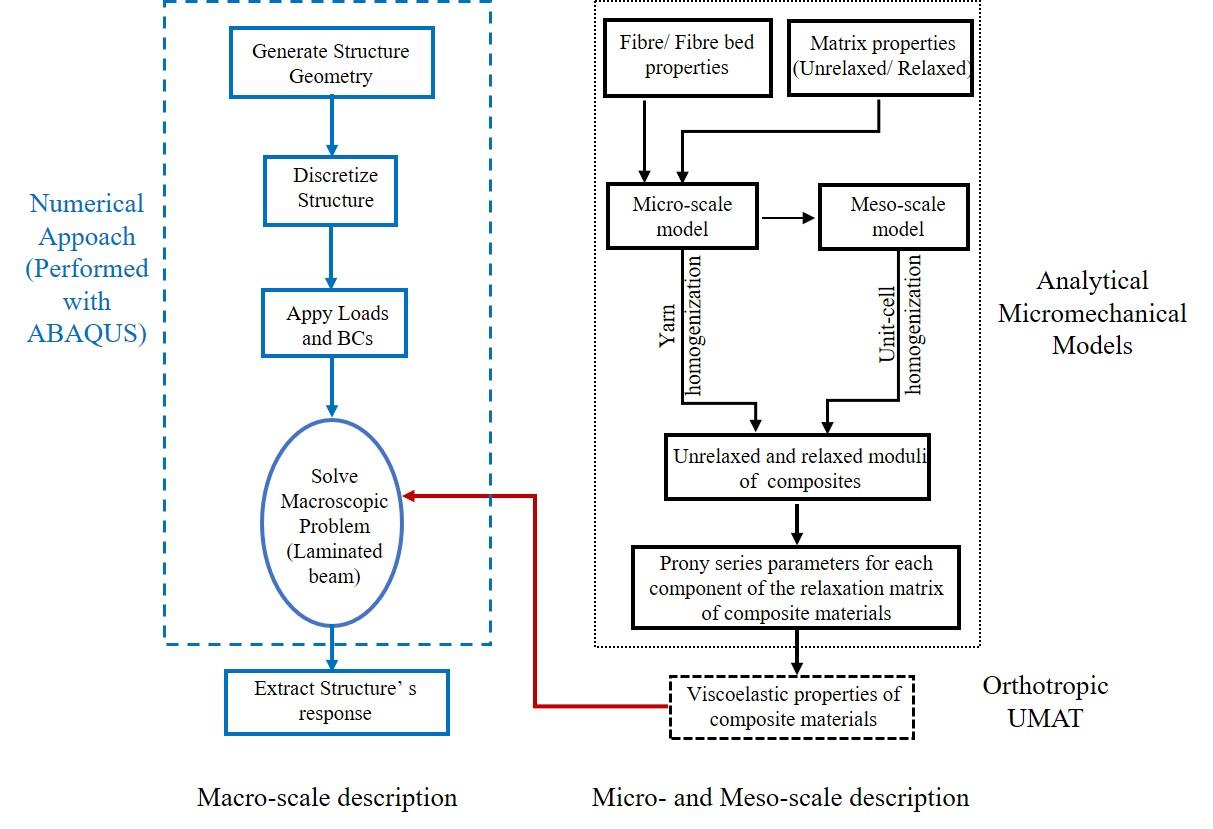
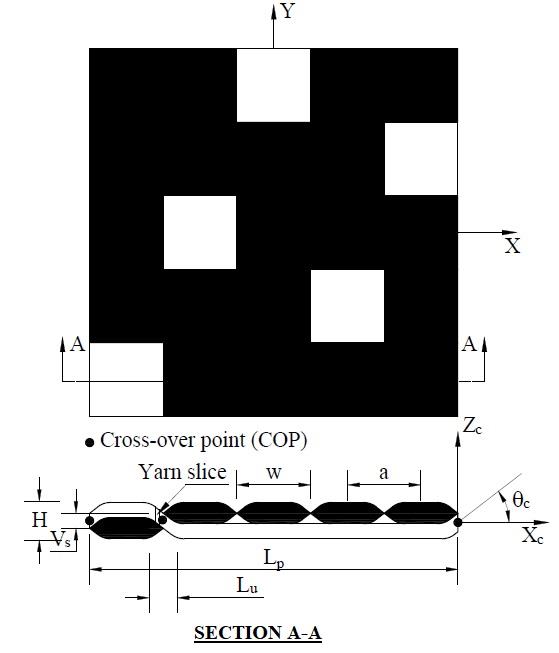
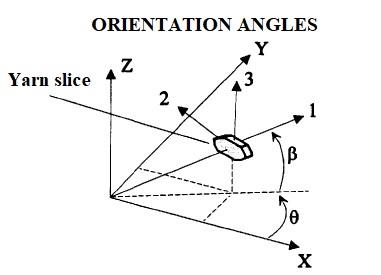
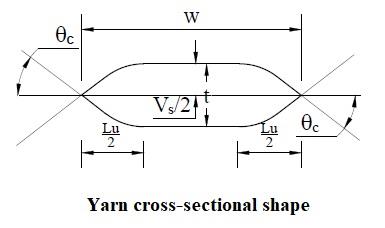
The chapter describes in general a multi-scale method that is used throughout this study to analyse wrinkling (i.e. buckling and bending responses) during consolidation of thermoset composites. At smaller contexts such as micro and meso levels, the effective viscoelastic properties of a unidirectional Representative Volume Element (RVE) or Repeating Unit Cell (RUC) of the woven fabric reinforced composites are determined using analytical models. Details of the geometric modelling technique of 5HS satin weave as well as discretisation technique of yarns and calculation of three-dimensional effective stiffnesses are presented in this chapter. A specific MATLAB script is written to facilitate the computation of the effective properties of the fabric at the meso-scale with given quantities. The transformation matrix [Tm] used in expression of effective stiffness matrix is documented in Appendix A.1.
At the macro-scale, both analytical and numerical methods are considered. The analytical approach involves different simple mathematical equations for specific particular mathematical equations are presented in a separate chapter according to certain problems of concern. In terms of numerical approach, the finite element method using commercial software, Abaqus is used to predict the structural responses such as buckling or bending of both elastic and viscoelastic composite plates at various loading rates. For viscoelastic analysis, the composite plate is first assumed to behave as an isotropic viscoelastic solid and modelled using the Abaqus built-in viscoelastic constitutive model which is based on the integral form (IF) of viscoelasticity. Since the application of Abaqus viscoelastic model is limited to isotropic materials, a more versatile orthotropic viscoelastic constitutive model (based on a differential form of viscoelasticity – DF) that has been developed and implemented as a UMAT by researchers (Malek 2014; Zobeiry et al. 2016) is employed to elucidate the effect of ply anisotropy on the structural responses of uncured/ partially cured composite plates. For this purpose, both numerical approaches using Abaqus built-in viscoelastic model (IF) and orthotropic viscoelastic user material model (UMAT) are shown in this chapter. The DF approach and its implementation in Abaqus are briefly described in Appendices A.2 and A.3 respectively.
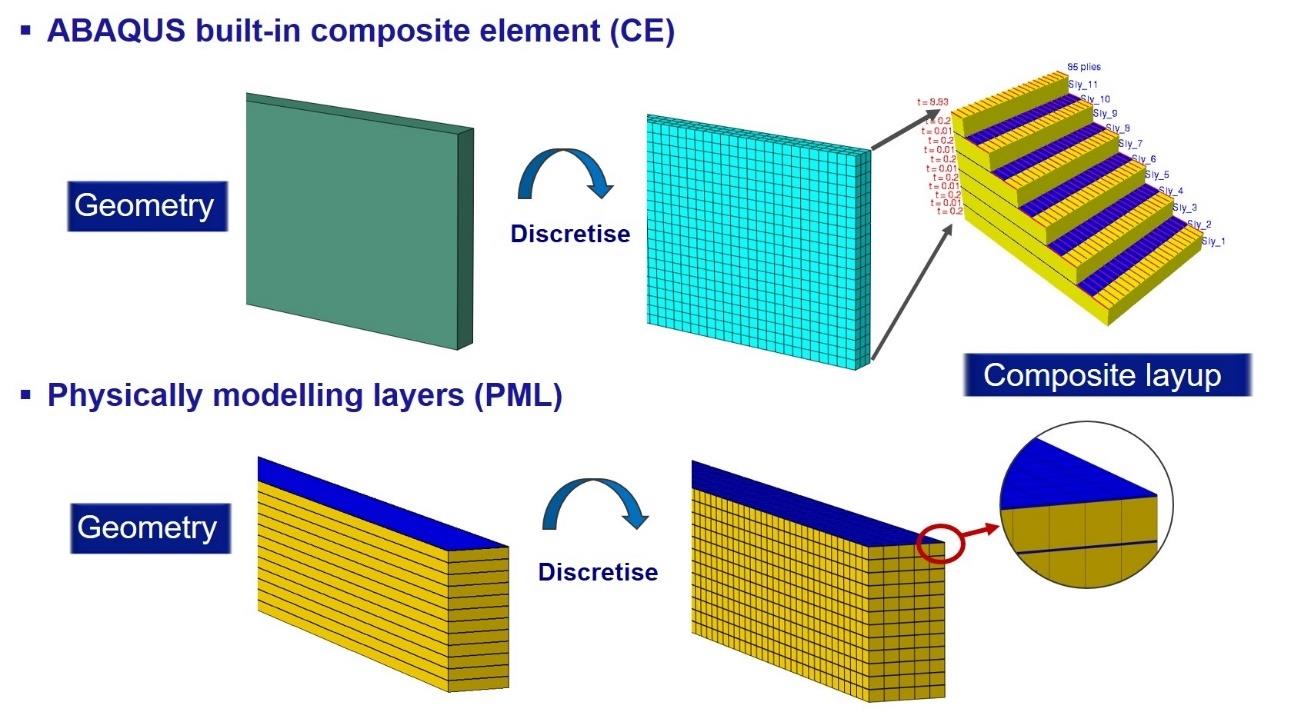
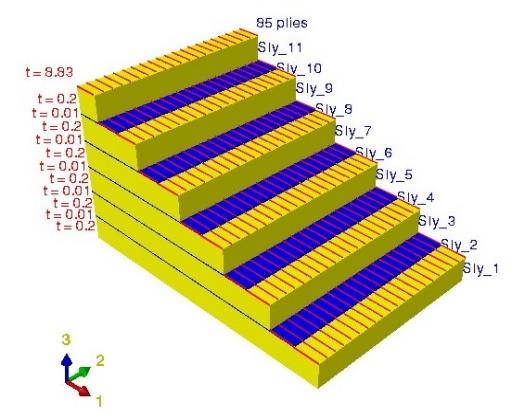
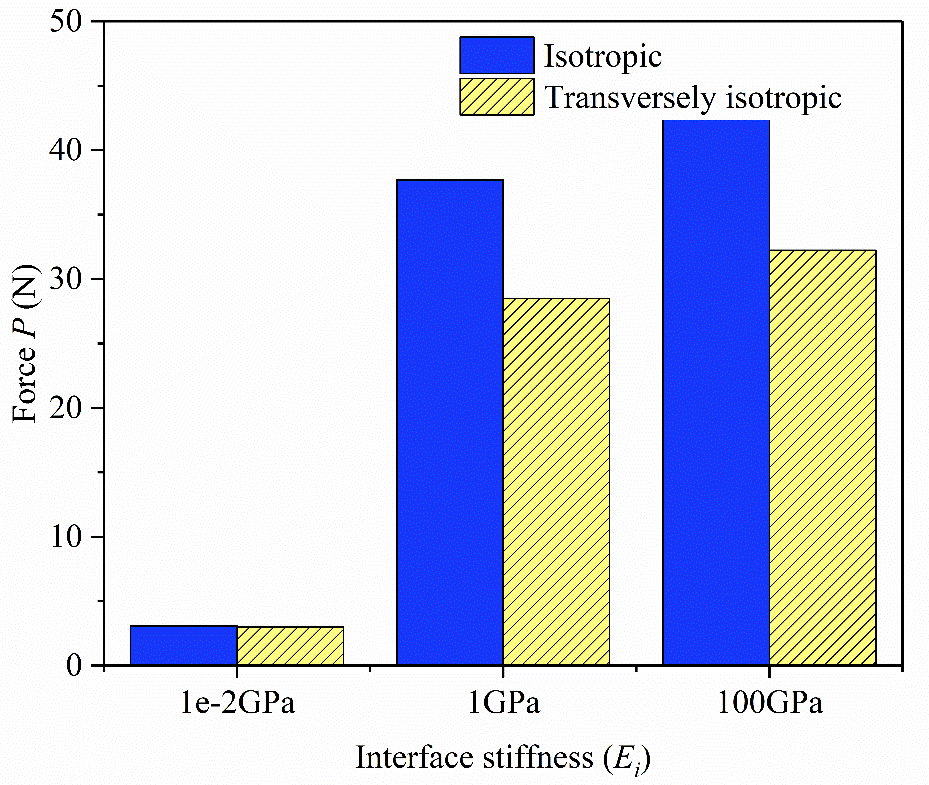
Chapter 4: Buckling analysis of multilayered elastic beams with soft and rigid interfaces As the first step for better comprehending wrinkle formation, the behaviour of multilayered elastic beams under bending and buckling is examined using available analytical and numerical strategies. A numerical model simulating the tests in Dodwell (2015) is described in detail at the beginning of this chapter. To investigate the effect of very soft interfaces and ply anisotropy on the overall beam rigidity using two types of models (i.e. composite layup option (CE) and physically modelling layers (PML)), two case studies are introduced later. By observing the obtained results, a new model based on the hypothesis that the resin stiffness dominates the longitudinal compressive strength is created in the next chapter. A version of this chapter has been published in conference proceedings (see Le, A., Zobeiry, N., Erkmen, E. & Malek, S. 2019, 'Buckling analysis of multilayered beams with soft and rigid interfaces', ICCM22, Engineers Australia, Melbourne, Vic, pp. 204-12).
Chapter 5: Buckling behaviour of laminated viscoelastic composite under axial loads Following the studies conducted in the previous chapter, here the viscoelastic properties of the resin are included in a macro-scale model. The effective properties of the composites obtained from viscoelastic micromechanical models instead of assumed elastic inputs for the resin properties as in Chapter 4 are used in the macro-scale FE model.
A more versatile orthotropic viscoelastic constitutive model based on differential form (DF) of viscoelasticity implemented as a user material subroutine (UMAT) compared to using Abaqus built-in viscoelastic model (IF) is employed. It helps to elucidate the effect of ply anisotropy on the buckling response of uncured/partially cured unidirectional (UD) laminates.
This chapter begins with a description of analytical equations to approximately estimate the critical buckling load of a linear isotropic laminate. Model verification and validation with the experimental data available in Wang, Long & Clifford (2009) are introduced in later subsections. Some important aspects such as viscoelastic behaviour, effect of resin properties on the post buckling response are also investigated. A version of this chapter has been published in a peer-reviewed international journal paper (see Le, V.A., Zobeiry, N., Erkmen, E. & Malek, S. 2021, 'Buckling behaviour of laminated viscoelastic composites under axial loads', Mechanics of Materials, 159, 103897).
Chapter 6: Bending behaviour of viscoelastic woven composite plates Given that out-of-plane bending is well known as an important deformation mechanism that governs the wrinkle formation during composite manifacturing (Margossian, Bel & Hinterhoelzl 2015), this chapter investigates the bending behaviour of viscoelastic composites under conditions similar to forming processes. For a multi- scale modelling framework involving analyses at different scales and implemented in a general purpose finite element code, Abaqus is used. Due to the limitation of Abaqus built-in viscoelastic model to isotropic materials, an orthotropic viscoelastic constitutive employed to consider the influence of ply anisotropy on bending behaviour.
The multi-scale modelling approach that is used in this study was introduced in general in Chapter 3. The detail of the multi-scale framework for a specific problem (i.e. bending behaviour of uncured woven composites) is described in Section 6.2. The details of the FE model and its verification are provided in 6.2. In Section 6.3, numerical results are compared with the experimental data available in the literature (Alshahrani & Hojjati 2017b) for validation purpose. The capabilities and limitations of the developed model are discussed in Section 6.4. Future works and the conclusion are presented in Section 6.5. A version of this chapter has been published in a peer-reviewed international journal paper (see Le, V.A., Nimbalkar, S., Zobeiry, N. & Malek, S. 2022, 'An efficient multi- scale approach for viscoelastic analysis of woven composites under bending', Composite Structures, 292, 115698).
Chapter 7: Bending behaviour of multilayered viscoelastic plates with thin and soft
Interfaces
As reviewed in the previous chapter, bending properties of uncured thin laminates are known to significantly influence the appearance of wrinkles including the shape, magnitude and intensity of wrinkles. Apart from bending stiffness, shear deformation in the form of inter-ply slippage is deemed to be an important deformation mechanism during the process of forming composites, particularly for multilayered textile composites. Therefore, the method developed in Chapter 6 has been expected to expand the investigation into the bending behaviour of multilayered textile composite separated by relatively soft interfaces. Consequently, this chapter is concerned primarily with the concurrent deformation mechanisms during bending behaviour of orthotropic elastic multilayered beams with thin and soft interfaces. A version of this chapter is submitted to ECCM20 Switzerland, 26-30 June 2022: Le, V.A., Nimbalkar, S., Zobeiry, N. & Malek, S. 2022, 'Multi-scale viscoelastic bending analysis of laminated composites with soft interfaces'.
Hapter 8: Conclusions And Recommendations
This chapter summarises the major outcomes of the research. A discussion of the possible issues that may be attributed to the disparity between the predictions using the proposed numerical model and available experimental results is also included.
Recommendations for future research are provided at the end.
Hapter 2. Literature Review
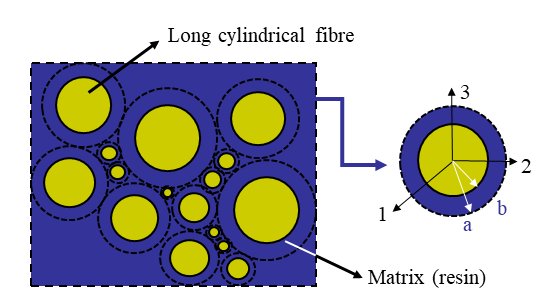
2.1. Micro-mechanical modelling of circular fibre composites Numerous studies on micromechanical models for the elastic study of composite materials have been published. While numerical models can take into account the microstructure's complexity, they frequently consume an increasing amount of computational time than simple closed-form equations. In the current study, the analytical micromechanical approach is adopted because it provides accurate and efficient ways to predict the effective mechanical properties of viscoelastic composites with circular fibre that can later be used within a multi-scale modelling framework like process simulation of composite structures. Well-known micromechanical models have been reviewed in detail in Malek (2014). Only chosen models for calculating specific moduli and modification approach for viscoelastic properties of composite materials during cure used in this study are reviewed in the sections below for completeness.
2.1.1. Analytical micromechanics equations for predicting properties of solid
Unidirectional Composites
The Composite Cylinder Assemblage (CCA) model proposed by Hashin & Rosen (1964) was used to estimate the effective viscoelastic characteristics of unidirectional (UD) cylindrical fibre composites. The approach based on the assumption that the volume of composite material can be occupied by a gathering of cylindrical fibres in a surrounding resin as demonstrated in Fig. 2.1. The volume fraction of fibre, Vf, defined as the ratio of the fibre diameter (b) to the matrix diameter (a), is considered to be the same in the whole system.
(2.1)
Figure 2.1: Composite Cylindrical Assemblage (Malek 2014) The longitudinal Young’s modulus (E1c) and Poisson’s ratio of the UD composite
(2.3)
Note that subscripts f and r refer to fibre and resin. The effective bulk modulus of the composite in plane strain (K23c) is given by (Hashin 1972):
(2.4)
where the fibre and the resin plane strain bulk modulus, K23f and K23r, can be determined
(2.6)
where 𝜈𝑟 and 𝜈𝑓 are the resin and the fibre Poison’s ratios. Similarly, the longitudinal shear modulus is given by:
(2.10)
Using GSC model, Christensen & Lo (1979) proposed the effective transverse shear modulus of UD composites with long fibre by solving the following quadratic
(2.11)
where A, B and C are math functions provided below:
(2.15)
2.1.2. Predicting the viscoelastic properties of composites during cure The accuracy of the above chosen closed-form analytical equations in determining the effective viscoelastic characteristics of UD composites had been verified with numerical reference solutions (Malek 2014) over a variety of fibre volume fractions.
However, for thermoset composites during cure, the resin develops from a lowly viscous fluid to a highly cross-linked viscoelastic solid. Therefore, these equations were adjusted by incorporating the fibre bed effect.
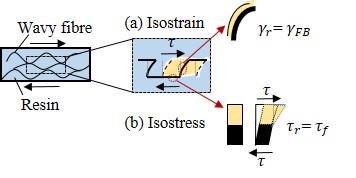
In practice, fibres in long-fibre reinforced composites are not ideally straight. We refer the slight waviness of the fibres in prepregs as shown in Fig. 2.2 as fibre bed. As fibre volume fraction is high (Vf > 0.5), the fibre bed plays a significant part in carrying the load in the transverse fibre orientation (Gutowski et al. 1987). Fig. 2.2ab illustrates the deformation behaviour of a fibre bed impregnated with resin under shear loading (Malek, Thorpe & Poursartip 2011). It is believed that in vertical section (see in Fig. 2.2a) the fibre bed and the resin deform equally (isostrain condition) and in the horizontal section (see in Fig. 2.2b), the resin carries the same stress as the fibre does (isostress).
(C)
Figure 2.2: Fibre bed deforms under shear stress. (a) Fibre bed deforms together with resin. (b) Fibre deforms under the overall shear stress. (c) Analog representation (Malek, Thorpe & Poursartip 2011).
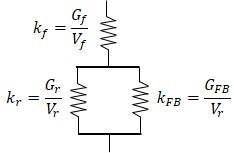
The mechanism of load transfer then can be represented using a simple analog model indicated in Fig. 2.2c. The impact of each element to the overall stiffness of the composite is expressed by k.
According to this representation, the fibre bed stiffness is parallel to the resin stiffness and therefore the wavy fibre bed perturbs the resin shear modulus Gr by GFB. Then the function of any solid micromechanical model MM (Gr, Gf, Vf, …), for example, the prepreg shear modulus could be represented by:
(2.16)
2.2. Meso-mechanical modelling of textile composites The prediction of elastic properties of textile composites has attracted much research attention in the past two decades because the mechanical characteristics of such composites are highly complex due to many parameters as fibre architecture, matrix properties and fibre properties involved (Balokas, Czichon & Rolfes 2018; Qi, Liu & Chen 2019). Various predictive models have been published and categorised into analytical models and numerical models (Dixit & Singh 2013).
Numerical models are more flexibly applied for different geometries and consider more complex mechanical interaction of yarns and matrix since it relies on available computational solvers (Nguyen et al. 2021; Qi, Liu & Chen 2019). Using FE-based numerical models (Qi, Liu & Chen 2019; Tan, Tong & Steven 1997), the general procedure to predict the mechanical properties of a textile composite includes determining properties of a RVE. The selected RVE is sufficient to represent the fabric architecture for a later calculation of entire textile structure’s mechanical properties (Dixit, Mali & Misra 2013; Sun & Vaidya 1996; Udhayaraman & Mulay 2017). With rapid advances being made in computers, the mechanical properties of composites with complex structures have been widely computed using the FE method. Sun et al. (2003) proposed a new method for modelling the effective mechanical properties of three- dimensionally braided composites material via homogenisation theory and incompatible multivariable FEM. Li et al. (2012) described the actual microstructure of 3D five- directional braided composites by using the unit cell model with the FEA method. Tensile behaviour in 0o and 90o directions at the RVE scale of 3D orthogonal woven composites was investigated numerically by Yang, Gao & Ma (2018). The effects of crack damage, yarn/matrix interface and geometric model size of component material (i.e. matrix, warp, weft and z-yarn) were analysed (Yang, Gao & Ma 2018). Based on cross-scale simulation and the homogenisation theory, the mechanical properties of different types of CFRP with the change of angle and different stacking sequences of UD-CFRP were obtained by Qi, Liu & Chen (2019). However, many challenges such as the choice of an appropriate unit cell (Cao et al. 2020) with correct boundary conditions and FE mesh size were involved in modelling a periodic representation of a specific textile composite (Camanho & Hallett 2015).
The need for accurate and less complicated analytical models compared to numerical models in terms of computational effort in predicting mechanical properties of textile composites is increasing (Hallal, Younes & Fardoun 2013). Moreover, there are many parameters involved in calculating the fabric structure such as fabric architecture, the density of yarns in the fabric, properties of warp and weft yarns, characteristics of fibre and matrix etc. Therefore, analytical models are necessary to evaluate the effects of various parameters on the mechanical properties of textile composites. Concerning two major factors such as the geometrical modelling and the homogenisation technique based on isostrain assumptions, isostress assumptions, mixed isostrain/isostress assumptions etc, many different approaches were proposed by researchers.
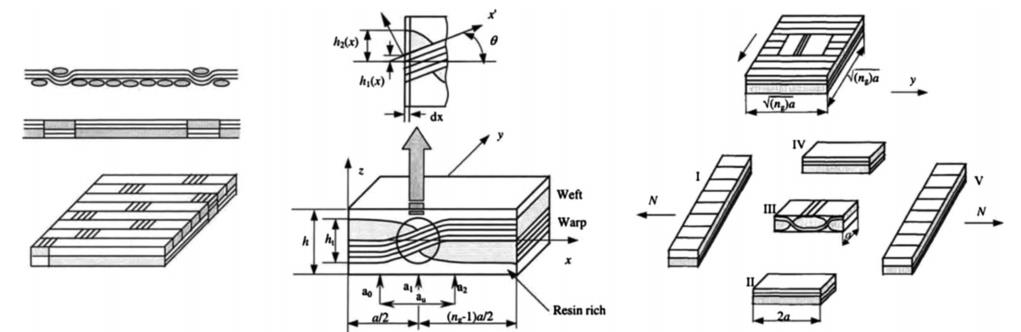
Ishikawa & Chou (1982) conducted the first studies that investigated the stiffness and strength of 2D woven fabric composites. Three analytical models were proposed and developed for approximating the elastic behaviour of woven fabric composites. The first model is referred to as “mosaic model” which is idealised as an assemblage of two one- dimensional models for a formation of a two-dimensional cross-ply laminate as a consequence of neglecting the continuity of fibres in the thread direction (see Fig. 2.3a).
The upper and lower bounds for stiffness in the tow direction are obtained according to constant strain (isostrain) and constant stress (isostress) assumed. Considering the fibre undulation and continuity, the second model introduced as “fibre undulation model” or “crimp model” (see Fig. 2.3b) was found to be effective for modelling the mechanical properties of 2D plain weave fabric composites (Ishikawa & Chou 1982). The length of a tow in the fabric repeating unit is divided into small portions (see Fig. 2.3b). For the undulating section, only considered in yarns along loading direction, a sinusoidal expression defines the undulation of the yarns. Then, they are assembled under isostress assumption using the Classical Laminate Theory (CLT).
The “bridging model” was later developed for the analysis of mechanical properties of satin composites. In this model shown in Fig. 2.3c, an interlaced region (labelled as III) is separated from surrounding straight regions (I, II, IV and V) as the local in-plane stiffness in this place was found to be much lower than that of the straight areas. The four regions of straight fill threads (I, II, IV and V) can be regarded as pieces of 0o/90o cross-ply laminates while the undulating tow in region III is modelled using the crimp model. Assuming that a load, N (see Fig. 2.3c) is applied along the weft threads, regions such as II, III and IV are considered to be parallel models and the remaining cross- ply laminates I and V are in series. Therefore, stiffnesses of regions II, III and IV are averaged using an isostrain assumption and stiffnesses of I and V are averaged based on isostress assumption. Employing laminated models to describe the geometry of the woven fabric composites, Ishikawa & Chou (1982)’s studies are based on classical laminate theory (CLT) and demonstrated the validity of the theory for every infinitesimal piece of the repeating unit of a woven lamina. However, these models only considered loading in the x-direction while the undulation and continuity in the warp threads were ignored.
(C)
Figure 2.3: Schematic of (a) mosaic model; (b) undulation model and (c) bridging
Model Proposed By Ishikawa & Chou (1982)
Naik & Shembekar (1992) extended the existing 1D models of Ishikawa & Chou (1982) and improved a 2D model for plain weave composites. The model accounts for undulation in both along and across the yarns (i.e, warp and weft) (see Fig. 2.4). The presence of a gap between two adjacent yarns, yarn cross-sectional area and lamina thickness was also investigated and demonstrated to have significant effects on the elastic analysis of woven fabric composites. Two methods used to assemble discrete sections are PS (Parallel-Series) scheme and SP (Series-Parallel) scheme. In the SP model, yarn slices along the loading direction are assembled in series using isostress assumptions and yarn portions across the loading direction are assembled in parallel using isostrain conditions.
The PS model is opposite to the SP one and been validated as generating better predictions of in-plane elastic properties. In later work, Naik (1994) developed an analytical technique for determining overall stiffness of woven composites along with braided textile composites (i.e. 2D braided and 2D triaxial braided composites). Having described the RUC geometry for a specific textile composite, the three-dimensional (3D) effective stiffness for the composite was calculated following two steps. Firstly, each yarn in the RUC was discretised into yarn slices. Secondly, based on an isostrain assumption within the RUC, the 3D effective properties of the composite were obtained by utilising the material characteristics, spatial direction and volume fraction of each yarn slice. The predicted mechanical properties agreed well with numerical solutions and experimental data for both the satin weave and braided composites. Subsequent research by Naik considered the effect of twisted yarns on the strength of plain weave fabric (Naik & Kuchibhotla 2002), leading to an analytical method for determining through-thickness moduli of 3D orthogonal interlock woven composites (Naik et al. 2001; Naik & Sridevi 2002).
Yarns
Figure 2.4: Unit cell of plain weave composite improved by Naik & Shembekar (1992) Sankar & Marrey (1997) proposed an analytical procedure known as the selective averaging method (SAM) for the estimating the thermoelastic properties of textile composite materials. The unit cell is divided into slices of a thickness (meso-scale) which are further subdivided into elements (mico-scale). Both stiffness and compliance coefficients can be averaged selectively based on either isostress or isostrain assumptions.
(Tan, Tong & Steven 1999, 2000; Tan et al. 2000) also devised two analytical models to determine the mechanical properties and the thermal expansion coefficients of 3D orthogonal and through-the-thickness angle interlock woven composites. Having discretised the RVE into micro-blocks, they are further assembled for simple strips using the “X model”, “Y model” or “Z model” as shown in Fig. 2.5. The micro-blocks can be warp/weft impregnated with resin or tow blocks whose mechanical properties and coefficients of thermal expansions are known. Depending on loading directions and the relative position of assembled blocks, isostrain and isostress assumptions are applied.
(C)
Figure 2.5: Schematic of (a) “X model”; (b) “Y model” and (c) “Z model” developed
By Tan, Tong & Steven (1999)
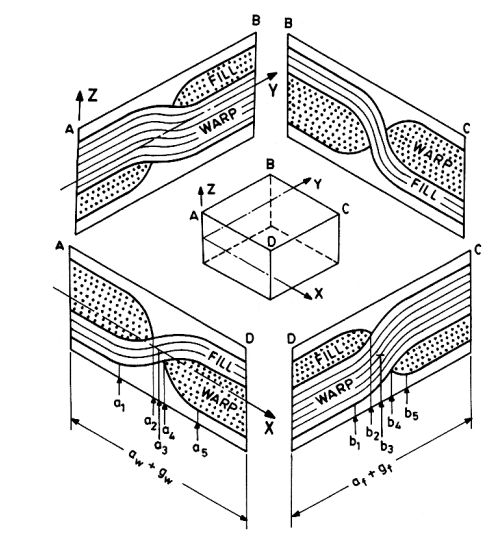
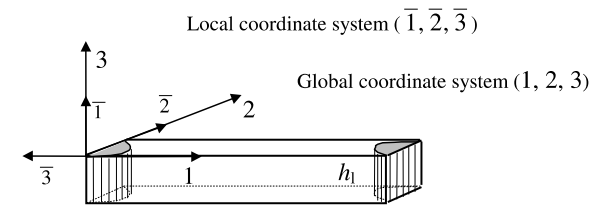
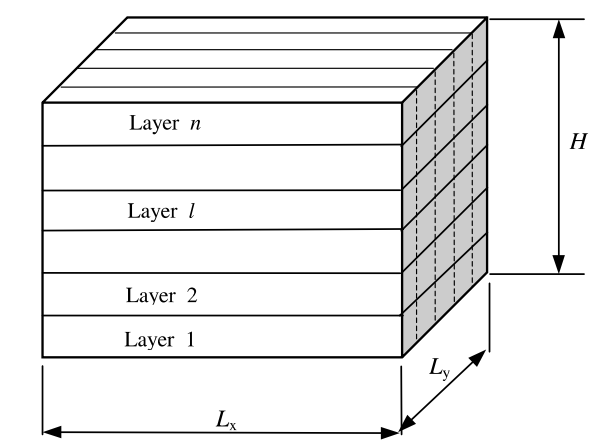
Wu, Brown & Davies (2002) and Wu (2009) introduced an analytical model for determining the stiffnesses of 3D orthotropic laminated fabric composites. The proposed technique includes discretising the representative unit cell into slices (layers) which are later decomposed into stripes (elements) (see Fig. 2.6). In the scenario of either isostress or isostrain following the applying stress, the components of the stiffness matrix of the slices are obtained based on those of the elements. The stiffness of the RUC is subsequently formulated by combining these slices. Although the approach has been shown to be simple and computationally efficient, it overestimates all Young’s moduli compared to the experimental values.
Hallal et al. (2012) developed an analytical model labelled as 3SHM for calculating the effective elastic properties of 2.5D interlock woven fabrics composite. The 3SHM is the abbreviation for 3 Stage Homogenisation Method at mico-, meso- and macro-scales. At micro-scale, each yarn is decomposed into sub-volumes with known volumes and these stiffness matrices are calculated using a micromechanics model in the literature. At meso-homogenisation stage, the stiffness matrices of yarns are later determined by assembling sub-volumes using mixed isostrain and isostress assumptions (see Fig. 2.7). Finally, at the macro-scale, the stiffness of the REV is obtained by combining homogenised yarns and matrix stiffness matrices under isostrain conditions (see Fig. It is noted that the proposed method accounts for the real geometry of undulated yarns, resulting in flexibility in modelling textile composites with different geometries.
Recently, Zhou et al. (2022) proposed an analytical model based on the energy principles for calculating the uniaxial tensile modulus of plain woven fabric (PWF) composites. By observing computed tomography, the lenticular shape was selected to describe the cross-section of the plain woven composites’ fibre tows and the undulation path was assumed to be composed of equal radius arcs for both the warp and weft yarns.
The yarn segments are subjected to uniaxial tension load along with the simplified interaction force between yarns. The analytical equations for the uniaxial tensile modulus of the plain woven fabric are subsequently withdrawn. Such a model results in a small deviation compared to experimental data and high calculation efficiency. However, Zhou’s model relies heavily on the input parameters from costly experiments and the cross-section of fibre tows and the interaction between the warp and weft tows are simplified for a specific woven fabric. Therefore, the application of the proposed analytical model for another type of textile composite with different geometric and mechanical properties (i.e. fibre and matrix) should be further investigated.
(C)
Figure 2.6: Schematic of (a) the representative unit cell in a 3D orthotropic laminated composite; (b) the discretised stripes of layer l; (c) global and local coordinate systems for stripe 1 (Wu, Brown & Davies 2002).
Figure 2.7: Schematic of 3 Stage Homogenisation Method (3SHM) developed by
Hallal Et Al. (2012)
al. 2014; Wehrkamp-Richter, De Carvalho & Pinho 2018) focuses on FE simulation for accurately predicting the meso-scale mechanical properties of textile composites. However, the current research aims to develop an efficient strategy for multi-scale analysis of wrinkling during the composite consolidation process. Then, an analytical model for determining the effective mechanical properties of woven composite at the meso-scale would be preferred. It has been demonstrated that the analytical model developed by (Naik 1994) for overall stiffness of 5-harness satin weave composite gave good correlation with experimental results, while maintaining flexibility and being easy to apply with less time consumption in comparison with corresponding numerical FE models. Therefore, analytical technique of Naik (1994) would be applied for predicting the mechanical properties of a fabric unit cell via the homogenisation technique as input constants of the structural analysis.
2.3. Buckling behaviour of laminated viscoelastic composites The composite structures employed in the aerospace industry are commonly composed of multiple thin layers (plies) (Hallander, Sjölander & Åkermo 2015).
Buckling of composite elements is one of the characteristic failure modes in such structures (Boisse et al. 2018; Hallander, Sjölander & Åkermo 2015; Leissa 1987). Buckling or ply wrinkling is more likely to lead to a sudden and dramatic failure of a component or the whole structure in service (Hallander, Sjölander & Åkermo 2015). As a result, special attention must be given to the design of laminated composite parts so that they can safely support their intended loadings without buckling.
In the literature, much attention has been paid on mechanisms behind wrinkle formation during consolidation onto curved tools. Lightfoot, Wisnom & Potter (2013) proposed a mechanism for the formation of wrinkles due to frictional shear stresses. At very early stages in the cure cycle when the resin is soft, plies can move relative to other plies and the tool surface. The mismatch between the coefficients of thermal expansion (CTE) of the tool surface and the curing composite, combined with a small amount of ply slippage results in shear forces. These shear forces are known to be the primary cause of wrinkle formation. Following a development of a one-dimensional analytical model comprising of uniformly thick layers laid over an external corner radius under the consolidation onto a tighter geometry, Dodwell, Butler & Hunt (2014) assumed that those layers may form wrinkles if they are prevented from slipping over one another. Wrinkling of a ply or buckling occurs when the ply is subjected to compressive stresses in the direction of its fibres generally (Hallander et al. 2013). According to Hallander et al.
(2013), although a tensile force may be applied globally, local compressive forces could still be developed in some recess areas, leading to out-of-plane defects during the forming process of quasi-isotropic, multilayer unidirectional (UD) prepreg over a double-curved geometry. Sjölander, Hallander & Åkermo (2016) simulated two different causes for wrinkle development during forming of multi-layer UD prepregs onto a 3D beam geometry to clarify the experimental findings in Hallander, Sjölander & Åkermo (2015).
They are global buckling of the entire tack of material due to excessive material and local compression of single layers. While wrinkles are commonly found in curved composite parts as the localised band of wavy fibres, buckling behaviour of flat laminated composites at the early stage of forming has also attracted the interest of researchers. Wang, Long & Clifford (2009) investigated the out-of-plane bending behaviour of a 3-ply flat UD laminate using large- displacement buckling tests. A bending model combining classical elastic laminate beam theory and uniaxial continuum theory was also developed for further understanding.
Although the shape of buckling curves captured from the experimental data and the prediction models agreed reasonably well, there is a mismatch at the transition region from pure elastic to pure plastic (Wang, Long & Clifford 2009). This inconsistency makes simulating the buckling behaviour challenging using a unified model. The predictive model of elastic buckling is actually set to fit experimental data while the practical bending rigidity of the prepreg is still unknown. Dodwell (2015) applied successfully a general 2D Cosserat model in modelling defect formation of thickly layered beams consisting of stiff layers separated by weak interfaces. This Cosserat continuum model showed the potential of capturing the internal buckling instabilities of laminated composites at the beginning of cure when the resin is very soft. However, the study focused only on the elasto-plastic behaviour instead of the true viscoelastic nature of polymer composites. In short, the predictive models of wrinkle formation during the composite manufacturing while considering the true viscoelastic nature of composites are still in high demand and of interest to composite manufacturers Currently, manufacturing composite parts with mitigation of defects relies heavily on the designers’ experience and trial-and-error practices (Belnoue et al. 2018; Hallander et al. 2013; Weber et al. 2019). Experiments (Belnoue et al. 2018) are costly because a large number of process, material and geometric parameters are involved in composite manufacturing. For example, when studying the micro-level mechanisms for wrinkle formation during hot drape forming of a C-shaped part, Farnand et al. (2017) showed that forming temperature, consolidation pressure and forming rate were important contributors to the fibre misalignment, leading to out-of-plane wrinkling. Moreover, the wrinkling behaviour has been reported to be influenced by the friction between the two sliding prepreg surfaces of noncured composite prepreg materials from a meso-level perspective. Therefore, many efforts have been made at different resolution levels to characterize inter-ply friction as a function of various parameters including volume fracture of fibres, fibre stiffness and the type of toughener (Larberg & Åkermo 2011). In a later experimental study, Larberg & Åkermo (2014) showed that stacking sequences could influence the deformation behaviour of multi-layered unidirectional thermoset prepreg during the sheet forming process significantly. Similarly, Johnson et al. (2019) also agreed that stacking sequence could potentially be the cause of defect generation and then suggested the most compatible stack arrangement together with application rates and favourable temperatures to minimise defect forming during automated production processes.
In previous works related to the wrinkling of viscoelastic composites, less attention has been given to the viscoelastic nature of the plies and the relaxation of the generated residual stresses during composites curing. Due to many parameters required for specific testing processes, predictive modelling to improve the understanding of design engineers about the wrinkling phenomena has become of paramount importance in the past two decades (Boisse, Hamila & Madeo 2016). Various process models have been developed by researchers to accelerate the insertion of different composites by simulating the behaviour of composite parts during their manufacturing process (Amini Niaki et al. 2019; Niaki et al. 2018). However, only a few of these models are able to capture the development of wrinkles accurately. The simplified model of Dodwell, Butler & Hunt (2014) was employed to determine parametric influences such as bending stiffness of single uncured ply, part thickness and tool radius on wrinkle wavelength and critical limb length during the forming process. Only the elastic buckling mechanisms coupled with geometric consolidation were considered and therefore the viscoelastic nature of the polymer composite and its effect, especially at the early stage of cure, were not well-investigated. Only recently, Alshahrani & Hojjati (2017c) proposed a theoretical model for predicting the bending behaviour of woven fabric under conditions relevant to forming process. Besides, a new bending test that provides sufficient control of loading rates and processing temperatures, as well as viscoelastic considerations, was also established for prediction of the parameters and validation of the proposed model (Alshahrani & Hojjati 2017b). However, their predictive model which is based on the principle of time-temperature superposition still overestimated the measured bending moment. Also, the test method was almost impossible in high temperature conditions (over 120oC) due to dependence on a non-contact heater facility.
To reduce the number of manufacturing trials, predictive finite element (FE) models for simulating wrinkle formation and its effect have been developed by several researchers. Linear buckling analysis of laminated plates under combined biaxial and shear loading was conducted numerically by Nali, Carrera & Lecca (2011). Two- dimensional plate modelling was considered and materials were assumed isotropic, orthotropic and anisotropic, alternately. Various plate finite element models were analysed to identify the most appropriate model for each class of buckling problem.
However, the study focused on only cured (solid) laminates. On the contrary, the predictive numerical models of Belnoue et al. (2018) have proven the potential to capture effectively the wrinkle formation during consolidation. Nevertheless, specific attention is given to thick L- and C-sections and influences of different boundary conditions. Some other numerical studies on the influence of wrinkles on compressive strength were performed by simulating embedded fibre wrinkle defects before proceeding numerical analyses of structural performance (Lemanski & Sutcliffe 2012; Mukhopadhyay, Jones & Hallett 2015; Xie et al. 2018). At present, FE models that can predict wrinkle formation effectively during the composite manufacturing while considering the true viscoelastic nature of composites are still in high demand and of interest to composite manufacturers.
2.4. Bending behaviour of woven composites during forming processes Advanced composite materials have increasing use in structural applications for aerospace, automotive, and marine industries thanks to their exceptional properties like higher specific stiffness and strength, as well as ability for net shape manufacturing (Farnand et al. 2017). Woven-reinforced composites are preferred due to their improved ability to produce complex shapes (Naik 1994). However, formation of process-induced defects such as wrinkles poses obstacles to fully exploiting the potential of advanced composites (Hallander, Sjölander & Åkermo 2015). Typically, aerospace industry process specifications limit the degree of defects for certification purposes. For instance, when it comes to wrinkles, the length and out-of-plane height of the wrinkles are kept within well-defined limits to minimise their influence on the mechanical performance of the end-part. Wrinkle development is facilitated during the forming process of complex composite components such as stringers by out-of-plane bending as well as in-plane shear deformations (Long 2005; Margossian, Bel & Hinterhoelzl 2015). As such, accurate prediction of in-plane and out-of-plane characteristics of an uncured laminate, as well as inter-ply slippage (Alshahrani & Hojjati 2017a) during the composite forming is highly desirable to optimize the forming process of composites and mitigate wrinkle formation.
Although several studies on the bending properties of cured prepreg materials have been published, efficient numerical modelling of large viscoelastic composites remains a significant challenge in the composite manufacturing industry. Given that the high- fidelity simulation of viscoelastic behaviour of large composite parts during forming process takes significant set-up and computational time, industry often relies on trial-and- error experimental methods instead of simulation. This highlights the need for developing efficient simulation methods. This study focuses on predicting the bending behaviour of woven composites using an efficient multi-scale modelling approach as a first step towards developing a fast and comprehensive multi-scale framework for viscoelastic analysis of woven composites during cure.
2.4.1. Bending properties of uncured thin laminates Bending properties of uncured thin laminates are known to significantly affect the occurrence of wrinkles, particularly in determining the shape of wrinkles (Alshahrani & Hojjati 2017a; Belnoue et al. 2018; Boisse et al. 2018; Huang et al. 2020; Liang et al.
2014). For example, increasing the bending rigidity of the laminate leads to an increase in the size of the wrinkles (Boisse et al. 2011). Numerous experimental studies (Alshahrani & Hojjati 2017b; Bilbao et al. 2009; Liang et al. 2014; Martin, Bhattacharyya & Collins 1995; Wang, Long & Clifford 2009) have been conducted in the recent decade to characterise the out-of-plane bending behaviour of prepregs. To eliminate time- consuming and costly measurement trials, various researchers have developed numerical models for the composite forming process. Forming simulations for composite fabrics were carried out under the membrane hypothesis (Larberg & Åkermo 2014; Skordos, Monroy Aceves & Sutcliffe 2007), i.e., neglecting the bending stiffness. For example, Larberg & Åkermo (2014) developed a methodology for modelling the in-plane deformations of unidirectional (UD) prepregs. Both in-plane shear and inter-ply friction were considered in the forming model of stacked thermoset UD prepregs in Larberg & Åkermo (2014). Subsequently, it was shown that bending stiffness has a substantial influence in determining the magnitude and intensity of wrinkles (Boisse et al. 2018).
Other studies (Alshahrani & Hojjati 2017a, 2017c; Haanappel & Akkerman 2014) suggested that the final desired shapes after forming of composite prepregs are determined by the complex interaction of intra-ply shear (including longitudinal and transverse intra-ply shearing), inter-ply slippage and out-of-plane bending. Numerous efforts have been made to incorporate such diverse deformation mechanisms into the composite forming model to accurately predict wrinkle evolution during the forming process. To capture such complex mechanisms, some researchers (Alshahrani 2020; Alshahrani & Hojjati 2017a; Hallander et al. 2013) have employed Aniform Finite Element (FE) software with shell elements to model the viscoelastic bending behaviour of composite plies under conditions relevant to the forming process. It is worth noting that the Aniform shell is a combination of a membrane element (LTR3D) and a Discrete Kirchhoff Triangle (DKT) element, which potentially can capture both in- and out-of- plane properties. However, time-consuming characterisation tests are required to determine the material parameters for a suitable constitutive model. For instance, the bias extension test was conducted and simulated in Aniform in order to obtain the fitted parameters for the membrane elements (Alshahrani & Hojjati 2017a; Farnand et al. 2017).
Furthermore, despite the fact that a plate or shell theory can provide kinematics for points in the thickness, kinematics in the thickness of textile reinforcements is very specific, especially for thick textile reinforcements, due to relative slippage (Boisse et al. 2018).
Accuracy of 3D predictive tools highly depends on the input properties. For a reliable forming simulation, the properties of the uncured material must be accurately represented in the finite element models. As a result, significant research has concentrated on characterizing three types of rigidity that can be used as inputs to wrinkling simulations: tensile, in-plane shear, and bending (Alshahrani 2020; Boisse et al. 2011; Haanappel et al. 2014; Long 2005). For this purpose, mechanical tests such as biaxial tests for tensile stiffness, picture-frame and bias-extension tests for in-plane shear stiffness and bending tests have been performed. The bias-extension test, which is a substitute for the picture-frame test, is intended to introduce pure shear into the material.
As the in-plane shear behaviour is considered to be the most dominant deformation mechanism during forming process, finite element models have been developed using material models calibrated with bias-extension tests for in-plane shear stiffness (Alshahrani 2020; Alshahrani & Hojjati 2017a; Haanappel et al. 2014; Larberg & Åkermo 2014; Sjölander, Hallander & Åkermo 2016). Thereafter, the calibrated fibre stiffness values of uncured composites are retrieved from the measured shear data and used as inputs to the corresponding FE simulations of the bias extension tests. These fitted values for bias-extension simulations on specific composite prepregs available in the literature are summarized in Table 2.1. While Larberg & Åkermo (2014) conducted bias-extension tests on cross-plied UD thermoset prepregs (T700/M21 and HTS/977-2), Haanappel et al.
(2014) applied bias-extension experiments for a woven glass fibre reinforcement (8HS/PPS). Bias-extension testing on multi-layer stack UD prepreg materials containing either HT (High Tenacity) fibre or IM (Intermediate Modulus) fibre and same matrix was considered by Sjölander, Hallander & Åkermo (2016). In recent studies conducted by (Alshahrani 2020; Alshahrani & Hojjati 2017a), using such a bias-extension test, the in- plane shear properties of 5HS satin weave impregnated with Cycom 5320 at forming conditions were characterized over a range of processing temperatures. The bias- extension response and simulation fit lead to a prediction of fibre stiffness as shown in Table 2.1. However, it should be noted that the value of the fibre stiffness was reduced compared to the real value reported in the data sheets to obtain a more stable simulation without a comprehensive investigation (Alshahrani 2020; Larberg & Åkermo 2014; Sjölander, Hallander & Åkermo 2016).
Bending tests have been widely used in the literature to assess ply bending stiffness for out-of-plane behaviour. Unlike cured composites, uncured prepregs may simultaneously promote mechanisms such as intra-ply slippages between fibres and local micro-buckling of fibres during bending since the resin is not stiff enough to prevent their occurrence (Belnoue et al. 2018; Boisse et al. 2018). The combined deformations result in the composite prepregs having an apparent lower bending rigidity than conventional solid materials. Therefore, the bending properties have been investigated experimentally and characterized separately from the in-plane properties (tensile and compressive moduli) by (Alshahrani & Hojjati 2017a; Sjölander, Hallander & Åkermo 2016).
(Alshahrani & Hojjati 2017a; Sjölander, Hallander & Åkermo 2016) carried out cantilever bending tests and later calibrated the bending properties of a single ply using replication of the bending simulations. While Sjölander, Hallander & Åkermo (2016) used an orthotropic elastic model to simulate the bending stiffness in the fibre direction and transverse to the fibre direction, Alshahrani & Hojjati (2017a) employed an isotropic viscoelastic material model for the out-of-plane bending elements. Table 2.1 lists the input parameters for the out-of-plane material properties based on the cantilever bending experiments. Similarly, Belnoue et al. (2018) adapted the cantilever test proposed by Liang et al. (2014) for capturing bending behaviour of a thermoplastic based prepreg at different temperatures. By measuring the bending stiffness in the fibre direction of an uncured prepreg ply (IMA-M21), material characteristic (i.e. Young’s modulus along the fibre direction) was derived from the beam theory (see Table 2.1) and used as an input for the FE consolidation model. Dörr et al. (2017), on the other hand, used a dynamic rheometer within a thermal chamber, rather than the more typically used static cantilever, to characterize the bending properties of a single ply of unidirectional (UD) reinforced PA6-CF tape. A constant parameter was used for the spring element in the viscoelastic material model to fit the bending characterization curve.
As discussed previously, the bending properties of an uncured prepreg were modelled separately from its in-plane properties using specific material models for the fibre and matrix (Alshahrani 2017; Sjölander, Hallander & Åkermo 2016). However, to relate bending stiffness to axial moduli (i.e. compressive and tensile modulus) using a hybrid model. Contrary to traditional isotropic materials, it is hypothesised that fibrous materials can exhibit significantly varied responses in tension and compression (Dangora, Mitchell & Sherwood 2015). While fibre is extremely strong and stiff under tension, it will buckle with extremely modest compressive stresses. As a result, the bending stiffness of fibrous materials cannot be obtained directly from the tensile modulus; it must be measured through experiments (Dangora et al. 2016). For instance, the vertical cantilever method was used to analyse the bending behaviour of a cross-ply thermoplastic lamina, Dyneema HB80 (Ultra-High Molecular Weight Polyethylene fibres embedded in a polyurethane matrix (DSM 2014), at elevated temperature (up to 120oC). A tensile test was also conducted to measure the apparent elastic modulus of such thermoplastic composites as a function of temperature. Subsequently, the obtained tensile modulus and bending stiffness were used to calculate an effective compressive modulus following an equation proposed by Dangora, Mitchell & Sherwood (2015) for implementation into the finite element model. Similarly, Yu et al. (2005) introduced an asymmetric axial modulus to calculate bending rigidity from the in-plane stiffness (i.e. tensile and compressive rigidities). The asymmetric axial modulus, defined as the ratio of compressive modulus to tensile modulus, was determined by conducting a cantilever deflection test in the warp and weft directions and then implemented into the FE software through a user material subroutine (Abaqus UMAT) for simulation of three-dimensional bending deformation.
Alshahrani & Hojjati (2017c) derived an expression for the equivalent bending stiffness as a function of compressive, tensile and relaxation modulus. The compressive modulus of prepreg was calculated by the slope of the stress-strain curve of an elastic region in a buckling test, while the tensile modulus was provided by the supplier. A generalised Maxwell model was applied to fit the stress-relaxation response measured from the cantilever bending test, and parameters for the relaxation modulus were consequently obtained. The computed in-plane properties of the prepreg samples used as input parameters for FE bending models are listed in Table 2.1.
Considering experimental studies on uncured composites, it is apparent that accurate prediction of the mechanical properties of composites under bending is quite challenging. According to the extensive literature review conducted in this chapter, it was found that regardless of the fibre type (i.e. carbon or glass fibre), fabric architecture (i.e.
UD or woven fabrics) or impregnated resin, a low value of around 1 GPa, downscaled from a real value for the fibre stiffness (e.g., 200 GPa for carbon fibre), is commonly used in most numerical models (Alshahrani 2020; Alshahrani & Hojjati 2017a; Haanappel et al. 2014; Larberg & Åkermo 2014). However, this low value has not been justified clearly in the literature (Sjölander, Hallander & Åkermo 2016). Moreover, bending properties at elevated temperatures were estimated based on an educated guess (Haanappel et al. 2014).
Hence, a better understanding of the mechanical properties of uncured composites under bending is crucial for successful forming simulations. This is accomplished using a multi- scale modelling framework that incorporates analyses at different scales and is accomplished in a general-purpose finite element code, Abaqus. Due to the limitation of Abaqus built-in viscoelastic model to isotropic materials, an orthotropic viscoelastic constitutive model implemented as a UMAT (Malek 2014; Zobeiry et al. 2016) is considered. Using this material model, the influence of ply anisotropy on the bending behaviour is investigated.
Table 2.1: List of experimental studies on deformation of uncured composites and calibrated material properties for the corresponding FE simulations.
Oc
Note: a Bending stiffness in the fibre direction used in the orthotropic elastic model for out-of- plane properties. b Isotropic Hooke modulus represents an elastic spring in the viscoelastic material model for the out-of-plane bending elements.
c Young’s modulus of the prepreg sheet in the fibre direction against temperature. d Tensile modulus of Dyneema HB80 in the fibre direction against temperature.
F Compressive Modulus Of The Prepreg Samples
g Unrelaxed modulus of the prepreg samples under bending at forming conditions
Hapter 3. Research Methodology
In the present research, the multi-scale method originally developed by Malek (2014) implemented which is here for determining the wrinkling during consolidation of thermoset composites. The proposed multi-scale approach ensures high efficiency when analysing the behaviour of large composite structures in practice or in applications where time-dependent (viscoelastic) response (i.e. in process modelling) is of interest. Accuracy requirement was also examined for new composites with directional dependent (orthotropic) properties (Malek 2014).
The approach consists of two key resolution scales, known as micro-scale and macro-scale (see Fig. 3.1). Note that the macro-scale is the scale at which the structural response is of interest. At lower scales such as the micro and meso levels, the effective viscoelastic properties of a unidirectional RVE or RUC of the woven fabric reinforced composites are determined using analytical models developed by Malek (2014) and Naik (1994). The obtained effective mechanical characteristics at small-scale contexts are subsequently used as inputs for structural analysis at the macro-scale. The following sections describe the methodology in detail.
In Malek (2014), the author focused on developing analytical micromechanics equations for predicting accurately the effective viscoelastic properties of the solid unidirectional (UD) circular fibre composites. In this thesis, the accuracy of these equations in determining the effective properties of uncured/cured UD composites with given inputs for component properties (i.e. fibre and resin) under a certain loading condition (i.e compression) is examined. The obtained predictions are compared with with data measured available in the literature. A meso-scale considering the weaving pattern has been included into the multi-scale modelling approach to estimate the effective properties of fabric. Unlike previous studies, the viscoelastic contribution of resin as well as fibre stiffnesses under different loading conditions and fabric architecture (for woven composites) are taken into account. The obtained effective properties have been validated wherever experimental tests are available in the literature. At the macro- scale, the wrinkling analyses (i.e. buckling and bending) during the early stage of cure have been verified and validated with analytical and experimental results using the obtained effective mechanical characteristics at small-scale provided as inputs.
Figure 3.1: Schematic of the multi-scale modelling framework for viscoelastic modelling of orthotropic composites (Adopted from Malek (2014))
Icro- And Meso-Scale Model
The effective viscoelastic characteristics of orthotropic composites are first modelled in the multi-scale analysis of viscoelastic composites. At the micro-scale, the analytical micromechanics equations described in Malek (2014) serve to to predict the effective elastic and viscoelastic properties of the solid unidirectional (UD) composites with a specific fibre volume fraction (Vf) (see Fig. 2.1). The effective properties obtained from the micromechanics model are then used to estimate the effective properties of the fabric at the meso-scale. The fabric is composed of two sets of interlacing, mutually orthogonal (warp and weft) yarns. The chosen weave type in this study is a 5-harness satin (5HS) (see Fig. 1.4c), which has advantages over plain and twill weaves in terms of drapability and conformity over complex shapes (Alshahrani & Hojjati 2017b). Based on the pattern in the woven fabric, a small RUC which is adequate to represent the fabric architecture is isolated. Details of geometric modelling of 2-D 5-harness satin weave composite along with discretisation technique of yarns within RUC and calculation of 3D effective stiffnesses are presented here, which is based on the work reported in Naik (1994). The analytical procedure was implemented in MATLAB. The obtained effective mechanical characteristics at small-scale contexts are subsequently used as inputs for structural analysis at the macro-scale.
3.1.1. Micro-mechanical modelling of UD composites As reviewed in Chapter 2, CCA (Hashin & Rosen 1964) and GSC (Christensen & Lo 1979) models are employed at the micro-scale to calculate the longitudinal and transverse elastic properties respectively of the UD composites. Note that the method has already been evaluated and compared with the numerical approach in Malek (2014). In this thesis, the accuracy of these equations in determining the effective properties of UD composites with given parameter inputs for component properties (i.e. fibre and resin) is examined by comparing the obtained predictions with data measured available in the literature. Moreover, such micromechanics models are used as a tool to obtain the mechanical properties of UD composites that would be input parameters for the structural analysis at the macro-scale.
Micromechanical models are used to combine the elastic mechanical properties of the fibre and the unrelaxed and relaxed properties of the polymer. Due to the viscoelastic characteristic of the resin, the combined composite also exhibits viscoelastic behaviour. The viscoelastic properties would be obtained by simply assuming the viscoelastic behaviour of the resulting composite as similar to the viscoelastic behaviour of the resin constituent. It means that the relaxation time and weight factors describing the viscoelastic response of the resin and the corresponding composite are assumed to be the same.
3.1.2. Analytical procedure for predicting elastic engineering constants of woven
Composites At The Meso-Scale
At the meso-scale, an easy but accurate geometric modelling and analysis procedure for 5HS satin weave composite developed by Naik (1994) is employed. Firstly, a three dimensional preform architecture of such a fabric reinforcement composite has to be described properly. Based on the pattern of the woven composite, a RUC is represented for the preform architecture. Detail of the geometric modelling technique of 5HS satin weave is demonstrated in section 3.1.2.1. Later, the 3D effective stiffnesses for the woven composite are determined in section 3.1.2.2. This is done by dividing each yarn in the RUC into discrete yarn slices with specific material characteristics, spatial direction and volume fraction of each yarn slice obtained from the previous step.
Geometric Modelling Of 5Hs Satin Weave
In the first step, the effective properties obtained from the micromechanics model for UD prepregs or yarns at the micro-scale are used to estimate the effective properties of the fabric at the meso-scale. The RUC for the 2-D, 5-harness satin (5HS) weave is presented in Fig. 3.2a. The sectional view (section A-A) illustrates the undulations of a warp yarn over one and under four weft yarns.
The 5HS satin weave composite is commonly described by quantities including yarn spacing, a, yarn filament count, n, yarn packing density, pd, filament diameter, df and overall fibre volume fraction, Vf . The projected length, Lp was a equation of the yarn spacing, a, and defined by Lp = 5 × a (see Fig. 3.2a). The volume filled with the ten yarns within the RUC was calculated by 10 × A × Lp in which A was the yarn cross-sectional area. By assuming that A was constant along the yarn length and same for both the warp and the weft yarns, the volume of the RUC was Lp × Lp × H, where H stood for the RUC thickness. Provided with such known quantities, unknown quantities such as yarn thickness, t, yarn cross-sectional area, A, can be calculated using equations written as
(3.2)
The yarn thickness, t, was determined from the RUC thickness, H, by t = H/2. By assuming there was no gap between adjacent, the yarn width, w, was then computed by w = a.
The undulations were centred at cross-over points (COP) where a yarn crosses over or under another yarn (see Fig. 3.2a). For the 5-harness satin weave, by looking at Fig. 3.2a from the bottom, the warp yarns in the first and fourth rows had three COPs while the warp yarns in the second, third and fifth rows had two COPs. In every undulating part, it was assumed that the yarn centreline path followed a sinusoidal expression. The sine function had its origin at the COP and was formulated using the vertical shift, Vs, and the undulating length, Lu. For instance, the undulation, Zc, at each
(3.3)
where Xc was a distance from the corresponding COP in the warp yarn direction (see Fig. 3.2a). The vertical shift, Vs in Eq. (3.3) was equal to the thickness, t, of the yarns. A negative sign in Eq. (3.3) was used to define the undulation at the central COP for the warp yarn shown in section A-A (see Fig. Conversely, at the COPs located on the RUC edges for the same warp yarn, a positive sign was used in Eq. (3.3). Similarly, the undulation path for the other warp yarn in the RUC was defined with the relevant sign and sine wave portion at each COP. The undulations in the weft yarns were also depicted using Eq. (3.3) in which Xc was measured along the weft yarn direction. The parameter, Lu, was calculated by assuming that the cross-sectional shape of the yarns (see in Fig.
3.2b) was composed of a central flat portion of thickness, t, and two sinusoidal lenticular end portions. It was considered that the curved portions of the yarn cross-section followed the sine form of Eq. (3.3). Hence, the width of the curved portion of the yarn cross-section was equal to Lu/2. The cross-sectional area, A, was consequently given by:
(3.4)
By combining Eqs. (3.2) and (3.4), the unknown parameter, Lu, was withdrawn. The total length of the straight portions, Lst, of each yarn was as follows:
(3.5)
In short, using Eqs. 3.3 – 3.5, geometry parameters necessary for the description of 5HS satin weave such as the yarn cross-sectional area, yarn thickness and yarn paths could be determined with a given knowledge of the yarn filament counts, yarn packing density, yarn spacing, filament diameter and overall fibre volume fraction. Furthermore, the undulation in the yarns is commonly represented by its crimp angle (see Fig. 3.2b).
(3.6)
where θc is commonly in a range of θmin and π/2 with θmin calculated by the constraint w ≥ Lu.
(C)
Figure 3.2: (a) The RUC geometry and notation for a 5-harness satin weave composite; (b)Yarn cross-sectional shape (c) Orientation angles 3.1.2.2. Discretisation technique of yarns and determination of three-dimensional
Effective Stiffnesses
Having described the woven architecture, overall composite properties would be calculated by dividing yarns within the RUC into discrete slices. The straight parts of each yarn path, Lst were considered as a sole slice. Meanwhile the undulating parts, Lu were discretised into equal straight slices, n, perpendicular to its in-plane and the XY- plane as seen in Fig. 3.2c. The reason for this was to approximate the undulating, sinusoidal yarn path to n straight yarn slices with equal volume of A × Lu/n.
The spatial coordinate of each yarn slice was specified by the in-plane angle, θ and the out-of-plane, β as shown in Fig. 3.2c. It can be seen that θ is made with the X- axis while β is made with the X-Y plane. As the woven architecture is composed of interlacing, mutually orthogonal (warp and weft) yarns, the angle θ was either 0 for warp yarns or 90 degrees for weft yarns. The angle β was determined for each yarn slice by differentiating the sine function mentioned above for the undulating yarn centerline path.
Therefore, the straight portions of the yarn path had β = 0. In summary, every yarn within the RUC was approximated by straight yarn slices with known quantities such as volumes and orientation angles (i.e. θ and β). The volume filled with the resin in the RUC was subsequently calculated by subtracting the total volume filled with all the yarn slices from the volume of the RUC. It should be noted that the interstitial resin had orientation angles equal to zero as it was modelled as an isotropic material slice.
As a result, the effective stiffness matrix [Ceff] of the RUC was expressed as a function of the yarn slice stiffness matrices (including resin), transformation matrices and
(3.7)
The transformation matrix [Tm] is defined in Appendix A.3. The 6 × 6 stiffness matrix [C’]m describes the 3D relationship between stress and strain of the mth yarn slice. Each yarn slice is considered to be a transversely isotropic material which requires five independent material constants (E11, E22, G12, ν12, and ν23, subscript 1 refers to the longitudinal fibre orientation) to describe the [C’]m matrix. Such engineering material constants had been estimated using micromechanics equations (Malek 2014) from known constituent properties such an fibre properties, matrix properties and the yarn packing density pd (or yarn fibre volume fraction). Additionally, a mesh convergence study was conducted to decide the relevant number of yarn slices, n, in the undulating parts of the yarns, necessary for the convergence of the overall stiffness values [Ceff]. It was found that the minimum value of n equal to 12 could result in an unchanged overall stiffness matrix (Naik 1994). The overall stiffness matrix [Ceff] would be inverted to acquire the overall compliance matrix [Seff] for a later determination of overall moduli and Poisson’ratios.
3.2. Macro-scale (structural) modelling of viscoelastic composites While the woven fabrics are discrete on the micro-scale, woven composites are assumed to be uniform and continuous at the macro-scale to simplify the computations and improve the efficiency of the analysis. The macro-scale analysis of woven fabrics is mainly conducted to simulate the overall structural behaviour of the prepreg/fabric with the input parameters obtained from micro-scale and meso-scale analyses. Both analytical and numerical methods are considered to be part of the macro-scale analysis. The analytical approach involves simple mathematical equations for predicting specific structural behaviour of an isotropic elastic beam under a small displacement. In the numerical approach, the finite element method is used to predict the bending moment- curvature relationship of both elastic and viscoelastic composite plates at various loading rates.
The composite plate is first assumed to behave as a viscoelastic isotropic solid and modelled using the Abaqus built-in viscoelastic constitutive model which is based on the integral form (IF) of viscoelasticity. As applying Abaqus viscoelastic model is limited to isotropic materials, a more versatile orthotropic viscoelastic constitutive model (based on a differential form of viscoelasticity – DF) developed and implemented as a UMAT by researchers (Malek 2014; Zobeiry et al. 2016) is then employed to elucidate the effect of ply anisotropy on the structural responses of uncured prepregs/5-harness satin weave plates.
3.2.1. Numerical approach using Abaqus built-in viscoelastic model (IF) To define the viscoelastic behaviour of an isotropic material in Abaqus, an instantaneous elastic modulus is needed to represent the rate-independent elasticity of the material behaviour. The effective relaxation moduli are obtained by multiplying the instantaneous moduli with the dimensionless effective relaxation functions as given below (Section 22.7.1 in Abaqus Analysis User’s Guide) (Abaqus 2013a):
(3.9)
where t is time, and Go and Ko are the instantaneous glassy (unrelaxed) shear and bulk moduli determined from the instantaneous elastic moduli, Eo, and Poisson’s ratio, υo:
(3.11)
The characteristic parameters of the Prony laws, gi and ki are the weight factors
(3.13)
where Gi and Ki are the shear and bulk moduli corresponding to the specific relaxation time (τi) and N is the number of Maxwell units. 3.2.2. Numerical approach using orthotropic viscoelastic user material model
(Umat)
A recently developed user material subroutine (UMAT) based on the differential form (DF) of viscoelasticity is employed to simulate the time-dependent behaviour of orthotropic laminates. The DF approach and its implementation in Abaqus are briefly described in Appendices A.2 and A.3 respectively. The DF subroutine has been coded in FORTRAN and then implemented through UMAT subroutine. The DF code is capable of modelling the viscoelastic behaviour of isotropic, transversely isotropic (Zobeiry et al.
2016) and orthotropic (Malek 2014) composite material in 3D. Therefore, the effect of ply anisotropy on the buckling behaviour of the viscoelastic composite material can be studied rigorously.
Based on the DF of viscoelasticity, the relaxation functions G(t) and K(t) of an isotropic viscoelastic solid are defined individually in terms of a series of exponentials
(3.15)
in which 𝐺∞ and 𝐾∞ define the long-term shear and bulk moduli (relaxed), respectively. Comparing Eqs. 3.8 - 3.9 to Eqs. 3.14 – 3.15 respectively, the relaxed moduli can be
(3.17)
For orthotropic viscoelastic solids, the above equations can be generalised as described in Malek (2014) and Zobeiry et al. (2016) for each component of the stiffness Using the generalised form of DF of viscoelasticity, the orthotropic behaviour of composite laminates is investigated numerically in this study and the results are compared with experimental data reported in the literature.
Chapter 4. Buckling analysis of multilayered elastic beams with soft and rigid
Ntroduction
As a first step in providing a better understanding of wrinkle formation, the buckling behaviour of solid laminated beams under compressive loads are examined using various analytical and numerical approaches. Two types of models are created by either using composite layup option available in Abaqus or physically modelling layers before assigning material properties as shown in Fig. 4.1. The purpose is to examine the capability of commercial numerical tools available to design engineers, i.e. composite editor in Abaqus, in simulating the buckling behaviour of layered systems separated by relatively soft viscoelastic layers occurring in manufacturing of a range of laminated composite products.
Figure 4.1: Two types of analysis model employed for this study. In this chapter, predictions of these models are compared with analytical models to verify the proposed modelling approach. Two analytical approaches such as eigenvalue and large deformation analyses are conducted. A new model based on the hypothesis that the resin stiffness dominates the longitudinal compressive strength is also created and shown in Chapter 5. Later, the viscoelastic properties of the resin are included in a macro- scale model by replacing previously assumed elastic inputs for the resin. The effective properties of the composite would be obtained by using the viscoelastic micromechanical model proposed by Malek, Vaziri & Poursartip (2018). The estimated composite properties are used in the macro-scale FE simulations.
Ethod
Three-dimensional multilayered beams are modelled using two approaches; (i) layup composite editor for 3D solid composite elements and (ii) physical modelling of individual layers (with 3D solid elements) and interfaces within Abaqus environment.
Each model is composed of N = 48 identical stiff layers which are separated by N - 1 soft interfaces similar to reference (Dodwell 2015). The thicknesses of a single layer (ply), tp, and an interface, ti, are 0.2 mm and 0.01 mm, respectively, thereby the total thickness of the multilayered beam is T = Ntp + (N – 1) ti. The generated multilayered beam is 50 mm of length and 1 mm width (h). For verification purposes, both materials are initially assumed to be homogeneous and isotropic. While Ep and υp, the material properties of the layers, are kept unchanged and equal to 100 GPa and 0.2, respectively, Ei takes a range of values which define the material properties of the interfaces. Identical Poison’s ratio is used for plies and interfaces (i.e. 𝜈𝑝= 𝜈𝑖).
Using the first approach, the composite characteristic is defined by a composite layup tool in the property module of Abaqus CAE as demonstrated in Fig. 4.2. In the second approach, the beam geometry is partitioned into physical layers (thickness of 0.2 mm) separated by distinct interfaces (thickness of 0.01 mm) before they are meshed and the material properties are assigned.
Figure 4.2: Composite Layup
To verify the model, the deformation behaviour of multilayered cantilever beams with a range of interface stiffness under a vertical displacement is examined (Case I). Results are compared with a simple beam bending equation to highlight the need for more sophisticated elements or approaches in this area. Then, the critical buckling loads and the first mode shapes of flat laminates with soft interfaces are compared with those with stiff ones (Case II). The critical buckling loads are presented and compared with Euler buckling estimates. In both cases, the effect of ply anisotropy on the buckling behaviour of laminates with soft and stiff interfaces is investigated.
4.3. Multilayered cantilever beam under bending (Case I) A 1 × 10.07 × 50 mm multilayered cantilever beam is modelled using a 20-node quadratic brick element with reduced integration element (C3D20R) and mesh size of 0.2 mm. The elastic behaviour of this beam is first examined using the PML approach. While one end of the beam is fixed, a vertical displacement equal to Δ = 0.2 mm is applied to the other end. Both the layers and interfaces are assumed to be isotropic in Case I. The force, P, at the free edge corresponding to the vertical displacement of 0.2 mm is obtained from finite element analysis and compared with the one calculated from the Euler – Bernoulli beam bending theory (i.e. ignoring shear deflection) (Bauchau & Craig 2009):
(4.1)
where EI is the flexural rigidity of the cantilever beam section. EI is obtained by assuming the layers fully bonded or no interaction between layers which provides a lower bound as demonstrated in Table 4.1. Four cases corresponding to four different values of Ei (interface modulus) are considered; starting at the same stiffness of ply modulus Ep (100 GPa) and reducing by a factor of 10 for the other three subsequent cases.
Table 4.1: Comparisons between current FE predictions, Dodwell (2015)’s FE results, and the analytical model based on Euler-Bernoulli kinematics (Eq. 4.1) for a multilayered cantilever beam (Case I).
10-2
Table 4.1 highlights a good agreement between results from the present finite element analysis with Dodwell’s FE model for all four cases and analytical upper bound when Ei equals Ep, 100 GPa; lower bound when Ei is very soft (1 kPa). It should be noted that only the bending deformation is considered in Eq. (4.1). When Ei = Ep = 100 GPa, the contribution of shear deformation is negligible and the multilayered cantilever deforms as a solid isotropic beam based on the assumptions of Eq. In the subsequent circumstances with soft interfaces, however, due to severe shear deformations at the interfaces, the layers are more likely to bend more independently, decreasing the apparent flexural stiffness of the entire beam.
To better understand the role of ply anisotropy on the overall beam rigidity, three more cases with transversely isotropic layers are considered. The elastic constants of such layers are listed in Table 4.2.
Table 4.2: Input properties of the transversely isotropic plies.
Note: * Indicates Non-Dimensional
Figure 4.3: The role of interface stiffness and ply anisotropy on the multilayered cantilever beam rigidity. Fig. 4.3 highlights the role of interface stiffness for isotropic and transversely isotropic laminates. As the interface becomes soft (Ei = 0.01 GPa), the beam flexural rigidity is significantly reduced irrespective of the ply orthotropic nature. In other words, the soft interface dominates the bending response (e.g. uncured prepregs and laminates during cure). However, the beam bending behaviour is dominated by the engineering constants of the plies when the interface is stiff (1 GPa < Ei < 100 GPa). In other words, we could assume that plies are almost perfectly bonded when the interface is relatively stiff (cured laminates).
4.4. Flat laminate under compressive load (Case II) The buckling behaviour of a flat laminate (10.07 × 1 × 50 mm) is considered here using two different approaches; Abaqus built-in composite editor (CE) and physically modelling layers (PML). Similar cases are also considered with transversely isotropic material properties to understand the role of ply anisotropy on the laminate buckling response.
Two Pinned Ends
First, the laminate is pin supported and a uniform axial pressure on the free end face is applied. Such a simple buckling scenario is considered because there is an existing analytical solution for verification purposes. The FE results using eigenvalue analyses for both approaches mentioned above along with Euler predictions are summarized in Fig.
4.4. Five interface properties, Ei, ranging from 100 kPa to 100 GPa, equal to constant Ep, are also introduced to investigate the influence of interface stiffness on the overall buckling behaviours.
As seen in Fig. 4.4, results from CE analyses increase slightly as the interface becomes more rigid. With PML models, critical buckling loads reduce significantly in comparison especially when the interfaces are much softer than the plies (Ei ≤ 1 MPa).
PML results are between Euler predictions and when the interfaces are very soft, the results approach the lower bound. The shapes of buckled beams with stiff interfaces (Ei = 100 GPa) are plotted in Fig. 4.5 and 4.6 for CE and PML models respectively. Both mode shapes are identical and buckle in y-plane. However, only PML analysis can capture buckling deformation when the interfaces are very soft (Fig. 4.7). The laminate bends in x-plane, meaning that dropped significantly, as shown in Fig. 4.4.
Figure 4.4: Comparisons of FE results with Euler predictions for isotropic plies (Ep= 100 GPa) bonded with a range of interfaces. Figure 4.5: Buckling mode shape for flat laminates with stiff interfaces (Ei = 100 GPa) using PML approach. The beam cross section is depicted on the right side.
Figure 4.6: Buckling mode shape for flat laminates with stiff interfaces (Ei = 100 GPa) using Abaqus CE. The laminate layup is depicted on the right side for clarity. Figure 4.7: Buckling mode shape for flat laminates with soft interfaces (Ei = 100 kPa) using PML approach.
Similar to Case I, the effect of ply anisotropy on the buckling behaviour of laminates is investigated by using PML models and results are presented in Fig. 4.8. Two different transversely isotropic properties listed in Table 4.2 and 4.3 are used for comparison. When the transverse Young’s modulus and shear moduli are still high (Table 4.2) their effects on the buckling response are negligible (Fig. 4.8). Results also demonstrate the less significant effect of ply anisotropy compared to the interface stiffness. The interface stiffness (or the presence of resin rich areas between the plies) dominates the buckling response of flat laminates similar to their bending response presented in Case I. During composite processing, the resin modulus may decrease quite significantly. This could lead to formation of wrinkles (buckled plies) under much lower compressive loads which needs to be captured accurately.
Table 4.3: Input properties of the transversely isotropic plies.
Note: * Indicates Non-Dimensional
Figure 4.8: The influence of ply elastic constants on the buckling response of flat laminates using PML approach.
Four Fixed Edges
To look at the role of manufacturing constraints, an additional boundary condition is applied for the two remaining edges of the laminate beam. It is to prevent plies from moving in the plane perpendicular to the compressive load direction, so that plies can buckle internally. Table 4.4 lists preliminary finite element results for beams with a range of interface properties. The four cases correspond to four values of starting with the same stiffness of ply modulus Ep = 100 GPa and reducing by a factor of 10 for subsequent cases.
Table 4.4: Comparisons of FE results between composite element models and models
(Pcr)Pml
For the beams modelled using Abaqus composite editor (CE), results show that as the interface becomes more rigid, the critical buckling load increases only slightly (see Table 4.4). In contrast, the critical buckling load reduces more than 6 times as the elastic modulus of the interfaces are reduced by a factor 1000 (compare Laminate 1 and Laminate 4) for PML analyses. When the interface and ply modulus are identical (100 GPa), the minimum critical loads obtained using both approaches (CE and PML) are almost the same. As shown in Fig. 4.9, the composite laminate is buckled into seven half waves in the longitudinal direction for the stiff interface (Ei = 100 GPa). Similar mode shape is observed using PML approach for stiff interface as depicted in Fig. 4.10 (red line). However, the predicted critical buckling load (Table 4.4) and first mode shape of laminates with PML become quite different from those modelled using Abaqus CE as the interfaces become soft. It is more likely that the soft interfaces dominate the overall buckling of the multilayered beams which cannot be captured with CE models. When the stiffness of the interfaces decreases, the internal buckling wavelength rises as seen in Fig.
4.10. Figure 4.9: Magnitude displacement (in mm) at critical buckling load – Composite element model – Ei = 100 GPa.
Figure 4.10: Internal buckling wavelength along the beam length – Physically modelling layers.
Summary And Conclusions
The buckling analysis of multilayered composite beams using two different approaches was conducted. The performance of Abaqus built-in composite editor was compared with physically modelling the individual plies and interfaces using solid elements. Results show that Abaqus built-in composite element (CE) is only capable of estimating the composite critical buckling load when the mismatch between layers (plies) and the interface elastic modulus is relatively low. When the interfaces are soft (e.g. at the early stage of cure), a significant difference was demonstrated between finite element results obtained from the composite editor and the physically layered model. Therefore, alternative approaches or elements are required for simulating the deformation of laminates during composite processing accurately. It was demonstrated that by physically modelling the thin interfaces between plies, the significant reduction of critical buckling loads could be captured for laminates bonded with soft interfaces.
The proposed approach is an initial step towards implementing an orthotropic viscoelastic model for multi-scale process modelling of laminated composites with complex microstructures in subsequent chapters.
Chapter 5. Buckling behaviour of laminated viscoelastic composites under axial
Ntroduction
This chapter considers the viscoelastic nature of the resin during the manufacturing process in the multi-scale modelling approach. The effective properties of the composites obtained from viscoelastic micromechanical models instead of assumed elastic inputs for the resin properties as in Chapter 4 are used in the macro-scale FE model.
The orthotropic viscoelastic properties of the laminate are considered by incorporating the fibre-bed elastic properties into the micromechanics equations to estimate the effective viscoelastic properties of the uncured prepreg.
At macro-scale, a more versatile orthotropic viscoelastic constitutive model based on differential form (DF) of viscoelasticity implemented as a user material subroutine (UMAT) compared to using Abaqus built-in viscoelastic model (IF) is employed. This helps to elucidate the effect of ply anisotropy on the buckling response of uncured/partially cured unidirectional (UD) laminates. The numerically viscoelastic modelling approach described in Chapter 3 was used to determine the critical buckling load of both cured elastic and uncured viscoelastic laminated composite under various loading rates. The analytical approach involving simple mathematical equations for estimating the buckling loads in thin elastic plates is provided in the following section for verification purpose. The details of the FE buckling model and its validation by comparing to experimental data available in the literature are also presented in this chapter. Using the numerical model, the influence of various parameters including loading rates, the instantaneous elastic modulus, and in particular the effects of the ply anisotropy on the buckling behaviour of composite laminates are analysed. It has been found that unlike cured composites, the compressive stiffness of uncured prepregs is mainly dominated by the resin modulus rather than the fibre modulus. Additionally, it is shown that the waviness of fibres (fibre-bed effect) which stiffens the prepreg’s transverse and shear properties increases its compressive stiffness slightly while the waviness effect on the post buckling stiffness is relatively significant.
Ethod
To simulate the buckling response of viscoelastic composites and to study rigorously the role of various parameters on the onset of wrinkle formation, the behaviour of flat unidirectional laminates under axial loads are modelled both analytically and numerically. The analytical approach involves simple mathematical equations for predicting the buckling loads in thin plates. For the numerical approach, finite element method is used to estimate the critical buckling load of uncured viscoelastic laminated composite under various loading rates.
For viscoelastic modelling, the composite laminate could be assumed to behave as a viscoelastic solid with perfect bonding between the layers using the Abaqus built-in viscoelastic constitutive model which is based on the integral form (IF) of viscoelasticity.
As the application of Abaqus viscoelastic model is limited to isotropic materials, a more versatile orthotropic viscoelastic constitutive model (based on differential form of viscoelasticity – DF) that has been developed and implemented as a UMAT by also employed to elucidate the effect of ply anisotropy on the buckling response of uncured unidirectional laminates. The detail of these two viscoelastic approaches was demonstrated in Chapter 3.
The axial compression behaviour of thin laminates with end supports and unsupported sides may be treated similar to the columns under axial loads. Using this very basic approach, the critical buckling load (Pcr) of a linear isotropic laminate can be approximately estimated using the Euler buckling theory (Timoshenko & Gere 1961):
(5.1)
where E is the elastic modulus of the isotropic material, I is the minimum area moment of inertia of the rectangular cross section, L is unsupported length of column and K is the effective length factor depending on the end constraints. As the slenderness ratio of the laminates in this study is high (i.e. 192.5), Euler buckling may be considered here.
To obtain more accurate prediction, the critical buckling stress can be determined with the plate buckling theory (Rees 2009) as follows:
(5.2)
in which 𝑘2 = 𝑡2/12 and t is the thickness of the laminate. The equivalent length, Le, for
(5.3)
where a and υ are the total length of the plate and the material Poisson’s ratio, respectively.
Odel Verification
Although the compaction and the bending behaviour of thin laminates which may lead to wrinkling during viscous composite forming have been investigated in the literature, the buckling behaviour of uncured laminates has not been investigated comprehensively with validated numerical tools. To illustrate the importance of buckling response of laminates at the early stage of cure, the behaviour of linearly isotropic and then transversely isotropic flat laminates with a range of stiffness values representing the uncured and cured composites are considered first. A buckling model, which has shown some advantages over other methods such as 3-point bending test (Wang, Long & Clifford 2009), is employed. For verification purposes, the numerical results for isotropic laminates are compared to the analytical model predictions.
Geometry And Input Parameters
For verification and validation purposes, a rectangular geometry with the dimensions similar to the experiments of Wang, Long & Clifford (2009) is selected. Three rectangular unidirectional (UD) prepreg plies (0o/0o/0o) are considered as a simple case to minimize the number of variables. According to Wang, Long & Clifford (2009), such a three thin ply model can allow elimination of the deformation under self-weight.
The geometry is partitioned in Abaqus environment before the material properties are assigned, as illustrated in Fig. 5.1 (right side). The total length of two clamped ends is 25 mm and the tested region is 50 × 50 mm as in the test set-up of Wang, Long & Clifford (2009). According to Wang, Long & Clifford (2009), the purpose of the long clamps mounted carefully on the specimen was to protect the fibre from any misalignment which can lead to defects at the early stage of forming process. The thickness of each UD prepreg is 0.3 mm and the fibre orientation is parallel to the compressive load as shown in Fig.
5.1 (left side). All translations were restricted on one of the transverse edges, while the other transverse side was considered to be free of in-plane displacement in the loaded direction. A uniform axial displacement along this transverse edge was applied in the load increment scheme. Since the specimen was mounted in the aluminium clamps, an additional restraint against vertical displacement at the clamped regions was included in the present FE model, as shown in Fig.
Prior to investigating the effect of loading rates on the time-dependent behaviour of prepregs, the material is assumed to behave as an isotropic elastic solid first. Then, the material is changed to a transversely isotropic one to represent the behaviour of UD composite laminates. The material input parameters for the cured laminate are taken from Wang et al. (2009) and summarized in Table 5.1. The elastic modulus along the Y-axis, is the laminate’s stiffness in its longitudinal direction E1, as depicted in Fig. 5.1. The proposed input values were based on the information provided by Hexcel Company for the cured composite laminate. It should be noted that the uncured properties have not been reported and some assumptions need to be made for uncured prepregs as described in Section 5.3.
Authors:
Peder EZ Larson 1, 2,* , Jenna ML Bernard1, James A Bankson 3, Nikolaj Bøgh 4, Robert A Bok1, Albert P. Chen 5, Charles H Cunningham 6,7, Jeremy Gordon1, Jan-Bernd Hövener 8, Christoffer Laustsen 4, Dirk Mayer 9,10, Mary A McLean11 12, Franz Schilling13, James Slater1, Jean-Luc Vanderheyden5, 14, Cornelius von Morze 15, Daniel B Vigneron1, 2, Duan Xu1, 2, and the HP 13C
94143, Usa.
Denmark. 5 GE Healthcare, Menlo Park, California, USA. 6 Physical Sciences, Sunnybrook Research Institute, Toronto, Ontario, Canada.

8 Section Biomedical Imaging, Molecular Imaging North Competence Center (MOIN CC), Medicine, Baltimore, MD, USA. Cambridge, United Kingdom.

14Jlvmi Consulting Llc, Dousman, Wi, Usa
#See Acknowledgements for a list of all HP 13C MRI Consensus Group Members This work was supported by the ISMRM Hyperpolarized Media MR Study Group, the ISMRM Hyperpolarization Methods & Equipment Study Group, and the Hyperpolarized MRI Technology Resource Center (NIH/NIBIB grant P41EB013598).
Abstract
MRI with hyperpolarized (HP) 13C agents, also known as HP 13C MRI, can measure processes such as localized metabolism that is altered in numerous cancers, liver, heart, kidney diseases, and more. It has been translated into human studies during the past 10 years, with recent rapid growth in studies largely based on increasing availability of hyperpolarized agent preparation methods suitable for use in humans. This paper aims to capture the current successful practices for HP MRI human studies with [1-13C]pyruvate - by far the most commonly used agent, which sits at a key metabolic junction in glycolysis. The paper is divided into four major topic areas: (1) HP 13C-pyruvate preparation, (2) MRI system setup and calibrations, (3) data acquisition and image reconstruction, and (4) data analysis and quantification. In each area, we identified the key components for a successful study, summarized both published studies and current practices, and discuss evidence gaps, strengths, and limitations. This paper is the output of the “HP 13C MRI Consensus Group” as well as the ISMRM Hyperpolarized Media MR and Hyperpolarized Methods & Equipment study groups. It further aims to provide a comprehensive reference for future consensus building as the field continues to advance human studies with this metabolic imaging modality.

Keywords: Hyperpolarized MRI, metabolic imaging, carbon-13, pyruvate, dissolution dynamic
Introduction
MRI with hyperpolarized 13C agents, also known as hyperpolarized (HP) 13C MRI, has shown great potential as a novel imaging modality, particularly for its ability to probe metabolic processes in real time. The first human studies with HP [1-13C]pyruvate were performed in 2011 in prostate cancer patients (1).

Since then, there have been over 60 papers published with imaging results of human subjects from 13 different sites, with applications including prostate cancer, brain tumors, breast cancer, kidney cancer, pancreatic cancer, metastatic disease, liver disease, ischemic heart disease, diabetes and cardiomyopathies. The vast majority of these studies used [1-13C]pyruvate (1–63), where [2-13C]pyruvate (64) and 13C-urea (56) have been demonstrated too.
As clinical HP 13C MRI advances, there is a growing need to build consensus for best practices, which are critical for comparing data across sites, performing multi-site trials,deploying methods to new sites, partnering with vendors, and potentially for obtaining broader regulatory approvals.
In March 2022, we initiated an effort to build consensus within the HP 13C MRI community with this opportunity in mind, and it was greeted with strong enthusiasm. The “HP 13C MRI Consensus Group”, containing over 55 members from 27 sites, identified the area of greatest need and opportunity for consensus building to be HP [1-13C]pyruvate human
●
Pyruvate is the most mature and widely used HP agent and has the most significant translational evidence emphasizing the potential clinical impact.
●
Clinical trials, particularly multi-site trials, have the strongest need for consensus methods to ensure that data can be combined across sites. This work is a Position Paper for which the goal is to describe current successful practices and study methods for HP [1-13C]pyruvate human studies along with justification to support those practices. This is divided into four major topic areas: (1) HP 13C-pyruvate preparation, (2) MRI system setup and calibrations, (3) data acquisition and image reconstruction, and (4) data analysis and quantification (Fig. 1). The current successful practices and study methods include a literature review of published peer-reviewed journal papers showing human HP [1-13C]pyruvate study data, up to September 2022 (1–63), as well as new unpublished information from surveys of HP 13C study sites. Based on this information, we also highlight the evidence gaps, strengths, and limitations of current practices which are summarized at the end of each section.
Figure 1: Illustration of the HP 13C MRI human study process, including the 4 major areas covered in this paper: Hyperpolarized 13C-pyruvate preparation, MRI system setup and calibration, Acquisition and Reconstruction, and Data Analysis and Quantification.
Figure 2: Anatomical targets of HP [1-13C]pyruvate MRI human studies published up to September 2022.
Hyperpolarized 13C-Pyruvate Preparation
This section covers the processes for creating the HP agent, 13C pyruvate, and will include many aspects and considerations that are needed to safely and effectively prepare doses for metabolic imaging studies in human subjects. These include material, personnel, equipment and facility, fluid path preparation, quality control, and release.
It is helpful to understand that the specifications of a dose of 13C pyruvate suitable for in vivo MR HP metabolic imaging were shaped in part by early preclinical studies performed by GE HealthCare summarized in Ref. (65). In short, the safety of the two novel drug components, 13C pyruvate and the electron paramagnetic agent (EPA) AH111501, were demonstrated in those studies. The more precise formulation of the dose suitable for human use was then determined from clinical studies (66) that included two Phase 1 clinical trials in young and elderly healthy volunteers without hyperpolarization of the 13C nuclei and another Phase 1/2a dose escalation and imaging feasibility study with HP 13C pyruvate in 31 prostate cancer patients at the With the exception of the first HP 13C imaging clinical trial, which utilized a prototype device in a cleanroom (1), all HP 13C studies performed in humans to date have utilized the SPINlab polarizer (manufactured by GE HealthCare). Consequently all doses of the HP 13C pyruvate delivered by SPINlab have been produced using the “SPINlab Pharmacy Kit” that serves as the container-closure system for the various drug components (13C pyruvic acid and EPA mixture, dissolution medium, and neutralization and dilution medium) during sample polarization, dissolution and quality control (QC) processes. Thus many aspects of the HP sample preparation considerations discussed below are related to the SPINlab instrument and the consumables designed to be used with it (67).
General Considerations
While more than 860 patients or healthy subjects having been injected with HP 13C pyruvate as of January 2022 without reports of any serious adverse events (68), HP 13C pyruvate injection remains an investigational MR contrast agent and can only be administered by those with Investigational New Drug (IND) exemption from the Food and Drug Administration (FDA) in the USA, a Clinical Trial Application (CTA) in Canada, approval from National Research Ethics Committee Services in the UK, or approval from the relevant local regulatory body. Thus, methods and processes involved to produce a dose should have patient safety as the first priority. Since utilizing dissolution dynamic nuclear polarization (dissolution-DNP) for human use is still a relatively new development, there are no existing published regulatory guidelines specifically for this method.
There are two major production styles that determine how various sites approach the agent preparation. In the US, the most common approach is to rely on a sterilizing filter (“Terminal Sterilization”) to ensure sterility of the final product, akin to PET tracer production, where a starting molecule with a radioisotope is processed using various other ingredients to make the final, desired and injectable contrast agent within a necessarily short amount of time (69). For these sites, sterilization of the components and accessories upstream of this filter are not required, although many of them were manufactured and tested following Good Manufacturing Practice (GMP) or Good Laboratory Practice (GLP) requirements. The filling process is usually performed under an ISO 5 laminar flow hood, but a clean room or an isolator is not required.
This approach is typically accompanied by testing the integrity of the sterilizing filter prior to release of the dose for injection. Typically, post release endotoxin and sterility tests are performed using an aliquot reserved from each released dose.
In the UK and EU, the most common approach is to more-closely follow sterile pharmaceutical compounding guidelines (70), where all components and ingredients are required to be sterile or manufactured under GMP guidelines and are assembled and filled within a clean room environment or an isolator system (“Sterile Preparation”). Typically a batch of Pharmacy Kits for HP 13C pyruvate injection are prepared together. The sterility of the final dose is also ensured by batch validation testing, in addition to the sterility of the ingredients and the sterile compounding process. The endotoxin and sterility testing are performed for the process validation but are not performed for each injected dose.
Some institutions fill and assemble the Pharmacy Kit required for a specific study on the same day or the day prior to polarization, dissolution, and patient administration, but others have also demonstrated the feasibility of preparing a batch of kits, keeping them in a -20ºC freezer and using them over a period of a few months.
Beyond the obvious requirements that the process and the facility has to ultimately produce a dose that is safe to inject into a human, regulatory authorities will also focus on the question “Are you in control of your processes?”. To be in control of your process requires an in-depth and broad understanding of all processes involved in pre, post, and during the production process.
Personnel
It is typical and may be required to have licensed personnel involved in the production process depending on local regulations.Typically a pharmacist, radiopharmacist or other similarly qualified person (QP), in charge of the facility where the Pharmacy Kit filling and preparation is taking place, is responsible for the overall process and the release of the injectable dose.
Qualified cleanroom technicians are often involved in the Pharmacy Kit filling under the supervision of the pharmacist or QP. As is required for pharmaceutical compounding or PET tracer production, training requirements and training records for all personnel need to be maintained and available for audit by the FDA or equivalent.
Equipment And Facility
The facility and all equipment need to have standard operating procedures (SOPs) that describe how equipment is used, maintained, and calibrated to comply with relevant legislation. Currently, almost all the filling of the Pharmacy Kit takes place within a compounding laminar flow hood or isolator (typically ISO 5). At some sites, the filling is conducted within a cleanroom, while at others, it is conducted in a dedicated non-cleanroom space, reflecting differences in cleanroom approach and specifications between regulators worldwide (71). Some equipment or facilities, such as the compounding hood or cleanroom, may require external certified laboratories for testing.
Material Handling
Material handling guidelines (69,70) require SOPs detailing a system to track all of the materials involved in the HP production process for a particular patient dose, similar to current good manufacturing practice (cGMP) requirements for material handling for drug compounding. This includes acceptance standards, storage conditions, amount used in the patient dose for each ingredient and materials used in the assembly of the fluid path and Pharmacy Kit. Currently some users choose to open and inspect and sometimes modify the Pharmacy Kits upon arrival, but some users keep them in the sealed packaging until they are required for dose preparation.
Pharmacy Kit Filling And Assembling
As required by an IND or its equivalent, the preparation of the doses of HP 13C agent are detailed in the Chemistry, Manufacturing, and Control (CMC) section of an applicable regulatory submission; an example of this has been made available (72). It describes the processes of filling the Pharmacy Kit with the different components that make up the final drug product, and of assembling the final kit for either storage or immediate use in the polarizer. Special attention should be given to the laser welding process in order to satisfy installation qualification (IQ) and operational qualification (OQ). Typically, the final developed process is validated by process qualification (PQ) runs, during which 3 or more Pharmacy Kits are filled and used and the final HP 13C products are tested for endotoxin and sterility and to confirm that they meet the dose specifications for injections (usually including pyruvate concentration, residual EPA concentration, pH, liquid state polarization level and dose temperature). The data from 3 consecutive PQ runs are submitted as part of the IND submission (or its equivalent), and are often also reviewed by the Institutional Review Board (IRB) where the studies are conducted.
Quality Control And Dose Release
The quality control (QC) and dose release can be separated into two aspects: one is the QC and release of the filled Pharmacy Kit, and second is the QC and release of the HP 13C agent for injection, after polarization and dissolution. For institutions filling a batch of kits and storing them to use over a period of time, typically the batch can be released based on initial validation, environmental monitoring data from the day of kit production, and if filters are used during preparation of any of the components, filter integrity testing. But in some cases one or more kits are used for validation before the batch of kits are released for future use. For institutions that fill only the kits required for specific studies shortly before the experiment, the filled kits often do not go through separate release tests before they are used.
The quality control of the HP 13C pyruvate solution post dissolution is primarily performed to ensure that the agent meets the dose specifications (Table 1) before it is administered to the subject. These specifications target both safety (pH, residual EPA, temperature) and efficacy (pyruvate concentration, polarization, volume). Typically, the pyruvate concentration, residual EPA concentration, pH, dose temperature, dose volume, and liquid state polarization are measured by the QC accessory associated with the SPINlab polarizer. Some users perform a secondary measurement for one of the parameters, such as pH, using a different instrument or pH paper. For sites that do not go through a separate release testing process for batch filled kits, the integrity of the sterilization assurance filter, a part of the Pharmacy Kit, is typically tested as a part of the dose release. It is also common for these users to preserve an aliquot of the final HP 13C pyruvate solution for post-release endotoxin and sterility testing. This testing cannot be completed fast enough to test an individual dose prior to injection, but this is why other processes such as PQ runs and validation testing are done to minimize the chance a subject could be injected with a contaminated dose.
The Final Dose Release And Injection
should be done under the supervision of a licensed professional, based on local regulations.
Some Key Challenges
Many of the challenges associated with HP 13C pyruvate preparation can be attributed to the conditions required for the dissolution-DNP method of high magnetic field (~3-7 T) and very low temperature (~1 K) during polarization, with pressurized and superheated water necessary for the rapid dissolution event. These extreme conditions are quite challenging for the design of the container-closure and fluid path system. In particular, the cryogenic temperature in the polarizer requires special attention to any moisture or ambient (moist) air introduced into that portion of the fluid path, which can form an ice block at ~1 K. This ice can lead to flow restriction during the dissolution event and reduce the strength of the laser welded bond between the cryovial and its cap. This can ultimately produce failures in the dissolution step, including variations in final pyruvate concentration and pH that may fail to meet QC release criteria as well as fluid path ruptures that provide no available dose and result in polarizer down-time.
The polarization of the HP 13C pyruvate sample decays quickly over the span of a few minutes after dissolution, and thus the process of dissolution, QC for release, and injection should be completed as fast as possible to preserve the high polarization level achieved. Any delays in the preparation process, such as transportation time or equipment malfunction, can significantly reduce the final polarization and result in lower quality imaging data.
Current Practices
A summary of data collected from all sites performing clinical trials with HP 13C-pyruvate is shown in Fig. 3 and Table 1, including the specification of the final dose and how the quality control and release of the final dose are performed. There is a split in the Production Style, described in the General Considerations section above, with 8/13 sites using Sterile Preparation versus 5/13 using Terminal Sterilization. While many of the dose specifications show notable differences in acceptable ranges, all of these variations listed in tables have been successfully and safely been used to perform HP 13C pyruvate studies in humans. Their differences depend on the institutions’ preferences, resources and their particular regulatory situation. There is high similarity in pyruvate ranges, temperature ranges, EPA limits, and volume limits. There is modest variability in pH ranges and large variability in the endotoxin test limit. There is a 3-fold difference in acceptable polarization levels, which are measured to ensure a futile dose is not injected since the polarization is directly proportional to SNR. This reflects the decision by several sites to believe that useful data can be still be obtained with suboptimal polarizations.
Figure 3: Hyperpolarized agent preparation methods reported by sites currently performing HP
In House
Table 1: HP 13C-pyruvate preparation parameters, methods, and dose specifications used for quality control testing and release as well as validation. These were obtained from a survey of all sites performing clinical trials with HP [1-13C]pyruvate. The parameters used for product release are noted in bold text, otherwise these parameters are measured for batch validation or other QC measurements. The endotoxin and sterility testing are performed during process validation of the batch and/or post-injection, and largely depends on the agent production approach.
Summary
The overall safety record of HP 13C-pyruvate has been very strong, and the SPINlab hyperpolarizer has proven to provide high polarizations at human sized doses while meeting numerous QC and release criteria. A weakness remains the failure modes of the SPINlab Phamacy Kits (e.g. ice blocks, path ruptures), which are placed under extreme requirements particularly during dissolution. The preparation process still requires a high degree of expertise.
Therefore, there is a significant need to improve the reliability, robustness, and ease of operation for generating HP 13C-pyruvate doses for human studies. Furthermore, there is a divide between manufacturing and sterile compounding style preparation as well as other site-specific practices, resulting in variations in SOPs and justification required to relevant regulatory bodies. There have also been no comparisons between these approaches. It is also unclear what release criteria and QC parameters are truly required to ensure patient safety.
However, all of the reported methods are acceptable and approved by the appropriate regulatory authorities, and have led to the rapid expansion of successful human studies in recent years.
Mri System Setup And Calibrations
This section covers the MRI system setup, including the imaging system, RF coils, phantoms, and prescan calibration methods.
Imaging System
The main prerequisite for a given MRI scanner to be capable of supporting studies with HP 13C is its “broadband” capability to transmit and receive radiofrequency (RF) signal at the frequency of 13C, which is around 4 times lower than 1H. This does not come as a default on clinical MR devices. The transmit power of the broadband amplifier should also be sufficient to support the intended flip angle and RF pulse shape with the employed transmission RF coil(s) for 13C. Most studies to date use relatively low flip angles (< 90 degrees) for HP 13C in order to preserve polarization for time-resolved imaging. The capability to receive 13C signal on multiple channels is also desirable to increase SNR, as discussed further in the “RF coils” section.
The choice of magnetic field strength is primarily dependent on the metabolites’ frequency separation due to chemical shift dispersion and 1H imaging. High field strengths do not enhance hyperpolarized 13C signal as they do for 1H because the signal strength in a HP experiment relies on manipulating the population of quantum energy states outside of the MRI scanner.
However, the injected HP 13C-pyruvate and its metabolic products have greater frequency separation at higher fields, and it may thus be easier to separate and quantify these resonances at higher fields. This comes at the cost of a reduction in the achievable T2* and often reduced T1. As the initial polarization is independent of the imaging field strength it has been proposed that the increased T2* at 1.5T can potentially be exploited to increase SNR by adapting the acquisition bandwidth or reduce off-resonance imaging effects in cases when the decay of the transverse magnetization is dominated by T2* (73). In practice, 3T has been used in all published human 13C-pyruvate studies surveyed (Supporting Table S1), and comprises the majority of scanners currently in use for human studies (Table 3). A field strength of 3T is well-suited for 1H MRI anatomical reference and correlative imaging.
Stronger and more rapidly slewing magnetic field gradients support more rapid spatial encoding, particularly for metabolite-specific single-shot imaging using echo-planar imaging (EPI) or spiral imaging (See “Acquisition and Reconstruction”). Although the spatial resolution acquired for HP 13C imaging is typically much coarser than for 1H MRI, the factor of ~4 in gyromagnetic ratio leads to the same reduction factor in performance of the gradient system, so 13C experiments are potentially more limited by gradient hardware performance. To date, all human studies have used the commercially-available integrated gradient systems provided in clinical MRI scanners.
Optimization of scanner design has understandably focused on minimization of artifacts in 1H MRI, where devices such as room lights, the gradient amplifiers, and the motors driving the patient bed are checked to ensure that they do not produce RF interference at the 1H frequency, but artifacts may arise at other frequencies. Eddy current compensation is also not always appropriately adjusted for nuclei at other frequencies (74). In order to optimize for 13C, many sites have performed checks on phantoms for RF interference, gradient artifacts, and eddy currents (74), including the use of post-hoc gradient impulse response function characterisation and correction, and some vendors have fixed these issues as well.
Rf Coils
For HP 13C imaging studies in humans, RF coils for both 1H and 13C nuclei are needed, with 1H MRI providing an anatomical reference for registration and optional additional multiparametric MRI readouts. At the Larmor frequency of 13C nuclei, the relative contributions from coil noise compared to sample noise increase compared to 1H (73,75), although sample noise still is likely the dominant contributor for human-sized coils at 32.1MHz - the resonance frequency of 13C nuclei at 3T.
The key requirement for human 13C-pyruvate RF coils are that the coil geometry and sensitive volume must cover the volume of interest in the subject. Table 2 and Figure 4 shows coil configurations that have been used and optimized for applications in different anatomic regions.
Volume resonators are most commonly used for transmit, as they surround the subject to
Provide B1 Transmit Across The Fov (B1
+). While 1H relies on a large birdcage (“body”) coil built into the scanner, 13C transmit coils must be placed inside the bore. This takes up valuable space within the magnet, and also has led to the use of designs with relatively inhomogeneous
B1
+. Many human studies have used Helmholz pair resonators for transmit, including the “clamshell coil”, which has a notably inhomogeneous B1
+ Profile But Has Been Used Because Of
relatively easy integration into the scanner bore. B1
+ Variation Results In Variations In The Flip
angles that control the use of the hyperpolarized magnetization and creates errors in common HP metrics (9,76). The exception are head coils, where birdcage designs with highly
Homogeneous B1
+ can be placed around the head while easily fitting inside the bore. As with 1H MRI, higher SNR can typically be achieved by smaller receive coil elements, such as surface coils or phased arrays, and the majority of 13C receive coils used have layouts similar to 1H phased arrays.
RF coil quality control is important to ensure proper functioning of the coils to provide consistent imaging quality, especially with limited natural abundance 13C signal in vivo. It typically involves 1) a physical integrity check of the coil cables and connectors and 2) phantom SNR tests to check the coil’s performance and to monitor it over time (see Phantoms below). An useful reference for RF coil quality control is outlined in the MRI accreditation program of the American College of Radiology (77) and can be adapted for 13C coils.
Notably, configurations for brain and prostate studies used dual-tuned 1H/13C coil designs, which greatly simplify workflow and registration of 1H and 13C images, as no switching of coils is needed.
(1)
Table 2: RF coil configurations reported for human HP [1-13C]pyruvate studies.
Tx = Transmit
coil, RX = receive coil. The commonly used “clamshell” TX coil is a Helmholz pair design. For 1H RF configurations, all used the Body coil for TX unless otherwise noted, and “repositioned” indicates the 13C coil was removed for 1H imaging. One representative reference is listed for each configuration. The RF coil configurations reported in the reviewed papers are shown in Supporting Table S1.
Figure 4: Examples of RF coil configurations used for human HP [1-13C]pyruvate brain studies. (A,B) 13C Clamshell TX (Helmholz pair) and 2× 4-channel paddle RX arrays. (C) 13C Birdcage volume TX and 32-channel RX array (RX array slides into TX coil). (D) 13C Birdcage volume TX and 24-channel RX array, combined with a 1H 8-channel RX array. Image reproduced with permission from Ref (16).
Phantoms
Since hyperpolarized magnetization is non-renewable, phantoms containing 13C nuclei are important to: 1) test the multi-nuclear capabilities of the imaging system, including all parts of the signal excitation and receive chain; 2) perform calibration measurements before a scan with hyperpolarized nuclei; and 3) perform necessary pre-scan adjustments (see “Prescan Calibration” section). The phantoms currently in use are listed in Table 3. Their composition must provide sufficient 13C signal, with additional considerations of conductivity, stability, chemical shift(s) present, potential for dynamic imaging, and cost. The phantom geometries are typically either compact, in order to be used alongside the subject during a HP scan, or large enough to mimic the inner volume of a RF coil for system testing.
One popular compact design contains enriched 13C-urea at high concentration, typically 8 M, which provides a single resonance, placed inside a small container ~1 mL. The most common recipe mixes 13C-urea in a 90% water/10% glycerol solution, with glycerol used to increase the urea solubility and doping with a Gd-based contrast agent to shorten T1 which increases the potential SNR per unit time. For example, when Dotarem is added at a 3:1000 volume ratio the 13C-urea T1 is around 500 ms and T2 is around 100 ms. However, when testing pulse sequences influenced by T1 and T2, doping should be used carefully. This phantom is suitable for frequency calibration, transmit gain calibration, sequence testing, and as a fiducial marker when placed next to a patient. However, enriched 13C-urea has a relatively high cost compared to natural abundance compounds.
For larger volumes (>100 ml), the phantoms most often used contain undiluted ethylene glycol, glycerol, or dimethyl silicone. These compounds have sufficiently high carbon concentrations to provide sufficient 13C signal even with the 1.1% natural abundance of 13C. These larger phantoms matching the inner volume of an RF coil are useful for coil testing, including transmit
+) And Receive (B1
-) coil profile mapping, as well as to mimic acquisitions using in vivo FOV requirements. In this case, size and conductivity should match the expected subject size in order to mimic coil loading and get a realistic estimation of B1+. Large-volume natural abundance urea phantoms have also been used by some sites, but suffer from higher conductivity compared to biological tissues. Typically, it is easier to increase the conductivity and hence coil loading of the non-conductive phantom by adding NaCl to match physiological loading (16,78).
Dynamic phantoms that aim to mimic metabolite kinetics have also been developed (79–81), and have the potential to more closely mimic the HP experiment, but so far these are not widely used.
Prescan Calibration
Prior to performing an MRI acquisition, the so-called prescan procedure is used to set the shim parameters to maximize B0 homogeneity over the field of view (FOV) or a specific region of interest (ROI), the scanner center frequency (CF), the RF transmit gain, and the receiver gain.
While this calibration procedure is usually automated for 1H, the lack of sufficient natural abundance 13C signal prevents use of automated methods. (Although natural abundance 13C lipid signal has been detected, there are so far no reports on using this signal for prescan.) Table 3 shows current practices across sites.
Maximizing B0 homogeneity is independent of the nucleus and is therefore performed prior to 13C imaging using the 1H water signal and existing shimming tools, such as by a standard automated process (“Auto Shimming”) or using high order shimming routines. Similarly, the 13C CF can be calculated from the 1H CF using a predetermined scaling factor that depends on the target chemical shift (82). Another common approach used is to have a small, high-concentration 13C phantom, e.g. 8M 13C-urea, integrated in the RF coil or placed next to the scan subject (1). The reference frequency can also be based on real-time measurements after the HP injection but prior to imaging (83). Both the CF and B0 shimming are critical when using spectrally-selective RF pulses, as inmetabolite-specific imaging methods, where the desired excitation bandwidths are typically very narrow and frequency offsets can lead to a failure mode that is only apparent after injection.
The calibration of the RF transmit power is typically performed on a small, high-concentration 13C phantom placed near the region of interest during the scan or on a large 13C phantom of similar size and coil loading as the subject, prior to the subject scan. Reference power is often done by sweeping the power in a pulse-acquire sequence (53,62), or the Bloch-Siegert method (52,84). When using a small phantom, the location of the phantom, B1
+ Inhomogeneity As Well
as any shielding effects, e.g., when the phantom is integrated into a coil (1), may degrade the accuracy. Other methods include real-time Bloch-Siegert method measurements after the HP injection (83), and using the stronger natural abundance 23Na signal that is close enough to the 13C resonance frequency to be detected by 13C coils (82).
The receiver gain is predetermined, either systematically based on independent phantom measurements and assuming the dose and polarization of the HP compound is known prior to injection, or based on past HP imaging studies.
Power [Kw]
Phantom(s) - during study Phantom(s) - before study 13C Frequency
8
13C-bicarbonate doped with dimethyl silicone, various
Power [Kw]
Phantom(s) - during study Phantom(s) - before study 13C Frequency
Maximum Values
Table 3: Summary of the imaging systems, phantoms, and prescan procedures used at sites currently performing HP 13C-pyruvate human studies. These were obtained from a survey of all sites performing clinical trials with HP [1-13C]pyruvate. *Previously performed studies with a Siemens 3T Tim Trio. The imaging systems, phantoms, and prescan procedures reported in the reviewed papers are shown in Supporting Table S1.
Summary
Commercially available 3T MRI systems are by far the most commonly used for human HP 13C-pyruvate studies, although a systematic investigation of the impact of B0 has only recently been investigated (73). The multi-nuclear RF transmit and receive chain has proven sufficient for current acquisition strategies, although many sites have observed artifacts due to RF interference, gradient interference, and residual eddy currents when operating at the 13C frequency. A variety of 13C RF coils, tailored for numerous anatomical targets, have been successfully demonstrated, with the main limitation that most transmit coils take up a lot of additional space inside the bore and provide relatively inhomogeneous B1
+ Profiles. The
phantoms used have converged into generally 2 categories - small phantoms containing 13C-enriched compounds that can be used during the study and human-sized phantoms containing compounds with high carbon concentrations but without 13C enrichment that are used to test and calibrate the coils. There are no standardized compositions or geometry, and dynamic phantoms that recapitulate in vivo kinetics would be desirable but are still an emerging area. Prescan calibration procedures were not well defined in most publications, so we surveyed individual sites to determine current practices. Calibration procedures for the B0 field (13C CF and shimming) for most sites take advantage of 1H signal and methods, while methods
For Calibration Of B1
+ is more variable across sites, likely a reflection of remaining challenges in how to perform this calibration. Standardization of both phantoms and calibration procedures would synergistically improve the robustness and reproducibility of HP 13C studies.
Acquisition And Reconstruction
Data acquisition strategies in human HP [1-13C]pyruvate MRI studies must account for multiple chemical shifts, efficiently utilize the non-renewable HP magnetization, and acquire data quickly relative to metabolism and relaxation decay processes. These studies require spectral encoding to separate metabolites, necessitating pulse sequences that efficiently encode up to 5D data (3 spatial + 1 spectral + 1 temporal dimension). RF pulses must efficiently sample without immediately saturating the non-renewable HP magnetization, and sequences must acquire data quickly and be robust to both experimental and physiologic variation (e.g. B1
+ Inhomogeneity,
variation in perfusion) to ensure reproducibility and minimize scan-to-scan variability. This section covers current successful practices for data acquisition in human [1-13C]pyruvate studies, and accompanying 1H imaging, from different anatomic regions, including scan parameters and image reconstruction.
Acquisition And Reconstruction Methods
The acquisition methods used in human [1-13C]pyruvate studies can be classified into 3 categories: 1) MR spectroscopy or MR spectroscopic imaging (“MRS/I”), 2) chemical shift encoding methods, and 3) metabolite-specific imaging (Fig. 5).
Mrs/I Methods Specifically
resolve a spectrum that can be analyzed to extract expected as well as unexpected resonances, making this approach very robust. It was used in many initial studies (1).
Chemical Shift
encoding methods, most commonly the Iterative Decomposition of water and fat with Echo Asymmetry and Least-squares estimation (IDEAL) method, use imaging sequences acquired with multiple TEs and rely on a model-based separation of expected chemical shifts (85).
Metabolite-specific imaging methods use specialized RF pulses that are spatially and spectrally selective to excite individual metabolites which are then typically imaged with fast k-space trajectories such as echo planar imaging (EPI) or spirals (86).
Their Application To Different
organ systems is described below. The image reconstruction methods used in human [1-13C]pyruvate studies have typically been conventional methods (e.g. FFT, non-uniform FFT, or equivalent). The incorporation of accelerated imaging and advanced reconstruction methods including parallel imaging (4,57,87) and compressed sensing (7) has also been applied in human studies for improved spatial resolution, temporal resolution and coverage, but have the potential for additional artifacts as well as SNR losses due to ill-conditioning of the reconstruction (e.g. g-factor).
The Majority Of
published studies do not use accelerated imaging indicating the resolution and coverage achievable without acceleration is currently adequate for successful data collection. Performing coil combination, even with fully sampled data has also been shown to have specific challenges for HP human images: using naive sum-of-squares methods suffer from high noise amplification in the relatively low SNR regime of HP [1-13C]pyruvate (compared to 1H), motivating several HP 13C-specific methods that include data-driven coil sensitivity estimation which have shown obvious improvements over sum-of-squares (11).
More recently denoising techniques have been applied as post-processing of human HP data(41,42,44). The techniques applied are based on spatial-temporal singular value decomposition for unsupervised estimation of signal and noise components. They have shown improvements in apparent SNR in the brain and liver, while care must be taken to choose parameters such as the rank threshold to avoid oversmoothing and overfitting to the estimated signal components.
Prostate Studies
Prostate cancer was the first human application of HP [1-13C]pyruvate (1), and data was acquired with MRS/I methods: 1D dynamic MRS, single-slice 2D dynamic echo-planar spectroscopic imaging (EPSI), and single time point 3D EPSI. Advances in imaging strategies led to the development and application of new acquisition schemes, including undersampled 3D EPSI with compressed-sensing (7), model-based chemical shift encoding methods that use a priori information (47,59), and metabolite-specific EPI (10), all of which can provide volumetric whole-organ coverage and dynamic acquisitions.
The pyruvate bolus arrival in the prostate can vary by ± 10 s between patients, necessitating dynamic imaging to reliably and consistently capture the pyruvate bolus (18). For this reason, all currently ongoing studies acquire dynamic data. While MRS/I, chemical shift encoding, and metabolite-specific imaging can all achieve dynamic imaging, chemical shift encoding and metabolite-specific imaging provide greater dynamic and volumetric coverage (85). For scan prescriptions, the FOV is designed to provide full prostate coverage and typically to match the orientation of the anatomic imaging used for registration. Flip angles used in current studies are constant through time, as quantification with a variable-through-time flip scheme is highly sensitive to bolus timing (8) and errors in the RF transmit (B1 +) field (76).
Heart Studies
Data acquisition methods for 13C imaging in the heart must be designed to meet the demands of significant cardiac motion and blood flow. To cope with the periodic cardiac motion, most human heart studies to date used gating to the diastolic window, the longest cardiac cycle interval, which has reduced motion (2,22,28,30,35,36,38,45,52). The duration of the diastolic window limits the available data sampling time, making cardiac acquisitions the most time-constrained of the HP 13C MRI applications. The most common acquisition approach is metabolite-specific imaging with spiral k-space trajectories (2). Their single-shot imaging capability makes these methods particularly robust to motion effects. Furthermore, spiral k-space trajectories provide rapid k-space coverage and relatively benign flow and motion artifacts. The majority of studies have used 2D multi-slice acquisitions, but 3D encoding has also been used successfully (35).
Brain Studies
For HP 13C MRI of the human brain, the majority of studies have also used 2D (slice selective) acquisitions (10–12,14,16,28,33,40,41,44,51,53,60), with a trend toward volumetric coverage using 2D multi-slice metabolite-specific imaging. 3D metabolite-specific imaging of the whole brain, with phase encoding of the slice direction (34,57), has been shown to provide similar SNR efficiency (88) compared with multislice imaging. A number of studies have employed MRS/I (5,6,29,31–33,50,55) resulting in a spectrum from each voxel, which has the advantage of not requiring a priori information about which peaks to encode. This was important in early brain studies when it was not known which peaks would be detectable. Chemical shift encoding, using a set of images with different echo times and an iterative reconstruction of the individual resonances (i.e. the IDEAL approach (85)), has also been used (12,49,54), with the drawback that coverage in the slice direction was limited due to the time required to acquire multiple echo time images.
Abdomen And Breast Studies
The fundamental approaches to data acquisition and reconstruction in the abdomen and breast are largely similar to the aforementioned applications, but demand attention to particular challenges associated with these anatomic regions, especially relating to respiratory motion.
Although it has been shown that a basic 2D MRSI approach based on phase encoding and FID readout can be successfully applied for HP 13C imaging in breast (15) and kidney (13), major advantages in terms of spatiotemporal resolution and coverage have been realized using tailored approaches based on metabolite-specific imaging (43,62) and chemical shift encoding (43), which have facilitated multi-slice or 3D dynamic acquisitions over large FOVs in the abdomen (4,37,46).
The significant respiratory motion encountered in these regions can directly blur 13C images, and has further favored these rapid acquisition strategies. Motion also degrades B0 homogeneity, which can shift frequency-selective excitation profiles and introduce artifacts into rapid imaging readouts. This makes accurate determination of the acquisition center frequency and shimming essential in these regions which often cover large FOVs. (See “Prescan Calibration” section for more information). In some studies, breath-holding was used to minimize motion effects and enforce frame-to-frame data consistency (42). A pragmatic and reasonably effective approach for dealing with respiratory motion during 13C data acquisition is an initial breath-hold (as long as can be tolerated), followed by free-breathing (46,62).
1H Imaging
Collection of 1H imaging data is essential both for prescribing the 13C acquisition and for interpretation of the resulting 13C data. Multi-planar 1H scouts are acquired prior to 13C acquisition to enable graphical prescription of the 13C imaging region. All human HP 13C-pyruvate imaging studies acquire conventional MRI scans (e.g. T1- and T2-weighted volumes) for anatomic reference, aiming to cover at least the full 13C FOV. Acquiring these anatomic scans as close as possible to the time of 13C imaging (immediately before or after) minimizes potential misregistration between the data sets. Depending on the application, other advanced 1H sequences are also acquired (e.g. diffusion-weighted imaging for cancer imaging).
When contrast-enhanced data is acquired, it is done after 13C imaging, as paramagnetic contrast agents will accelerate 13C relaxation.
Reported Study Parameters
Figures 5 and 6, and Supporting Table S2 shows the reported acquisition study parameters for human HP [1-13C]pyruvate studies published as of September 2022. Figure 5 shows a mixture of MRS/I, metabolite-specific imaging, and chemical shift encoding methods have been successfully used, where spectroscopy-based methods have become less prevalent in recent studies. Figure 6 shows the acquisition timing, including the important start time and interval/temporal resolution, is quite variable across studies.
Figure 5: Acquisition methods used in published HP [1-13C]pyruvate human studies published up to September 2022, classified into: MR spectroscopy and spectroscopy imaging (MRS/I); chemical shift encoding methods, such as IDEAL, that use multiple TEs and model-based reconstructions; and metabolite-specific imaging methods that use spectrally-selective excitation to image a single resonance at a time.
Figure 6: Temporal acquisition characteristics reported in HP [1-13C]pyruvate human studies published up to September 2022. (a) Reported referencing of acquisition start times.
(B)
Acquisition start times reported when using dynamic imaging and when timing was reported relative to the end of the injection. (c) Temporal resolutions. “Not Applicable” indicates dynamic imaging was not used.
Summary
Three general categories of acquisition strategies have been used successfully for human HP 13C-pyruvate studies: MRS/I, model-based chemical shift encoding (e.g. IDEAL) methods, and metabolite-specific imaging methods. These have enabled successful studies in the prostate, heart, brain, abdomen, and breast. Recent studies increasingly have used the imaging-based strategies of metabolite-specific imaging and chemical shift encoding which are the fastest methods, although a heads-to–head comparison between techniques has not been performed.
Metabolite-specific imaging is quite popular because of its speed and compatibility with single-shot imaging, but is sensitive to B0 field variations and thus requires careful calibrations. Nearly all studies surveyed acquired data dynamically, allowing measurement of the bolus and metabolite kinetics. The exact timings and associated flip angles vary quite widely across reported studies, with no consensus yet as to how to choose these parameters. Image reconstruction is typically done directly using Fourier Transform methods, and accelerated imaging strategies are uncommon.
Data Analysis And Quantification
This section covers the analysis of data from human HP [1-13C]pyruvate studies, including modeling and metrics, visualization, as well as considerations for how to store data and metadata. Depending on study design, the analysis may need to give quantitative or semi-quantitative output reflecting a biological process or may just reflect a contrast between different regions of interest for quantitative evaluation.
Metrics
Figure 7: HP [1-13C]pyruvate raw data (A) have typically been quantified using four categories of metrics depending on the acquisition. Data acquired as a single time point are often quantified using normalized metabolite images or metabolite ratios (B). Dynamic data can be quantified using normalized metabolite images or metabolite ratios (B), or with metabolite timings such as time-to-peak (TTP) or pharmacokinetic (PK) models (C). The latter two require the data to be time-resolved. [1-13C]alanine and 13C-bicarbonate are analyzed similarly to [1-13C]lactate but omitted here for display.
Metabolite images are commonly used as summary metrics for HP MRI data, often including some form of normalization as well as summed over time as an area under the time curve (AUC) (17). These are analogous to the visual evaluation that is most used for routine clinical work (89,90). In these metabolite images, we expect that the [1-13C]pyruvate AUC signal is predominantly weighted towards perfusion and uptake, while [1-13C]lactate, [1-13C]alanine and 13C-bicarbonate AUCs represent metabolic conversion. The strength of this approach lies in its simplicity and relatively few underlying assumptions. Limitations to the use of single-metabolite images or AUCs include sensitivity to inhomogeneous coil profiles (57,87,91), the acquisition strategy and acquisition parameters, pyruvate polarization and concentration level, and signal relaxation rates (92). Further, the reader must be careful to interpret all the images in conjunction to better understand the underlying biology; for example, increased [1-13C]lactate in the presence of decreased [1-13C]pyruvate delivery can have a very different meaning compared to increased [1-13C]lactate with increased [1-13C]pyruvate delivery.
In an attempt to address variations in coil sensitivity, polarization level, and pyruvate delivery, AUC images are often computed by normalizing to a specified parameter, such as the maximum pyruvate or average lactate signals, or presented as a ratio such as lactate/pyruvate or divided by “total Carbon” - the sum total of HP 13C signal observed across all metabolites. The AUC ratios between metabolites and pyruvate are proportional to the corresponding forward kinetic rates (81,93), but are not directly comparable to rate constants when magnetization loss rates (e.g. relaxation and losses due to signal excitation) differ between studies. Similarly, the ratios between the produced metabolites (e.g. bicarbonate/lactate) can reflect the balance between downstream metabolic pathways (12,55). Care must be taken to consider how AUC images are calculated and normalized before comparing values between studies.
To further quantify the interpretation, pharmacokinetic (PK) modeling approaches were developed to compute the apparent kinetics of pyruvate-to-metabolite exchange (92,94–99). These yield semi-quantitative to quantitative apparent rate constants, given in s-1. Some models require a vascular input function, while others avoid this requirement (95). PK models can explicitly account for acquisition-specific details such as excitation angle and repetition time, and thus may reduce the effects of these details on quantification. An input-less model, provided in the Hyperpolarized-MRI-Toolbox (https://github.com/LarsonLab/hyperpolarized-mri-toolbox) (100) and thus frequently employed for human data, has been shown to fit well and robustly to prostate and brain data (8,20). PK models are quantitative in nature, arguably provide more relevant biological information (8,20), and appear to be reproducible across sites (51). However, rate constants derived from PK models are still apparent rates, and likely do not reflect a single biological characteristic.
Some additional considerations include whether complex or magnitude data is used, as the noise behaviors will impact the analysis differently. Additionally, cut-off thresholds or other criteria may be used to identify and avoid voxels with insufficient SNR before analysis to improve robustness (20,41).
Regardless of the analysis approach, the underlying biology is not always clearly represented by the data; instead, the metrics may be influenced by perfusion, barrier permeability, intercellular shuttles, enzyme activities, co-substrate concentrations, or combinations thereof, depending on the organ and disease of interest (19,43,94,101–103). This may be addressed by incorporating complementary information. As an example, HP 13C pyruvate data is influenced by perfusion, and thus addition of perfusion MRI could be important for interpretation (98,104,105).
All the methods outlined above have been explored in clinical studies, described in Supporting Table 3 and summarized in Figure 8. As of September 2022, approximately 52% of studies involving human subjects report rate constants derived from a PK model with a few different models reported. A nearly equal fraction (51%) of the studies report AUC ratio values.
Approximately 66% of these studies report metabolite-specific images or AUC values. About 40% report SNR values; this metric is particularly frequent in manuscripts that describe technical developments for clinical HP MRI. Approximately 16% of these studies summarize model-free metrics, and 10% report measurements from a single timepoint. Most studies report a combination of quantities.
Figure 8: Reported metrics used for analysis in HP [1-13C]pyruvate human studies published up to September 2022.
Visualization
A wide variety of approaches have been used for visualizing data from human HP 13C-MRI studies. The challenges and practical considerations are: 1) choosing the appropriate metrics to display, 2) how to encode the parameters (e.g. the colormap), and 3) choosing how to provide anatomical context and other multi-parametric data. The choice of visualization also depends on the goal which could be for diagnostic interpretation, but also quality control, reproducibility among readers and publication.
Metrics
The choice of HP 13C metrics is described in detail above. At this stage in HP 13C development where there is no standardized metric, often a combination of metabolite images and ratios or PK model parameters are shown.
Parameter Encoding
The mapping function chosen should provide an adequate, often quantitative, impression of the parameter mapped. There is a consensus in the visualization field that perceptually uniform maps are best suited to visualize continuous parameters, like the greyscale typically used by radiologists as well as other monochrome (black to blue) and color ranges (fire-type, rainbow-type) (106,107). Multi-color heatmaps have been the most frequently employed method for HP 13C data, while greyscale has infrequently been used but it ensures there is no coloring-based bias as well as facilitating later reuse (Fig. 9a). Among the color schemes employed in the clinical HP 13C literature, fire-type scheme seems to be the most common [similar to “Plasma” or “Inferno” in matplotlib.org]. Next most commonly employed is the rainbow-type scheme [similar to “Rainbow” in matplotlib.org].
Anatomical Context
HP MRI faces the challenge that it does not necessarily depict the anatomical features, similar to PET, and thus requires an anatomical reference. Most often, a grayscale anatomical image is overlaid with a HP colormap (Fig. 9c,d). This approach is very intuitive, but can skew perception as the grey-scale anatomical reference may affect the brightness of the HP data (e.g. signal in the skull). This bias does not occur when showing adjacent maps (Fig. 9a, b). Here, anatomical outlines may help to provide reference (Fig. 9b).
Related Journal Articles & DOI Links
Selected peer-reviewed publications relevant to 12 Lead ECG Acquisition. Click the DOI to access the full paper (may require institutional access).
-
1. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
IEEE Journal of Biomedical and Health Informatics
https://doi.org/10.1109/JBHI.2020.2981234 -
2. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Medical & Biological Engineering & Computing
https://doi.org/10.1007/s11517-020-02145-6 -
3. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
IEEE Transactions on Biomedical Engineering
https://doi.org/10.1109/TBME.2019.2895762 -
4. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Frontiers in Bioengineering and Biotechnology
https://doi.org/10.3389/fbioe.2020.00123 -
5. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Biosensors and Bioelectronics
https://doi.org/10.1016/j.bios.2021.112345 -
6. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
Computers in Biology and Medicine
https://doi.org/10.1016/j.compbiomed.2021.104567 -
7. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Nature Communications
https://doi.org/10.1038/s41467-020-12345-6
Why Choose Us?
Bangalore guidance for robotics, Spectre and autonomous systems projects.
Spectre & Simulation
Gazebo, cloud twin and Webots worlds with navigation, SLAM and control stacks.
Control & Planning
Compliance, deep learning control, path planning and behavior trees.
Hardware Bring-up
Motors, sensors, ESP32/STM32 firmware and HIL validation paths.
Report & Viva
University-format documentation, PPT and viva preparation.
FAQ
CFD Lab — Bangalore
Simulation, control and hardware support for final-year robotics projects.
Stacks
Worlds
Digital Twin
Control
Robots
Offline
Bring-up