International Journal of Electrical and Computer Engineering (IJECE)
1488
Journal homepage: http://iaescore.com/journals/index.php/IJECE Phase-Shifted Full-Bridge Zero Voltage Switching DC-DC Converter Design with MATLAB/Simulink Implementation Oladimeji Ibrahim1, Nor Zaihar Yahaya2, Nordin Saad3
Accepted Mar 30, 2018
Design of phase-shifted full bridge zero voltage switching DC-DC converter has been very challenging due to circuit parasitic effect on the system dynamics. This paper presents steady-state analysis and iterative approach for the systemic design of phase-shifted full bridge DC-DC converter with improved dynamic performance and satisfactory operational requirement in terms of zero-voltage switching range, operating switching frequency and switching resonance. A 3 kW DC-DC converter is designed using the iterative design approach and the system dynamics performance was investigated in the MATLAB/Simulink environment. The converter zero- voltage switching simulation results were satisfactory with 90% efficiency under full load condition.
Zero Voltage Switching
Copyright © 2018 Institute of Advanced Engineering and Science. All rights reserved.
Universiti Teknologi Petronas,
32610 Bandar Seri Iskandar, Perak, Malaysia. 1.
Introduction
Phase-shifted full-bridge (PS-FB) DC-DC converter is widely used in high power application due to the advantage of high power handling capability , . The conventional full-bridge converter has issues of ringing effect, circulating current, high switching and conduction losses but easily eliminated by employing phase-shifted PWM switching control that allows FET device zero voltage switching (ZVS) . The switching control operation ensures that the converter transformer is connected to the source or shorted for continuous circuit current flow thereby limiting current ringing that might result from transformer leakage inductance. Smooth operation and improved dynamic performance of PS-FB ZVS DC-DC converter require the right choice of component value due to nonlinear operating nature and interdependency of circuit elements. This makes the analytical design of PS-FB ZVS DC-DC converter quite different from other conventional PWM converters. The components are chosen to precision in order to ensure that the circuit parasitics like the transformer leakage inductance, FET device output capacitance and transformer turn ratio are used to the system advantage for improved system dynamics.
The phase-shifted full-bridge ZVS DC-DC converter design, analysis and implementation have been presented in several literatures -. Efforts are being made on efficient circuit design to address most of the prevailing challenges like the loss of ZVS under light load condition, high voltage spike at secondary output rectifier, duty cycle loss, high circulating current and electromagnetic interference. The proffered solutions are mostly based on circuit topology and control techniques modification . Most of the recent proposed modify topologies require auxiliary components to increase the resonant inductance energy for wider ZVS. Addition of auxiliary component like magnetic inductor is presented in , transformer design modification in and the addition of passive-active component like capacitors and diode in for
Phase-Shifted Full-Bridge Zero Voltage Switching DC-DC Converter Design ... (Oladimeji Ibrahim)
1489
extending the converter ZVS range. Adding auxiliary component has successfully extended PS-FB converter ZVS range but at the expense of voltage ringing and circulating current resulting in high conduction loss. The other trade-off among these solutions are cost and components part increase, increase size and weight, and the implementation complexity. To this effect, switching control scheme was proposed to reduce the switching losses under light load condition when ZVS is lost by the converter lagging leg. The popular control methods include pulse skip mode and a burst mode that mask some of the PWM periods as presented in , .
This paper presents a systemic approach based on an iterative method for designing PS-FB ZVS DC-DC converter to optimize converter circuit parasitic for achieving improved dynamic performance. A 3 kW 100 kHz high-frequency converter is designed and zero-voltage switching performance investigated in MATLAB/Simulink environment. The simulation results show that the system performed satisfactorily over the design load range with 90% full load efficiency.
2.
Steady-State Analysis Of Ps-Fb Zvs Dc-Dc Converter
Phase-shifted full bridge ZVS PWM converter is an isolated DC-DC converter with two power conversion stages; the primary DC-AC with a high-frequency isolation transformer and the AC-DC full-wave rectifier providing regulated DC output voltage. The PWM switching control signal offers the advantage of switching all the FET device with ZVS using the junction capacitance and transformer leakage inductance energy. The topology of a full bridge converter is presented in Figure 1 has a leading leg with pair switches
2
S turned on complimentarily with 50 % duty cycle minus short dead time and same for the lagging leg
4
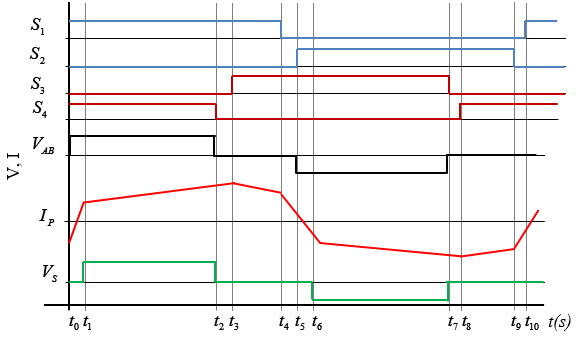
S . The PWM gating switching control signal to the H-bridge inverter lagging leg is phase shifted with respect to the leading leg as presented in Figure 2.
1490
The voltage gain of ZVS PWM phase-shifted full bridge converter is expressed as:
(1)
The duty cycle available at the secondary side of the converter is lower than the primary due to finite slope in the rising and falling edges of the primary current as depicted in Figure 2. The current flow through the leakage inductance does not change instantaneously, the rising and falling edge of the primary current reduces the effective duty cycle available at the transformer secondary side by
. The Primary
duty cycle D set by the control circuit is given by:
D
-is the effective duty cycle of transformer secondary voltage and
Is The Duty Cycle Loss Due To
finite slope during rising and falling edges of the primary current. In order to achieve H-bridge inverter ZVS during operation, the leakage inductance energy (
E
must be equal or greater than the total capacitive energy of the FET output capacitance and that of the
E
. The zero-voltage switching in leading leg with pair switches
S
depends only on leakage inductance energy and the total inductive energy available for ZVS is given by (3):
4
S , the total energy available for ZVS comprised of
Are
magnetizing inductance and current respectively. The resonance of FET devices switching transition in each pair leg of the H-bridge inverter requires
Dt
to complete the zero-voltage switching transition. The dead-time allows the charging and discharging of the FET (MOSFETs) output capacitance depending on the resonant circuit parameters. The resonant frequency for achieving ZVS in all the four switches is similar and given in (5) .

To maintain ZVS, minimum dead time for switching commutation must meet the condition in (6).
(6)
The lagging leg switches would easily achieve the ZVS throughout loading conditions because there is sufficient energy from leakage inductor and output filter inductor for switching. Leading leg ZVS only depend on the transformer leakage inductance energy based on reflected load current which may not be
1491
sufficient under light load to achieve the ZVS. The critical current
Which Is The Minimum Load Current
requires to maintain leading leg ZVS is given by (7) .
C
is FET energy stored in the nonlinear drain to source output capacitance, while the ratio 4/3 is the 2 times the
C
energy. If assumed that the energy stored in the drain to source output capacitance of FET device is linear and the critical current is known, then the critical current
(8)
The required leakage inductance value for the ZVS range with critical current
(9)
3.
Design And Simulink Model Of Ps-Fb Zvs Dc-Dc Converter
This section presents a summary of steps for designing PS-FB ZVS DC-DC converter with the iterative method and the MATLAB/Simulink implementation of a 3-kW converter as a case study.
3.1. Ps-Fb Zvs Dc-Dc Converter Design
The two main analytical methods for designing PS-FB ZVS DC-DC converter are the iterative and exhaustive search methods . The PS-FB ZVS DC-DC converter iterative design method ensures that the circuit parameters such as transformer turn ratio, the leakage inductance, the switching frequency and maximum duty cycle are optimized after series of design iterations. The summary of the procedural steps involved in obtaining optimal circuit parameters for converter smooth operation are provided as follows .

D
is chosen to be as large as possible to maximize the transformer turn ratio
V
is chosen to be low such that the voltage stress on the secondary
condition.
I
that determines the ZVS range is then calculated.
Lk
L required for ZVS is calculated using the total switching device and transformer parasitics.
(10)
In this work, a 3 kW rating PS-FB ZVS DC-DC converter is developed based on iterative design technique with ZVS range between 40 % load current to full load. The isolated transformer step-up the 48 V nominal supply to 400 V DC before the output rectification. The converter operates in continues conduction mode (CCM) and the output current ripple is designed for 1.5A. The regulated output voltage is suitable for the DC-AC conversion to a 230V AC to serve local load or grid connection.

D
is chosen as 0.84 and a ferrite material with low saturation flux density was considered for the transformer magnetic core having a maximum magnetic flux Bmax of 0.2 T (2000G) and
C
A of 1.5 cm2. The number of the primary side turns
N Is Calculated Using (11) And A 5-Turn
ratio is chosen for the primary turn (Np). The converter operating supply voltage is between 36 V-60 V with
1492
48 V nominal. The number of transformer secondary turns (Ns) is calculated by (12) using the minimum input voltage and 70-turns was obtained for the transformer secondary side , , .
(12)
3.2. PS-FB ZVS DC-DC converter MATLAB/Simulink model MATLAB/Simulink model of the PS-FB ZVS DC-DC converter is presented in Figure 3 showing the H-bridge inverter, high-frequency transformer, full wave rectifier and the output filter. The H-bridge inverter has pair MOSFETs on each leg for converting the DC supply voltage to a chopped AC that serves the high-frequency transformer. The switching frequency is 100-kHz to reduce the transformer size for high power density. The MOSFET block has inbuilt parasitic that exhibits switching characteristics closed to the real-FET device. The N-Channel SuperFET FCH043N60 MOSFET is selected with 730 pF effective output
R
and all the parameters were configured within the Simulink. The high-frequency transformer is configured for 1:14 turn ratio as obtained from the design and the full bridge rectifier converts the transformer secondary voltage to 400 V DC voltage before the LC-output filter stage. The load is modelled as resistor while the output inductor ripple current is specified as 20 % of load current and the obtained filter inductor is 466 µH. Also, output voltage ripple current is specified as 1 % of the output voltage and the output filter capacitor is 1.47 µF.

Figure 3. MATLAB/Simulink model of PS-FB ZVS DC-DC converter 4.
Results And Analysis
The PS-FB ZVS DC-DC converter design parameters and the system dynamic performance results for various loading conditions investigated in MATLAB/Simulink environment are presented in this section.
4.1. Converter Parameters And Dpwm Scheme
Three design iterations were carried out to obtain the converter optimized circuit parameter. The secondary voltage was first chosen as 500 V and the critical load current as 40 % (3 A) of the average full
Deployment In Out-Of-Position Situations
D. Bendjaballah1, A. Bouchoucha1, M. L. Sahli1,2* and J-C. Gelin2
Abstract
Side-impact collisions represent the second greatest cause of fatality in motor vehicle accidents. Side-impact airbags have been installed in recent model year vehicle due to its effectiveness in reducing passengers’ injuries and fatality rates. In meeting these requirements, simulations of folding and deploying airbags are very useful and are widely used. The paper presents a simulation method for the deploying airbags using three materials in different working conditions. Finite element analysis is primarily used to evaluate this concept. In these simulations, the gas flow is described by the conservation laws of mass, momentum, and energy. The numerical results indicate that the FE method in this paper is capable of capturing airbag deploying process accurately.

Keywords: Airbag simulations, Out-of-position, Crash, Modeling, Out-of-position
Background
The passive safety of cars has become a very high prior- ity issue for the automotive industry. Today, there are not only one or two airbags in a car; certain models have ten times more than that. With the increasing usage of airbags, the number of accidents where the airbag itself can cause an injury to the occupant also increases
(Augenstein Et Al. 2003; Gabauer And Gabler 2010;
Audrey et al. 2011). As is well known, safety belts are also now devices designed to provide protection to the users of vehicles during crash events, minimizing the loads necessary to adapt their movement to the move- ment of the car (Freesmeier and Butler 1999; Schmitt et al. 1997). In general, the seat belt is designed to restrain the occupant in the vehicle and prevent the
Occupant From Having Harsh Contacts With Interior
surfaces of the vehicles. The airbag acts to cushion any impact with vehicle structure and has positive internal pressure, which can exert distributed restraining forces over the head and face. As a safety component of auto- mobile, an airbag decreases occupants’ injury likelihood effectively in case of an accident (Ruff et al. 2007). These safety elements can reduce the death rates on the roads, and its protection effects have been widely approved (Crandall et al. 2001; Teru and Ishikawa 2003). With computational tools such as finite element methods designed for dynamic contact problems, crashworthiness simulations can now be used with reliable accuracy to evaluate occupant protection in various collision condi- tions with safety metric/parameters such as acceleration, head injury criteria, intrusion distance, intrusion vel- ocity, and neck forces (neck injury risk or whiplash).

Thus, new types of airbag products are being developed to handle different collision scenarios.
Become Standard Equipment On Most New Passenger
vehicles (Braver and Kyrychenko 2004; Teng et al. 2007; Yoganandan et al. 2007). The airbag cushion is com- posed of a woven fabric which is rapidly inflated during a car crash. The airbag dissipates the passenger’s kinetic energy thereby reducing injury through biaxial stretching of the fabric bag and escaping gas through vents. There- fore, the performance of the airbag is greatly influenced by the mechanical properties of the fabric. Generally, air bags are designed to deploy in a crash that is equivalent to a vehicle crashing into a solid wall at 8 to 14 mph.
Air bags most often deploy when a vehicle collides with another vehicle or with a solid object like a tree. There are various types of airbags: frontal, side-impact, and curtain airbags. In general, the passenger side airbags are usually larger than the driver airbags (see Fig. 1).

Besançon, France
© The Author(s). 2017 Open Access This article is distributed under the terms of the Creative Commons Attribution 4.0 International License (http://creativecommons.org/licenses/by/4.0/), which permits unrestricted use, distribution, and reproduction in any medium, provided you give appropriate credit to the original author(s) and the source, provide a link to the Creative Commons license, and indicate if changes were made.

Bendjaballah et al. International Journal of Mechanical
Doi 10.1186/S40712-016-0070-2
Extensive studies have shown that the airbag deploy- ment in load cases consists of two occupant loading phases: a punch-out effect where the airbag bursts out of its container with the airbag and airbag module cover accelerating towards the occupant and a second loading phase during which the airbag is taking on its deployed shape and volume (membrane-loading effect). Bankdak et al. (2002) developed an experimental airbag test system to study airbag-occupant interactions during close proximity deployment. The results provided insight for simulating the effect of inflation energy and mass flow on target response. Bedard et al. (2002) found that while left-side (driver-side) impacts accounted for only 13.5% of all crashes, the fatality rate among these
Crashes Was 68.3% In Comparison To Front Impact
(48.3%), right-side impact (31.3%), and rear impact (38.4%). These studies underscore the importance of oc- cupant safety during side-impact collisions. In the last years, the current market requested to reduce the time and cost airbag development. In order to achieve this result, virtual simulations play an important role since they allow to minimize the number of experimental tests (Pei et al. 2013; Cao et al. 2014). Several simulation models of airbag were established (Wang et al. 2007). It is feasible to optimize the parameters of airbag deploy- ment using simulation technology. Experimental and numerical studies have quantified injury risks to close- proximity occupants from deploying side airbags. These studies have focused on the prevention of the most ad- verse effects of airbag deployment (Duma et al. 2003).
Other studies have proposed airbag characteristics to minimize particular biomechanical responses (Haland and Pipkorn 1996). In a more recent study, Marklund and Nilsson (2003) compared deformation patterns with experimental data as well as the computational costs associated with three different airbag deployment simu- lation methods; they concluded that the SPH method is relatively inexpensive and produces incremental deform- ation patterns that compare most closely to the experi- mental results. The process of inflation of an airbag is one of the determining factors in saving lives. The duration from the initial impact of the crash to the full inflation of an airbag is about 40 ms, and during this time, the airbag goes from being in a folded state to a fully inflated state, with a high internal pressure. After achieving this state, the airbag begins to deflate, thus providing a nice cushion for the body impacting it.
Ideally, the person in the crash should come into contact with the airbag at this time. In the present study, a large volume passenger side airbag model is developed to handle different collision scenarios. The main aim is evaluate the performance of deploying of passenger side airbag using finite element methods (FEM).
Materials
The tensile specimens were made in different airbags (P: Peugeot, R: Renault, and VW: Volkswagen) with a length of 200 mm long and a width of 40 mm. Table 1 shows the mechanical properties of the airbag.
Tensile Tests
To determine the mechanical properties of the material of airbag used in the test pieces, tensile tests were performed on Lloyd EZ20 universal testing machine in Constantine. These tests were conducted using rect- angular samples. The axial force and axial displacement acquired during a test are converted into stress and the strain in order to be used for the fabric material model.
The continuous recording of the stress-strain data was performed during both the load and unload phases. A minimum of five samples were made in order to check the repeatability of the measurements. All the data was collected by using a PC-based data acquisition system and analyzed by commercial software. The picture frame test device that is made for this study is shown in Fig. 2.
Fig. 1 a Frontal and side airbags. b Oblique view of facet occupant model in sitting posture following airbag deployment (Lim et al. 2014)
0.150
Bendjaballah et al. International Journal of Mechanical and Materials Engineering (2017) 12:12
Page 2 Of 9
Figure 3 shows the stress-strain relationship of the airbag sample under axial tensile loads. The results are showing a linear increase in extension with the increas- ing stresses. This is an expected output and it confirms with the theoretical behavior of a sample subjected to tensile stress. The rupture strain values for different airbags (R/P/VW) were 0.322, 0.441, and 0.472, respect- ively. The measured elastic parameters (i.e., Young’s modulus E and initial yield strength) and Poisson’s ratio are summarized in Table 2. The tensile tests of the woven fabrics can show differences on mechanical prop- erties because woven fabrics can resist in-plane shear loads once the yarn lock-up angle has been reached. The differences of material property on material direction can affect the shape of fully deployed bag (see Fig. 3b).
Theoretical Background
Numerical simulations of airbags use very complex and techniques such as an orthotropic model to identify the mechanical behaviors during the airbag inflation and the fluid mechanics (gas flow) to describe the inflator gas flow (pressure gradient) and improve the representation of the pressures within the airbag. To model the airbag as an orthotropic model, three material constants have to be provided. Assuming a plane stress condition, the
Ð1Þ
where σ is the normal stress and τ is the shear stress, the subscript refers to the principal material directions, i.e., the fill and warp directions. Also, ε and γ are the strain components. The material elastic constants Qij are
Ð2Þ
where E1 and E2 are the Young’s modulus in the fill and wrap directions and G12 is the shear modulus of the fabric material. νij is the Poisson ratio of the material.
The gas exerts a pressure load on the airbag causing it to expand. This expansion puts the airbag under tensile stress lowering the expansion rate. In this study, heat conduction and heat transfer is not taken into account.
Fig. 2 A photograph of Lloyd EZ20 universal testing Fig. 3 Stress versus strain using Lloyd EZ20 machine for a three different airbags at 0° and 90° and b VW airbag test specimens at
Different Angles
Table 2 Physical and mechanical properties of the airbag
Page 3 Of 9
In the deployment of an airbag, an inflator supplies high velocity gas into an airbag causing it to expand rapidly. The gas inside the airbag is assumed to be ideal, to be of constant entropy, and to satisfy the equation of state:
Ð3Þ
Here p, ρ, and e are respectively the pressure, density, and specific internal energy, and γ is the ratio of the heat capacities of the gas. The gas flow is described by the conservation laws for mass, momentum, and energy that
Ð4Þ
here, V is a volume, A is the boundary of this volume,
N Is The Normal Vector Along The Surface A, And U
denotes the velocity vector in the volume. Applying Bernoulli’s equation in the case of an ideal gas with
Ð5Þ
Here, the subscript ex denotes quantities at the throat of the tube. Furthermore u, p, and ρ denote the quan- tities inside that part of the tube that is supplying mass.
Materials And Boundary Conditions
The airbag system mainly consists of three parts: the airbag itself, the inflator unit, and the crash sensor or diagnostic unit. Thus, to study the behavior of the airbag using FE simulations, we need to have an FE model of the airbag in the folded position. A FE model of the airbag was used to simulate the test condition as shown in Fig. 5. LS-DYNA® material model FABRIC (MAT_34) is used to simulate the airbag material. It is a variation of the layered orthotropic material model. Additionally, in the LS-DYNA® material model, fabric leakage can be accounted for. However, for this CAB material, the leak- age is almost negligible and therefore no leakage is specified. The mechanical properties can be determined from the physical test. Typical material properties for airbag fabrics are taken as given in Chawla et al. (2004a) (Table 3). These properties are used to simulate inflation process of airbag (see Table 1). The car dashboard is modeled as the rectangular thin plate using a MAT_RI-
Gid Material, And The Degrees Of Freedom Are Con-
strained in all the directions. The similar properties of thermoplastic polymer are assigned for contact purposes. The porosity of the fabric is assumed zero. The nitro- gen gas is taken for inflating the airbag. Properties of nitrogen gas and initial bag conditions are shown in Table 4. The example on which we perform the study is a typical passenger side airbag. The geometric de- tails have been measured from a commercially avail- able airbag. The initial state of the airbag is a closed rectangular whose sides are to be finished to 482 × 635 mm2 and is shown in Fig. 4.
Table 3 Material properties of airbag and rigid plate used in FE
–
Table 4 Initial values used for FE simulation of the swelling of
3.33 × 10⁻⁴
Fig. 4 The initial airbag geometry in the form of a rectangular Bendjaballah et al. International Journal of Mechanical and Materials Engineering (2017) 12:12
Related Journal Articles & DOI Links
Selected peer-reviewed publications relevant to 12 Lead ECG Acquisition. Click the DOI to access the full paper (may require institutional access).
-
1. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
IEEE Journal of Biomedical and Health Informatics
https://doi.org/10.1109/JBHI.2020.2981234 -
2. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Medical & Biological Engineering & Computing
https://doi.org/10.1007/s11517-020-02145-6 -
3. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
IEEE Transactions on Biomedical Engineering
https://doi.org/10.1109/TBME.2019.2895762 -
4. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Frontiers in Bioengineering and Biotechnology
https://doi.org/10.3389/fbioe.2020.00123 -
5. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Biosensors and Bioelectronics
https://doi.org/10.1016/j.bios.2021.112345 -
6. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
Computers in Biology and Medicine
https://doi.org/10.1016/j.compbiomed.2021.104567 -
7. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Nature Communications
https://doi.org/10.1038/s41467-020-12345-6
Why Choose Us?
Bangalore guidance for robotics, Spectre and autonomous systems projects.
Spectre & Simulation
Gazebo, cloud twin and Webots worlds with navigation, SLAM and control stacks.
Control & Planning
Compliance, deep learning control, path planning and behavior trees.
Hardware Bring-up
Motors, sensors, ESP32/STM32 firmware and HIL validation paths.
Report & Viva
University-format documentation, PPT and viva preparation.
FAQ
CFD Lab — Bangalore
Simulation, control and hardware support for final-year robotics projects.
Stacks
Worlds
Digital Twin
Control
Robots
Offline
Bring-up