Tokamak Vacuum Vessel
Ravi Guptaa, Rahul Babu Konerua, Saptarshi Rajan Sarkara, Santosh Ansumalib, Animesh Kuleyc, Roshan Georgea, Shaurya Kaushala,∗ aPranos Fusion Private Limited, Innovation and Development Centre,
Jncasr, Bengaluru, Karnataka, 562162, India
bEngineering Mechanics Unit, Jawaharlal Nehru Centre for Advanced Scientific
Abstract
PRAGYA is a new and India’s first privately developed low aspect ratio toka- mak device designed by Pranos Fusion Energy. The tokamak is designed for a plasma major radius (R0) of about 0.4 m, plasma minor radius (a) greater than 0.18 m, plasma current (Ip) of up to 25 kA and a toroidal magnetic field (BT) of 0.1 T. The PRAGYA vacuum vessel has distinctive features such as a toroidal elec- tric break to minimize induced eddy current and a double O-ring arrangement to minimize the loss of vacuum. This paper details the final design of the PRAGYA vacuum vessel and presents a comprehensive three-dimensional (3D) finite ele- ment model (FEM) assessment of its structural performance. Evaluations cover the effects of self-weight, atmospheric load and thermal stress arising from in-situ baking. The results confirm that the design satisfies all required safety margins under these combined loading conditions, providing a robust foundation for sub- sequent plasma operations in this compact tokamak.
1. Introduction
An ever-increasing global energy demand, largely met by fossil fuels, is ac- celerating anthropogenic climate change. Robust low carbon energy alternatives arXiv:2603.11549v1 [physics.plasm-ph] 12 Mar 2026 are essential to reduce greenhouse gas emissions and nuclear fusion offers a safe and energy dense alternative to the existing set of green energy technologies.
Magnetic-confinement fusion (MCF), with the tokamak as its most extensively studied and experimentally validated configuration, aims to satisfy the Lawson energy-balance requirement by confining a 10 keV plasma long enough that alpha self-heating together with auxiliary heating exceeds losses due to transport and radiation (Lawson, 1957; ITER Physics Expert Group on Confinement and Trans- port and ITER Physics Expert Group on Confinement Modelling and Database and ITER Physics Basis Editors, 1999).
The Current Barriers To Tokamaks As
commercial power sources are primarily around achieving high energy confine- ment despite microturbulence driven anomalous transport (Horton, 1999); main- taining stable operation against MHD instabilities and disruptions while control- ling current and pressure profiles (Hender et al., 2007); and realizing a durable plasma–material interface that can simultaneously handle extreme steady state and transient heat fluxes and provide reliable power and particle exhaust (divertor/first- wall performance) (Federici et al., 2001; Herrmann, 2002).
Against this multi-constraint background, decades of research has produced major advances in both tokamak physics and the enabling technologies.
The
record fusion gain and triple product by JET (Keilhacker, 1999), TFTR (Strachan et al., 1997) and JT-60U (Kishimoto et al., 2005), discovery of the new operational regime H-mode by ASDEX-U (Wagner et al., 1982), development of spherical tokamaks such as MAST (Darke et al., 1995), NSTX (Ono et al., 2001), allowing for a high plasma β (β=plasma pressure/magnetic pressure) operations in a com- pact space. In parallel, state-of-the-art high-temperature superconducting (HTS) rare earth barium copper oxide (REBCO) magnets have demonstrated large-scale, ∼20 T-class fields, strengthening the case for compact high-field tokamak con- cepts (Hartwig et al., 2023; Whyte et al., 2023). High-performance computing and integrated predictive modelling frameworks increasingly couple microturbu- lence, transport, pedestal and equilibrium physics, MHD stability and engineer- ing constraints, enabling a more constrained scenario development and design iteration (Staebler et al., 2022; Lyons et al., 2023; Jenko, 2025). Novel plasma control systems based on machine learning are being actively developed for im- proved flexibility and generalizability (Degrave et al., 2022; Kerboua-Benlarbi et al., 2024). With ITER and SPARC progressing towards first plasma operations, the field is now positioned to test fusion net-gain relevant regimes with substan- tially improved physics understanding and technology readiness.
A central design variable in tokamaks is the aspect ratio A, which strongly couples to MHD stability limits and engineering integration. The aspect ratio is
2
defined as the ratio of plasma major radius R0 to the plasma minor radius a. A schematic of the plasma geometry is shown in Figure 1. From a magnetohydro-
Plasma Boundary
Figure 1: A schematic of the plasma geometry depicting the magnetic contours inside the last closed flux surface (LCFS) which is shown in red. The plasma major radius R0 is defined as the radial distance from the axis of rotation to the plasma magnetic axis. The plasma minor radius a = (Rmax −Rmin)/2 where Rmax and Rmin are the maximum and the minimum radial extents of the LCFS respectively. The ellipticity κ = b/a and triangularity δ = (Rgeo −Rup/low)/a where Rgeo is the geometric center of the plasma and Rup/low is the radial extent of the uppermost or the lowermost point on the LCFS.
dynamic (MHD) stability point of view, a higher plasma β offers better stability against ballooning and kink modes. As the plasma β scales as 1/A, a smaller A is favoured for stable operations (Miller et al., 1996). At one end are the ultra- compact spherical tokamaks (STs) such as PEGASUS-III (Sontag et al., 2022),
3
MAST (Darke et al., 1995), NSTX (Ono et al., 2001), SUNIST (Ying et al., 2003), LATE (Maekawa et al., 2005), LTX-β (Boyle et al., 2023; Banerjee et al., 2024) with A < 2. These machines allow for operations at a high β, a high plasma current and a high bootstrap fraction (Peng, 2000; Ono and Kaita, 2015). How- ever, the lack of space at the high-field side poses a challenge to placing a central solenoid, shielding and blankets. On the other end of the aspect ratio spectrum are EAST (A = 4.25) (Wu et al., 2007), SST-1 (A = 5.5) (Deshpande, 1997), WEST (A > 5.6) (Bucalossi et al., 2022) which are not constrained for space but are prone to MHD instabilities. The remainder of the aspect ratio range has tokamaks such as DIII-D (A = 2.5) (Luxon, 2002), JT-60SA (A = 2.5) (Tomarchio et al., 2017), ADITYA (A = 3.0) (Bhatt et al., 1989), Alcator C-Mod (A = 3.09) (Marmar and Group, 2007), SPARC (A = 3.24) (Creely et al., 2020), KSTAR (A = 3.6) (Lee et al., 2001) which offer exploration of various physics and subsystems for ITER and DEMO-like machines (Tomarchio et al., 2017). Wong and co-authors (Wong et al., 2002) in their analysis observed that for an elongation of 2, the minimum cost of electricity was obtained for A ∈ and A ∼2 for a superconducting (SC) reactor and a normal conducting (NC) reactor respectively. The analysis ex- plored the combined effect of aspect ratio (1.2 −6.0), elongation (1.5,3.0) and MHD stability on the design of NC and SC fusion reactors. From an economics standpoint, along with the trade-off between available space inside a tokamak and MHD stability, the low aspect ratio tokamaks are very promising in the context of a pilot fusion power plant.
Within this landscape, PRAGYA is being developed as India’s first privately developed low aspect ratio tokamak designed by Pranos Fusion Energy. PRAGYA is designed for a plasma major radius R0 of 0.4 m and minor radius a of 0.18 m which gives A ∼2.2 with a planned operational plasma current Ip of about 25 kA.
The magnetic system consists of a central solenoid along with the toroidal and poloidal field coils. The toroidal field coils are designed to produce a magnetic field BT of strength 0.1 T at R0. The plasma current will be driven by a central solenoid while a 6 kW microwave source operating at 2.45 GHz will be used for pre-ionization and plasma startup. The target vacuum pressure is 10−6 mbar.
This is a small compact tokamak designed as a precursor to a larger tokamak with scientific exploration and development of critical human resources as a core objective. In particular, PRAGYA is designed to address the following objectives: i. accommodate plasma with an elongation between 1.5 and 2.2 and a triangu-
Larity Between 0.0 And 0.4
ii. test bed for superconductor magnets, auxillary heating, solenoid-free start-up
4
and current drive, novel plasma control systems for future large-scale fusion
Device
iii. investigate the magnetohydrodynamic (MHD) stability of plasma iv. test remote handling. The vacuum vessel is a crucial component of tokamak maintaining a very high vacuum necessary for plasma generation, confinement and shaping. In addition to the vacuum load and the self-weight, the vacuum vessel is also subjected to thermal load during baking operations, electromagnetic loads from the magnetic system and also large asymmetric loads encountered during plasma disruption events. Additionally, a vacuum vessel provides support for plasma facing compo- nents such as limiters and divertors along with diagnostics such as flux loops and Rogowski coils. Furthermore, the vacuum vessel also acts as a support structure for the toroidal field (TF) and the poloidal field (PF) coils. The design of the vessel should ensure requisite level of vacuum pressure and structural integrity against the aforementioned loads all the while sparing enough room for diagnostics.
The primary focus of this paper is the design of PRAGYA tokamak’s vacuum vessel. The vessel is designed to strictly adhere to the safe structural and ther- mal loads encountered during the tokamak operation. Detailed simulations are conducted to assess the structural integrity of vacuum vessel. The remainder of the paper is organized as follows. The mechanical design of the vacuum vessel and a detailed description of its various components are presented in Section 2.
The results from the thermo-mechanical stress analysis are discussed in Section 3 wherein results from 3D FEA analysis of mechanical and thermal loads on the vacuum vessel are discussed. Finally, the conclusions are drawn and a future out-
2.1. Description Of The Vacuum Vessel
PRAGYA tokamak is being designed for a plasma major radius of 0.4 m, a plasma minor radius of 0.13 m - 0.18 m and a plasma current of upto 25 kA. The resulting aspect ratio is between 2.2 and 3.1. The key target operational parame- ters of PRAGYA are listed in Table 1. The bounds of the operational limits are sub- ject to safety factor on axis q0 and on the edge q95 that allow for a stable plasma operation. For a given geometry of the plasma, q0 and q95 are computed using the fixed-boundary Grad-Shafranov solver in TokaMaker (Hansen et al., 2024).

These values are listed for the minimum and maximum values of A and δ in Table
5
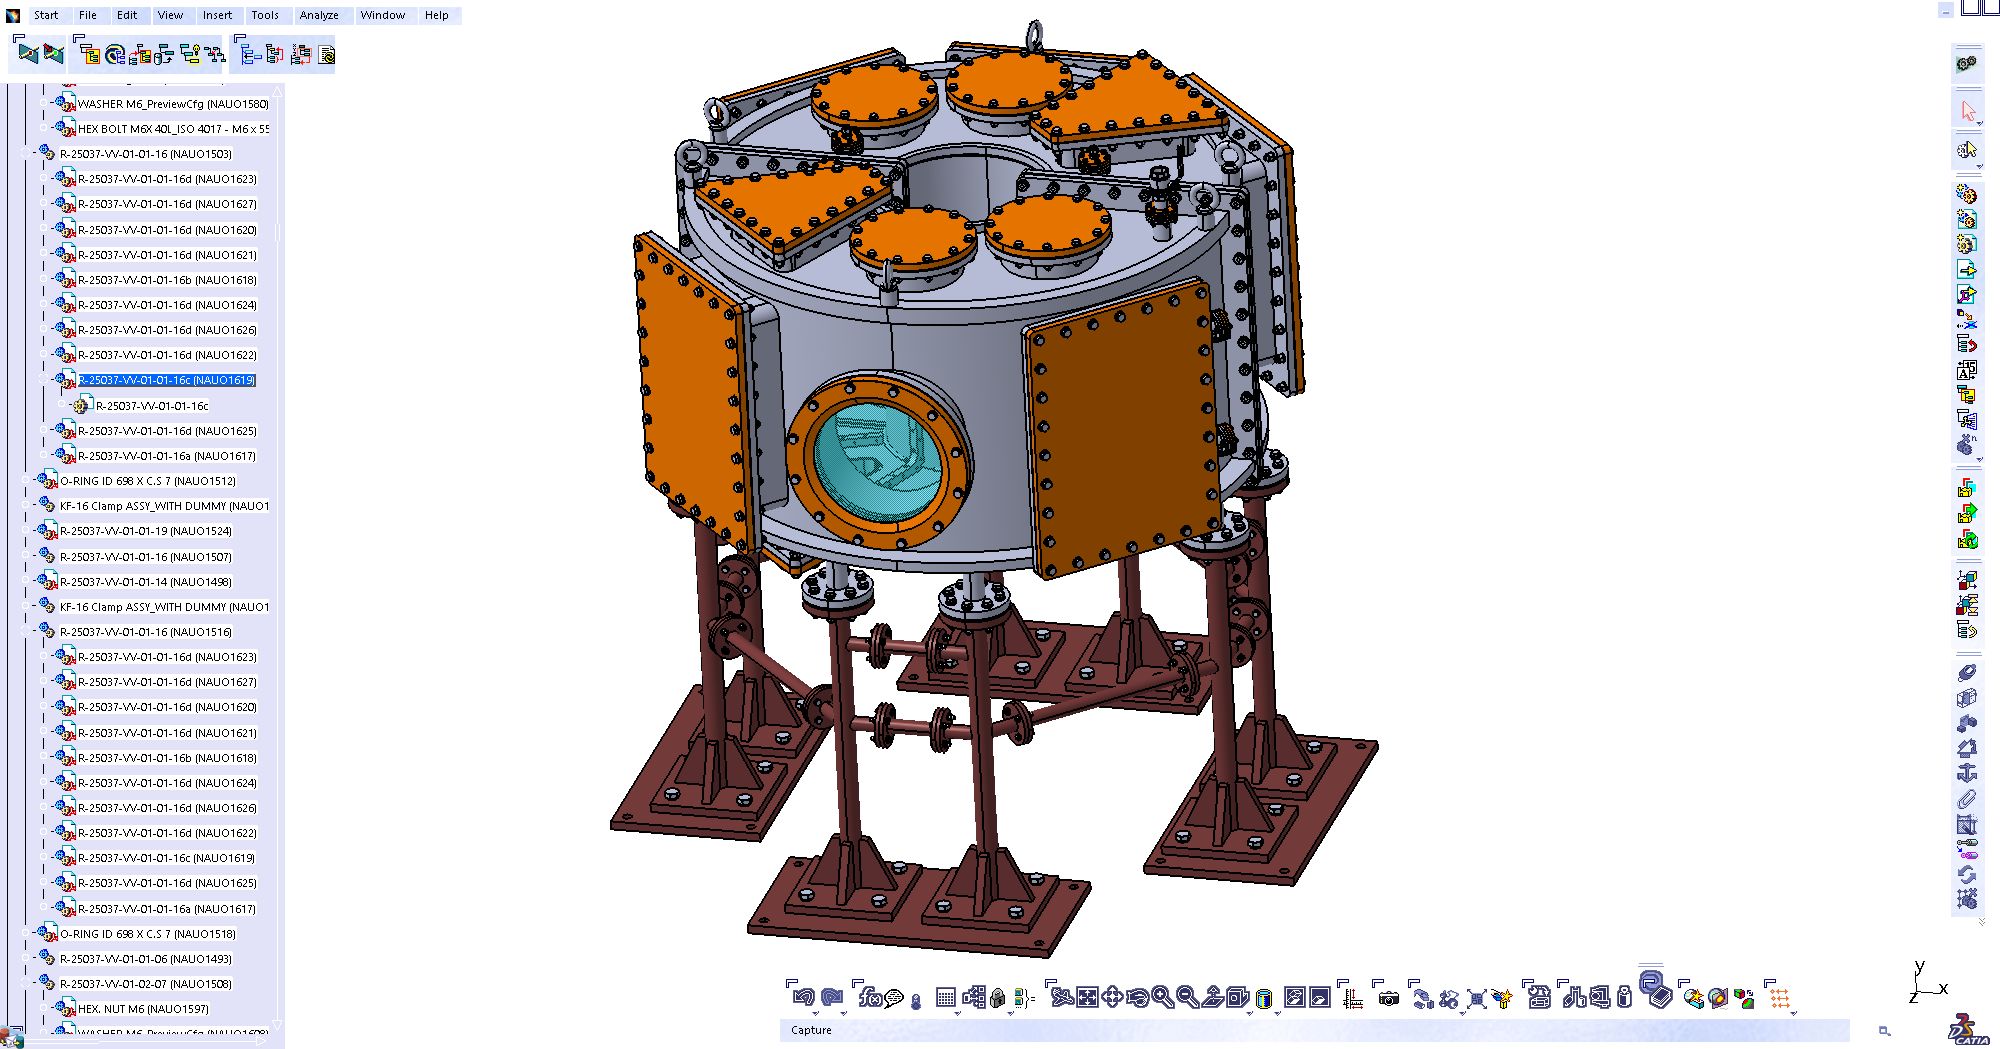
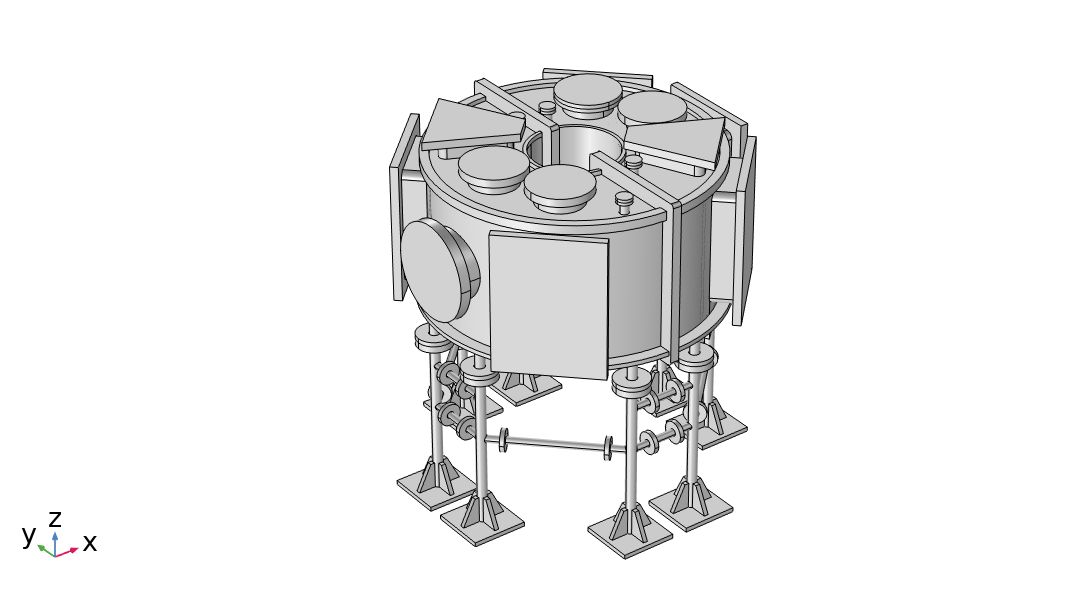
2. A short description of the Grad-Shafranov equation is provided in Appendix C. Based on the aforementioned requirements and budgetary constraints, a vacuum vessel of width 400 mm and a height of 600 mm is designed. The wall thickness of the vacuum vessel is 6 mm on all sides. This particular choice of the wall thick- ness was result of an optimization procedure set to minimize the maximum stress on the vessel and is discussed in Section 3. The resulting inner diameter (ID) and the outer diameter (OD) of the vessel are 388 mm and 1212 mm respectively with a total interior volume of 0.8 m3. The 3D computer aided design (CAD) model of the vacuum vessel assembly is shown in Figure 2. To provide electrical insulation, the vacuum vessel is divided into two sub-tori with an electrical isolation material, G10, sandwiched between them. The electrical break is discussed in more detail in Section 2.3. The inner diameter (ID), outer diameter (OD) and wall thickness of the torus are 388 mm, 1212 mm, and 6 mm, respectively. The total interior volume (or, vacuum volume) of the vessel is 0.8 m3. A combination of circular, rectangular and trapezoidal ports, 22 in total, are present on the vacuum vessel.
The description of various ports and their utility is presented in Section 2.2.1. The vacuum vessel is made of stainless steel 304L.
Re-Entrant Port 1
Figure 2: 3D CAD model of the PRAGYA vacuum vessel (VV) assembly.
0.0−0.4
Table 1: Geometric features of the plasma in PRAGYA vacuum vessel
3.10
Table 2: The safety factor on the axis q0 and at the edge q95 for the extreme values of the aspect ratio A and triangularity δ computed from the fixed-boundary Grad-Shafranov solver TokaMaker.
2.2.1. Ports
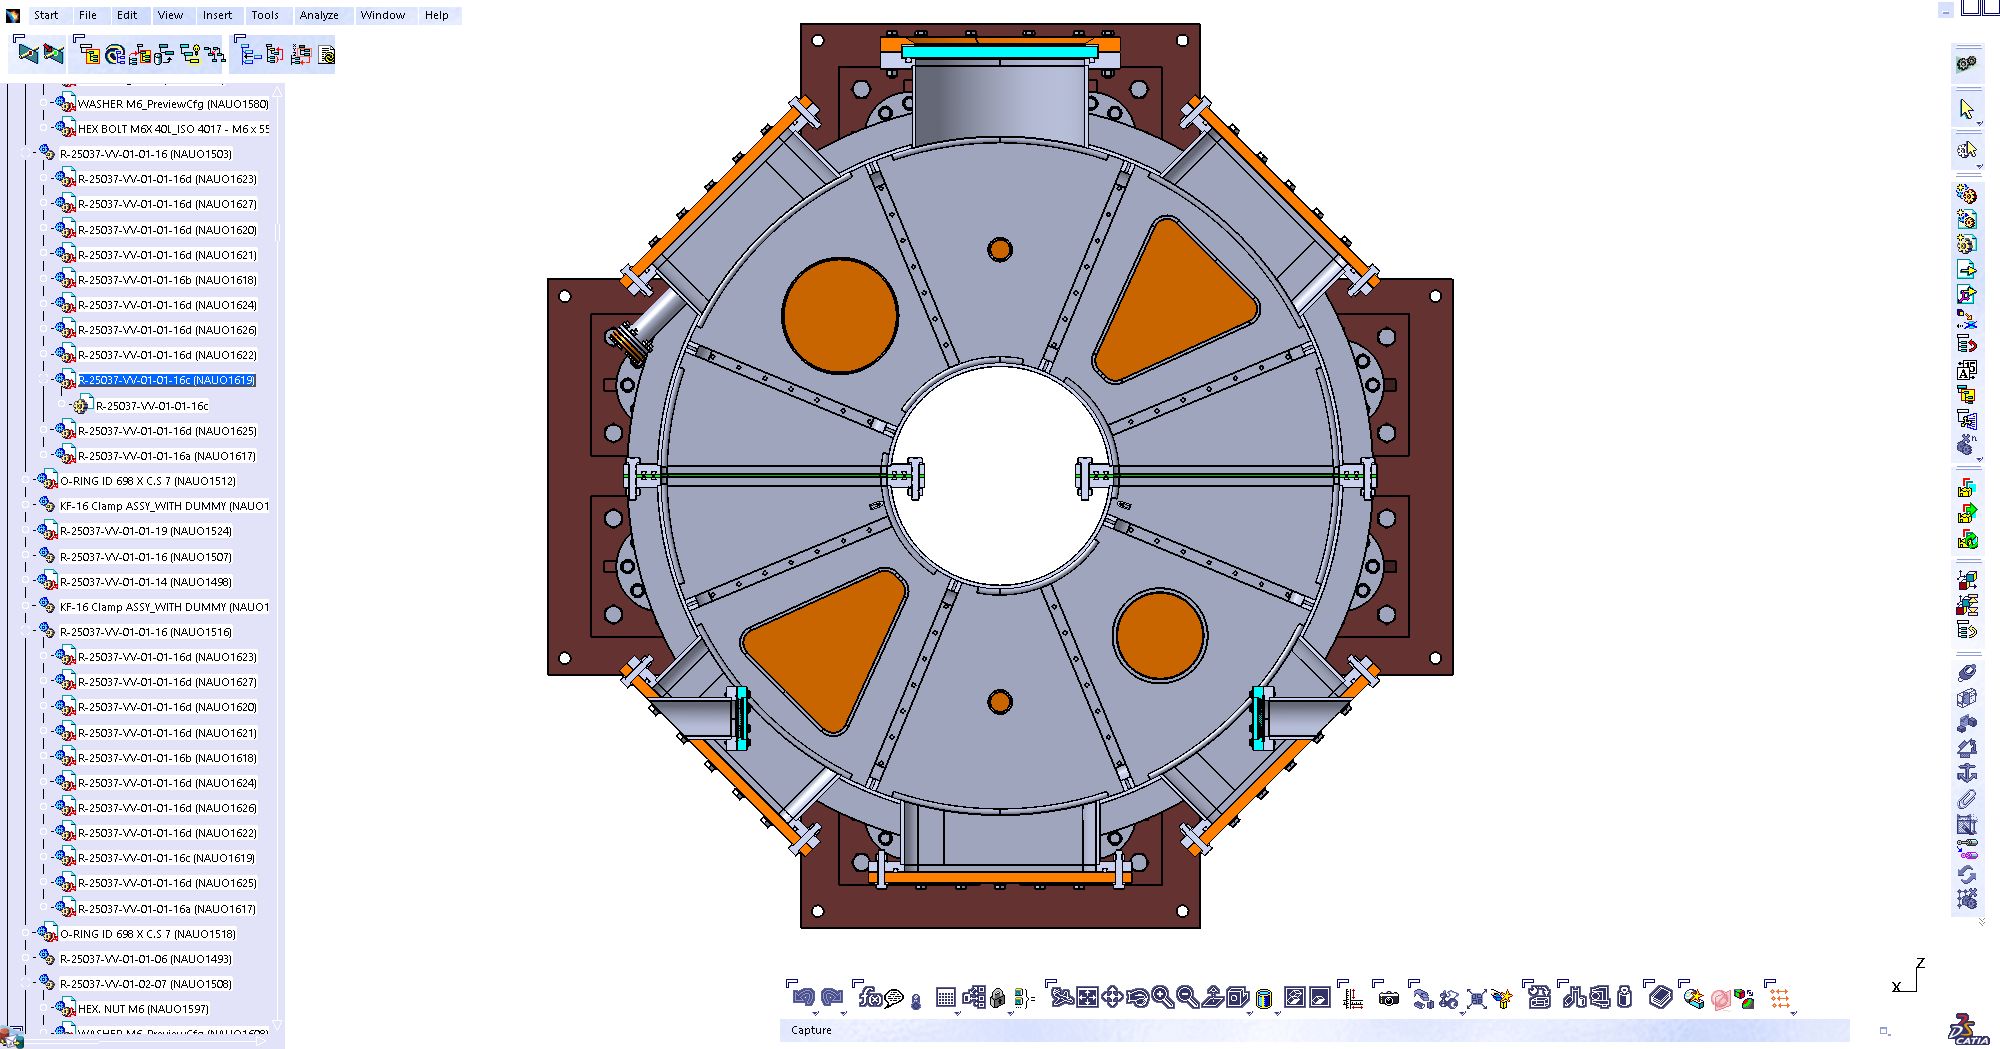
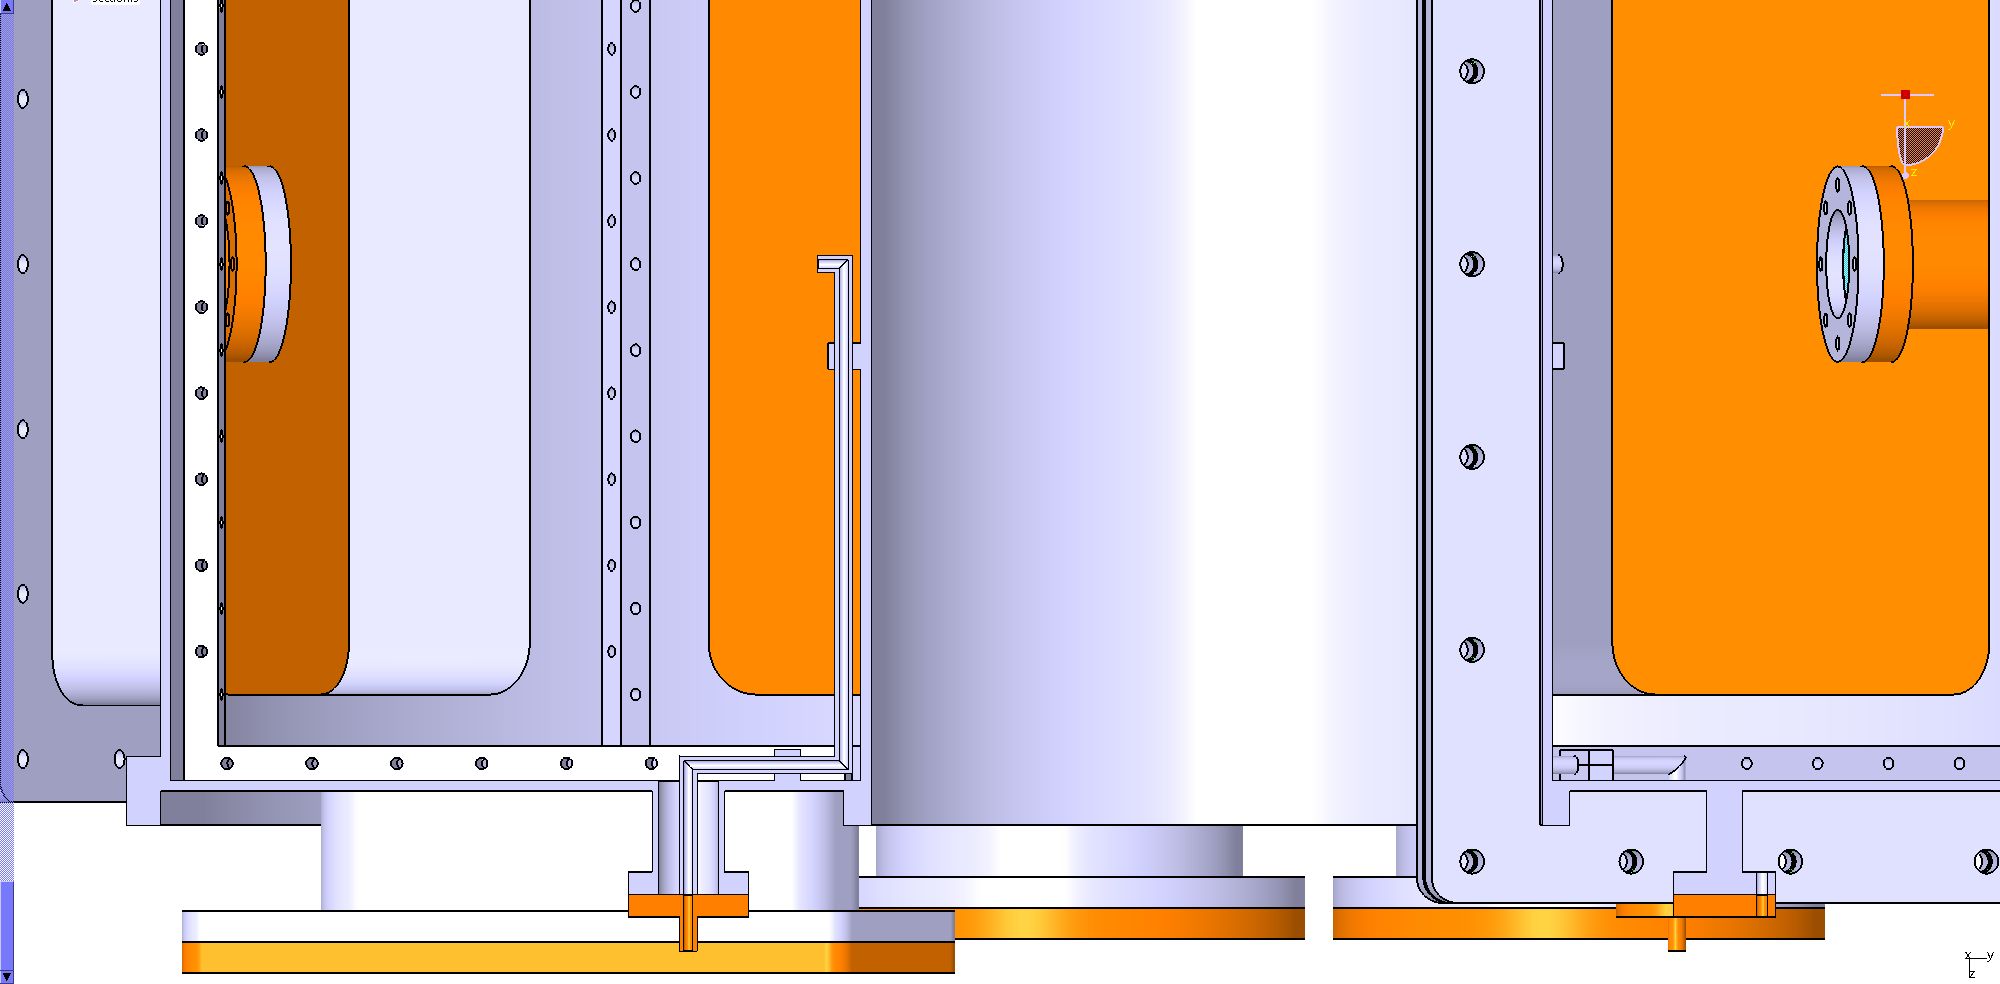
Each of the two sub-tori house multiple ports along the equatorial, top, and bottom sides. These ports will be used for diagnostics, connecting the pumping system, fuel inlet, and microwave heating source. The layout of the ports on the vacuum vessel is shown in Figure 2 and Figure 3 with a brief description of all the ports provided below.
Viewing port. A circular viewing port (diameter = 300 mm) is provided in the equatorial direction (shown in Figure 2, 3). The viewing port has a 20 mm thick toughened glass with O-ring sealing provided on the vacuum and atmosphere sides. This port provides visual access to high-speed cameras or for capturing plasma emissions using photomultiplier tubes (or photodiodes).

Trapezoidal-shaped port. A pair of trapezoidal ports are placed on the top and bottom sides of the vacuum vessel for diagnostics such as microwave interferom- etry. The trapezoidal shape allows a broader access in the radial direction and a closer reach on the inboard side of the vacuum vessel.
7
Diameter Nominal (DN) 200 ConFlat (CF) ports. Four DN 200 CF ports are provided on the top and one DN 200 CF port is provided bottom side of the vessel. The DN 200 ports placed on the top face of the vacuum vessel will be used for different diagnostics such as Langmuir probe. The bottom DN 200 port serves a dual purpose as a backup port for connecting the vacuum pump and as a port for diagnostics.
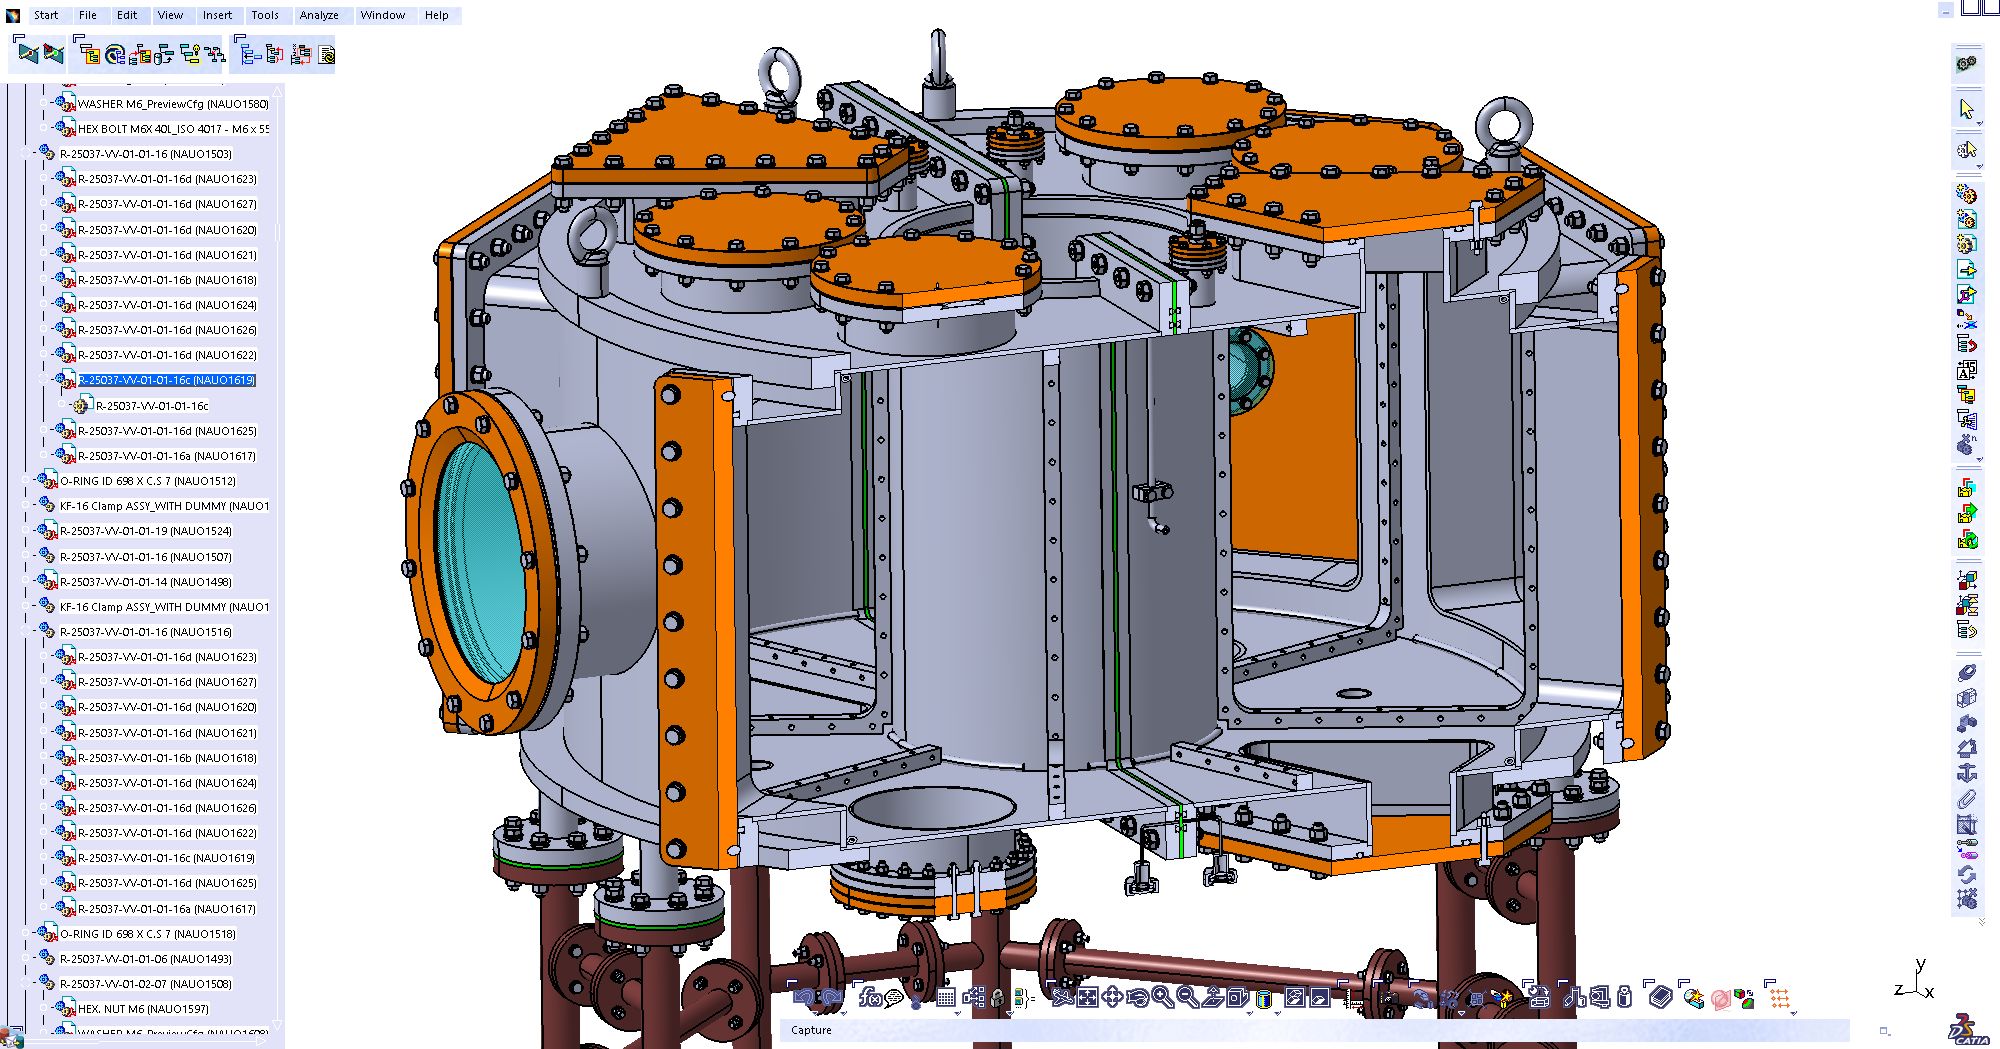
Gas injection port. Two DN 40 ports are placed on the top face of the vessel for gas injection (shown in Figure 2). A DN 3 SS304L (OD = 10.3 mm) pipe runs from each DN 40 CF port into the chamber while hugging along the wall (as shown in Figure 4a, 4c). These SS304L pipes run till the midplane and the gas is injected in the radial direction. To avoid vibrations of the inlet pipe during operations, they are held to the vacuum vessel using a clamp arrangement.
Equatorial rectangular port. A total of five identical rectangular ports are pro- vided on the outboard side of the vessel along the toroidal direction. These ports are 340 mm in width and 500 mm in height. These ports have multiple utili- ties such as microwave injection, visualization and diagnostics. Figure 3 shows tangential entry port assembly in the PRAGYA vessel. The viewing port has tough- ened glass mounted on a DN 63 CF flange. The radial coverage of the tangential entry viewing port is 63 mm ranging from 384 mm till 447 mm.
Turbomolecular pump (TMP) port. A DN 160 CF port is placed on the bottom side of the vacuum vessel to connect a Pfeiffer HiPace 700 H turbomolecular pump (TMP) (as shown in Figure 3). The TMP is not directly mounted on the designated TMP port to avoid a large magnetic field protruding inside the TMP.
The safe limit of external magnetic field for the TMP is 6 mT (provided in the operating instructions manual of Pfeiffer HiPace 700 1). Therefore, the TMP is placed 2 m away from the centerline of the vessel via an L-shaped bellow con- nected to the TMP port on the vessel. Based on the internal surface area (4.23 m2) and the total volume (0.8 m3) of the vacuum vessel along with the distance of the TMP from the vessel, reaching a vacuum of order 10−6 mbar will take approxi- mately 20 hours. This can be reduced to 8 hours with the introduction of a booster pump.
Roughing pump port. Two DN 40 ports are placed on the bottom side of the vac- uum vessel to connect Pfeiffer DuoVane 18 rotary vane pump (as shown in Figure 1Pfeiffer HiPace 700 operating instructions manual
8
3). The details of the vacuum pumping are provided in Section 2.7. Vacuum vent port. A DN 40 port is placed on the top side of the vacuum vessel for venting out the vacuum inside the vessel (as shown in Figure 2). For activities such as periodic maintenance and setting-up new diagnostics, the vessel needs to be purged and brought to atmospheric condition. Purging will be done by first ensuring all the pumps and gate valves are closed, and later injecting dry N2 gas into the vessel.
Torus2
Figure 3: A cut-section view of the 3D CAD model of tangential viewing port in the PRAGYA vacuum vessel assembly.
2.3. Electrical Break
The characteristic input current to the electrical coils responsible for magnetic field and plasma current involves current ramp-up and ramp-down stages. During the ramp-up or ramp-down stage, the change in magnetic flux leads to induced eddy current in the vacuum vessel walls. The induced eddy currents generate magnetic fields that interact with the plasma and affects its stability. In elongated tokamak plasmas, vertical stability is inherently unstable as any small vertical displacements grow exponentially without control (Fukuyama et al., 1975). Eddy currents in the vacuum vessel create up-down asymmetric radial fields that can ei- ther passively stabilize (reduce growth rate) or destabilize the plasma (worsen ver- tical instability and accelerate VDEs), depending on vessel geometry, time scale, and current mode. Furthermore in a toroidally continuous vacuum vessel, a ma- jor part of the Ohmic flux swing is lost in driving the current through the walls.
M8 Tapped Hole
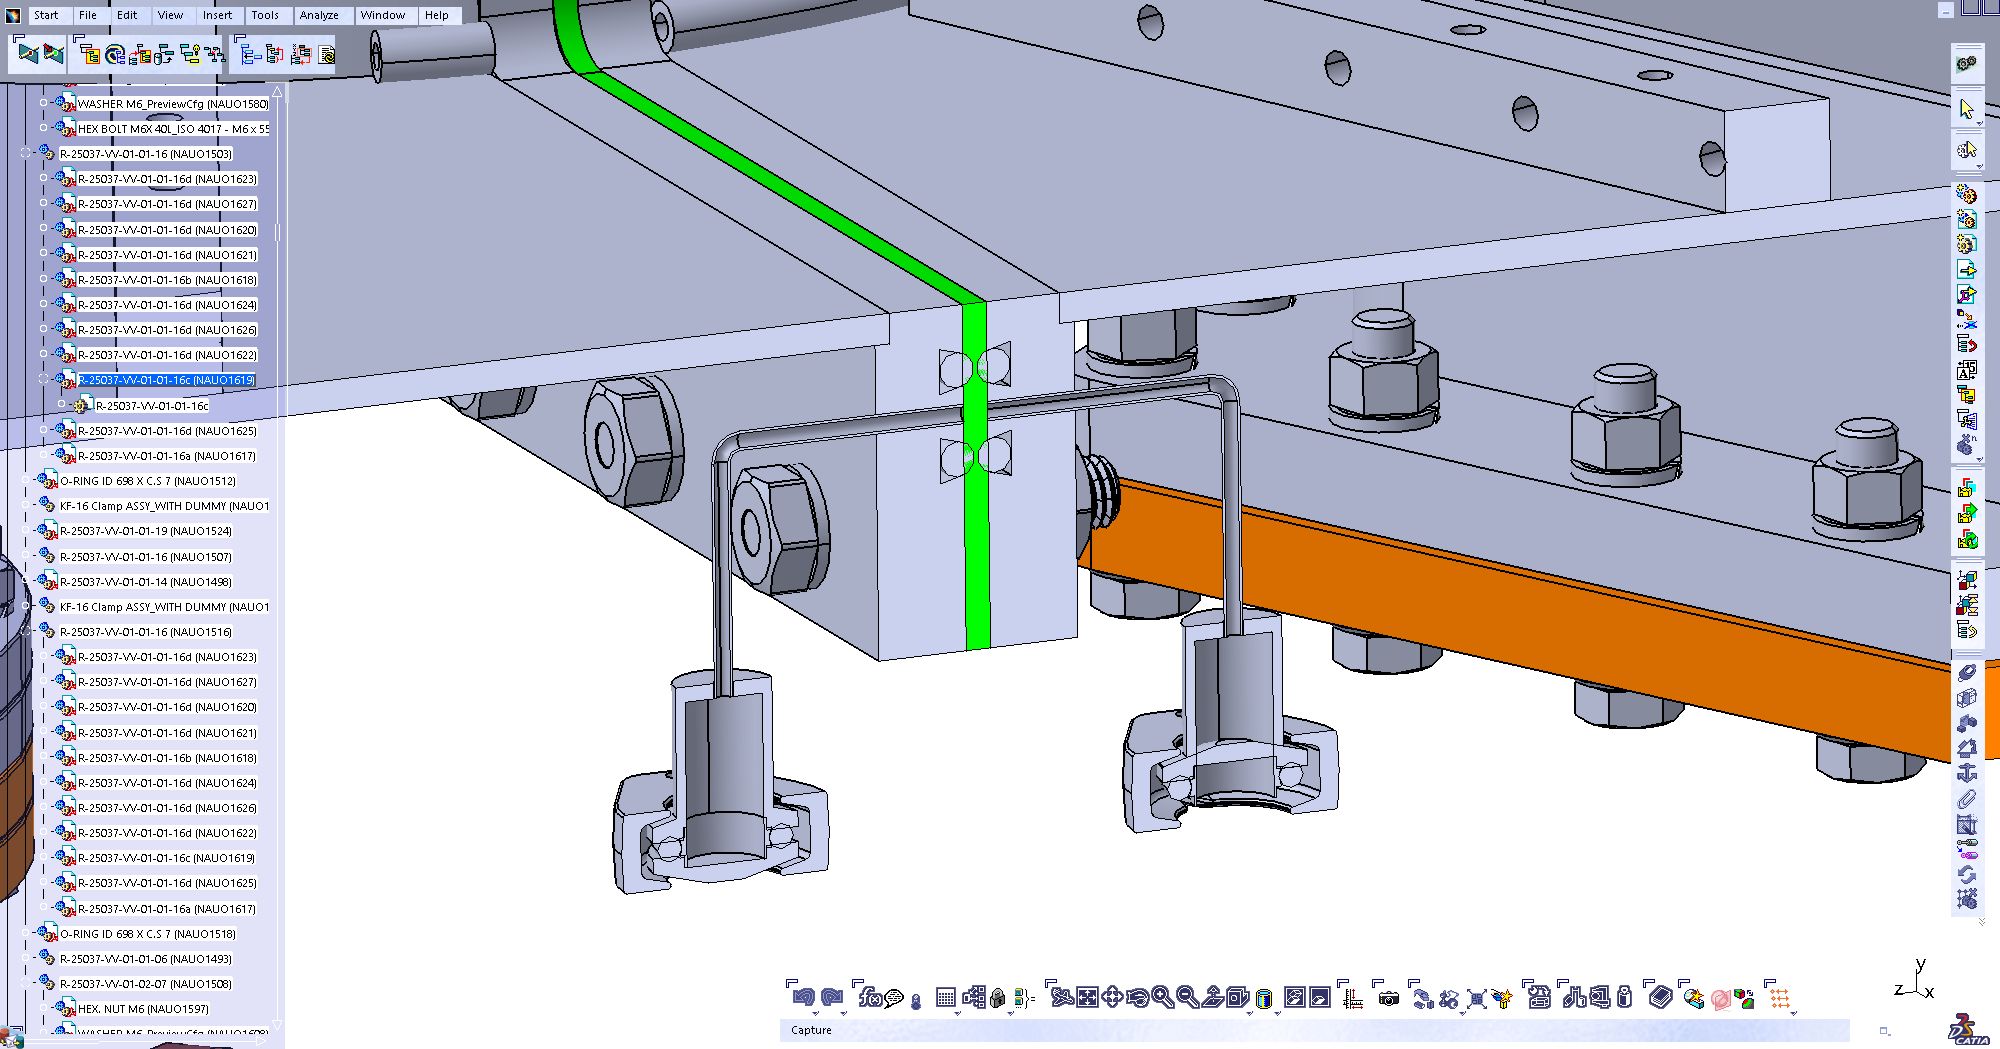
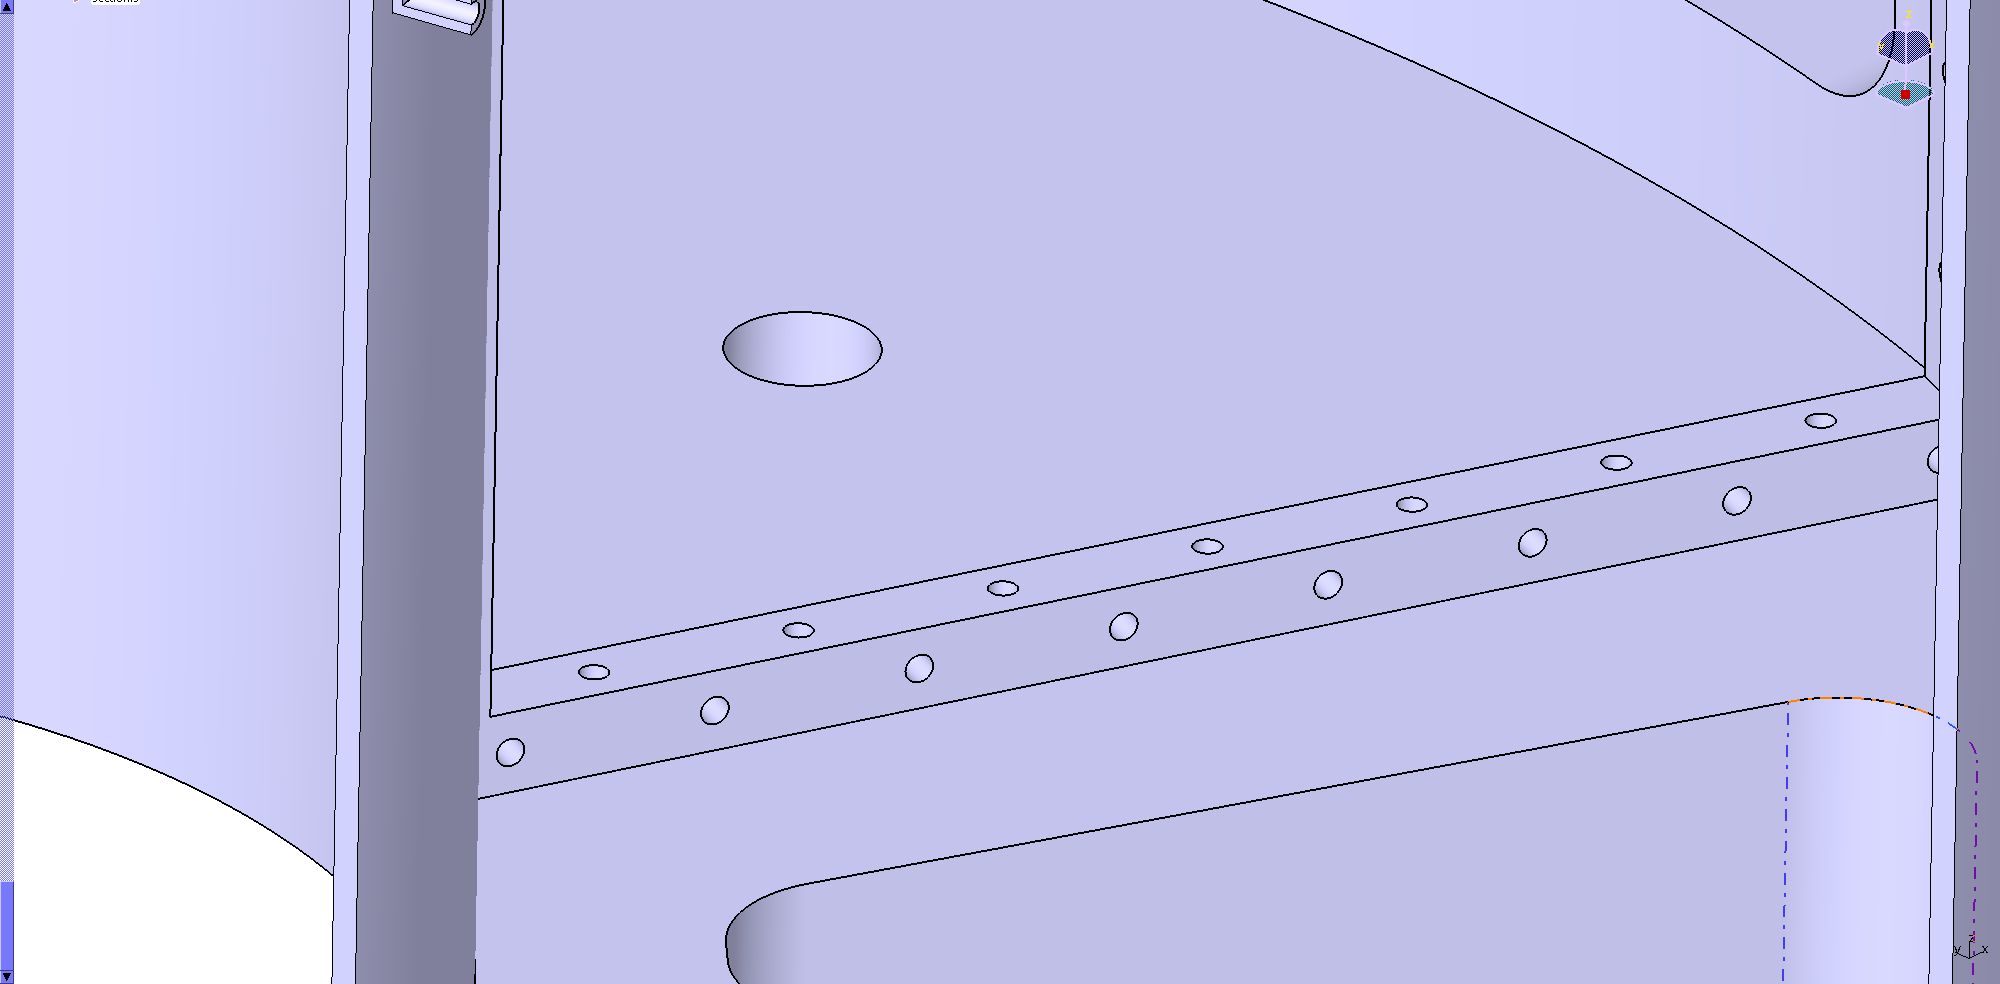
Figure 4: (a) A cut-section view of the 3D CAD model of the vacuum vessel assembly; zoomed-in descriptive view of (b) stiffener, (c) gas inlet system (dotted red arrows represent the direction of incoming gas flow), (d) double O-ring vacuum sealant assembly (dotted magenta arrows represent the direction of flow due to vacuum produced between the two O-ring arrangement).
This could be problematic in small machines where the available volt-seconds are minimal to start with. To minimize these effects, the vessel is divided into two sub-tori along the toroidal direction. A similar approach has been followed in existing tokamaks such as ADITYA-U (Jadeja et al., 2017), SUNIST (Li et al., 2015) and ASDEX (Finkelmeyer et al., 1979). An electrical insulation material G10, is sandwiched between the two sub-tori to provide electrical insulation in the toroidal direction. Figures 2 and 4d show the placement of G10 material in between the two torus. Additional G10 insulation is provided between the vessel and the support structure, as shown in Figure 2, to further minimize eddy currents.
To ensure a good vacuum sealing at the junction where the two sub-tori are placed together (with G10 in between them), the flanges of the two sub-tori are provided with a double O-ring arrangement as shown in Figures 4a and 4d. A series of two additional O-rings are placed along the poloidal direction and the space between them is evacuated using a roughing pump. The vacuum in this space will be maintained between 10−2 and 10−3 mbar. This will ensure that any atmospheric gas passing through the outer O-ring will be evacuated in the space between the two O-rings.
2.4. Stiffeners
The vacuum facing side of each tori houses ribs running along the poloidal direction. Figures 4a, 4b show the stiffeners in the vacuum vessel assembly. Al- though the addition of these ribs reduces the available volume for plasma, these ribs act as stiffeners providing structural rigidity to the vessel. These ribs have a cross-section 20×20 mm2. A total of eight ribs are present in the toroidal direc- tion. Eight stiffeners are added on the top plate, bottom plate and outer cylinder.
All these stiffeners are present on the inner faces. Four stiffeners are present on the inner face of inner cylinder. Furthermore, these ribs are lined with standard M8 tapped holes on three sides which will be used to mount limiter or diagnostic equipment inside the vacuum vessel. These tappings are 50 mm apart and are staggered on the adjacent faces. Figure B.1 in Appendix B shows a comparison of stress induced on a vacuum vessel with and without stiffeners. With the addition of stiffeners, a 6 to 7 times reduction in the maximum stress is observed.
2.5. Vacuum Vessel Support Structure
The vacuum vessel rests on a support structure that consists of 8 legs (4 on each sub-torus). The legs are 0.75 m tall which puts the center of the circular viewing port 1.2 m above the ground. These legs are connected to the vessel at 620 mm away from the central axis to provide sufficient space at the bottom side of the vessel connecting vacuum pumps and diagnostics. These legs rest on base plate which will be grouted to the floor of the facility. The support legs are designed to hold the weight of the vessel without undergoing buckling. The details of linear buckling analysis performed on the support legs are provided in the Section 3.5.1.
The legs are connected through trusses in the toroidal direction to give stability to the vessel against the lateral forces or moments acting onto it.
2.6. Material For Construction
A common choice for the tokamak vacuum vessels is stainless steel due to its non-magnetic nature, good machinability characteristics, lower cost and corro- sion resistance. The two widely used grades of stainless steel in the construction of tokamak vacuum vessels are 304 (L) (Ying et al., 2003; Song et al., 2006; Jadeja et al., 2017; Sontag et al., 2022) and 316 (L) (Sakurai et al., 2009; Mardani et al., 2012; Chung et al., 2013; Mancini et al., 2021; Huang et al., 2024) which differ by their corrosion resistance properties and the amount of carbon present in them. The vacuum vessel, ports, blanks of the ports, support structures are all made of SS304L. SS304L is chosen due to its lower magnetic permeability, high mechanical strength, corrosion resistance, low electrical conductivity, ease
11
of availability, established fabrication/machining processes and also the relatively low cost compared to SS316. In summary, the key characteristics of the PRAGYA vacuum vessel assembly are listed below.
i. The vacuum vessel is electrically isolated from the induced eddy current in the toroidal direction by dividing it into two sections. ii. To reduce leaks, a double O-ring arrangement is designed on the flanges and the space between the two sets of O-rings is evacuated using a vacuum pump.
iii. Multiple ports are present on the equatorial, top and bottom sides of the vac- uum vessel. iv. Use of ribs (or, stiffeners) to provide additional structural strength to the vac- uum vessel which allows for mounting limiter or diagnostics inside the vac- uum vessel.
2.7. Vacuum Pumping System
The PRAGYA vacuum vessel is designed for a maximum vacuum of 10−6 mbar. To generate a vacuum of this order, a series of two pumps, a roughing pump (Pfeiffer Duovane 18 rotary vane pump2) of capacity 3.9 l/s and a turbomolecular pump (TMP) (Pfeiffer HiPace 700 H3) of capacity 665 l/s, are used. The TMP is connected to the bottom face of the vessel in the designated DN 160 CF port.
The CF has a knife edge and an OFHC copper gasket to provide a vacuum seal. A splinter plate and a manual/electropneumatic gate valve is provided in between the DN 160 port and the TMP. The splinter plate prevents any unwanted material dropping into the TMP. The gate valve provides control to connect/disconnect the TMP from the vessel. The RVP is connected to the DN 40 CF port at the bottom face of the vacuum vessel.
3. Thermo-Mechanical Stress Analysis
During operation, the vacuum vessel will be subjected to different loads, i. pressure differential due to vacuum inside the vacuum vessel and atmospheric
Iii. Thermal Load During Baking And
iv. electromagnetic load. Different features of the vacuum vessel such as the wall thickness, stiffener lo- cations and dimensions, radius of curvature of the edges of the ports, are designed such that the stress induced in the vacuum vessel due to all these loads combined is within the material’s yield strength (170 MPa for SS304L).
Finite element analysis (FEA) is performed on the entire vacuum vessel as- sembly (including ports and support structure) to compute the stresses induced due to the vacuum, self-weight and thermal loads using COMSOL Multiphysics 6.3. The governing equations pertinent to the results in this paper are presented in Appendix C. Table 3 shows the mechanical and thermal and properties of stain- less steel SS304L used during the simulations (American Society of Mechanical Engineers, 2019). The values at 20 ◦C are used during simulations at room tem- perature conditions, while the values at 150 ◦C are used for simulations at baking conditions.
16.6
Table 3: Mechanical, thermal and electrical properties of stainless steel SS304L used in the COM- SOL simulations. The heat capacity at constant pressure, Cp = k/(ρα).
3.1. Grid Refinement Study
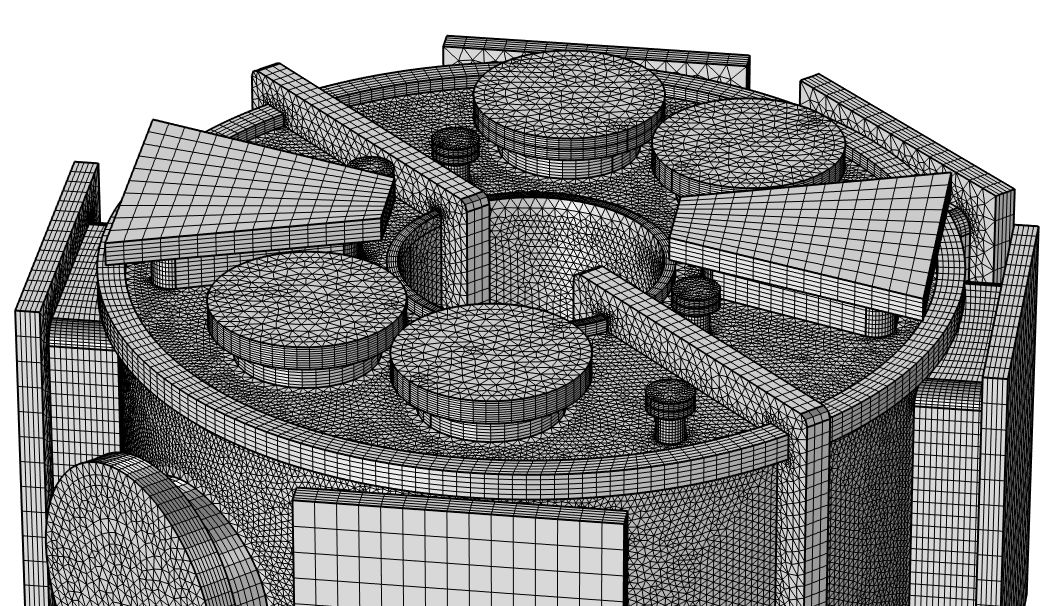
A grid refinement study is performed to optimize the number of mesh ele- ments used for the simulations. Figure 5 shows the 3D CAD model and the mesh used for the simulation. At multiple places in the geometry, quadrilateral mesh elements are used as they provide uniform and better control of spatial distribu- tion of mesh elements. The small features of the vacuum vessel assembly such as radius of curvature of the ports, stiffeners, port thickness, blank thickness, are
13
locally resolved as shown in Figure 5c to accurately represent the stress and de- formation. To perform the grid convergence study, global and local mesh element size were changed. For the tetrahedral elements, the global mesh elements size was modified while for the quadrilateral elements, the local mesh element size was modified. Two parameters, surface-averaged von Mises stress and line-averaged von Mises stress are the quantities of interest in this study. The surface averaged von Mises stress is monitored at three locations - top plate, bottom plate and out- board cylinder. At certain locations where the changes in geometry are not smooth enough, a localization (in one or two mesh elements) of stress is observed. In this work, the locations where the ports meet the vessel especially on the inboard side of the trapezoidal ports were observed to be the regions of high stress localization.
This is a well-known numerical artefact which can be resolved with a finer mesh around the problem zone or by analyzing the data a few mesh elements away from the problem zone. In this work, this issue is remedied by computing the line-averaged von Mises stress at the inboard side of the trapezoidal port. In all the simulations, the quantities of interest converge to a residual error of the order of 10−9. The effect of mesh resolution on these quantities is shown in Figure 6a and Figure 6b. In the absence of a known solution, the error is measured relative to the solution on the finest grid. These figures are semilog plots with the abscissa (or number of mesh elements) in the log scale. As expected, the relative error reduces with an increase in number of mesh elements or a reduction in the mesh volume. The reduction is quite steep up to about 700k elements after which the error plateaus. Therefore, the simulations discussed in subsequent sections is per- formed on the mesh with 1012k number of mesh elements. This mesh is shown in the Figure 5(b-c).
3.2. Vacuum Vessel Wall Thickness
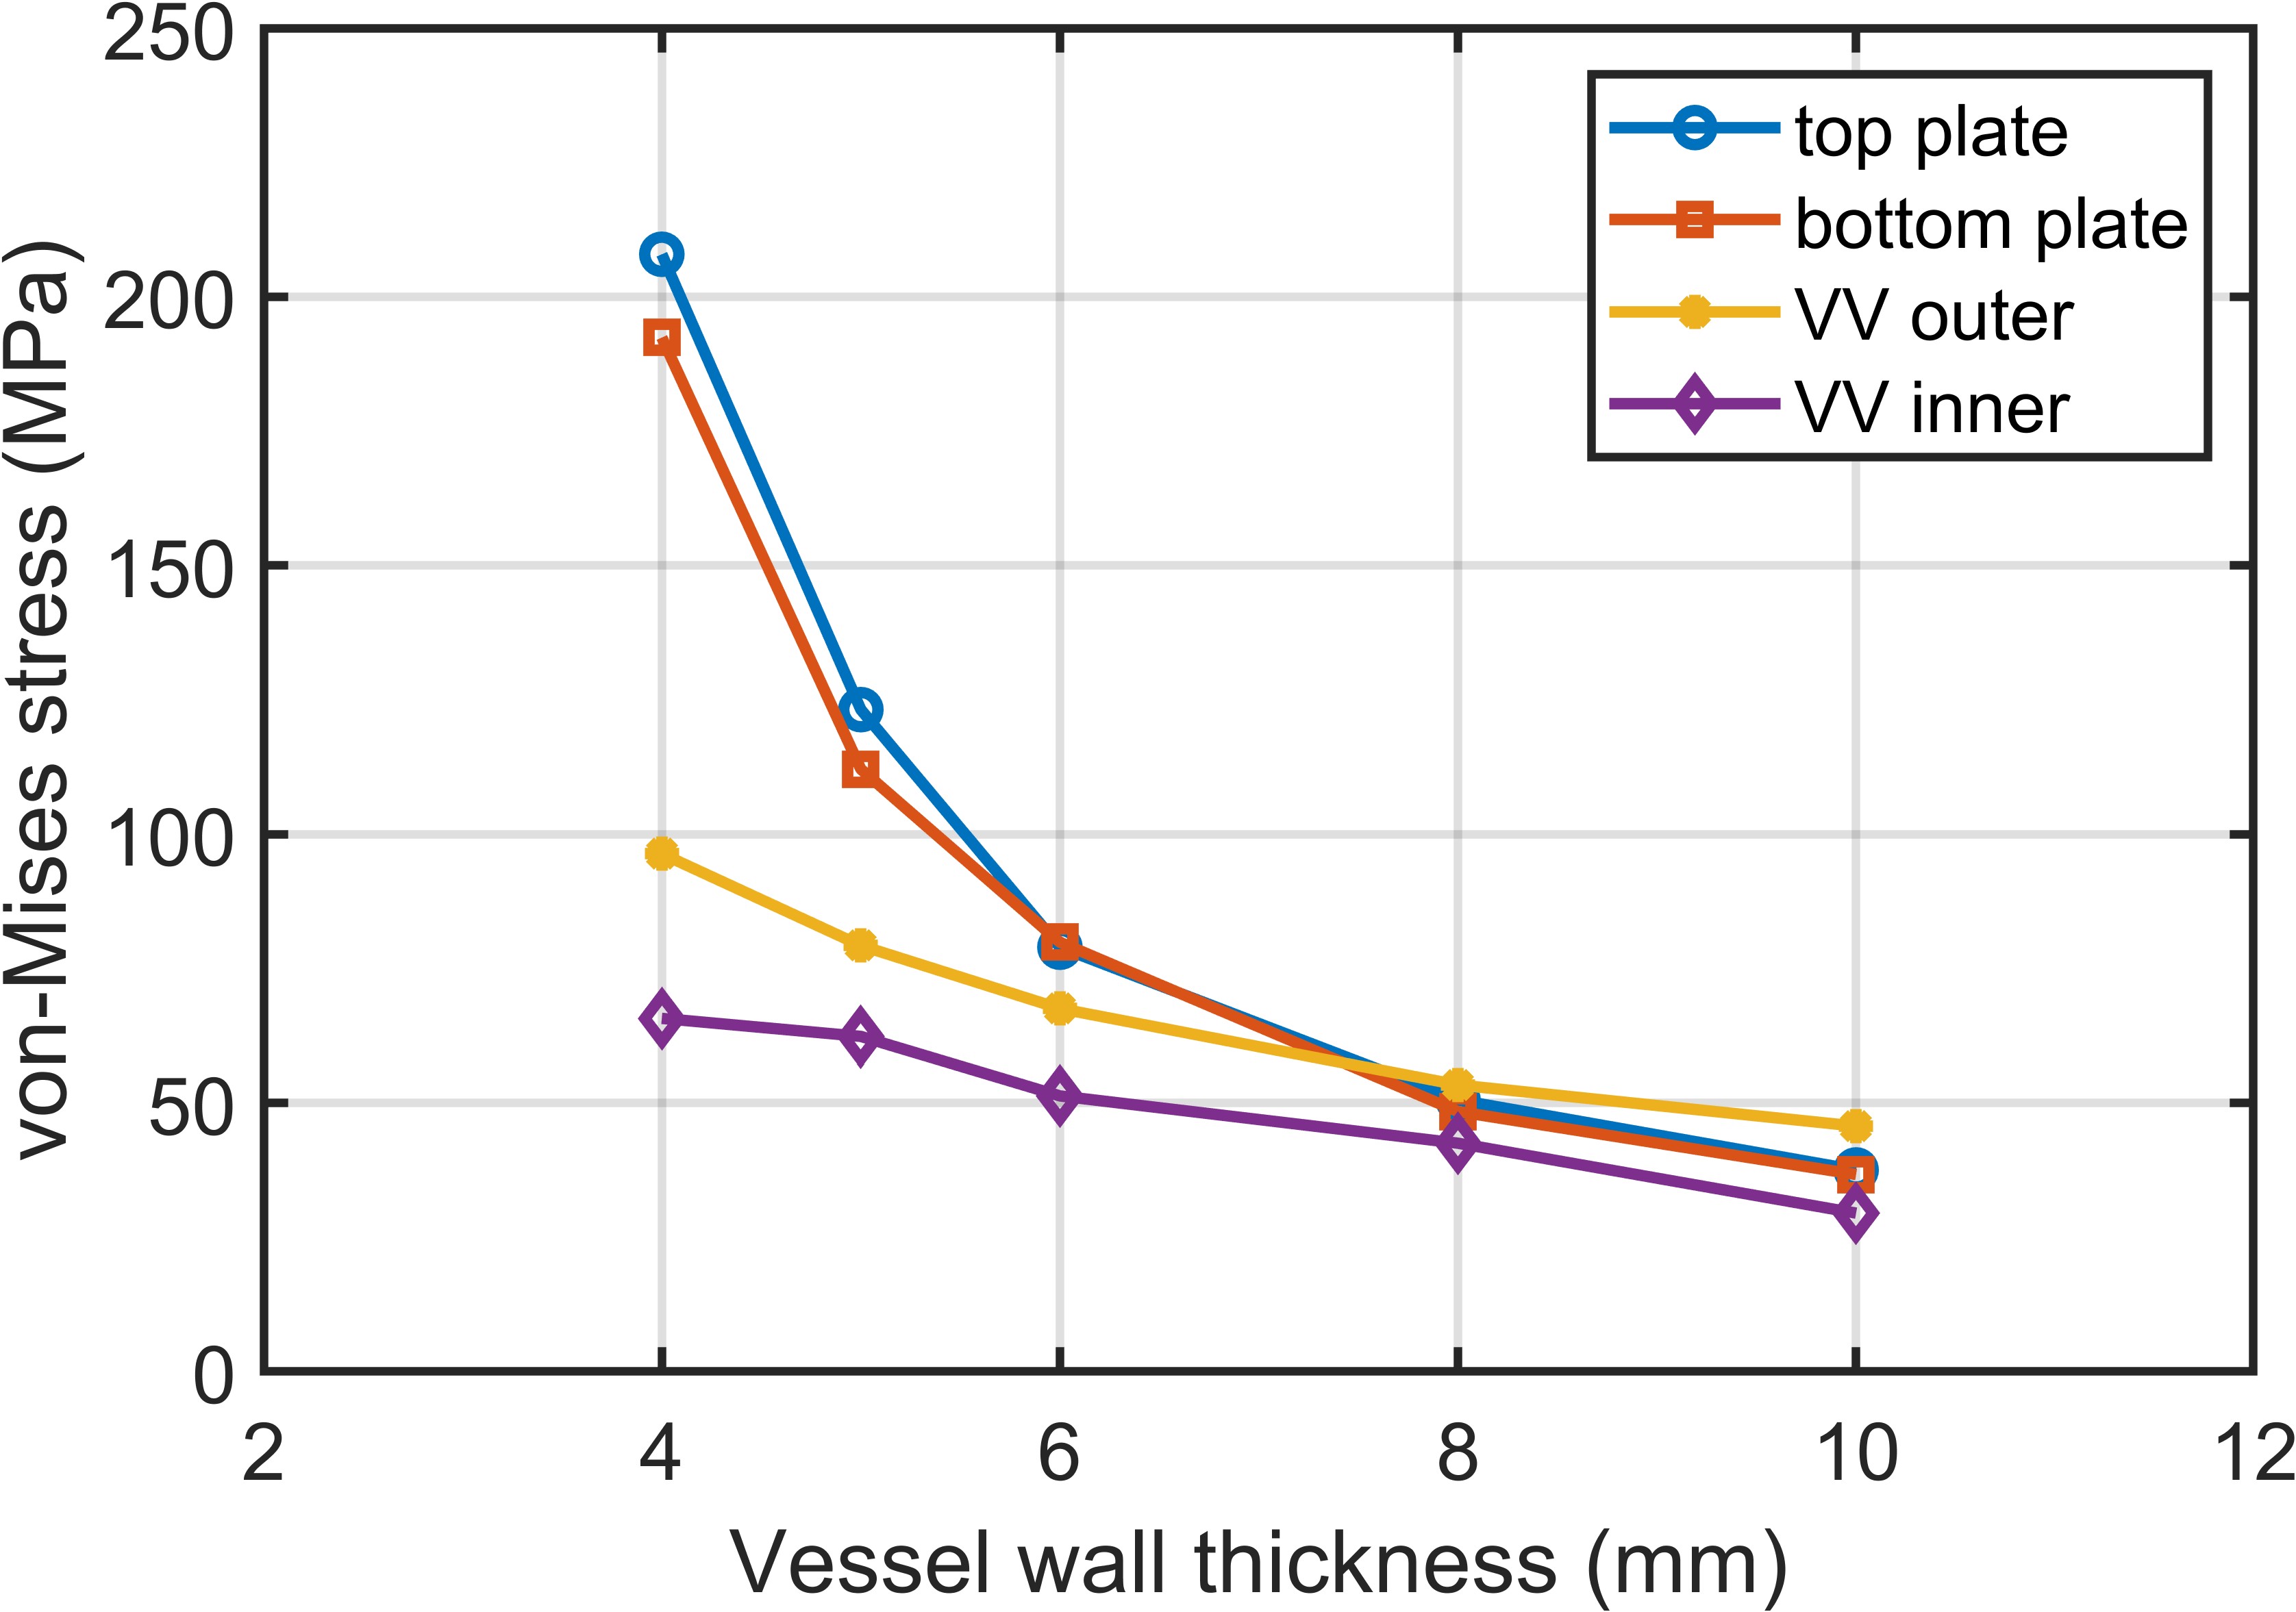
The effect of wall thickness over the maximum stress induced in the vacuum vessel is evaluated first to narrow down the wall thickness. A convergence study is performed to evaluate the optimum wall thickness for the vessel. The study is performed considering the pressure difference due to vacuum and atmosphere, and self weight of the vessel. Maximum von Mises stress induced on different faces (top plate, bottom plate, inner cylinder and outer cylinder) of the vessel is monitored. The geometry and the corresponding mesh for this study is shown in Appendix A. Figure 7 shows the variation of maximum von Mises stress induced at these surfaces with respect to different wall thickness. Two observations are made: first, the maximum von Mises stress induced on the different faces of the vessel increases with a decrease in wall thickness; and second, for a given wall
(B)
Figure 5: (a) 3D CAD model and (b) mesh used for the simulations.
(B)
Figure 6: Semilogx plots of relative error in (a) von Mises stress averaged along a curve near the top trapezoidal port on the inboard side and (b) surface averaged von Mises stress averaged along top plate, bottom plate and vacuum vessel outer cylindrical surface.
thickness, the maximum von Mises stress is observed on the top plate except at higher wall thickness of 8 and 10 mm. Therefore, we consider the maximum stress induced on the top/bottom plate for the optimum wall thickness evaluation.
It is observed that the maximum stress induced on a 4 mm thick vacuum vessel is approximately 200 MPa which is already quite close to the yield limit of SS304L. Increasing the wall thickness to 5 mm, 6 mm and 8 mm, induces a maximum stress of 123 MPa, 79 MPa and 51 MPa respectively. While the stress is considerably lower for both the 6 mm and the 8 mm thick wall, a 6 mm thick wall is chosen from a material volume and cost point of view.
15
Figure 7: Wall thickness convergence study: Variation of peak von Mises stress at different sur- faces of vacuum vessel vs vessel wall thickness. 3.3. Stress due to vacuum and self-weight of the vacuum vessel To ascertain the structural integrity of the vacuum vessel against a differential pressure load due to vacuum, all the vacuum facing surfaces are set to a pressure of 10−5 Pa, while the atmosphere facing surfaces are set to a pressure of 101325 Pa. The base of the support legs are set to a fixed boundary condition with gravity acting along the negative z direction.
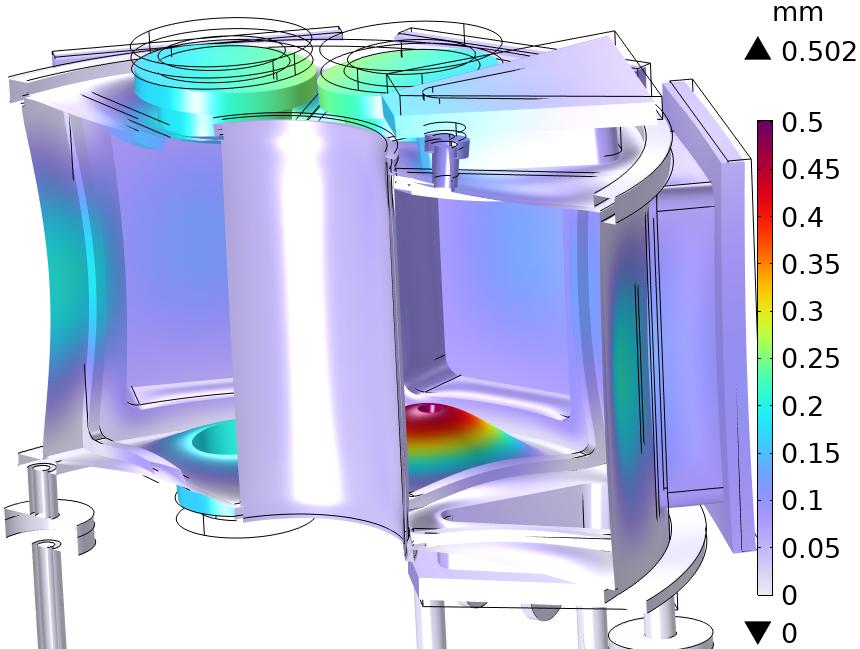
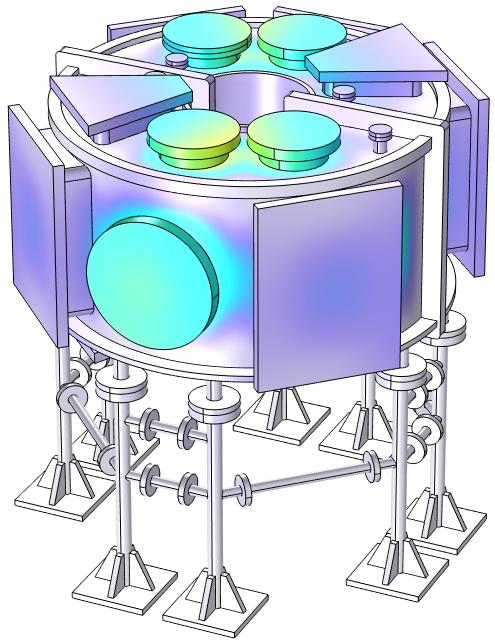
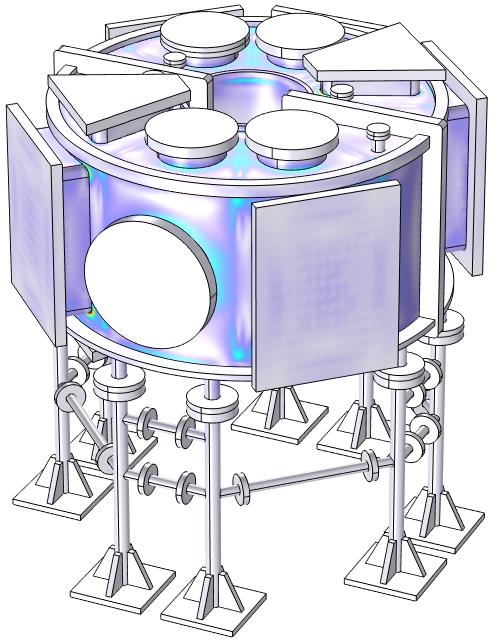
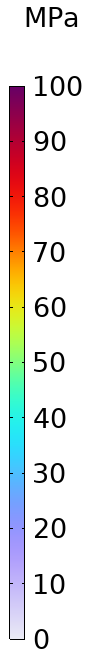
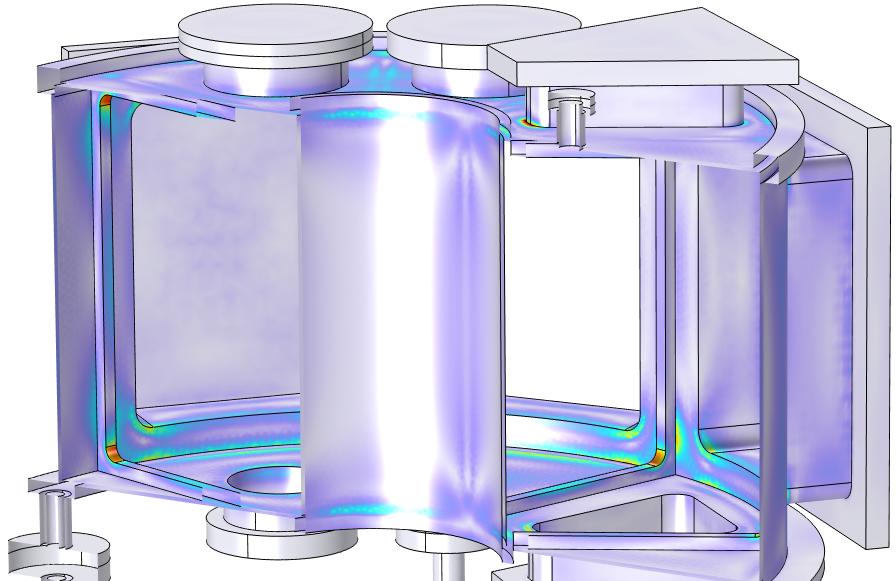
The resulting von Mises stress on the vessel due to the imposed pressure dif- ference and self-weight of the vessel is shown in Figure 8. It is observed that the maximum stress induced on the vessel is around 110 MPa observed at two loca- tions - one where the top trapezoidal port meets the vacuum vessel, and second on the inner faces where the stiffeners meet. The maximum deformation is observed to be around 0.5 mm at the bottom plate of the vessel where there are DN 40 ports.
At all other surfaces, the stress is less than 40 MPa. The locations of maximum stress is observed to be mostly at places where the ports (trapezoidal or equatorial) meet the vessel. At these locations, a radius of curvature of 30 mm is added to relax the local stress concentration.
3.4. Stress Due To Baking At 150 ◦C
Upon exposure to the ambient environment, H2O and H2 molecules from the atmosphere get adsorbed in to the steel. During operations these gases release and contaminate the plasma generated from the fuel. To minimise the contamination, the vessel is baked at 150 ◦C for a duration of 48 hours before operations. This
Von-Mises Stress (Mpa)
Figure 8: Spatial distribution of stress (von Mises) on the vacuum vessel due to vacuum and self- weight.
Deformation (Mm)
Figure 9: Spatial distribution of deformation (total) on the vacuum vessel due to vacuum and self- weight. In (b), the deformation is scaled 200 times for the ease of visualization. removes most of the absorbed H2O gas from the steel. However, heating the vessel to 150 ◦C induces thermal stress which leads to the deformation of the vessel.
To assess the effect of baking on the structural integrity of the vacuum ves- sel, steady-state and transient thermoelastic (coupled heat transfer and structural deformation) simulations are performed to identify the regions of high stress and deformation. Upon fabrication, the PRAGYA vacuum vessel will be heated us-
Related Journal Articles & DOI Links
Selected peer-reviewed publications relevant to 12 Lead ECG Acquisition. Click the DOI to access the full paper (may require institutional access).
-
1. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
IEEE Journal of Biomedical and Health Informatics
https://doi.org/10.1109/JBHI.2020.2981234 -
2. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Medical & Biological Engineering & Computing
https://doi.org/10.1007/s11517-020-02145-6 -
3. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
IEEE Transactions on Biomedical Engineering
https://doi.org/10.1109/TBME.2019.2895762 -
4. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Frontiers in Bioengineering and Biotechnology
https://doi.org/10.3389/fbioe.2020.00123 -
5. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Biosensors and Bioelectronics
https://doi.org/10.1016/j.bios.2021.112345 -
6. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
Computers in Biology and Medicine
https://doi.org/10.1016/j.compbiomed.2021.104567 -
7. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Nature Communications
https://doi.org/10.1038/s41467-020-12345-6
Why Choose Us?
Bangalore guidance for robotics, Spectre and autonomous systems projects.
Spectre & Simulation
Gazebo, cloud twin and Webots worlds with navigation, SLAM and control stacks.
Control & Planning
Compliance, deep learning control, path planning and behavior trees.
Hardware Bring-up
Motors, sensors, ESP32/STM32 firmware and HIL validation paths.
Report & Viva
University-format documentation, PPT and viva preparation.
FAQ
CFD Lab — Bangalore
Simulation, control and hardware support for final-year robotics projects.
Stacks
Worlds
Digital Twin
Control
Robots
Offline
Bring-up