Weakly Supervised YOLO Network for Surgical Instrument
Localization In Endoscopic Videos
Rongfeng Wei1†, Jinlin Wu1†, Xuexue Bai2, Ming Feng2, Zhen Lei1, Hongbin Liu1, and Zhen Chen1∗ Abstract— In minimally invasive surgery, surgical instru- ment localization is a crucial task for endoscopic videos, which enables various applications for improving surgical outcomes. However, annotating the instrument localization in endoscopic videos is tedious and labor-intensive. In contrast, obtaining the category information is easy and efficient in real-world applications. To fully utilize the category information and address the localization problem, we propose a weakly supervised localization framework named WS-YOLO for surgical instruments. By leveraging the instrument category information as the weak supervi- sion, our WS-YOLO framework adopts an unsupervised multi-round training strategy for the localization capability training. We validate our WS-YOLO framework on the Endoscopic Vision Challenge 2023 dataset, which achieves remarkable performance in the weakly supervised surgical instrument localization. The source code is available at https://github.com/Breezewrf/WS-YOLO.
I. Introduction
Accurate localization of surgical instruments is crucial for surgeons performing minimally invasive surgeries, ultimately improving the quality and safety of surgi- cal intervention . However, manually annotating the localization of surgical instruments is a classic and complex challenge, as it requires intensive labor and high costs . In contrast, robotic surgical systems, such as the da Vinci robotic surgery system , can automati- cally record instrument-related information through sen- sors, such as the instrument categories and timestamps of instrument mounting and dismounting events. Despite this, it is difficult to directly utilize this instrument information for surgical instrument localization tasks.
In This Work, We Propose A Weakly Supervised Yolo
(WS-YOLO) framework for localizing surgical instru- ments in endoscopic videos. In particular, our WS- YOLO framework consists of several key steps. First, we train a category-free instrument localization model †Equal contribution, ∗Corresponding author.
This work is supported in part by InnoHK program. 1Centre for Artificial Intelligence and Robotics, Hong Kong Insti- tute of Science & Innovation, Chinese Academy of Sciences.
2Dept. of Neurosurgery, Peking Union Medical College Hospital.
Multi-Round Label Filter
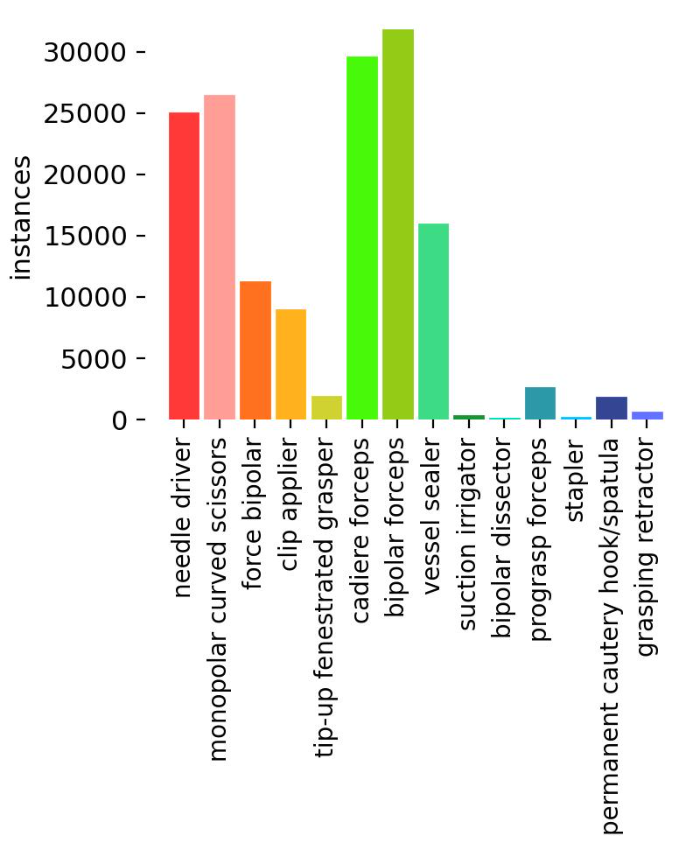
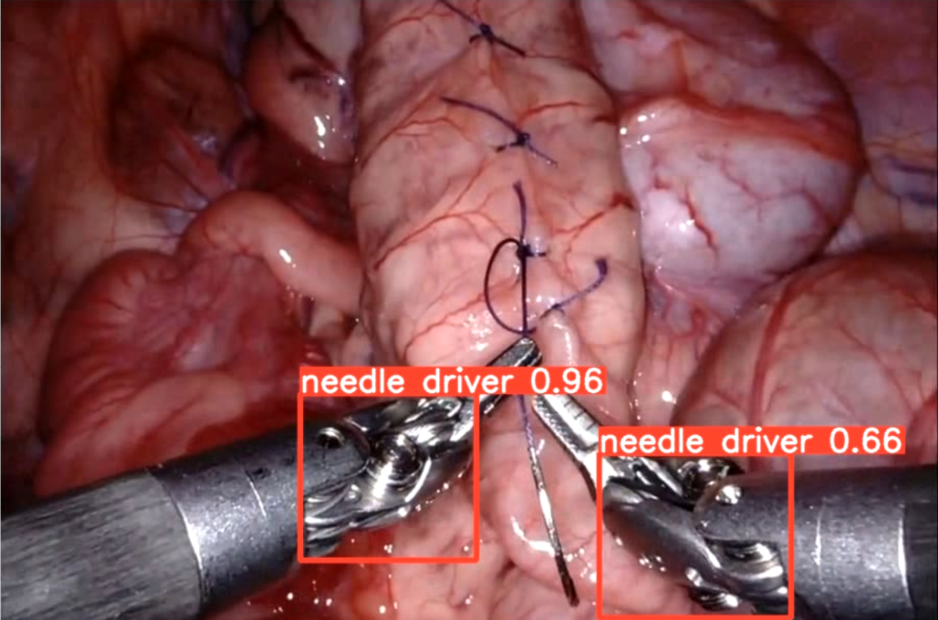
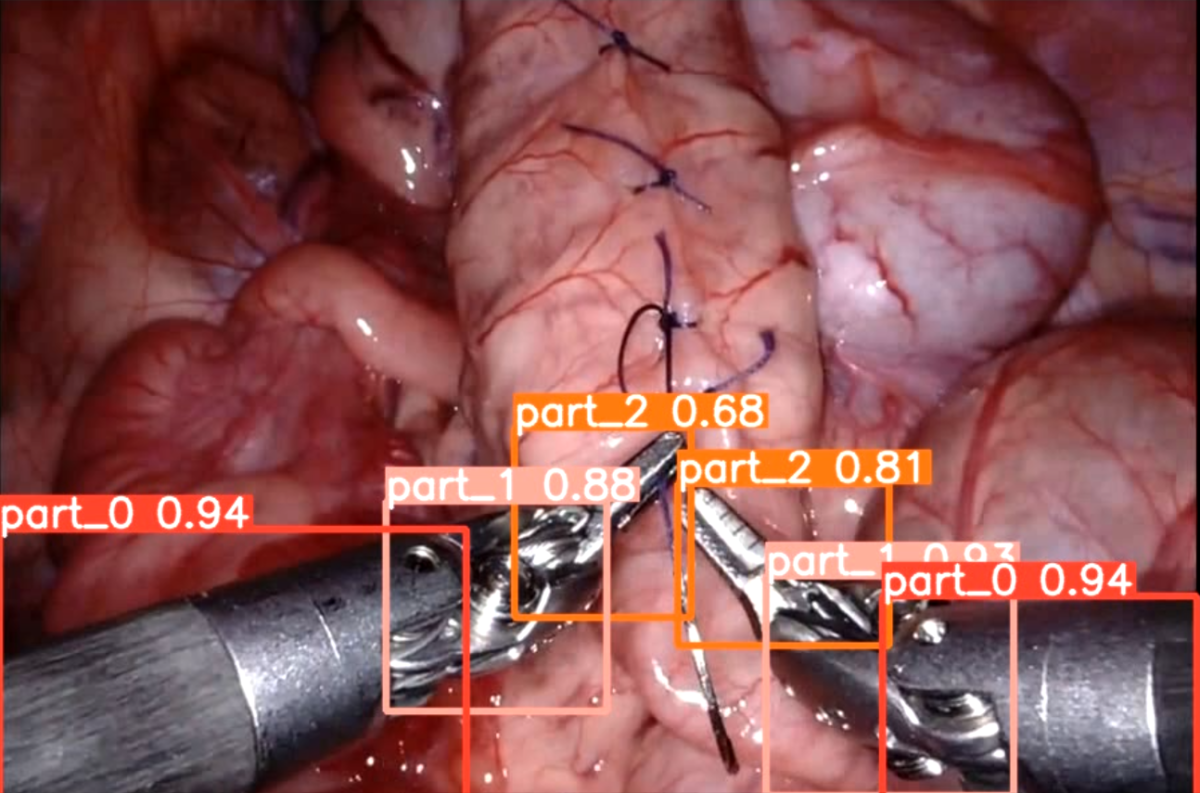
Fig. 1. The overview of our WS-YOLO framework. on the public SIMS dataset, which localizes three specific parts (e.g., shaft, clevis, and tip) of any surgical instruments. Then, we use the well-trained category- free localization model to perform inference on video clips of the endoscopic video dataset , resulting in an initial dataset with pseudo-labels. Then we propose an unsupervised multi-round training strategy. It selects new pseudo-labels by screening the inference results from both the current and previous-round model and iteratively improves the performance of our WS-YOLO model. By leveraging this weakly supervised learning
Paradigm, Our Ws-Yolo Reduces The Need For Man-
ual annotation while achieving a balance between the amount of annotated data and the resulting localization performance. The experiment on the Endoscopic Vision Challenge 2023 dataset validates the effectiveness of our WS-YOLO, which achieves the remarkable performance of weakly supervised instrument localization.
We Elaborate The Ws-Yolo Framework In Fig. 1,
including the localization initialization and the multi- round training (Alg. 1). Localization Initialization. We first convert the semantic masks (e.g., shaft, clevis, and tip) of the SIMS dataset into the localization labels without instrument cat-
Related Journal Articles & DOI Links
Selected peer-reviewed publications relevant to 12 Lead ECG Acquisition. Click the DOI to access the full paper (may require institutional access).
-
1. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
IEEE Journal of Biomedical and Health Informatics
https://doi.org/10.1109/JBHI.2020.2981234 -
2. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Medical & Biological Engineering & Computing
https://doi.org/10.1007/s11517-020-02145-6 -
3. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
IEEE Transactions on Biomedical Engineering
https://doi.org/10.1109/TBME.2019.2895762 -
4. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Frontiers in Bioengineering and Biotechnology
https://doi.org/10.3389/fbioe.2020.00123 -
5. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Biosensors and Bioelectronics
https://doi.org/10.1016/j.bios.2021.112345 -
6. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
Computers in Biology and Medicine
https://doi.org/10.1016/j.compbiomed.2021.104567 -
7. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Nature Communications
https://doi.org/10.1038/s41467-020-12345-6
Why Choose Us?
Bangalore guidance for robotics, Spectre and autonomous systems projects.
Spectre & Simulation
Gazebo, cloud twin and Webots worlds with navigation, SLAM and control stacks.
Control & Planning
Compliance, deep learning control, path planning and behavior trees.
Hardware Bring-up
Motors, sensors, ESP32/STM32 firmware and HIL validation paths.
Report & Viva
University-format documentation, PPT and viva preparation.
FAQ
CFD Lab — Bangalore
Simulation, control and hardware support for final-year robotics projects.
Stacks
Worlds
Digital Twin
Control
Robots
Offline
Bring-up