Is
widely used to recognize users’ intentions. Especially, BCI related to tactile and sensation decoding could provide various effects on many industrial fields such as manufacturing advanced touch displays, controlling robotic devices, and more immersive virtual reality or augmented reality. In this paper, we introduce haptic and sensory perception-based BCI systems called neurohaptics. It is a preliminary study for a variety of scenarios using actual touch and touch imagery paradigms. We designed a novel experimental environment and a device that could acquire brain signals under touching designated materials to generate natural touch and texture sensations. Through the experiment, we collected the electroencephalogram (EEG) signals with respect to four different texture objects. Seven subjects were recruited for the experiment and evaluated classification performances using machine learning and deep learning approaches. Hence, we could confirm the feasibility of decoding actual touch and touch imagery on EEG signals to develop practical neurohaptics.
Electroencephalogram;
tactile information; haptic sensation analysis; touch imagery
I. Introduction
Brain–computer interface (BCI)s are systems that could decode brain signals to understand the intention and status including reprinting/republishing this material for advertising or promotional purposes, creating new collective works, for resale or redistribution to servers or lists, or reuse of any copyrighted component of this work in other works.
This work was partly supported by Institute of Information & Com- munications Technology Planning & Evaluation (IITP) grant funded by Invasive Integrated BCI SW Platform to Control Home Appliances and Development of BCI based Brain and Cognitive Computing Technology of people. BCIs are also used to analyze various tactile sensations related to haptics. Numerous studies have attempted to understand electroencephalogram (EEG) signals because the signals contain significant information about the cognition of
People –. For Decades, Eeg–Based Bcis Focused And
investigated into several paradigms for signal acquisition such as movement-related cortical potential , , event-related
Potential (Erp) , , And Motor Imagery –. As
applications of the BCIs, robotic arm controls , speller systems , , brain–controlled wheelchairs , and the
Neurohaptics – Were Commonly Used For Communica-
tion between human and machines. However, the neurohaptics are relatively few compared to conventional paradigms. Recently, a BCI-based haptic sensation is one of the most interesting topics. The haptic sensation is an electrical sense of objects and surfaces felt through the nerves in the skin of the fingers. Before haptic sensation studies became active in the non-invasive BCI research field, invasive BCI-based haptic studies had begun first. Osborn et al. developed a haptic feedback system that operates on a prosthetic basis. Based on the tactile information obtained through the electronic skin installed on the robot’s prosthetic arm and the sensory recognition information of the subjects obtained through the BCI, the sensory information felt when holding a sharp object was made available to the brain by using a transcutaneous nerve stimulation that could give electrical stimulation to the nerves. Ganzer et al. also implemented a bi-directional communication system of the brain and haptic feedback. Based on brain signals from invasive BCI, they developed a system that could give patients adequate electrical feedback through a functional electrical stimulation (FES) attached to the arm.
When the patient with reduced finger sensation holds the object with a hand, the system amplified the haptic perception
Arxiv:2012.06753V2 [Cs.Hc] 20 Dec 2020
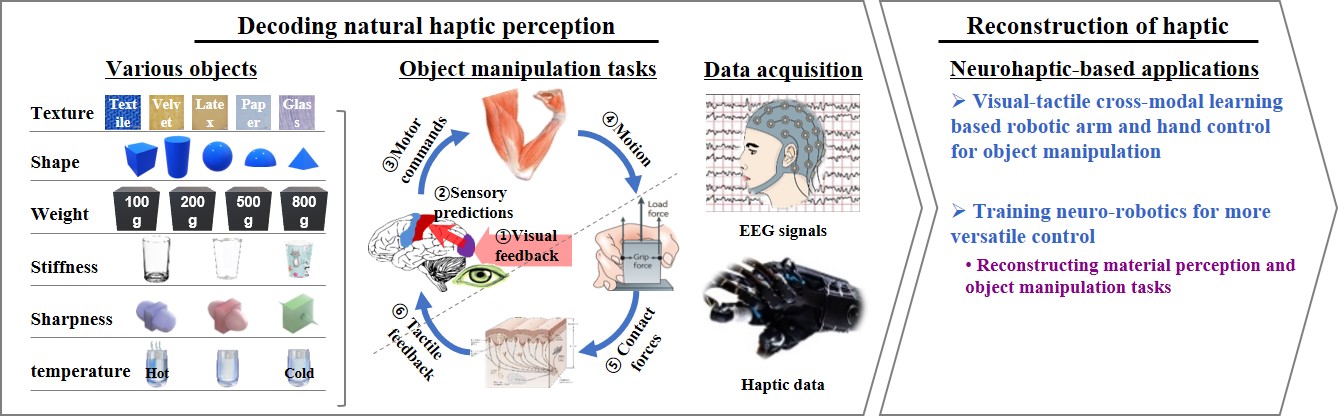
Fig. 1. Overview of decoding natural haptic perception and reconstructing the haptic feedback to develop haptic-related BCI systems. to assist the patient makes a better and stronger grasp through FES. Tayeb et al. proposed a non-invasive BCI system that could implement the same system as the studies described above. They developed a prosthetic arm that can restore the sense of touch and pain. Brain responses are analyzed and decoded to understand the tactile sensory perception, including pain, and identify activated brain regions. Neural activity can be used to design a prosthesis that mimics natural pain withdrawal behavior in humans. The overview in Fig. 1 illustrates what tactile information is being targeted to analyze in recent studies and what purpose and process are using EEG and haptic information.
In this study, we measured EEG signals of 4-class of actual touch and touch imagery (‘Fabric’, ‘Glass’, ‘Paper’, and ‘Fur’). The classes used in the experimental paradigm consist of the most basic haptic perception for analysis of touch sensation. To the best of our knowledge, this is the first attempt that demonstrates the feasibility of classifying the high-level haptic perception which consists of 4-class to develop a high-performance classification model based on a deep learning approach. Second, we achieved robust classifi- cation performance in the 4-class touch perception compared with the chance-level accuracy (0.25).
A. Participants
Seven healthy subjects, who were naive BCI users, have recruited in the experiment (aged 25-38, all right–handed). Before the experiment, each subject was informed of the ex- perimental protocols, paradigms, and purpose. After they had understood, all of them provided their given written consent according to the Declaration of Helsinki. The experimental protocols and environments were reviewed and approved by 2020-0013-01].
B. Experimental Setup
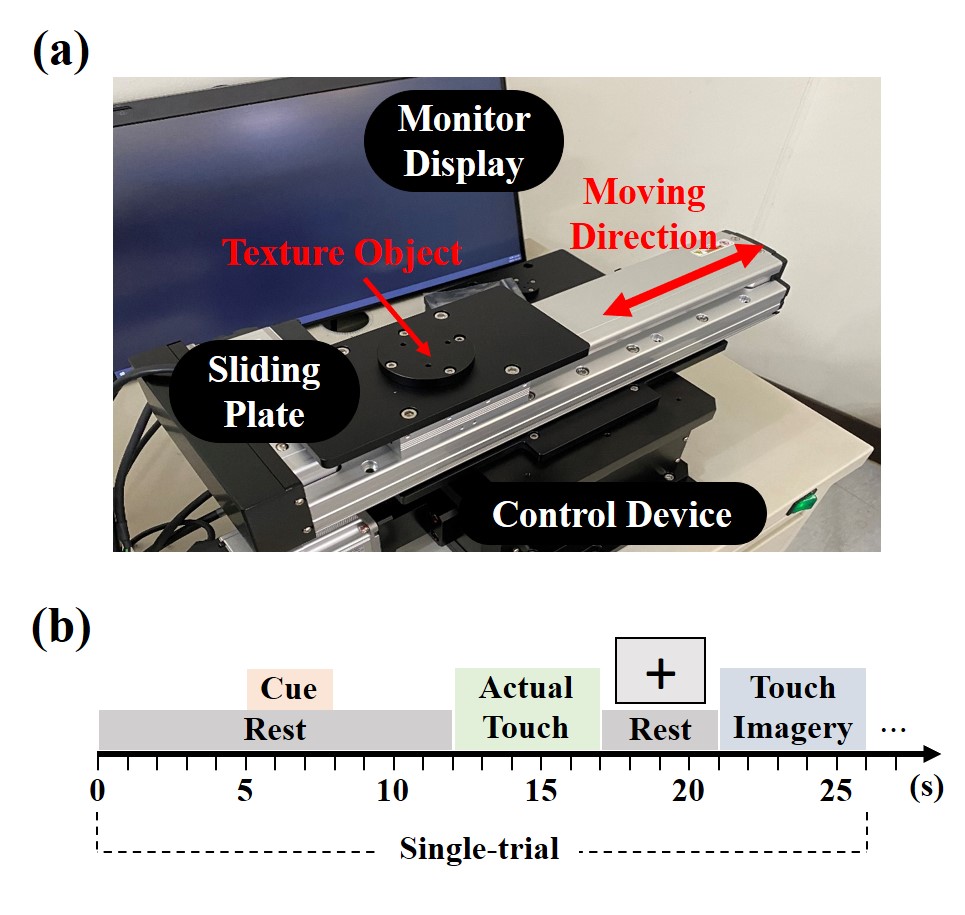
First, a monitor display for touch instruction was put at a distance of 90cm from the subjects. At the same time, Fig. 2.
Experimental setup and protocol to record touch sensation. A self- made instrument for the purpose of obtaining EEG signals under consistent tactile sensation (a) and experimental protocol for recording EEG signals related to the actual touch and the touch imagery (b).
we devised a control device that can give the subject a consistent and uniformed tactile sensation with his hands fixed as depicted in Fig. 2 (a). The subjects were asked to perform actual touch and touch imagery according to the four different tactile objects. Each trial was composed of four phases such as rest, cue/preparation, actual touch, and imagery, as shown in Fig. 2 (b). In the rest phase, the subject took a comfortable rest with restraining eye and body movement. Between the rest phase, the monitor displays one of the texture images (picture of the four texture objects) as a touch cue, and then subjects prepare the touch imagery task according to the cue.
The subjects stared the fixation point during 3 s to avoid an afterimage effect. During the 5 s, The subjects conducted a
Related Journal Articles & DOI Links
Selected peer-reviewed publications relevant to 12 Lead ECG Acquisition. Click the DOI to access the full paper (may require institutional access).
-
1. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
IEEE Journal of Biomedical and Health Informatics
https://doi.org/10.1109/JBHI.2020.2981234 -
2. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Medical & Biological Engineering & Computing
https://doi.org/10.1007/s11517-020-02145-6 -
3. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
IEEE Transactions on Biomedical Engineering
https://doi.org/10.1109/TBME.2019.2895762 -
4. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Frontiers in Bioengineering and Biotechnology
https://doi.org/10.3389/fbioe.2020.00123 -
5. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Biosensors and Bioelectronics
https://doi.org/10.1016/j.bios.2021.112345 -
6. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
Computers in Biology and Medicine
https://doi.org/10.1016/j.compbiomed.2021.104567 -
7. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Nature Communications
https://doi.org/10.1038/s41467-020-12345-6
Why Choose Us?
Bangalore guidance for robotics, Spectre and autonomous systems projects.
Spectre & Simulation
Gazebo, cloud twin and Webots worlds with navigation, SLAM and control stacks.
Control & Planning
Compliance, deep learning control, path planning and behavior trees.
Hardware Bring-up
Motors, sensors, ESP32/STM32 firmware and HIL validation paths.
Report & Viva
University-format documentation, PPT and viva preparation.
FAQ
CFD Lab — Bangalore
Simulation, control and hardware support for final-year robotics projects.
Stacks
Worlds
Digital Twin
Control
Robots
Offline
Bring-up