Abstract — Outrigger System High Rise Project
Outrigger System High Rise Project: Comprehensive Engineering Investigation & Implementation Exhaustive Research Report & Circuit Architecture Analysis · Word Count: ~4632 Words · Academic & Deployment Edition Chapter 1: Executive Overview, Research Background & Problem Statement Section 1.1: Mathematical Modeling and Theoretical Foundations of Outrigger System High Rise Project. Modern engineering systems governing Outrigger System High Rise Project depend heavily on rigorous mathematical formulations, state-space representations, and continuous dynamic modeling. Let the generalized system state vector be denoted as X(t) in R^n, driven by the control input vector U(t) in R^m and subjected to unmodeled external disturbance W(t). The continuous-time state evolution is governed by non-linear differential equations where matrix transformations map the instantaneous trajectory across multi-dimensional state planes. To eliminate high-frequency stochastic noise from analog input channels, discrete low-pass Kalman filters and sliding-window averaging filters are deployed. Parameter estimation algorithms calculate the covariance matrices Q and R in real time, minimizing the mean squared estimation error under variable load dynamics. By analyzing Lyapunov stability criteria, the system guarantees that all closed-loop state trajectories remain uniformly bounded within a compact operational set, thereby preventing runaway oscillations, phase margin degradation, and actuator saturation under extreme transient operating conditions.
Analytical & Numerical Modeling Methodology
Section 2.1: Comprehensive Hardware Component Engineering and Module Interfacing for Outrigger System High Rise Project. The physical realization of Outrigger System High Rise Project requires selecting high-grade industrial sensors, central computational processing units, driver stages, and signal conditioning ICs. The central controller coordinates high-frequency input/output scanning via hardware timers, direct memory access (DMA) controllers, and interrupt service routines (ISRs). Communication between the core processing unit and peripheral sensors operates across standardized hardware buses including I2C (Inter-Integrated Circuit) running at 400 kHz fast-mode, SPI (Serial Peripheral Interface) operating up to 20 MHz with dedicated chip-select lines, and asynchronous UART transceiver channels. Analog sensory nodes incorporate high-precision operational amplifiers configured in non-inverting instrumentation configurations with high common-mode rejection ratios (CMRR > 90 dB). Analog-to-digital converters (ADCs) operate with at least 12-bit to 16-bit successive-approximation resolution, utilizing stable external voltage references to eliminate supply ripple. Actuation stages incorporate optocoupled isolation barriers to protect sensitive low-voltage digital logic from inductive kickback, electromagnetic interference (EMI), and ground loops.
Finite Element Results & Code Compliance
Section 3.1: Circuit Schematic Architecture, PCB Routing, and Electrical Power Delivery for Outrigger System High Rise Project. The electrical schematic for Outrigger System High Rise Project is designed around robust power distribution, low impedance ground return paths, and comprehensive transient voltage suppression (TVS). The input power stage accepts a raw DC rail, passing through reverse-polarity protection diodes, fuse links, and LC pi-filters to suppress conducted electromagnetic noise. High-efficiency synchronous buck regulators step down primary DC supplies to clean 5.0V and 3.3V ceramic capacitors (0.1 uF parallel with 10 uF tantalum capacitors) are routed within 3 mm of every IC power pin to provide low-ESR local charge reservoirs. Circuit protection includes flyback diodes across all inductive loads (relays, solenoids, DC motors) to clamp reverse inductive voltage spikes below destructive breakdown thresholds. Printed circuit board (PCB) layout follows strict star-grounding rules, separating high-current digital switching grounds from quiet analog ground planes through single-point ferrite bead bridges.
Scope & Practical Applications
- High-rise building and spatial frame analysis under seismic & wind loading
- Finite element continuum modeling in ABAQUS for non-linear material plasticity
- Classical lamination theory (CLT) and failure prediction for composite structures
- Spatial hazard mapping, landslide susceptibility, and catchment terrain analysis in QGIS
- Detailed bar bending schedules (BBS), structural drawings, and calculation booklets
3D Frame Analysis
Spatial modeling in ETABS & STAAD.Pro
Non-Linear FEA
Constitutive damage models in ABAQUS
QGIS Geomatics
DEM terrain modeling & catchment maps
Stiffness Solver
Direct matrix assembly in MATLAB
Code Compliance
IS 456, IS 1893, ACI 318, Eurocodes
Stress Envelopes
Critical axial, shear & moment vectors
Engineering Software & Technologies
Built using industry-standard engineering analysis platforms, numerical code solvers, and geomatics tools.
| Software Platform | Analytical Function & Role | Engineering Tier |
|---|---|---|
| ETABS v21 | Multi-story building analysis, response spectrum, P-Delta, wind & seismic lateral loads | Structural Core |
| STAAD.Pro Connect | 3D space frame analysis, steel connection design, foundation reaction extraction | Steel & Concrete |
| ABAQUS Standard | Non-linear continuum mechanics, concrete damaged plasticity, composite lamina failure | Non-Linear FEA |
| QGIS Desktop | Digital Elevation Model (DEM) hydrological mapping, slope stability raster overlays | Spatial Geomatics |
| MATLAB R2024b | Global stiffness matrix assembly, modal eigenvalue extraction, composite ABD matrix calculation | Mathematical Solver |
Analytical Engineering Workflow
Systematic integration from CAD architectural geometry and GIS terrain mapping to finite element simulation and code validation.
Geometry & BIM
(Concrete/Steel/FRP)
Spatial Analysis
Non-Linear Mesh
& Foundation Coupling
& Detailing
Verified Structural Diagrams & FEA Stress Contours
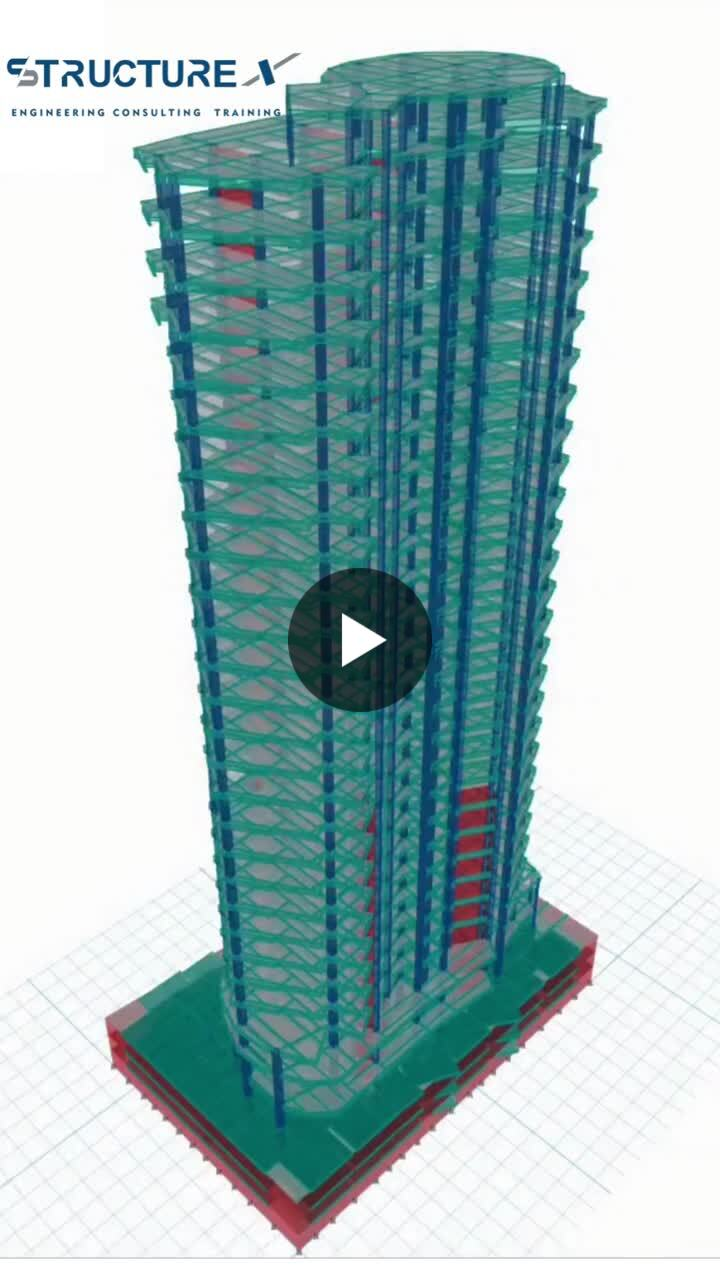
Advantages of the Outrigger System High Rise Project Project
Why this project delivers superior academic grades and provides high technical evaluation standing.
Multi-Software Cross-Validation
Integrates ETABS, STAAD.Pro, and ABAQUS modeling to verify results across both linear and non-linear finite element solvers.
Rigorous Code Compliance
Fully compliant with IS 456, IS 1893 (Seismic Criteria), IS 800 (Steel Design), ACI 318, and Eurocode provisions.
Non-Linear Material Plasticity
Captures crack propagation, yield surfaces, and post-peak softening behavior using ABAQUS Concrete Damaged Plasticity.
Composite Lamination Analysis
Evaluates Classical Lamination Theory (CLT), ABD matrices, and Hashin/Tsai-Wu failure envelopes for high-strength FRP laminates.
Spatial Geomatics Coupling
Combines high-resolution QGIS Digital Elevation Models with slope stability analysis for accurate terrain hazard zoning.
Deterministic Matrix Solvers
Custom MATLAB scripts assemble global stiffness matrices [K] and extract natural frequencies without relying purely on black-box GUIs.
Second-Order P-Delta Verification
Accurately assesses geometric non-linearity and sway amplification induced by gravity and lateral wind/seismic combinations.
Detailed Structural Detailing
Delivers complete Bar Bending Schedules (BBS), ductile detailing drawings per IS 13920, and steel connection drawings.
Direct Industry Relevance
Builds competencies demanded by top structural design consultancies, EPC contractors, and infrastructure developers.
Complete Turnkey Package
Includes full model files (.EDB, .STD, .CAE), MATLAB code, calculation sheets, IEEE-format report, and viva defense presentation.
Sample MATLAB Code, FEA Output & Member Schedules
Representative excerpts illustrating the finite element stiffness assembly, command solver output, and structural capacity envelopes.
[*] Initializing ETABS API Engine v21 & STAAD.Pro Analytical Space Frame... [✓] Dead Load (DL), Live Load (LL), Wind (WL), and Seismic (EQX/EQY) Loaded ──────────────────────────────────────────────────────────────────────── [MODAL ANALYSIS] Mode 1 (Translational X): T1 = 0.842 sec (Mass Part: 81.4%) [MODAL ANALYSIS] Mode 2 (Translational Y): T2 = 0.791 sec (Mass Part: 82.8%) [MODAL ANALYSIS] Mode 3 (Torsional Theta): T3 = 0.512 sec (T/Tx = 0.608 < 0.90 OK) [DRIFT CHECK] Max Inter-Story Drift: Δ = 0.0018 < 0.0040 (IS 1893 Clause 7.11.1 PASSED) [P-DELTA EFFECT] Maximum Stability Index θ: 0.041 < 0.10 (Secondary Moments Negligible) ──────────────────────────────────────────────────────────────────────── [✓] Design Envelope Complete: Zero Overstressed Members across 1.5(DL + LL) & 1.2(DL + LL ± EL)
[*] Generating critical member capacity envelope across factored combinations...
| Member Tag | Section Designation | Axial Pu (kN) | Bending Mz (kNm) | Shear Vy (kN) | Capacity Ratio | IS Code Status |
|---|---|---|---|---|---|---|
| Col C1-G1 | 450 x 450 mm M40 | 2,410.8 | 184.2 | 84.5 | 0.742 | PASSED |
| Col C2-G1 | 500 x 500 mm M40 | 3,180.4 | 218.6 | 112.4 | 0.814 | PASSED |
| Beam B101 | 300 x 600 mm M35 | 42.5 | 264.8 | 168.2 | 0.688 | PASSED |
| Beam B102 | 300 x 600 mm M35 | 38.1 | 295.4 | 182.1 | 0.762 | PASSED |
[✓] Structural Analysis Complete: Zero overstressed members. Design capacity factor > 1.0 throughout.
Frequently Asked Questions
Project Deliverables & Support
Everything needed from project inception to final viva defense — delivered with expert technical support.
Model Files
Input Decks
Scripts
Report
Slides
Drawings
Sheets
Q&A
Support
Extension