Complete Technical Paper Content — Sensitive Data Exposure Scanner In Web Applications
Overview & System Context
Sensitive Data Exposure Scanner In Web Applications: Comprehensive Web-Sourced Technical Investigation Exhaustive Research Dossier · Pure Web-Scraped Content: ~9652 Words · Real Software Screenshots: 3 1. Executive Overview & Technical Background An image scanner (often abbreviated to just scanner) is a device that optically scans images, printed text, handwriting, or an object and converts it to a digital image. The most common type of scanner used in the home and the office is the flatbed scanner, where the document is placed on a glass bed. A sheetfed scanner, which moves the page across an image sensor using a series of rollers, may be used to scan one page of a document at a time or multiple pages, as in an automatic document feeder. A handheld scanner is a portable version of an image scanner that can be used on any flat surface. Scans are typically downloaded to the computer that the scanner is connected to, although some scanners are able to store scans on standalone flash media (e.g., memory cards and USB drives). Modern scanners typically use a charge-coupled device (CCD) or a contact image sensor (CIS) as the image sensor, whereas drum scanners, developed earlier and still used for the highest possible image quality, use a photomultiplier tube (PMT) as the image sensor. Document cameras, which use commodity or specialized high-resolution cameras, photograph documents all at once.
Image scanners are considered the successors of early facsimile (fax) and wirephoto machines. Unlike scanners, these devices were used to transmit images over long distances rather than for processing and storing images locally. The earliest attempt at a fax machine was patented in 1843 by the Scottish clockmaker Alexander Bain but never put into production. In his design, a metal stylus linked to a pendulum scans across a copper plate with a raised image. When the stylus makes contact with a raised part of the plate, it sends a pulse across a pair of wires to a receiver containing an electrode linked to another pendulum. A piece of paper impregnated with an electrochemically sensitive solution resides underneath the electrode and changes color whenever a pulse reaches the electrode. A gear advances the copper plate and paper in tandem with each swing of the pendulum; over time, the result is a perfect reproduction of the copper plate. In Bain's system, it is critical that the pendulums of the transceiver and receiver are in perfect step, or else the reproduced image will be distorted. In 1847, the English physicist Frederick Bakewell developed the first working fax machine. Bakewell's machine was similar to Bain's but used a revolving drum coated in tinfoil, with non-conductive ink painted on the foil and a stylus that scans across the drum and sends a pulse down a pair of wires when it contacts a conductive point on the foil. The receiver contains an electrode that touches a sheet of chemically treated paper, which changes color when the electrode receives a pulse; the result is a reverse contrast (white-on-blue) reproduction of the original image. Bakewell's fax machine was marginally more successful than Bain's but suffered from the same synchronization issues. In 1862, Giovanni Caselli solved this with the pantelegraph, the first fax machine put into regular service. Largely based on Bain's design, it ensured complete synchronization by flanking the pendulums of both the transceiver and receiver between two magnetic regulators, which become magnetized with each swing of the pendulum and become demagnetized when the pendulum reaches the maxima and minima of each oscillation. In 1893, the American engineer Elisha Gray introduced the telautograph, the first widely commercially successful fax machine that used linkage bars translating x- and y-axis motion at the receiver to scan a pen across the paper and strike it only when actuated by the stylus moving across the transceiver drum. Because it could use commodity stationery paper, it became popular in business and hospitals. In 1902, the German engineer Arthur Korn introduced the phototelautograph, a fax machine that used a light-sensitive selenium cell to scan a paper to be copied, instead of relying on a metallic drum and stylus. It was even more commercially successful than Gray's machine and became the basis for wirephoto (also known as telephotography) machines used by newspapers around the world from the early 1900s onward.
The first digital imaging system was the Bartlane system in 1920. Named after the pair who invented it, Harry G. Bartholomew and Maynard D. McFarlane, the Bartlane system used zinc plates etched with an image from a film negative projected at five different exposure levels to correspond to five quantization levels. All five plates are affixed to a long, motor-driven rotating cylinder, with five equidistant contacts scanning over each plate at the same starting position. The Bartlane system was initially used exclusively by telegraph, with the five-bit Baudot code used to transmit the grayscale digital image. In 1921, the system was modified for offline use, with a five-bit paper tape punch punching holes depending on whether its connections to the contacts are bridged or not. The result was a stored digital image with five gray levels. Reproduction of the image was achieved with a lamp passing over the punched holes, exposing five different intensities of light onto a film negative. The first scanner to store its images digitally onto a computer was a drum scanner built in 1957 at the National Bureau of Standards (NBS, later NIST) by a team led by Russell A. Kirsch. It used a photomultiplier tube to detect light at a given point and produced an amplified signal that a computer could read and store into memory. The computer of choice at the time was the SEAC mainframe; the maximum horizontal resolution that the SEAC was capable of processing was 176 pixels. The first image ever scanned on this machine was a photograph of Kirsch's three-month-old son, Walden. In 1969, Dacom introduced the 111 fax machine, which was the first digital fax machine to employ data compression using an on-board computer. It employed a flatbed design with a continuous feed capable of scanning up to letter paper in 1-bit monochrome (black and white).
The first flatbed scanner used for digital image processing was the Autokon line introduced by ECRM Inc. in 1975. The inaugural Autokon 8400 used a laser beam to scan pages up to 11 by 14 inches at a maximum resolution of 1000 lines per inch. Although it was only capable of scanning in 1-bit monochrome, the on-board processor was capable of halftoning, unsharp masking, contrast adjustment, and anamorphic distortions, among other features. The Autokon 8400 could either be connected to a film recorder to create a negative for producing plates or connected to a mainframe or minicomputer for further image processing and digital storage. The Autokon series was expanded over the following two decades and enjoyed widespread use in newspapers and prepress. In 1977, Raymond Kurzweil, of his start-up company Kurzweil Computer Products, released the Kurzweil Reading Machine, which was the first flatbed scanner with a charge-coupled device (CCD) imaging element. The Kurzweil Reading Machine was invented to assist blind people in reading books that had not been translated to braille. It comprised the image scanner and a Data General Nova minicomputer—the latter performing the image processing, optical character recognition (OCR), and speech synthesis. The first scanners for personal computers appeared in the mid-1980s, starting with ThunderScan for the Macintosh in December 1984. Designed by Andy Hertzfeld and released by Thunderware Inc., the ThunderScan contains a specialized image sensor built into a plastic housing the same shape as the ink ribbon cartridge of Apple's ImageWriter printer. The ThunderScan slots into the ImageWriter's ribbon carrier and connects to both the ImageWriter and the Macintosh simultaneously. The ImageWriter's carriage, controlled by the ThunderScan, moves left-to-right to scan one 200-dpi (dots per inch) line at a time, with the carriage return serving to advance the scanner down the print to be scanned. The ThunderScan was the Macintosh's first scanner and sold well but operated very slowly and was only capable of scanning prints at 1-bit monochrome. In 1999, Canon iterated on this idea with the IS-22, a cartridge that fit into their inkjet printers to convert them into sheetfed scanners. In early 1985, Datacopy released the first flatbed scanner for the IBM PC, the Datacopy Model 700. Based on a CCD imaging element, the Model 700 was capable of scanning letter-sized documents at a maximum resolution of 200 dpi at 1-bit monochrome. The Model 700 came with a special interface card for connecting to the PC, and an optional, aftermarket OCR software card and software package were sold for the Model 700. In April 1985, LaserFAX Inc. introduced a CCD-based color flatbed scanner, the SpectraSCAN 200 (later rebranded the SpectraFAX 200), for the IBM PC. The SpectraSCAN 200 worked by placing color filters over the CCD and taking four passes (three for each primary color and one for black) per scan to build up a color reproduction. The SpectraSCAN 200 took between two and three minutes to produce a scan of a letter-sized print at 200-dpi; its grayscale counterpart, the DS-200, took only 30 seconds to make a scan at the same size and resolution. The SpectraSCAN was the first flatbed scanner capable of scanning in color. The first relatively affordable flatbed scanner for personal computers appeared in February 1987 with Hewlett-Packard's ScanJet, which was capable of scanning 4-bit (64-shade) grayscale images at a maximum resolution of 300 dpi. By the beginning of 1988, the ScanJet had accounted for 27 percent of all scanner sales in terms of dollar volume, per Gartner Dataquest. In February 1989, the company introduced the ScanJet Plus, which increased the bit depth to 8 bits (256 shades) while costing only US$200 more than the original ScanJet's $1990 (equivalent to $5,169 in 2025). This led to a massive price drop in grayscale scanners with equivalent or lesser features in the market. The number of third-party developers producing software and hardware supporting these scanners jumped dramatically in turn, effectively popularizing the scanner for the personal computer user. By 1999, the cost of the average color-capable scanner had dropped to $300 (equivalent to $580 in 2025). That year, Computer Shopper declared 1999 "the year that scanners finally became a mainstream commodity".
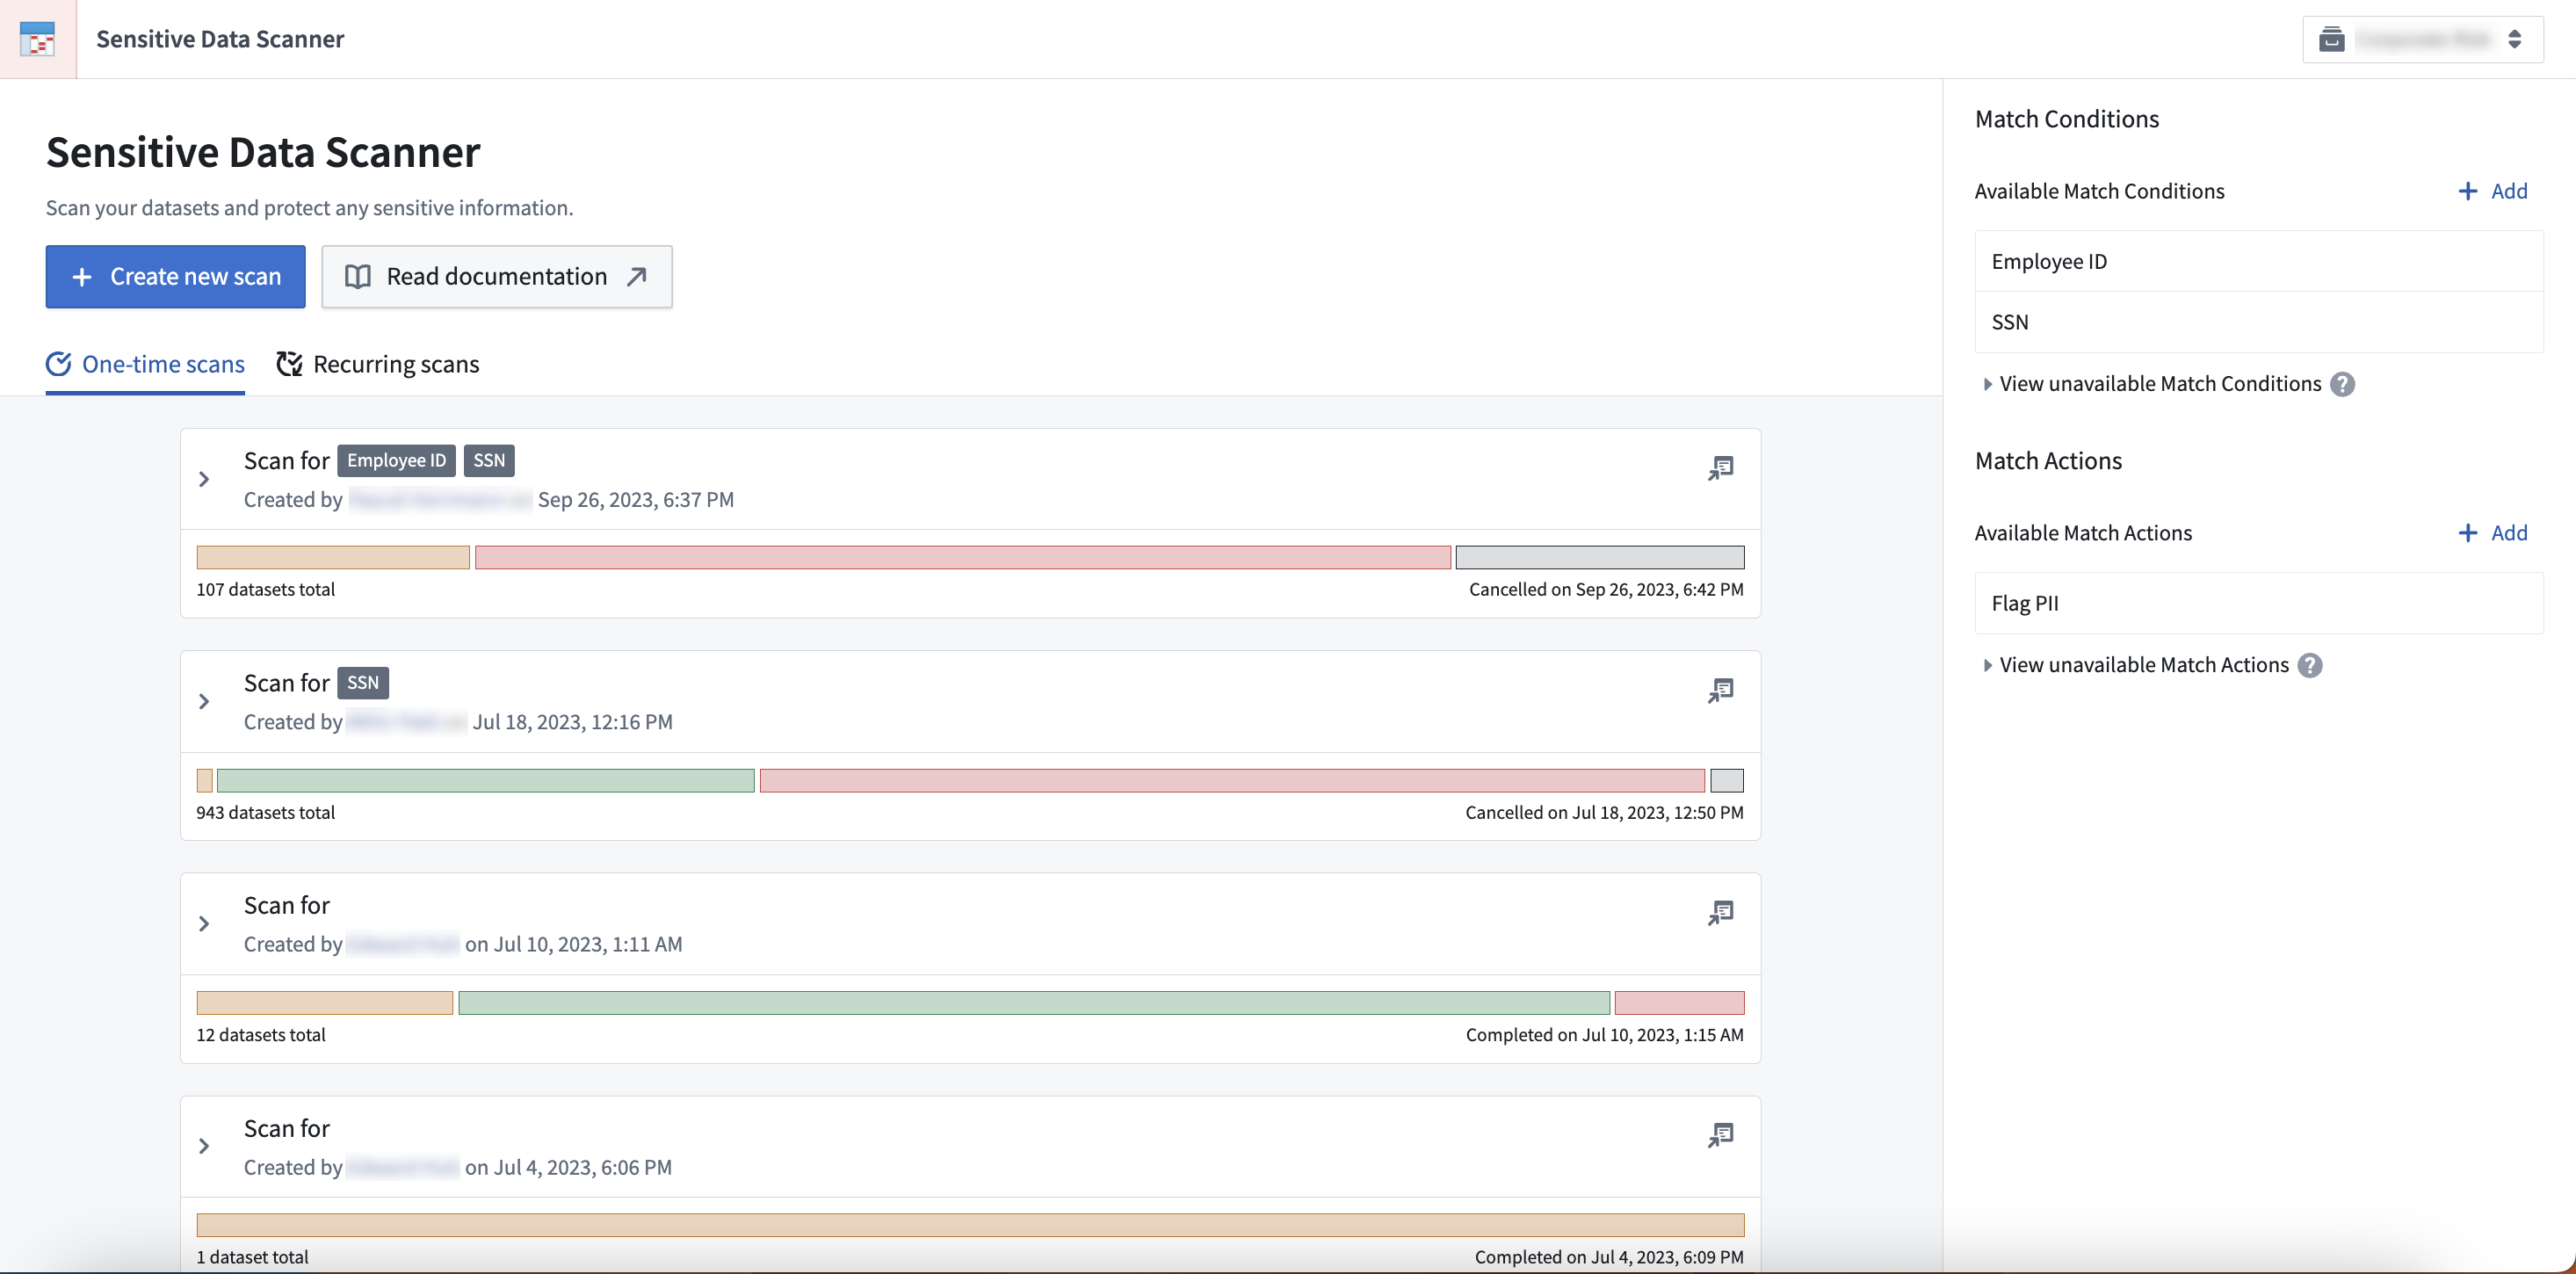
Figure 1: Sensitive Data Scanner • Overview • Palantir A flatbed scanner is a type of scanner that provides a glass bed (platen) on which the object to be scanned lies motionless. The scanning element moves vertically from under the glass, scanning either the entirety of the platen or a predetermined portion. The driver software for most flatbed scanners allows users to prescan their documents—in essence, to take a quick, low-resolution pass at a document in order to judge what area of the document should be scanned (if not the entirety of it), before scanning it at a higher resolution. Some flatbed scanners incorporate sheet-feeding mechanisms called automatic document feeders (ADFs) that use the same scanning element as the flatbed portion. This type of scanner is sometimes called a reflective scanner, because it works by shining white light onto the object to be scanned and reading the intensity and color of light that is reflected from it, usually a line at a time. They are designed for scanning prints or other flat, opaque materials; can be used as a sort of lensless camera to directly digitize flat objects like leaves. Some models of flatbed scanners have available transparency adapters or incorporate a transparency unit for converting film originals to digital files, which—for a number of reasons—in most cases, are not very well suited to scanning film. But a minority of those small number of models that resolved most of the issues and can produce similar results to film scanners, called "photo flatbed" scanners, have the distinct advantage in allowing more versatility over the film format that can be scanned. Also, switching between reflective and transparency scanning can be done in software.
A sheetfed scanner, also known as a document feeder, is a type of scanner that uses motor-driven rollers to move one single sheet of paper at a time past a stationary scanning element (two scanning elements, in the case of scanners with duplex functionality). Unlike flatbed scanners, sheetfed scanners are not equipped to scan bound material such as books or magazines, nor are they suitable for any material thicker than plain printer paper. Some sheetfed scanners, called automatic document feeders (ADFs), are capable of scanning several sheets in one session, although others only accept one page at a time. Some sheetfed scanners are portable, powered by batteries, and have their own storage, eventually transferring stored scans to a computer.
A handheld scanner is a type of scanner that must be manually dragged or gilded by hand across the surface of the object to be scanned. Scanning documents in this manner requires a steady hand, as an uneven scanning rate produces distorted images. Some handheld scanners have an indicator light on the scanner for this purpose, actuating if the user is moving the scanner too fast. They typically have at least one button that starts the scan when pressed; it is held by the user for the duration of the scan. Some other handheld scanners have switches to set the optical resolution, as well as a roller, which generates a clock pulse for synchronization with the computer. Older hand scanners were monochrome, and produced light from an array of green LEDs to illuminate the image; later ones scan in monochrome or color, as desired. A hand scanner may also have a small window through which the document being scanned could be viewed. As hand scanners are much narrower than most normal document or book sizes, software (or the end user) needed to combine several narrow "strips" of scanned documents to produce the finished article. Inexpensive, portable, battery-powered or USB-powered wand scanners and pen scanners, typically capable of scanning an area as wide as a normal letter and much longer, remain available as of 2024. Some computer mice can also scan documents.
A drum scanner is a type of scanner that uses a clear, motor-driven rotating cylinder (drum) onto which a print, a film negative, a transparency, or any other flat object is taped or otherwise secured. A beam of light either projects past, or reflects off, the material to be scanned onto a series of mirrors, which focus the beam onto the drum scanner's photomultiplier tube (PMT). After one revolution, the beam of light moves down a single step. When scanning transparent media, such as negatives, a light beam is directed from within the cylinder onto the media; when scanning opaque items, a light beam from above is reflected off the surface of the media. When only one PMT is present, three passes of the image are required for a full-color RGB scan. When three PMTs are present, only a single pass is required. The photomultiplier tubes of drum scanners offer superior dynamic range to that of CCD sensors. For this reason, drum scanners can extract more detail from very dark shadow areas of a transparency than flatbed scanners using CCD sensors. The smaller dynamic range of the CCD sensors (versus photomultiplier tubes) can lead to loss of shadow detail, especially when scanning very dense transparency film.
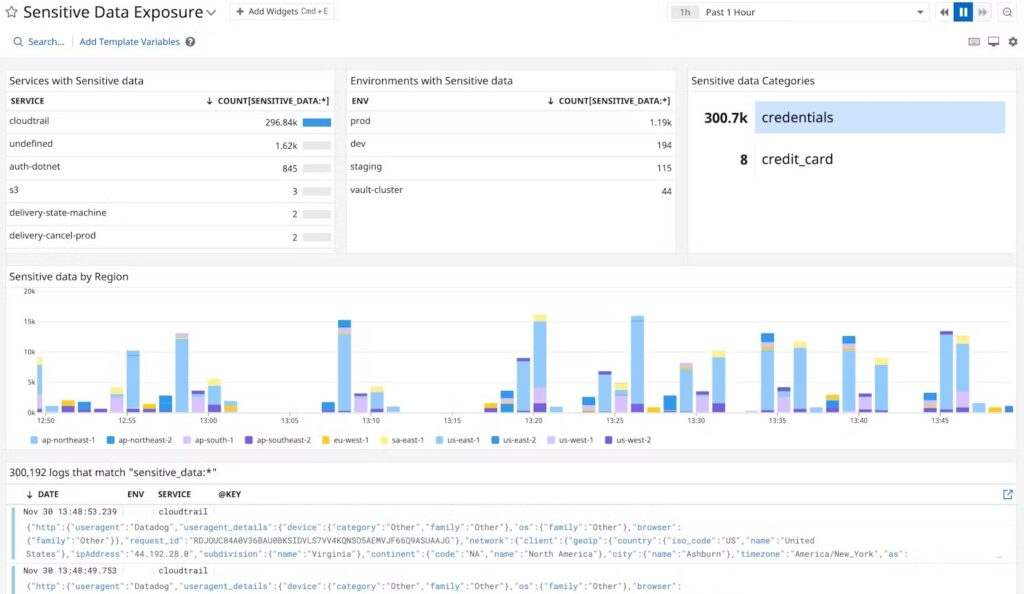
Drum scanners are also able to resolve true detail in excess of 10000 dpi, producing higher-resolution scans than any CCD scanner. Figure 2: Best Sensitive Data Discovery Software - Planet Compliance An overhead scanner is a type of scanner that places the scanning element in a housing on top of a vertical post, hovering above the document or object to be scanned, which lies stationary on an open-air bed. Chinon Industries patented a specific type of overhead scanner, which uses a rotating mirror to reflect the contents of the bed onto a linear CCD, in 1987. Although very flexible—allowing users to scan not only two-dimensional prints and documents but any 3D object, of any size—the Chinon design required the user to provide uniform illumination of the object to be scanned and was more cumbersome to set up. A more modern type of overhead scanner is a document camera (also known as a video scanner), which uses a digital camera to capture a document all at once. Most document cameras output live video of the document and are usually reserved for displaying documents to a live audience, but they may also be used as replacements for image scanners, capturing a single frame of the output as an image file. Document cameras may even use the same APIs as scanners when connected to computers. A planetary scanner is a type of very-high-resolution document camera used for capturing certain fragile documents. A book scanner is another kind of document camera, pairing a digital camera with a scanning area defined by a mat to assist in scanning books. Some more advanced models of book scanners project a laser onto the page for calibration and software skew correction.
A film scanner, also known as a slide scanner or a transparency scanner, is a type of specialized flatbed scanner specifically for scanning film negatives and slides. A typical film scanner works by passing a narrowly focused beam of light through the film and reading the intensity and color of the light that emerges. The lowest-cost dedicated film scanners can be had for less than $50, and they might be sufficient for modest needs. From there they inch up in staggered levels of quality and advanced features upward of five figures.
Image scanners are usually used in conjunction with a computer which controls the scanner and stores scans. Small portable scanners, either sheetfed or handheld and operated by batteries and with storage capability, are available for use away from a computer; stored scans can be transferred later. Many can scan both small documents such as business cards and till receipts, as well as letter-sized documents.
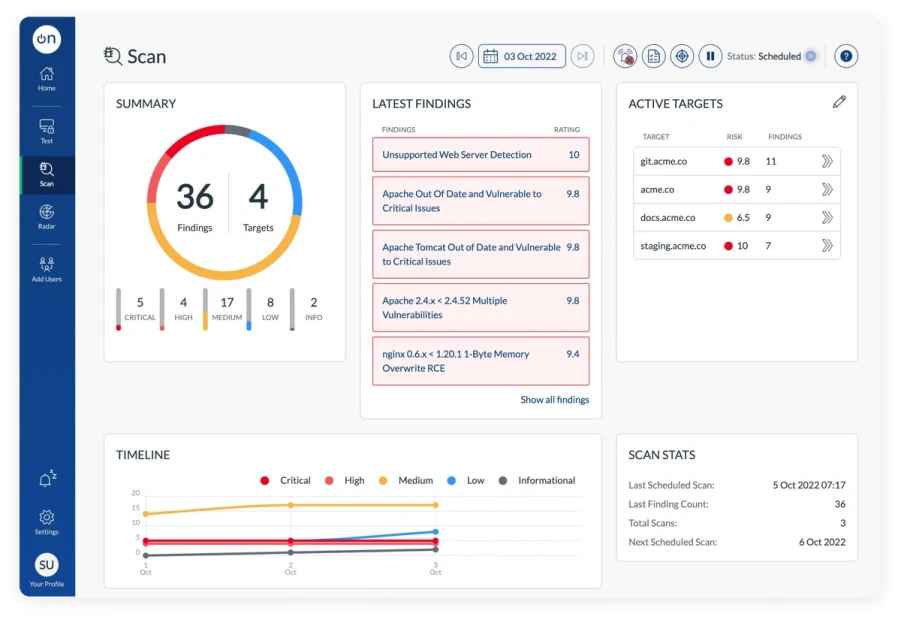
Document scanning apps primarily designed to handle documents and output PDF, and sometimes JPEG, files Photo scanning apps that output JPEG files, and have editing functions useful for photo rather than document editing; Barcode-like QR code scanning apps that then search the internet for information associated with the code. Figure 3: Open Source Vulnerability Assessment Tools & Scanners | LinuxSecuri...
Scanners equipped with charge-coupled device (CCD) scanning elements require a sophisticated series of mirrors and lenses to reproduce an image, but the result of this complexity is a much higher-quality scan. Because CCDs have a much greater depth of field, they are more forgiving when it comes to scanning documents that are difficult to get perfectly flat against the platen (such as bound books).
Scanners equipped with contact image sensor (CIS) scanning elements are designed to be in near-direct contact with the document to be scanned and thus do not require the complex optics of CCDs scanners. However, their depth of field is much worse, resulting in blurry scans if the scanned document is not perfectly flush against the platten. Because the sensors require far less power than CCD scanners, CIS scanners are able to be manufactured down to a low cost and are typically much lighter in weight and depth than CCD scanners.
2. System Architecture & Core Working Principles Scans must virtually always be transferred from the scanner to a computer or information storage system for further processing or storage. There are two basic issues: (1) how the scanner is physically connected to the computer and (2) how the application retrieves the information from the scanner.
Parallel port – Connecting through a parallel port is the slowest common transfer method. Early scanners had parallel port connections that could not transfer data faster than 70 kilobytes/second. The primary advantage of the parallel port connection was economic and user skill level: it avoided adding an interface card to the computer. GPIB – General Purpose Interface Bus. Certain drum scanners like the Howtek D4000 featured both a SCSI and GPIB interface. The latter conforms to the IEEE-488 standard, introduced in the mid-1970s. The GPIB interface has only been used by a few scanner manufacturers, mostly serving the DOS/Windows environment. For Apple Macintosh systems, National Instruments provided a NuBus GPIB interface card. Small Computer System Interface (SCSI) – SCSI is rarely used since the early 21st century, supported only by computers with a SCSI interface, either on a card or built-in. During the evolution of the SCSI standard, speeds increased. Widely available and easily set up USB and Firewire largely supplanted SCSI. Universal Serial Bus (USB) – USB scanners can transfer data quickly. The early USB 1.1 standard could transfer data at 1.5 megabytes per second (slower than SCSI), but the later USB 2.0/3.0 standards can transfer at more than 20/60 megabytes per second in practice.
FireWire – Also known as IEEE-1394, FireWire is an interface of comparable speed to USB 2.0. Possible FireWire speeds are 25, 50, and 100, 400, and 800 megabits per second, but devices may not support all speeds. Proprietary interfaces – Bespoke interfaces were used on some early scanners that used a proprietary interface card rather than a standard interface. TWAIN – An API used by most scanners. Originally used for low-end and home-use equipment, it is now widely used for large-volume scanning. SANE (Scanner Access Now Easy) – A free/open-source API for accessing scanners. Originally developed for Unix and Linux operating systems, it has been ported to OS/2, Mac OS X, and Microsoft Windows. Unlike TWAIN, SANE does not handle the user interface. This allows batch scans and transparent network access without any special support from the device driver. Windows Image Acquisition (WIA) – An API provided by Microsoft for use on Microsoft Windows. ImageCaptureCore - A Cocoa API used by Apple devices, replacing the Carbon-based ImageCapture Services.
Image and Scanner Interface Specification (ISIS) – Created by Pixel Translations, which still uses SCSI-2 for performance reasons, ISIS is used by large, departmental-scale, machines. Document processing requirements differ from those of image scanning. These requirements include scanning speed, automated paper feed, and the ability to automatically scan both the front and the back of a document. On the other hand, image scanning typically requires the ability to handle fragile and or three-dimensional objects as well as scan at a much higher resolution. Document scanners have document feeders, usually larger than those sometimes found on copiers or all-purpose scanners. Scans are made at high speed, from 20 up to 420 pages per minute, often in grayscale, although many scanners support color. Many scanners can scan both sides of double-sided originals (duplex operation). Sophisticated document scanners have firmware or software that cleans up scans of text as they are produced, eliminating accidental marks and sharpening type; this would be unacceptable for photographic work, where marks cannot reliably be distinguished from desired fine detail. Files created are compressed as they are made. The resolution used is usually from 150 to 300 dpi, although the hardware may be capable of 600 or higher resolution; this produces images of text good enough to read and for OCR, without the higher demands on storage space required by higher-resolution images. Document scans are often processed using OCR technology to create editable and searchable files. Most scanners use ISIS or TWAIN device drivers to scan documents into TIFF format so that the scanned pages can be fed into a document management system that will handle the archiving and retrieval of the scanned pages. Lossy JPEG compression, which is very efficient for pictures, is undesirable for text documents, as slanted straight edges take on a jagged appearance, and solid black (or other color) text on a light background compresses well with lossless compression formats. While paper feeding and scanning can be done automatically and quickly, preparation and indexing are necessary and require much work by humans. Preparation involves manually inspecting the papers to be scanned and making sure that they are in order, unfolded, without staples or anything else that might jam the scanner. Additionally, some industries such as legal and medical may require documents to have Bates Numbering or some other mark giving a document identification number and date/time of the document scan. Indexing involves associating relevant keywords to files so that they can be retrieved by content. This process can sometimes be automated to some extent, but it often requires manual labour performed by data-entry clerks. One common practice is the use of barcode-recognition technology: during preparation, barcode sheets with folder names or index information are inserted into the document files, folders, and document groups. Using automatic batch scanning, the documents are saved into appropriate folders, and an index is created for integration into document management systems.
A specialized form of document scanning is book scanning. Technical difficulties arise from the books usually being bound and sometimes fragile and irreplaceable, but some manufacturers have developed specialized machinery to deal with this. Often special robotic mechanisms are used to automate the page-turning and scanning process. SAINT (Security Administrator's Integrated Network Tool) is computer software used for scanning computer networks for security vulnerabilities, and exploiting found vulnerabilities.
Step 1 – SAINT screens every live system on a network for TCP and UDP services. Step 2 – For each service it finds running, it launches a set of probes designed to detect anything that could allow an attacker to gain unauthorized access, create a denial-of-service, or gain sensitive information about the network. Step 3 – The scanner checks for vulnerabilities. Step 4 – When vulnerabilities are detected, the results are categorized in several ways, allowing customers to target the data they find most useful. SAINT can group vulnerabilities according to severity, type, or count. It can also provide information about a particular host or group of hosts. SAINT describes each of the vulnerabilities it locates; references Common Vulnerabilities and Exposures (CVE), CERT advisories, and IAVA (Information Assurance Vulnerability Alerts); and describes ways to correct the vulnerabilities. In many cases, the SAINT scanner provides links to patches or new software versions that will eliminate the detected vulnerabilities. A vulnerability is a flaw in a system, device, or application that, if leveraged by an attacker, could impact the security of the system. Exploits take advantage of a vulnerability by compromising or destructing the vulnerable system, device, or application. Remediation is the process of repairing or providing a remedy for a vulnerability, thereby eliminating the risk of being exploited. Vulnerability scanning is used to identify and evaluate the security posture of a network. Historically, scanners were developed for specific purposes such as scanning only Windows desktops, applications, or network devices. SAINT offers heterogeneous scanning that identifies vulnerabilities across operating systems, desktop applications, network devices, Web applications, databases, and more.
Remote Exploit – These attacks are launched across the Internet or network against a vulnerable target without the user having previous access to the system. Client Exploit – The victim must access the attacker's resource for a successful attack to take place. Common client exploits include e-mail forgery attacks, enticing the user to visit a Web site, or to open a file. Local Exploit – In order to launch a local attack, the attacker must have previous access to the victim. (Also known as privilege elevation and tunneling). In this case, the victim's machine is used as the launch pad for connecting to other vulnerable targets.
3D scanning is the process of analyzing a real-world object or environment to collect three dimensional data of its shape and possibly its appearance (e.g. color). The collected data can then be used to construct digital 3D models. A 3D scanner can be based on many different technologies, each with its own limitations, advantages and costs. Many limitations in the kind of objects that can be digitized are still present. For example, optical technology may encounter difficulties with dark, shiny, reflective or transparent objects while industrial computed tomography scanning, structured-light 3D scanners, LiDAR and Time Of Flight 3D Scanners can be used to construct digital 3D models, without destructive testing. Collected 3D data is useful for a wide variety of applications. These devices are used extensively by the entertainment industry in the production of movies and video games, including virtual reality. Other common applications of this technology include augmented reality, motion capture, gesture recognition, robotic mapping, industrial design, orthotics and prosthetics, reverse engineering and prototyping, quality control/inspection and the digitization of cultural artifacts.
Contact 3D scanners work by physically probing (touching) the part and recording the position of the sensor as the probe moves around the part. There are two main types of contact 3D scanners: Coordinate measuring machines (CMMs) which traditionally have 3 perpendicular moving axis with a touch probe mounted on the Z axis. As the touch probe moves around the part, sensors on each axis record the position to generate XYZ coordinates.
Modern CMMs are 5 axis systems, with the two extra axes provided by pivoting sensor heads. CMMs are the most accurate form of 3D measurement achieving micron precision. The greatest advantage of a CMM after accuracy is that it can be run in autonomous (CNC) mode or as a manual probing system. The disadvantages of CMMs are their upfront cost and the technical knowledge required to operate them. Articulated Arms which generally have multiple segments with polar sensors on each joint. As per the CMM, as the articulated arm moves around the part sensors record their position and the location of the end of the arm is calculated using complex math and the wrist rotation angle and hinge angle of each joint. While not usually as accurate as CMMs, articulated arms still achieve high accuracy and are cheaper and slightly easier to use. They do not usually have CNC options. Both modern CMMs and Articulated Arms can also be fitted with non-contact laser scanners instead of touch probes.
The time-of-flight 3D laser scanner is an active scanner that uses laser light to probe the subject. At the heart of this type of scanner is a time-of-flight laser range finder. The laser range finder finds the distance of a surface by timing the round-trip time of a pulse of light. A laser is used to emit a pulse of light and the amount of time before the reflected light is seen by a detector is measured. Since the speed of light c {\displaystyle c} is known, the round-trip time determines the travel distance of the light, which is twice the distance between the scanner and the surface. If t {\displaystyle t} is the round-trip time, then distance is equal to c ⋅ t / 2 {\displaystyle \textstyle c\!\cdot \!t/2} . The accuracy of a time-of-flight 3D laser scanner depends on how precisely we can measure the t {\displaystyle t} time: 3.3 picoseconds (approx.) is the time taken for light to travel 1 millimetre.
The laser range finder only detects the distance of one point in its direction of view. Thus, the scanner scans its entire field of view one point at a time by changing the range finder's direction of view to scan different points. The view direction of the laser range finder can be changed either by rotating the range finder itself, or by using a system of rotating mirrors. The latter method is commonly used because mirrors are much lighter and can thus be rotated much faster and with greater accuracy.
Typical time-of-flight 3D laser scanners can measure the distance of 10,000~100,000 points every second. Time-of-flight devices are also available in a 2D configuration. This is referred to as a time-of-flight camera. Triangulation based 3D laser scanners are also active scanners that use laser light to probe the environment. With respect to time-of-flight 3D laser scanner the triangulation laser shines a laser on the subject and exploits a camera to look for the location of the laser dot. Depending on how far away the laser strikes a surface, the laser dot appears at different places in the camera's field of view. This technique is called triangulation because the laser dot, the camera and the laser emitter form a triangle. The length of one side of the triangle, the distance between the camera and the laser emitter is known. The angle of the laser emitter corner is also known. The angle of the camera corner can be determined by looking at the location of the laser dot in the camera's field of view. These three pieces of information fully determine the shape and size of the triangle and give the location of the laser dot corner of the triangle. In most cases a laser stripe, instead of a single laser dot, is swept across the object to speed up the acquisition process. The use of triangulation to measure distances dates to antiquity.
Structured-light 3D scanners project a pattern of light on the subject and look at the deformation of the pattern on the subject. The pattern is projected onto the subject using either an LCD projector or other stable light source. A camera, offset slightly from the pattern projector, looks at the shape of the pattern and calculates the distance of every point in the field of view. Structured-light methods are among the principal active optical techniques used for three-dimensional surface metrology.
Structured-light scanning is still a very active area of research with many research papers published each year. Perfect maps have also been proven useful as structured light patterns that solve the correspondence problem and allow for error detection and error correction. The advantage of structured-light 3D scanners is speed and precision. Instead of scanning one point at a time, structured light scanners scan multiple points or the entire field of view at once. Scanning an entire field of view in a fraction of a second reduces or eliminates the problem of distortion from motion. Some existing systems are capable of scanning moving objects in real-time. A real-time scanner using digital fringe projection and phase-shifting technique (certain kinds of structured light methods) was developed, to capture, reconstruct, and render high-density details of dynamically deformable objects (such as facial expressions) at 40 frames per second. Recently, another scanner has been developed.
Different patterns can be applied to this system, and the frame rate for capturing and data processing achieves 120 frames per second. It can also scan isolated surfaces, for example two moving hands. By utilising the binary defocusing technique, speed breakthroughs have been made that could reach hundreds to thousands of frames per second. 3. Software Implementation, Frameworks & Protocols Stereoscopic systems usually employ two video cameras, slightly apart, looking at the same scene. By analysing the slight differences between the images seen by each camera, it is possible to determine the distance at each point in the images.
This method is based on the same principles driving human stereoscopic vision. Photometric systems usually use a single camera, but take multiple images under varying lighting conditions. These techniques attempt to invert the image formation model in order to recover the surface orientation at each pixel. Silhouette techniques use outlines created from a sequence of photographs around a three-dimensional object against a well contrasted background. These silhouettes are extruded and intersected to form the visual hull approximation of the object. With these approaches some concavities of an object (like the interior of a bowl) cannot be detected.
Photogrammetry provides reliable information about 3D shapes of physical objects based on analysis of photographic images. The resulting 3D data is typically provided as a 3D point cloud, 3D mesh or 3D points. Modern photogrammetry software applications automatically analyze a large number of digital images for 3D reconstruction, however manual interaction may be required if the software cannot automatically determine the 3D positions of the camera in the images which is an essential step in the reconstruction pipeline. Various software packages are available including PhotoModeler, Geodetic Systems, Autodesk ReCap, RealityCapture and Agisoft Metashape (see comparison of photogrammetry software). The underlying reconstruction technique is known as structure from motion. Distinctive points, such as corners or other features with strong gradients in multiple directions, are detected in each image and matched across the set using algorithms such as SIFT or SURF. Because some of these matches are incorrect, RANSAC is commonly used to discard outlier correspondences before the remaining feature trajectories are used to solve jointly for the camera positions and the three-dimensional locations of the matched points, a process known as bundle adjustment. Camera poses may be solved for one at a time, known as incremental structure from motion, or simultaneously for the whole image set, known as global structure from motion.
Close range photogrammetry typically uses a handheld camera such as a DSLR with a fixed focal length lens to capture images of objects for 3D reconstruction. Subjects include smaller objects such as a building facade, vehicles, sculptures, rocks, and shoes. Camera Arrays can be used to generate 3D point clouds or meshes of live objects such as people or pets by synchronizing multiple cameras to photograph a subject from multiple perspectives at the same time for 3D object reconstruction. Wide angle photogrammetry can be used to capture the interior of buildings or enclosed spaces using a wide angle lens camera such as a 360 camera. Aerial photogrammetry uses aerial images acquired by satellite, commercial aircraft or UAV drone to collect images of buildings, structures and terrain for 3D reconstruction into a point cloud or mesh.
The point clouds produced by 3D scanners and 3D imaging can be used directly for measurement and visualisation in the architecture and construction world. Polygon mesh models: In a polygonal representation of a shape, a curved surface is modeled as many small faceted flat surfaces (think of a sphere modeled as a disco ball). Polygon models—also called Mesh models, are useful for visualisation, for some CAM (i.e., machining), but are generally "heavy" ( i.e., very large data sets), and are relatively un-editable in this form. Reconstruction to polygonal model involves finding and connecting adjacent points with straight lines in order to create a continuous surface. Many applications, both free and nonfree, are available for this purpose (e.g. GigaMesh, MeshLab, PointCab, kubit PointCloud for AutoCAD, Reconstructor, imagemodel, PolyWorks, Rapidform, Geomagic, Imageware, Rhino 3D etc.). Surface models: The next level of sophistication in modeling involves using a quilt of curved surface patches to model the shape. These might be NURBS, TSplines or other curved representations of curved topology. Using NURBS, the spherical shape becomes a true mathematical sphere. Some applications offer patch layout by hand but the best in class offer both automated patch layout and manual layout. These patches have the advantage of being lighter and more manipulable when exported to CAD. Surface models are somewhat editable, but only in a sculptural sense of pushing and pulling to deform the surface. This representation lends itself well to modelling organic and artistic shapes. Providers of surface modellers include Rapidform, Geomagic, Rhino 3D, Maya, T Splines etc. Solid CAD models: From an engineering/manufacturing perspective, the ultimate representation of a digitised shape is the editable, parametric CAD model. In CAD, the sphere is described by parametric features which are easily edited by changing a value (e.g., centre point and radius). These CAD models describe not simply the envelope or shape of the object, but CAD models also embody the "design intent" (i.e., critical features and their relationship to other features). An example of design intent not evident in the shape alone might be a brake drum's lug bolts, which must be concentric with the hole in the centre of the drum. This knowledge would drive the sequence and method of creating the CAD model; a designer with an awareness of this relationship would not design the lug bolts referenced to the outside diameter, but instead, to the center. A modeler creating a CAD model will want to include both shape and design intent in the complete CAD model. Vendors offer different approaches to getting to the parametric CAD model. Some export the NURBS surfaces and leave it to the CAD designer to complete the model in CAD (e.g., Geomagic, Imageware, Rhino 3D). Others use the scan data to create an editable and verifiable feature based model that is imported into CAD with full feature tree intact, yielding a complete, native CAD model, capturing both shape and design intent (e.g. Geomagic, Rapidform). For instance, the market offers various plug-ins for established CAD-programs, such as SolidWorks. Xtract3D, DezignWorks and Geomagic for SolidWorks allow manipulating a 3D scan directly inside SolidWorks. Still other CAD applications are robust enough to manipulate limited points or polygon models within the CAD environment (e.g., CATIA, AutoCAD, Revit).
CT, industrial CT, MRI, or micro-CT scanners do not produce point clouds but a set of 2D slices (each termed a "tomogram") which are then 'stacked together' to produce a 3D representation. There are several ways to do this depending on the output required: Volume rendering: Different parts of an object usually have different threshold values or greyscale densities. From this, a 3-dimensional model can be constructed and displayed on screen. Multiple models can be constructed from various thresholds, allowing different colors to represent each component of the object. Volume rendering is usually only used for visualisation of the scanned object. Image segmentation: Where different structures have similar threshold/greyscale values, it can become impossible to separate them simply by adjusting volume rendering parameters. The solution is called segmentation, a manual or automatic procedure that can remove the unwanted structures from the image. Image segmentation software usually allows export of the segmented structures in CAD or STL format for further manipulation.
Image-based meshing: When using 3D image data for computational analysis (e.g. CFD and FEA), simply segmenting the data and meshing from CAD can become time-consuming, and virtually intractable for the complex topologies typical of image data. The solution is called image-based meshing, an automated process of generating an accurate and realistic geometrical description of the scan data.
3D data acquisition and object reconstruction can be performed using stereo image pairs. Stereo photogrammetry or photogrammetry based on a block of overlapped images is the primary approach for 3D mapping and object reconstruction using 2D images. Close-range photogrammetry has also matured to the level where cameras or digital cameras can be used to capture the close-look images of objects, e.g., buildings, and reconstruct them using the very same theory as the aerial photogrammetry. An example of software which could do this is Vexcel FotoG 5. This software has now been replaced by Vexcel GeoSynth. Another similar software program is Microsoft Photosynth. A semi-automatic method for acquiring 3D topologically structured data from 2D aerial stereo images has been presented by Sisi Zlatanova. The process involves the manual digitizing of a number of points necessary for automatically reconstructing the 3D objects. Each reconstructed object is validated by superimposition of its wire frame graphics in the stereo model. The topologically structured 3D data is stored in a database and are also used for visualization of the objects. Notable software used for 3D data acquisition using 2D images include e.g. Agisoft Metashape, RealityCapture, and ENSAIS Engineering College TIPHON (Traitement d'Image et PHOtogrammétrie Numérique). A method for semi-automatic building extraction together with a concept for storing building models alongside terrain and other topographic data in a topographical information system has been developed by Franz Rottensteiner. His approach was based on the integration of building parameter estimations into the photogrammetry process applying a hybrid modeling scheme. Buildings are decomposed into a set of simple primitives that are reconstructed individually and are then combined by Boolean operators. The internal data structure of both the primitives and the compound building models are based on the boundary representation methods Multiple images are used in Zhang's approach to surface reconstruction from multiple images. A central idea is to explore the integration of both 3D stereo data and 2D calibrated images. This approach is motivated by the fact that only robust and accurate feature points that survived the geometry scrutiny of multiple images are reconstructed in space. The density insufficiency and the inevitable holes in the stereo data should then be filled in by using information from multiple images. The idea is thus to first construct small surface patches from stereo points, then to progressively propagate only reliable patches in their neighborhood from images into the whole surface using a best-first strategy. The problem thus reduces to searching for an optimal local surface patch going through a given set of stereo points from images. Multi-spectral images are also used for 3D building detection. The first and last pulse data and the normalized difference vegetation index are used in the process. New measurement techniques are also employed to obtain measurements of and between objects from single images by using the projection, or the shadow as well as their combination. This technology is gaining attention given its fast processing time, and far lower cost than stereo measurements.
3D scanners are evolving for the use of cameras to represent 3D objects in an accurate manner. Companies are emerging since 2010 that create 3D portraits of people (3D figurines or 3D selfie). An augmented reality menu for the Madrid restaurant chain 80 Degrees Crime scenes Bullet trajectories Bloodstain pattern analysis Accident reconstruction Bombings Plane crashes, and more After the data has been collected, the acquired (and sometimes already processed) data from images or sensors needs to be reconstructed. This may be done in the same program or in some cases, the 3D data needs to be exported and imported into another program for further refining, and/or to add additional data. Such additional data could be GPS-location data. After the reconstruction, the data might be directly implemented into a local (GIS) map or a worldwide map such as Google Earth or Apple Maps.
Qlone 3DF Zephyr Canoma CapCam – smartphone LiDAR-based 3D scanning app using Apple's Object Capture API Leica Photogrammetry Suite MeshLab MountainsMap SEM (microscopy applications only) PhotoModeler SketchUp tomviz Sensitive Data Exposure is the accidental or deliberate disclosure of protected information to unauthorized parties. Analogy: like leaving a safe unlocked in a busy train station. Formal technical line: Unauthorized availability or leakage of data violating confidentiality, integrity, or compliance constraints across storage, transit, or processing domains.
Sensitive Data Exposure refers to situations where data that should remain private, restricted, or governed is accessible, visible, or retrievable by entities that should not have that access. It includes accidental leaks, misconfigurations, insecure defaults, insufficient encryption, logging of secrets, and overly permissive APIs. 4. Practical Deployment, Analysis & Case Studies Sensitive Data Exposure is the unintended availability of confidential or regulated data to unauthorized parties due to flaws in design, configuration, or operations.
ID | Term | How it differs from Sensitive Data Exposure | Common confusion T1 | Data Breach | Data breach is an event often caused by exposure | Breach always equals exposure T2 | Data Leak | Leak emphasizes unintended dissemination | Leak implies exfiltration T3 | Data Exfiltration | Active theft of data via attacker actions | Exfiltration is malicious action T4 | Misconfiguration | Misconfig can cause exposure but is broader | Not all misconfigs leak data T5 | Encryption Failure | Focused on cryptographic controls failing | Failure may not expose all data T6 | Insider Threat | Actor-focused concept | Not all exposure involves insiders T7 | Privacy Violation | Legal/regulatory framing | Exposure may be technical without legal breach T8 | Information Disclosure | Broad term including expected sharing | Exposure is unwanted disclosure T9 | Compliance Violation | Policy or regulation nonconformance | Compliance may be intact while exposure exists T10 | Token Misuse | Token misuse is a vector not the whole exposure | Token issues often confuse with auth failures ID | Layer/Area | How Sensitive Data Exposure appears | Typical telemetry | Common tools L1 | Edge/Network | TLS misconfig, public endpoints exposing APIs | TLS errors, access logs, unusual IPs | WAF, CDN, LoadBalancer L2 | Service/API | Over-permissive endpoints returning PII | Request traces, error rates, payload sizes | API Gateway, Service Mesh L3 | Application | Logging secrets or debug data | Application logs, traces, deploy tags | Logging frameworks, SDKs L4 | Data Storage | Public buckets, unencrypted db snapshots | Access logs, S3 inventory, audit trail | Object storage, DB backups L5 | CI/CD | Secrets leaked in build logs or artifacts | Build logs, artifact searches | CI runners, artifact repos L6 | Platform/K8s | Misconfigured RBAC, leaked secrets to pods | Audit logs, kube-apiserver events | Kubernetes, IAM, Secrets Manager L7 | Serverless/PaaS | Environment variables with secrets visible in runtime | Invocation logs, env diffs | Managed functions, PaaS consoles L8 | Third-party Integrations | Over-shared scopes or webhooks sending data | Outbound request logs, webhook deliveries | OAuth apps, webhooks L9 | Observability | Telemetry contains PII in traces or metrics | Trace spans, log contents, dashboards | Tracing, Metrics, Logging backends L10 | Backups/Archives | Snapshots stored without controls | Backup inventories, storage ACLs | Backup services, snapshot tools ID | Failure mode | Symptom | Likely cause | Mitigation | Observability signal F1 | Public storage | Data indexed or downloaded publicly | Public ACL or misconfig | Lockdown ACLs, policy scan | Access from unknown IPs F2 | Logged secrets | Secrets visible in logs | No redaction, debug logging | Redact, remove debug logs | Log entries with secret patterns F3 | Excessive IAM perms | Services access more data than needed | Overbroad roles | Principle of least privilege | Spike in access counts F4 | Unencrypted backups | Backup media readable | Missing encryption keys | Enforce encryption, key rotation | Backup read events F5 | Token leakage | Stolen token used externally | Token in repo or log | Rotate tokens, short lives | Unusual service calls F6 | Third-party overreach | SaaS stores more fields than intended | Broad API scopes | Limit scopes, contractual controls | Outbound data transfers F7 | Dev/staging parity gap | Staging data exposed publicly | Production creds in staging | Use synthetic data, separate KMS | Access from staging accounts F8 | Observability leakage | Traces contain raw PII | Full payload tracing | Mask PII at tracer | Trace spans with PII patterns ID | Metric/SLI | What it tells you | How to measure | Starting target | Gotchas M1 | Exposed Secrets Count | Number of leaked secrets observed | Secret scanner, logs count | 0 | False positives from test secrets M2 | Public Bucket Count | Count of storage buckets publicly accessible | Config scan weekly | 0 | Temporary public for deploys M3 | PII in Logs Rate | Percent of logs containing PII | Log processors detect PII | <0.1% | Detection depends on regexes M4 | Unauthorized Access Attempts | Attempts blocked vs allowed | Auth logs and audit trail | 100% blocked | Shadow accounts may hide attempts M5 | Time to Revoke Compromised Creds | Time to rotate/disable after detection | Ticketing and automation timestamps | <1 hour | Manual rotation delays M6 | Backup Encryption Coverage | Percent of backups encrypted | Backup metadata scan | 100% | Legacy backups may be untagged M7 | Third-party Data Transfers | Number of outbound transfers with sensitive fields | Outbound audit logs | 0 unexpected | Legit transfers require whitelisting M8 | Privilege Creep Rate | Rate of permissions expanding over time | IAM change logs | Minimal | Automated roles can mask growth M9 | Exposure Incident MTTR | Mean time to contain exposure | Incident timelines | <4 hours | Detection latency dominates M10 | Policy-as-Code Coverage | Percent of infra policies enforced | Policy scans vs infra state | 90% | Partial coverage leaves gaps 1) Prerequisites – Data classification policy. – Inventory of data stores and flows. – Centralized IAM and secrets management.
– Baseline observability and logging. 2) Instrumentation plan – Identify ingress points and log redaction points. – Add tracers with PII scrubbing. – Configure audit logging at platform level. 3) Data collection – Centralize logs and traces. – Use metadata tagging for data sensitivity. – Ensure immutable storage for audit trails.
4) SLO design – Define SLIs such as PII-in-logs rate, time-to-revoke, and public-bucket count. – Set realistic starting SLOs and refine via playbooks. 5) Dashboards – Build executive, on-call, and debug dashboards. – Include drilldowns and context links to runbooks. 6) Alerts & routing – Configure high-confidence pages for confirmed exposures. – Route to security on-call and SRE for remediation. – Create ticketing for low-priority findings.
7) Runbooks & automation – Playbooks to rotate keys, lock buckets, and revoke tokens. – Automation for isolating affected services and rotating creds. 8) Validation (load/chaos/game days) – Game days simulating leaked creds and public buckets. – Chaos exercises to validate revocation automation. – Load tests to ensure redaction middleware scales.
9) Continuous improvement – Post-incident reviews and policy updates. – Regular secret scans and policy-as-code refinements. – Quarterly access certification. 5. Performance Evaluation & Extended Technical Observations Customer Data Export – Context: Users can export their data. – Problem: Exports saved to object storage without ACLs. – Why it helps: Controls and policies prevent accidental public access. – What to measure: Exports public bucket incidents, access logs. – Typical tools: Object storage IAM, policy-as-code, audit logs.
Developer Debugging – Context: Developers enable debug logs in prod. – Problem: Logs include user emails and tokens. – Why it helps: Redaction prevents leakage via logs. – What to measure: PII in logs rate, debug flag changes. – Typical tools: Logging middleware, feature flags. Third-party Analytics Integration – Context: Sending event streams to analytics vendor. – Problem: Vendor receives raw PII not allowed by contract. – Why it helps: Field-level masking and consent checks stop unnecessary sharing. – What to measure: Outbound data transfers containing sensitive fields. – Typical tools: ETL pipeline filters, contractual controls.
CI/CD Pipeline Secrets – Context: Build logs exposing credentials. – Problem: Persistent history of secret in artifact. – Why it helps: Scanning and redaction stop exposure before merge. – What to measure: Secrets detected in PRs and builds. – Typical tools: Secret scanners, ephemeral build credentials. Backup Snapshots – Context: Daily snapshots stored across accounts. – Problem: Backups accessible to wrong teams. – Why it helps: Encryption and access controls protect backups. – What to measure: Unencrypted backup count, access events. – Typical tools: Backup services, KMS, IAM.
Serverless Environment Variables – Context: Functions use env vars for DB credentials. – Problem: Console shows plaintext variables to many roles. – Why it helps: Use vaults with ephemeral tokens instead of env vars. – What to measure: Stale env var secrets, access logs. – Typical tools: Secrets manager, function runtimes. Audit Logging – Context: Logs required for compliance include sensitive fields. – Problem: Logs stored where many teams can read. – Why it helps: Separate audit log stores with restricted access protect data. – What to measure: Read access counts to audit logs. – Typical tools: Immutable logging backends, SIEM.
Data Science Sandbox – Context: Analysts need datasets for modeling. – Problem: Full PII dataset replicated into low-control sandboxes. – Why it helps: Synthetic data and access controls reduce exposure. – What to measure: Sandboxes with production data, access frequency. – Typical tools: Data catalogs, masking tools. Service Mesh Introduction – Context: Introducing service mesh for observability. – Problem: Traces include full payloads with PII. – Why it helps: Redaction at mesh sidecars reduces leakage. – What to measure: PII occurrences in traces after mesh rollout. – Typical tools: Service mesh, tracing middleware.
Vendor Onboarding – Context: Giving external vendor scoped access. – Problem: Over-permissive OAuth scopes allow excess data. – Why it helps: Scoped tokens and time limits minimize exposure. – What to measure: Active vendor tokens and their scopes. – Typical tools: OAuth, access reviews. Context: Internal K8s microservices exchange user profiles. Goal: Prevent internal API from exposing PII to non-authorized pods. Why Sensitive Data Exposure matters here: Kubernetes RBAC and service account misuse can allow lateral exposure.
Architecture / workflow: Service mesh with mTLS, sidecar redaction, secrets from vault, pod-level policies. Step-by-step
Implementation
Context: A managed PaaS function sends notification emails. Goal: Ensure functions do not log customer emails or appear in monitoring. Why Sensitive Data Exposure matters here: Logs and execution traces in managed consoles are accessible to platform users. Architecture / workflow: Function triggered by event, uses email service via ephemeral token, redaction layer for logs. Step-by-step implementation: Context: API key committed to public repository and used by attacker. Goal: Contain exposure, rotate key, and remediate pipelines. Why Sensitive Data Exposure matters here: Keys in public repos lead to immediate unauthorized access.
Implementation Synonym
Architecture / workflow: Detection via secret scanner webhook triggers incident. Step-by-step implementation: Context: High-volume platform needs log redaction with minimal latency. Goal: Decide between edge redaction at API gateway or centralized batch redaction. Why Sensitive Data Exposure matters here: Redaction must be timely but not introduce latency or cost overruns. Architecture / workflow: API gateway with optional fast-pattern redaction vs sending raw logs to central scrubbing service. Step-by-step implementation: Harvested Online Documentation & Reference Sources • https://en.wikipedia.org/wiki/Image%20scanner • https://en.wikipedia.org/wiki/SAINT%20%28software%29 • https://en.wikipedia.org/wiki/3D%20scanning • https://devsecopsschool.com/blog/sensitive-data-exposure/
Extracted Research Figures & Simulation Topologies
Total 3 diagrams and telemetry visual outputs extracted directly from the complete technical documentation.
Breach Emulation & Defense Validation Architecture
Standardized testing pipeline mapping threat vectors directly into simulated inspection engines.
(AttackIQ / SafeBreach)
(Burp Suite Pro)
(Cisco Packet Tracer)
(Metasploit Engine)
(KnowBe4 Training)
Sample Simulation Code & Telemetry Log
Automated tool orchestration script and command window outputs for Sensitive Data Exposure Scanner In Web Applications.
[*] Initializing Burp Suite Spider & Vulnerability Engine for Sensitive Data Exposure Scanner In Web Applications... [✓] Burp Extender / Macro Automation Hook Synced ──────────────────────────────────────────────────────────────────────── [11:42:01.104] AUDIT Crawled dynamic endpoints | Injecting input vectors [11:42:01.218] FINDING Cymulate / Burp: Input sanitation check executed in parameter 'q' [11:42:01.312] VERIFY SafeBreach payload validation: Out-of-band interaction confirmed [11:42:01.405] REPORT Severity: Evaluated | Remediation: Enforce context-aware validation ──────────────────────────────────────────────────────────────────────── [✓] Burp Suite Audit Completed: Verified across OWASP Top 10 vectors
| Vulnerability Vector | Testing Tool | Injection Target | Severity | Remediation Status |
|---|---|---|---|---|
| SQL Injection (SQLi) | Burp Suite Professional | POST /api/auth/login | CRITICAL | PARAMETERIZED |
| Cross-Site Scripting (XSS) | SafeBreach / Cymulate | GET /search?q= | HIGH | CSP ENFORCED |
| Broken Object Level Access | Picus Security Audit | GET /user/account/840 | HIGH | RBAC APPLIED |
| Security Misconfiguration | AttackIQ Suite | HTTP Security Headers | MEDIUM | RESOLVED |