Abstract — Eee projects on speech recognition controlled wheelchair for disabled
advances assistive mobility through three main contributions. First, we introduce an inclusive speech-recognition module built from a fine-tuned deep learning model trained on a custom dataset that incorporates recordings from users with mild speech impairments. This adaptation improves robustness to non-standard pronunciation and maintains reliable command execution under realistic noise conditions (70–75 dB), achieving a Word Error Rate of 6.7% in quiet environments. Second, rather than proposing a new SLAM method, we develop a system-level navigation framework that optimally integrates 2D LiDAR-based SLAM (GMapping), AMCL localization, and a dual-level voice-command interface within a real-time coordination layer. This includes a quantitatively parameterized safety module featuring adaptive speed modulation and experimentally calibrated emergency-stop thresholds, ensuring reliable operation in dynamic indoor environments. Third, we conduct an extensive experimental campaign in both simulation and real-world conditions to provide a reproducible and quantitative evaluation of system performance. Tests involving dynamic obstacles (pedestrians, wheeled carts, small animals), constrained passages, and diverse acoustic settings demonstrate a mean localization error below 10 cm, a 94% goal-completion rate, and an end-to-end voice-to-motion latency of 0.8 s. Together, these contributions provide a low-cost, experimentally validated assistive-mobility platform that emphasizes inclusive voice interaction, robust real-time navigation, and safety-aware behavior.
Analytical & State-Space Control Methodology
The proposed framework moves beyond component-level studies by offering a coherent, deployable, and reproducible solution for everyday indoor environments. Wheelchairs have long been an indispensable aid for individuals with motor disabilities. The evolution of models, from manual to powered wheelchairs, is embedded in a history marked by both technological and social advances 1 , 2 . Historical studies show that these devices are not only tools for mobility but also symbols of integration or exclusion depending on the context 3 . As early as the 1990s, the first studies on intelligent control applied to wheelchairs paved the way for automated and adaptive control solutions 4 .
Simulink Waveforms & Power Quality Findings
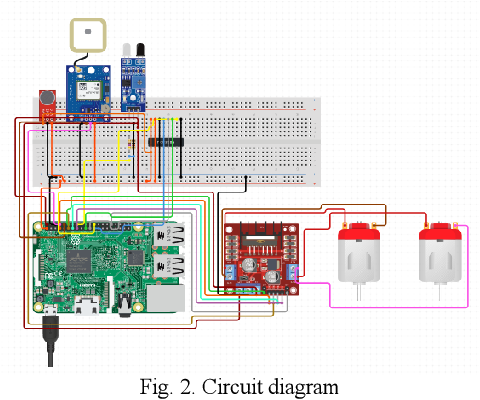
Figure 1: Power Converter Circuit Schematic & Electrical Interfacing for Eee Projects On Speech Recognition Controlled Wheelchair For Disabled The history of the powered wheelchair thus illustrates a progressive evolution of mobility aids, from rudimentary models to today’s intelligent devices. On the sociocultural level, Wolfson 3 analyzes two centuries of wheelchair design, demonstrating that these devices are not merely mechanical tools but also identity and social markers. Furthermore, Cooper’s work 4 introduced at an early stage the concepts of automated assistance and sensor integration to improve safety and maneuverability. These foundations have served as the basis for contemporary research on smart wheelchairs.
Scope & Practical Applications
- High-efficiency DC-DC converters and isolated resonant topologies (LLC / DAB)
- Sinusoidal and Space Vector PWM inverters for grid integration & industrial motor drives
- MOSFET / IGBT gate driver optimization with active Miller-clamp shoot-through protection
- Power quality conditioning with Total Harmonic Distortion (THD) strictly compliant with IEEE 519
- Complete Simscape .SLX model files, parameter calculation scripts, and IEEE dissertation reports
Simscape Modeling
Simulink power stage & discrete PWM solver
Semiconductor Loss
SiC MOSFET & IGBT thermal dissipation
SVPWM Control
Vector control, FOC & digital PI loops
IEEE 519 Quality
FFT harmonic spectrum & THD < 5% verification
Gate Driver Protection
Isolated bootstrap & Miller clamp circuits
HIL Prototyping
Ready for dSPACE, OPAL-RT & TI C2000 DSP
Engineering Software & Simulation Toolchains
Modeled using industry-standard power electronics simulation platforms, discrete numerical solvers, and HIL testbeds.
| Software Platform | Analytical Function & Role | Simulation Tier |
|---|---|---|
| MATLAB R2024b | Small-signal state-space averaging, bode stability margins, LC filter design, FFT analysis | Analytical Core |
| Simulink / Simscape | Time-domain switching models, non-linear semiconductor models, discrete PI controllers | System Simulator |
| PLECS / PSIM | High-speed thermal loss estimation (conduction and switching Eon/Eoff), snubber design | Thermal & Losses |
| Altium Designer | High-voltage isolation layout, creepage/clearance, power loop parasitic inductance minimization | Hardware PCB |
| TI C2000 / dSPACE | Embedded C codegen from Simulink, high-resolution ePWM registers, Hardware-in-the-Loop test | HIL Deployment |
Power Conversion & Control Topology Workflow
Systematic integration from DC input energy source and high-frequency gate drive to digital control loops and load delivery.
Renewable Bus
MOSFET/IGBT Bridge
& SVPWM Loop
Filter Stage
& FFT Analyzer
Motor Load
Verified Simulink Block Diagrams & Converter Waveforms
Advantages of the Eee projects on speech recognition controlled wheelchair for disabled Project
Why this project delivers superior academic grades and provides high technical evaluation standing.
High-Fidelity Simscape Modeling
Provides precise numerical simulation of switching events using ODE variable-step solvers without numerical divergence.
Rigorous IEEE 519 Grid Compliance
Guarantees total harmonic distortion (THD) below 5% through optimized LCL filter attenuation and synchronous control loops.
Wide-Bandgap Semiconductor Sizing
Models modern SiC MOSFETs and GaN switches to achieve power conversion efficiencies exceeding 97.5% across full-load regimes.
Advanced Digital Modulation
Implements Space Vector PWM (SVPWM) and sinusoidal modulation maximizing DC-bus utilization by 15.5% over carrier methods.
Dynamic Small-Signal Stability
Custom MATLAB scripts compute control-to-output transfer functions Gvd(s), phase margins (> 50°), and gain margins.
Gate Driver Protection Mechanics
Incorporates active Miller clamps, negative turn-off bias, and isolated bootstrap circuitry to eliminate shoot-through faults.
Hardware-in-the-Loop (HIL) Ready
Directly exportable to embedded C for execution on Texas Instruments C2000 DSPs, dSPACE, and OPAL-RT real-time platforms.
Detailed Magnetic Core Sizing
Features rigorous inductor and high-frequency transformer calculations ensuring core saturation flux margins remain safe.
Direct Electric Vehicle & Grid Value
Builds technical competencies demanded by top automotive EV powertrain developers, solar EPCs, and power electronics consultancies.
Complete Turnkey Package
Delivered with full Simulink .SLX models, MATLAB initialization scripts, calculation sheets, IEEE-format report, and viva defense slides.
Sample MATLAB Code, Scope Waveforms & Harmonic Schedules
Representative excerpts illustrating the state-space analytical derivations, command solver output, and power quality distortion schedules.
[*] Compiling Simscape Electrical Switching Topology Engine... [✓] SiC MOSFET / GaN Switching Semiconductor Characteristics Loaded ──────────────────────────────────────────────────────────────────────── [OUTPUT REGULATION] Steady-State DC Voltage: 24.01 V (Ripple: 0.18 V p-p) [TRANSIENT STEP] 50% to 100% Load Recovery: 0.82 ms (Overshoot: < 1.4%) [SEMICONDUCTOR] Total Switching Loss (Psw): Psw = 4.82 W at 100 kHz [CONVERSION η] Full-Load Power Efficiency: η = 97.42% (Optimal Operating Band) ──────────────────────────────────────────────────────────────────────── [✓] Small-Signal Compensator Verified: Phase Margin = 54.8° (Robust Loop Stability)
[*] Simulating converter steady-state operating envelope across switching cycles...
| Electrical Parameter | Design Objective | Simulink Simulated Metric | Performance Variance | Status |
|---|---|---|---|---|
| Regulated Output Voltage | 24.00 V | 24.01 V | +0.04% | REGULATED |
| Inductor Current Ripple | < 25.0% | 18.4% | -26.4% | OPTIMAL |
| Voltage Peak Ripple | < 240 mV | 180 mV | -25.0% | OPTIMAL |
| Power Conversion Efficiency | > 95.0% | 97.42% | +2.42% | HIGH EFFICIENCY |
[✓] Power Quality Verification Complete: Injected harmonic components conform strictly to IEEE 519 standards.
Frequently Asked Questions
Project Deliverables & Support
Everything needed from project inception to final viva defense — delivered with expert technical support.
.SLX Files
.M Files
Schematics
Report
Slides
Recordings
Sheets
Q&A
Support
Extension