Chapter 10
Kalman Filters for Reference Current Generation in
Zulkifilie Bin Ibrahim
Additional information is available at the end of the chapter
Abstract
Shunt active power filter (APF) method have been used by many researchers as a solu- tion in reducing the harmonics creating by the non-liner loads. Therefore, this research is targeted to design and implement a three-phase shunt APF employing Kalman filter esti- mator. Conventionally, low-pass filter (LPF) is used to filter out the unwanted DC compo- nent of the non-linear load to produce the sinusoidal waveform called the reference current.
However, when applying LPF it contributes with the phase shift and high transient at the supply current. Therefore, to reduce these problems, the digital Kalman filter estimator is used to replace the LPF for generating the reference current. Details on the investigation between conventional and proposed methods under simulation based on Matlab Simulink platform and experimental that are made for two types of load, namely, three-phase recti- fier with RC-load and three-phase induction motor, are presented. The performance criteria of the shunt APF are determined by the supply current waveform, total harmonic distortion (THD), harmonic spectrum and power quality measurements, which were also obtained by simulation and experimental. In conclusion, by employing Kalman filter estimator for generating the reference current, it reduces the time delay and high transient current at the power supply and, thus, improved the overall THD from 0.1 to 0.42% compared to the LPF.
Keywords: three-phase system, harmonic reduction, active power filter (APF), reference
1. Introduction
Electrical power is essential to people’s modern lifestyle. In recent five decades, due to the development of the industry contributed to the increase of the types and capacity of the © 2018 The Author(s). Licensee InTech. This chapter is distributed under the terms of the Creative Commons Attribution License (http://creativecommons.org/licenses/by/3.0), which permits unrestricted use, distribution, and reproduction in any medium, provided the original work is properly cited.
grid connected load drastically. For that reason, all the electrical consumers at all levels of usage have facing an issue of power quality problems. Both industrial/commercial sector and domestic environment commonly use sensitive equipment and non-linear loads (NLL).
Inadvertently, these result in a non-sinusoidal current being drawn from the supply, which contains the harmful harmonic component and fed back to the supply system on the same point of common coupling (PCC). Passive filter is one of the common methods that have been used to overcome this problem. The passive filter is connected in parallel between the supply and NLL for improvement of power factor and harmonic suppression and thus exhibits lower impedance at tuned harmonic frequency. However, this approach does not solve the problem effectively due to its inability to compensate random frequency variation in the current, tuning problem and parallel resonant. Among the techniques, the d-q algo- rithm has been widely used to eliminate the harmonics due to its simplicity of control design relative to the rest. Commonly, the d-q algorithm is using LPF to generate the reference cur- rent. However, time delay introduced when applying the LPF will contribute to the phase shift in harmonics and higher transient current. Therefore, a new proposed technique of the current reference generator embedded with Kalman filter for shunt APF system is proposed where it reduces the time delay, thus producing improvement of the overall total harmonic distortion (THD) in the system.
1.1. State Of The Art
The active power filter (APF) technology is now mature in providing compensation for har- monics, reactive power and neutral current in AC networks. It has evolved for the past quar- ter century of development with varying configurations, control strategies and solid-state devices. Commonly, the APFs are used to eliminate the voltage harmonics, regulate terminal voltage, suppress voltage flicker and improve voltage balance in three-phase systems. This wide range of objectives can be achieved either individually or in combination depending upon the requirements, control strategy and configuration, which have to be selected appro- priately. This section describes the history of development and the present status of the APF technology.
With the proliferation of power electronics in energy conversions, power quality is fast becoming an issue of an increasingly important aspect of electrical consumers at all levels of usage. A large number of publications have been covering the power quality survey, measurements, analysis, cause and effects of harmonics and reactive power in the electric networks . APFs can be categorized into three types, namely, two-wire (single-phase), three-wire and four-wire three- phase configurations, to meet the requirements of the three types of NLL on supply systems.
Domestic lights and ovens, TVs, computer power supplies, air conditioners, laser printers and Xerox machines behave as NLL and cause power quality problems for single-phase loads. For this type of load, the APFs are investigated in varying configurations and control strategies [10– 19]. Starting in 1971, many configurations of APF have been developed for improving the power system quality. It can be categorized into four basic types, namely, series, parallel (shunt), hybrid APFs and unified power quality conditioner (universal AF). The series APF operates mainly as a voltage regulator and a harmonic isolator between NLL and utility system . In other
184
words, it allows only fundamental component of the current to flow in the system, suppress- ing other higher-frequency components. It can also be used to regulate the negative sequence voltage at the load. The series active filter is ideal for eliminating and/or maintaining the output voltage while balancing three-phase voltages [20, 21, 23–26]. On the other hand, shunt APF has been widely used to mitigate the harmonics. It cancels the load-current harmonics and provides reactive compensation to the supply, through the act of injecting equal but opposite harmonic compensating current to the supply . Shunt APF has the advantage of carrying only the compensation current plus a small amount of active fundamental current to compensate for sys- tem losses. It is also possible to connect several filters in parallel to cater for higher currents, mak- ing this type of circuit suitable for a wide range of power ratings [26, 39, 40]. The most common configuration of shunt APF is the inverter type where the role of the filter inductor is to suppress the high frequency at tuned current generated at tuned frequency, while the converter provides complementary filtering on others that includes any random variations through switching tech- niques [28, 34, 41, 42]. The shunt APF controller can be used in direct or indirect connection.
Hybrid APF can be characterized by a combination of passive filter and APF in series or parallel. The combination between series APF with parallel passive filter is the most popular arrangement because the solid-state devices used in active series part help in reducing the size and cost, to about 60–80% of load size [43, 44]. Furthermore, the passive parallel LC filter is used to eliminate lower-order harmonics at reasonable cost [26, 37, 44–49]. Another arrangement is the combina- tion of active filter in series with a parallel passive filter, which is used especially for medium- and high-voltage applications . Further arrangements also include a combination of parallel active and passive filters where the APF part is designed to eliminate the lower order of harmon- ics, while the passive filter works to eliminate the bulk load-current harmonic . The combi- nation of series active and parallel APF will produce unified power quality conditioner (also known as universal AF). The DC-link element of either inductor or capacitor is shared between two current sources or voltage-source bridges operating as active series and active parallel com- pensator [50, 51]. This universal AF is considered as an ideal AF, which eliminates voltage and current harmonics, thus capable of providing clean power to critical and harmonic-prone loads, such as computer, medical equipment and others. The main drawbacks are large costs and com- plex control due to dependency on the number of solid-state devices involved [26, 50, 51].
Many control approaches have been developed to extract and estimate the harmonics in the system. Instantaneous reactive power theory (p-q theory), modified p-q theory , p-q-r theory [55, 56], vectorial theory and d-q theory are the techniques that fall into the extraction technique. Due to its simplicity of control design relative to the rest, for that reason this d-q algorithm has been widely used to eliminate the harmonics . On the other hand, estimation approach is used to estimate harmonics of frequency component present in the signal and measurement or estimation of the amplitude and phases of those frequencies .
This approach can be divided into two classes, non-parametric and parametric methods. The non-parametric methods are based on transformation of the given time-series data sequence. During the estimation process, these methods are not capable of incorporating with any avail- able information about the system. Frequency domain approach using Fourier transform is most commonly used for spectrum analysis in this harmonic estimation . In addition, parametric methods use an appropriate model to represent the signal and then estimate the Kalman Filters for Reference Current Generation in Shunt Active Power Filter (APF)
185
parameters of the model from the available data points. Estimated parameters are applied to the selected model to determine harmonic contents in the signal. This parametric methods offer higher resolution and better accuracy than the non-parametric methods . Kalman filter (KF) estimator is one of the methods that fall into the parametric method category which have been widely studied and used for different applications .
1.2. Main Contribution
There are three main contributions regarding with this research: a. Developed a new design of shunt APF employing Kalman filter estimator. • The new design of shunt APF for generating the reference currents using Kalman filter es- timator was proposed to reduce the delay time and high transient current when applying the conventional technique. In addition, the developed system was tested for two different types of loads such as three-phase rectifier with RC-load and three-phase induction motor.
b. Investigation of the details of performance based on simulation and experimental for con- ventional and the proposed technique. • The investigation criteria are on the harmonic spectrum, THD and power quality for dif- ferent three types of load because these criteria affect directly the performance of system that used active power filter.
c. Comparative studies between the conventional and the proposed technique upon experi- mental implementation. d. An analysis is carried out in terms of harmonic spectrum, THD and power quality as well to validate the advantages offered by employing the new techniques relative to the com- mon implementation of an active power filter.
1.3. Proposal Of The Research
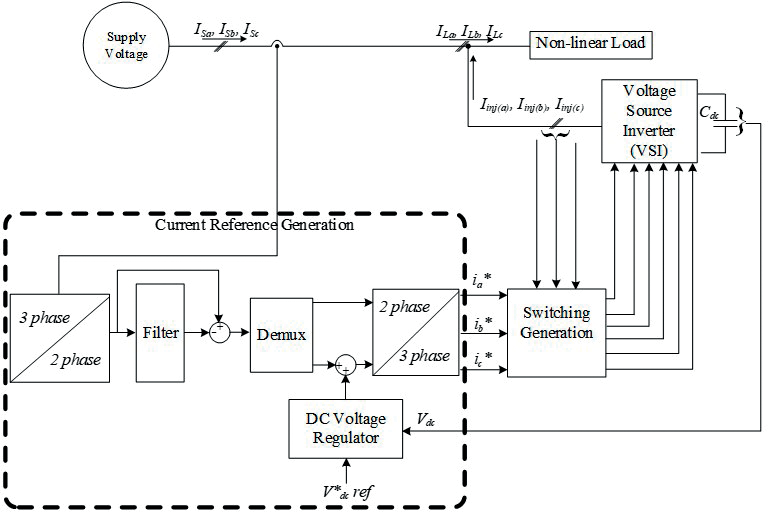
Power quality problems have becoming a critical issue when dealing with power electronic converter and NLL due to the effects of the harmonic contamination in power system. Many techniques have been proposed to overcome these problems such as passive filter which con- tribute to improve the power factor and harmonic suppression and exhibit lower impedance at a tuned harmonic frequency. However this approach provides incomplete solutions par- ticularly when compensating random frequency variations in the current, tuning and paral- lel resonant problems. Therefore, various active power filter (APF) configurations with their respective control strategies have been proposed and have been recognized as a viable solu- tion to the problem created by harmonics. Among the technique, the d-q algorithm has been widely used to eliminate the harmonics due to its simplicity of control design relative to the rest. Commonly, the d-q algorithm is using LPF to generate the reference current. However, time delay introduced when applying the LPF will contribute to the phase shift in harmonics and higher transient current. A new proposed technique of the current reference generator embedded with Kalman filter (KF) for shunt APF system is proposed as shown in Figure 1.
The KF in the system was used as a LPF to produce a reference current in three-phase system
186
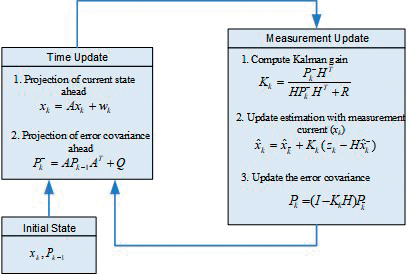
as shown in Figure 2. The KF used a form of feedback control in which the filter estimates the process at any time and then obtains feedback in the form of noisy measurements. These noisy measurements can be further exploited to improve the next estimates in which KF is able to perform because it has both time update and measurement update equations. The time update also known as predictor equation is responsible for projecting forward (in time) current state and error covariance estimate to obtain the estimation in the next time step, while the measurement update equation also called corrector equation is responsible for the feedback such as for incorporating a new measurement into the estimator to improve the Figure 1. Overall system of shunt APF.
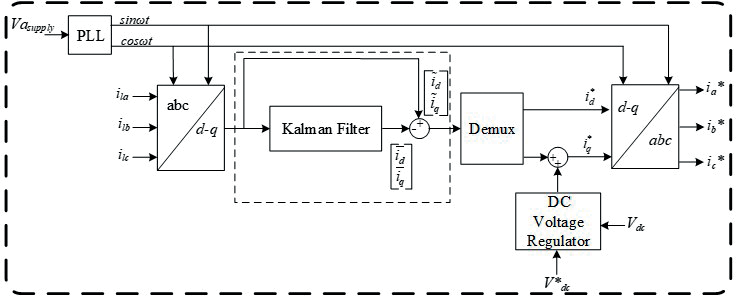
Figure 2. New technique of three-phase reference current generator employing Kalman filter estimator. Kalman Filters for Reference Current Generation in Shunt Active Power Filter (APF)
187
estimation. Therefore the estimation resembles the combination of predictor-corrector algo- rithm, which is used in the system. By applying KF, it improves the overall performance and also reduces the time delay and transient current which occurs in the conventional technique.
Furthermore, this technique uses every measurement that the system has to further improve on the results by giving a better estimate at each time epoch. The significant improvement can be observed at the total harmonic distortion (THD) reduction at 2.38% compared to when the shunt APF is not implemented at all which performs at 168.39%. The TDH of the source imposed a limit at less than 5% of the overall harmonics. In fact, for comparison, the use of KF also performed better than the established low-pass filter, which performs at 2.8% of the THD.
2. Mathematical Formulation
There are three elements that involved in generating the required current reference that is used to compensate the undesirable load current components as shown in Figure 2. These elements are stationary reference frame, Kalman filter (KF) and DC voltage regulator. The mathematical formulation for each element is further explained in the next subtopics.
2.1. Stationary Reference Frame
Stationary reference frame also known as d-q algorithm was developed based on Park trans- formation. This method transforms three-phase into d-q coordinates (rotating reference frame with fundamental frequency) using Park transformations. In this case, the load currents are measured and transformed into d-q coordinates. The equations to transform a-b-c coordinate
(1)
By employing Park transformation, the α-β-0 coordinate is transformed into d-q coordinate as
__
i α ). The phase angle, θ, in d-q frame is the same with fundamental frequency which makes the DC fundamental current component (i d ¯ , i q ¯ ) and harmonic AC component (i d
, I Q ~ ) Arise Due To Har-
monics at the load . Low-pass filter (LPF) is normally used to determine the DC component. Nevertheless, for such system, phase shift in harmonics and high transient response is unavoid- able before attaining its steady state. This is where KF estimator is used to replace the LPF and further improve the overall performance of the system. In order to stabilize the voltage on the DC side of the VSI, the measurement voltage, Vdc, measure must follow the reference voltage, Vdc ref. Therefore, DC voltage regulator loop is designed by integrating a suitable PI controller.
2.2. Dc Voltage Regulator
The DC voltage regulator is controlled with a traditional PI controller. The DC voltage, Vdc, is measured and then compared with a constant reference value Vdc*. The error is processed by a PI controller with two gains: Kp and Ki. Both gains are calculated and tuned accordingly to the dynamic response in which the values of both gain are set to 4 for Kp and 91 for Ki.
2.3. Kalman Filter
The use of Kalman filter (KF) provides an efficient computational means to estimate the state of a process which is able to minimize the means of the squared error. This is achieved by keeping tracks of the estimated state of the system as well as the variance of the estimates via two distinct phases: predict and update. The basic KF can be defined as.
(4)
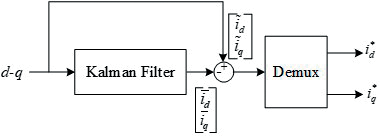
where A is the state transition matrix, B is the control matrix that is applied to u k, which is the control vector of the system, and H is defined as observation matrix with x k the state of the system and y k the measurement or sometimes called observation vector. w k and v k are the pro- cess noise vector and observation noise vector, respectively, and it is assumed to be mutually independent and normally distributed. Relative to the system, since the fundamental positive sequence components of the non-linear load current appears as DC quantities of the synchro- nous reference frame rotating at 50 Hz, it can then be separated from the load currents using KF as depicted in Figure 3.
In this case, the state transition matrix is the differential equation that relates the state at the previous time step k − 1 to the current step k. Therefore, the state vector x k can be further defined as.
(5)
Figure 3. Kalman filter. Kalman Filters for Reference Current Generation in Shunt Active Power Filter (APF)
189
Furthermore, the optional control input which defined the control matrix B can be neglected. Since the system only measured two parameters, respectively, therefore the measurement matrix can be simply represented by two-by-two identity matrix. Therefore, the implementa- tion of the KF can be rewritten as.
(7)
The measurement update equation x ̂ k is the estimate reference current of i d and i q, x ̂ k
− Is The Pre-
dicted state, z k is the measurement of actual current, P k is the estimate error covariance, R k is the observation covariance matrix and K k is the Kalman gain. In this representation, matrix P is the variance matrix of the error x k − x ̂ k where the goal is to minimize this value. Here the Kalman gain calculation will be based on the conventional calculation defined in Eq. (8):
(8)
The process noise covariance matrix Q and observation noise covariance matrix R are tuned manually in order to achieve the optimal performance of the filter. Figure 4 shows the cycle of KF.
Figure 4. Cycle of discrete Kalman filter.
3. Simulation And Experimental Result
The proposed simulation and experimental results designed for the three-phase reference current generation employing KF estimator for three-phase shunt APF are presented. The work is simulated and implemented using Matlab Simulink and dSPACE.
3.1. Non-Linear Load
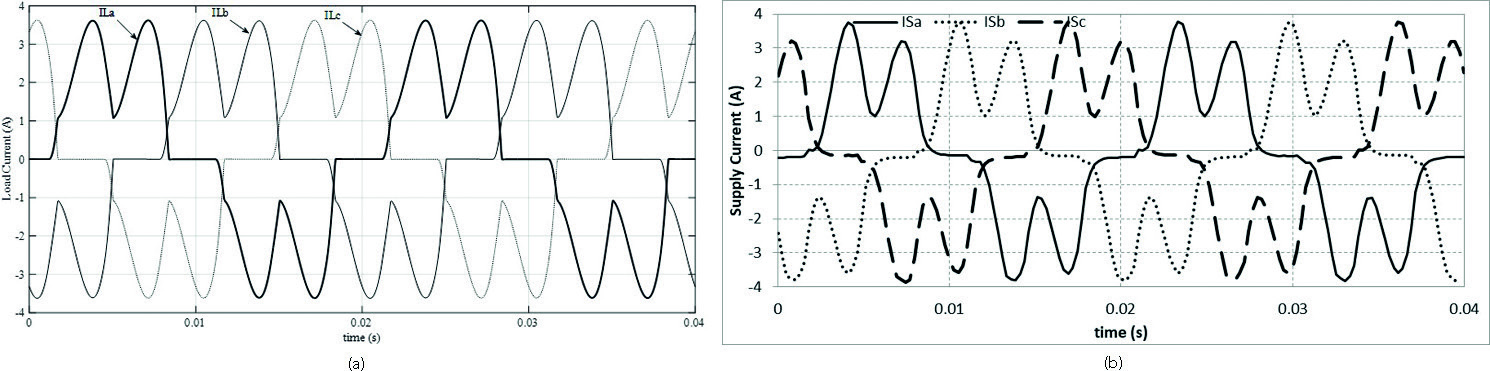
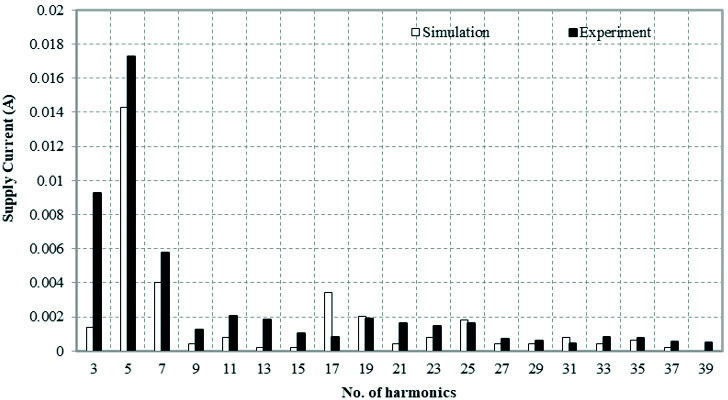
The results for the APF before and after compensation are simulated using Matlab Simulink, while Fluke Power Quality Analyzer captures the results for the experimental. Figure 5(a) and (b) shows the supply current waveform before the compensation for simulation and experimental result; thus, the harmonic spectrum of both simulation and experimental is shown in Figure 6, respectively.
From the harmonic spectrum results, the total harmonic distortion (THD) can be determined by using the formula defined as.
(9)
Figure 5. Simulation and experimental result without shunt APF (a) simulation and (b) Experiment. Figure 6. Harmonic spectrum before the compensation. Kalman Filters for Reference Current Generation in Shunt Active Power Filter (APF)
191
where Ih is the harmonic component, If is the fundamental component, and n is the harmonic number: 2, 3, 4, etc. Therefore, the THD of the line current obtained by the simulation is 56.14%, while the experi- mental obtains about 47.26%. There are slightly different between the simulation and experi- mental results because the simulation is simulated at an ideal condition.
3.2. Kalman filter estimator result versus low-pass filter Commonly, a Butterworth low-pass filter (LPF) was applied to filter out the unwanted DC component for d-q algorithm to ensure that the correct reference currents are generated in the system. Failure to obtain the correct reference current resolves reduction of the overall Figure 8. Simulation of Kalman filter.
Figure 7. Simulation Butterworth low-pass filter.
192
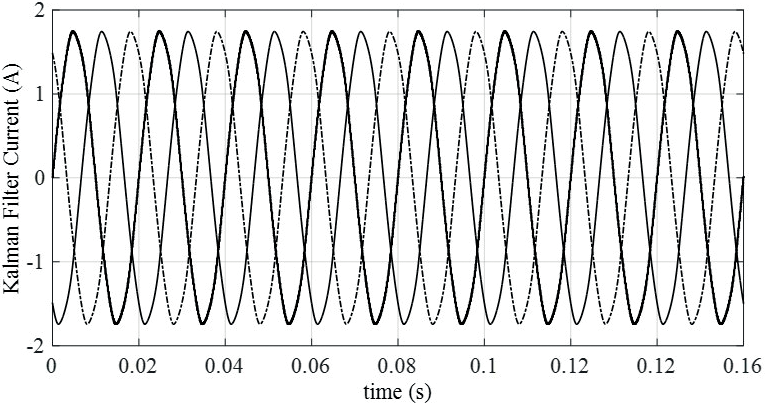
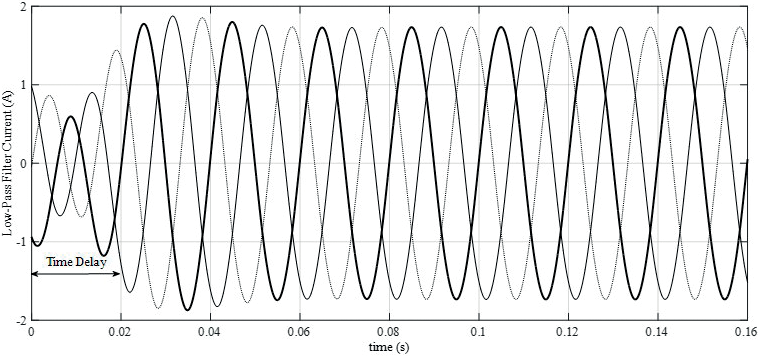
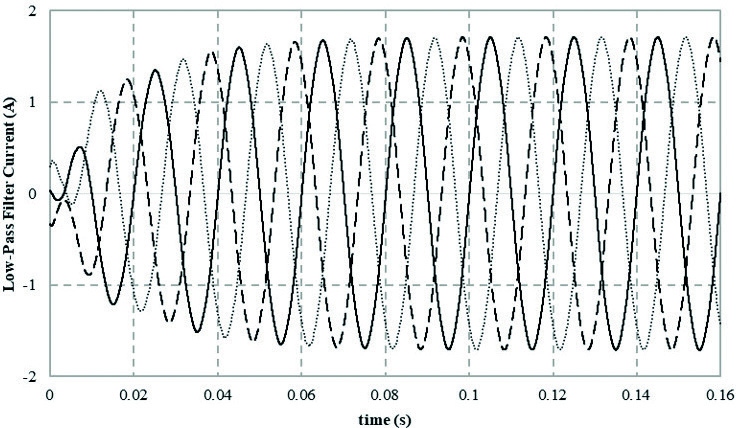
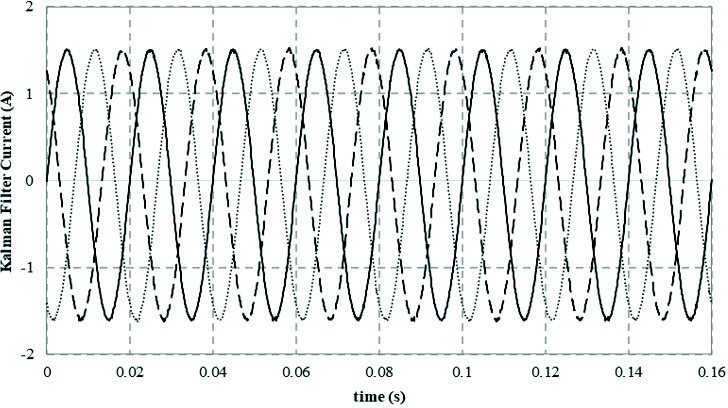
performance of the active power filter (APF). But, time delay which contributes to the phase shift in harmonics and high transient current is the common effect when applying the LPF. Figure 7 shows the shunt APF when applying Butterworth LPF. It is clearly shown that from the figure, the time delay is recorded at 0.02 s with 43.36% of the THD. On the other hand, there is no time delay when applying the shunt APF using KF estimator which is shown in Figure 8. Therefore, the THD produced by the KF estimator is 98% improvement compared to LPF. On the other hand, the experimental results for low-pass and KF are shown in Figures 9 and 10, respectively.
Figure 9. Experimental Butterworth low-pass filter. Figure 10. Experiment of Kalman filter. Kalman Filters for Reference Current Generation in Shunt Active Power Filter (APF)
Deployment In Out-Of-Position Situations
D. Bendjaballah1, A. Bouchoucha1, M. L. Sahli1,2* and J-C. Gelin2
Abstract
Side-impact collisions represent the second greatest cause of fatality in motor vehicle accidents. Side-impact airbags have been installed in recent model year vehicle due to its effectiveness in reducing passengers’ injuries and fatality rates. In meeting these requirements, simulations of folding and deploying airbags are very useful and are widely used. The paper presents a simulation method for the deploying airbags using three materials in different working conditions. Finite element analysis is primarily used to evaluate this concept. In these simulations, the gas flow is described by the conservation laws of mass, momentum, and energy. The numerical results indicate that the FE method in this paper is capable of capturing airbag deploying process accurately.

Keywords: Airbag simulations, Out-of-position, Crash, Modeling, Out-of-position
Background
The passive safety of cars has become a very high prior- ity issue for the automotive industry. Today, there are not only one or two airbags in a car; certain models have ten times more than that. With the increasing usage of airbags, the number of accidents where the airbag itself can cause an injury to the occupant also increases
(Augenstein Et Al. 2003; Gabauer And Gabler 2010;
Audrey et al. 2011). As is well known, safety belts are also now devices designed to provide protection to the users of vehicles during crash events, minimizing the loads necessary to adapt their movement to the move- ment of the car (Freesmeier and Butler 1999; Schmitt et al. 1997). In general, the seat belt is designed to restrain the occupant in the vehicle and prevent the
Occupant From Having Harsh Contacts With Interior
surfaces of the vehicles. The airbag acts to cushion any impact with vehicle structure and has positive internal pressure, which can exert distributed restraining forces over the head and face. As a safety component of auto- mobile, an airbag decreases occupants’ injury likelihood effectively in case of an accident (Ruff et al. 2007). These safety elements can reduce the death rates on the roads, and its protection effects have been widely approved (Crandall et al. 2001; Teru and Ishikawa 2003). With computational tools such as finite element methods designed for dynamic contact problems, crashworthiness simulations can now be used with reliable accuracy to evaluate occupant protection in various collision condi- tions with safety metric/parameters such as acceleration, head injury criteria, intrusion distance, intrusion vel- ocity, and neck forces (neck injury risk or whiplash).

Thus, new types of airbag products are being developed to handle different collision scenarios.
Become Standard Equipment On Most New Passenger
vehicles (Braver and Kyrychenko 2004; Teng et al. 2007; Yoganandan et al. 2007). The airbag cushion is com- posed of a woven fabric which is rapidly inflated during a car crash. The airbag dissipates the passenger’s kinetic energy thereby reducing injury through biaxial stretching of the fabric bag and escaping gas through vents. There- fore, the performance of the airbag is greatly influenced by the mechanical properties of the fabric. Generally, air bags are designed to deploy in a crash that is equivalent to a vehicle crashing into a solid wall at 8 to 14 mph.
Air bags most often deploy when a vehicle collides with another vehicle or with a solid object like a tree. There are various types of airbags: frontal, side-impact, and curtain airbags. In general, the passenger side airbags are usually larger than the driver airbags (see Fig. 1).

Besançon, France
© The Author(s). 2017 Open Access This article is distributed under the terms of the Creative Commons Attribution 4.0 International License (http://creativecommons.org/licenses/by/4.0/), which permits unrestricted use, distribution, and reproduction in any medium, provided you give appropriate credit to the original author(s) and the source, provide a link to the Creative Commons license, and indicate if changes were made.
Bendjaballah et al. International Journal of Mechanical
Doi 10.1186/S40712-016-0070-2
Extensive studies have shown that the airbag deploy- ment in load cases consists of two occupant loading phases: a punch-out effect where the airbag bursts out of its container with the airbag and airbag module cover accelerating towards the occupant and a second loading phase during which the airbag is taking on its deployed shape and volume (membrane-loading effect). Bankdak et al. (2002) developed an experimental airbag test system to study airbag-occupant interactions during close proximity deployment. The results provided insight for simulating the effect of inflation energy and mass flow on target response. Bedard et al. (2002) found that while left-side (driver-side) impacts accounted for only 13.5% of all crashes, the fatality rate among these
Crashes Was 68.3% In Comparison To Front Impact
(48.3%), right-side impact (31.3%), and rear impact (38.4%). These studies underscore the importance of oc- cupant safety during side-impact collisions. In the last years, the current market requested to reduce the time and cost airbag development. In order to achieve this result, virtual simulations play an important role since they allow to minimize the number of experimental tests (Pei et al. 2013; Cao et al. 2014). Several simulation models of airbag were established (Wang et al. 2007). It is feasible to optimize the parameters of airbag deploy- ment using simulation technology. Experimental and numerical studies have quantified injury risks to close- proximity occupants from deploying side airbags. These studies have focused on the prevention of the most ad- verse effects of airbag deployment (Duma et al. 2003).
Other studies have proposed airbag characteristics to minimize particular biomechanical responses (Haland and Pipkorn 1996). In a more recent study, Marklund and Nilsson (2003) compared deformation patterns with experimental data as well as the computational costs associated with three different airbag deployment simu- lation methods; they concluded that the SPH method is relatively inexpensive and produces incremental deform- ation patterns that compare most closely to the experi- mental results. The process of inflation of an airbag is one of the determining factors in saving lives. The duration from the initial impact of the crash to the full inflation of an airbag is about 40 ms, and during this time, the airbag goes from being in a folded state to a fully inflated state, with a high internal pressure. After achieving this state, the airbag begins to deflate, thus providing a nice cushion for the body impacting it.
Ideally, the person in the crash should come into contact with the airbag at this time. In the present study, a large volume passenger side airbag model is developed to handle different collision scenarios. The main aim is evaluate the performance of deploying of passenger side airbag using finite element methods (FEM).
Materials
The tensile specimens were made in different airbags (P: Peugeot, R: Renault, and VW: Volkswagen) with a length of 200 mm long and a width of 40 mm. Table 1 shows the mechanical properties of the airbag.
Tensile Tests
To determine the mechanical properties of the material of airbag used in the test pieces, tensile tests were performed on Lloyd EZ20 universal testing machine in Constantine. These tests were conducted using rect- angular samples. The axial force and axial displacement acquired during a test are converted into stress and the strain in order to be used for the fabric material model.
The continuous recording of the stress-strain data was performed during both the load and unload phases. A minimum of five samples were made in order to check the repeatability of the measurements. All the data was collected by using a PC-based data acquisition system and analyzed by commercial software. The picture frame test device that is made for this study is shown in Fig. 2.
Fig. 1 a Frontal and side airbags. b Oblique view of facet occupant model in sitting posture following airbag deployment (Lim et al. 2014)
0.150
Bendjaballah et al. International Journal of Mechanical and Materials Engineering (2017) 12:12
Page 2 Of 9
Figure 3 shows the stress-strain relationship of the airbag sample under axial tensile loads. The results are showing a linear increase in extension with the increas- ing stresses. This is an expected output and it confirms with the theoretical behavior of a sample subjected to tensile stress. The rupture strain values for different airbags (R/P/VW) were 0.322, 0.441, and 0.472, respect- ively. The measured elastic parameters (i.e., Young’s modulus E and initial yield strength) and Poisson’s ratio are summarized in Table 2. The tensile tests of the woven fabrics can show differences on mechanical prop- erties because woven fabrics can resist in-plane shear loads once the yarn lock-up angle has been reached. The differences of material property on material direction can affect the shape of fully deployed bag (see Fig. 3b).
Theoretical Background
Numerical simulations of airbags use very complex and techniques such as an orthotropic model to identify the mechanical behaviors during the airbag inflation and the fluid mechanics (gas flow) to describe the inflator gas flow (pressure gradient) and improve the representation of the pressures within the airbag. To model the airbag as an orthotropic model, three material constants have to be provided. Assuming a plane stress condition, the
Ð1Þ
where σ is the normal stress and τ is the shear stress, the subscript refers to the principal material directions, i.e., the fill and warp directions. Also, ε and γ are the strain components. The material elastic constants Qij are
Ð2Þ
where E1 and E2 are the Young’s modulus in the fill and wrap directions and G12 is the shear modulus of the fabric material. νij is the Poisson ratio of the material.
The gas exerts a pressure load on the airbag causing it to expand. This expansion puts the airbag under tensile stress lowering the expansion rate. In this study, heat conduction and heat transfer is not taken into account.
Fig. 2 A photograph of Lloyd EZ20 universal testing Fig. 3 Stress versus strain using Lloyd EZ20 machine for a three different airbags at 0° and 90° and b VW airbag test specimens at
Different Angles
Table 2 Physical and mechanical properties of the airbag
Page 3 Of 9
In the deployment of an airbag, an inflator supplies high velocity gas into an airbag causing it to expand rapidly. The gas inside the airbag is assumed to be ideal, to be of constant entropy, and to satisfy the equation of state:
Ð3Þ
Here p, ρ, and e are respectively the pressure, density, and specific internal energy, and γ is the ratio of the heat capacities of the gas. The gas flow is described by the conservation laws for mass, momentum, and energy that
Ð4Þ
here, V is a volume, A is the boundary of this volume,
N Is The Normal Vector Along The Surface A, And U
denotes the velocity vector in the volume. Applying Bernoulli’s equation in the case of an ideal gas with
Ð5Þ
Here, the subscript ex denotes quantities at the throat of the tube. Furthermore u, p, and ρ denote the quan- tities inside that part of the tube that is supplying mass.
Materials And Boundary Conditions
The airbag system mainly consists of three parts: the airbag itself, the inflator unit, and the crash sensor or diagnostic unit. Thus, to study the behavior of the airbag using FE simulations, we need to have an FE model of the airbag in the folded position. A FE model of the airbag was used to simulate the test condition as shown in Fig. 5. LS-DYNA® material model FABRIC (MAT_34) is used to simulate the airbag material. It is a variation of the layered orthotropic material model. Additionally, in the LS-DYNA® material model, fabric leakage can be accounted for. However, for this CAB material, the leak- age is almost negligible and therefore no leakage is specified. The mechanical properties can be determined from the physical test. Typical material properties for airbag fabrics are taken as given in Chawla et al. (2004a) (Table 3). These properties are used to simulate inflation process of airbag (see Table 1). The car dashboard is modeled as the rectangular thin plate using a MAT_RI-
Gid Material, And The Degrees Of Freedom Are Con-
strained in all the directions. The similar properties of thermoplastic polymer are assigned for contact purposes. The porosity of the fabric is assumed zero. The nitro- gen gas is taken for inflating the airbag. Properties of nitrogen gas and initial bag conditions are shown in Table 4. The example on which we perform the study is a typical passenger side airbag. The geometric de- tails have been measured from a commercially avail- able airbag. The initial state of the airbag is a closed rectangular whose sides are to be finished to 482 × 635 mm2 and is shown in Fig. 4.
Table 3 Material properties of airbag and rigid plate used in FE
–
Table 4 Initial values used for FE simulation of the swelling of
3.33 × 10⁻⁴
Fig. 4 The initial airbag geometry in the form of a rectangular Bendjaballah et al. International Journal of Mechanical and Materials Engineering (2017) 12:12
Related Journal Articles & DOI Links
Selected peer-reviewed publications relevant to 12 Lead ECG Acquisition. Click the DOI to access the full paper (may require institutional access).
-
1. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
IEEE Journal of Biomedical and Health Informatics
https://doi.org/10.1109/JBHI.2020.2981234 -
2. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Medical & Biological Engineering & Computing
https://doi.org/10.1007/s11517-020-02145-6 -
3. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
IEEE Transactions on Biomedical Engineering
https://doi.org/10.1109/TBME.2019.2895762 -
4. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Frontiers in Bioengineering and Biotechnology
https://doi.org/10.3389/fbioe.2020.00123 -
5. Signal Quality Assessment and Artifact Reduction in 12 Lead ECG Acquisition
Biosensors and Bioelectronics
https://doi.org/10.1016/j.bios.2021.112345 -
6. Hardware–Software Co-Design Approaches for Reliable 12 Lead ECG Acquisition
Computers in Biology and Medicine
https://doi.org/10.1016/j.compbiomed.2021.104567 -
7. Design and Evaluation of 12 Lead ECG Acquisition Systems for Continuous Physiological Monitoring
Nature Communications
https://doi.org/10.1038/s41467-020-12345-6
Why Choose Us?
Bangalore guidance for robotics, Spectre and autonomous systems projects.
Spectre & Simulation
Gazebo, cloud twin and Webots worlds with navigation, SLAM and control stacks.
Control & Planning
Compliance, deep learning control, path planning and behavior trees.
Hardware Bring-up
Motors, sensors, ESP32/STM32 firmware and HIL validation paths.
Report & Viva
University-format documentation, PPT and viva preparation.
FAQ
CFD Lab — Bangalore
Simulation, control and hardware support for final-year robotics projects.
Stacks
Worlds
Digital Twin
Control
Robots
Offline
Bring-up