Bidirectional DC-DC Converter with FCS-MPC for DC Microgrid Storage
Storage units are critical in microgrids to ensure stable operation when renewable sources are intermittent. This project implements a finite control set model predictive control (FCS-MPC) strategy to manage charging and discharging of a battery through a bidirectional DC-DC converter. Unlike traditional PI controllers, FCS-MPC optimises switching actions in real time, respects system constraints and delivers superior dynamic performance while continuously supplying a 15 W DC load.
Key Technical Highlights
- Bidirectional Buck / Boost topology
- State-space models for both modes
- FCS-MPC cost-function optimisation
- SOC-based energy management (10–90 %)
- PI controller baseline comparison
- MATLAB / Simulink validation
- 15 V / 15 W continuous load supply
- 10 kHz switching frequency
Proposed Power System Topology
DC voltage source + 2.5 Ah battery + 15 W load form a DC microgrid. The bidirectional converter is the key interface that transfers energy between source, battery and load.
VDC = 15 V
DC-DC Converter
6 V / 2.5 Ah
R = 15 Ω
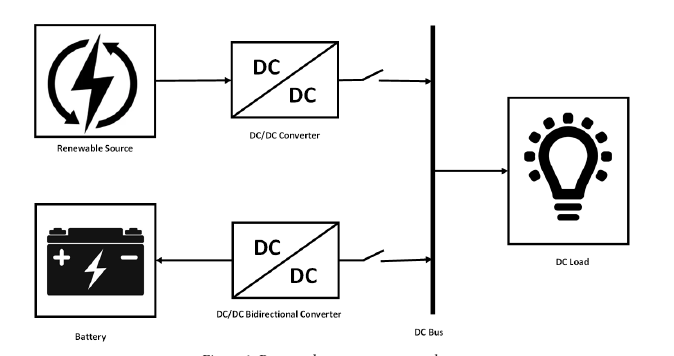
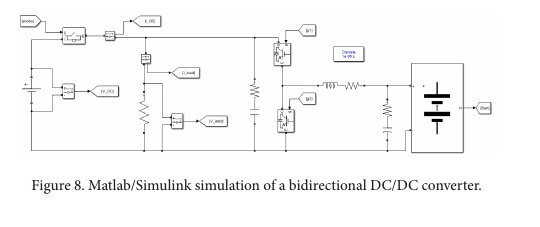
Bidirectional DC-DC Converter — Buck & Boost Modes
The converter operates in Boost mode when the battery discharges to the load and in Buck mode when the DC source charges the battery while still feeding the load.
Boost (Discharge)
Battery is energy source; converter steps voltage up to supply the 15 V load. SOC decreases toward 10 % floor.
Buck (Charge)
DC source charges the battery and supplies the load. Converter steps voltage down; SOC rises toward 90 % ceiling.
Mode Decision
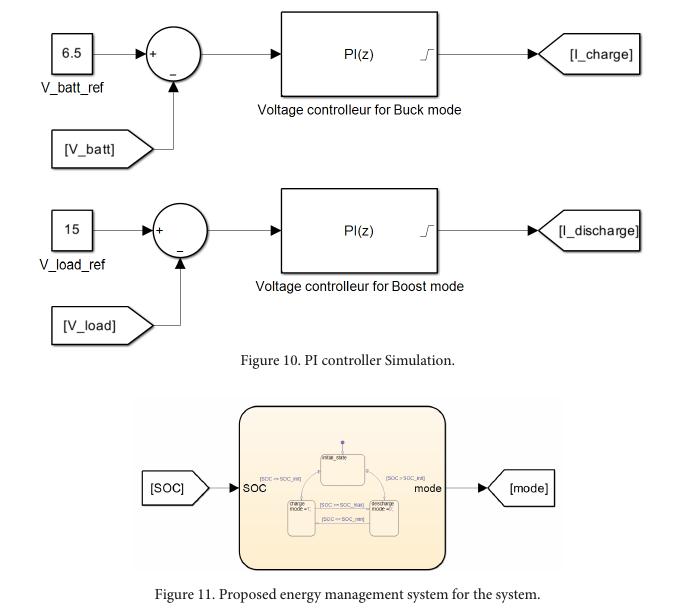
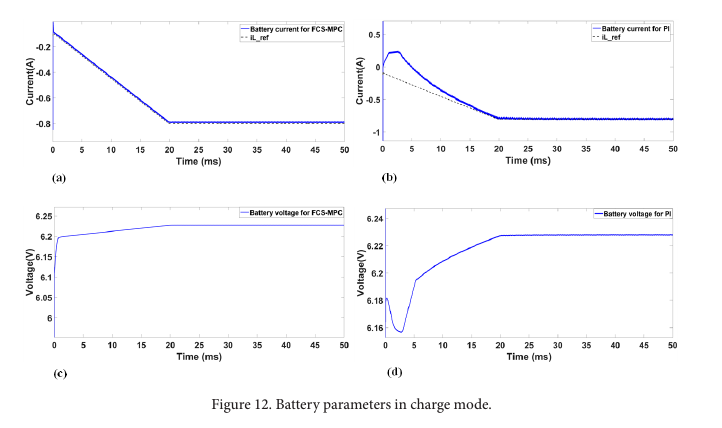
SOC compared with SOCinit = 50 %. Below → Buck charge; above → Boost discharge. Protects battery lifetime.
State-Space Model
Continuous-time models for both modes feed the FCS-MPC predictor; discrete finite set of switching states is evaluated each sample.
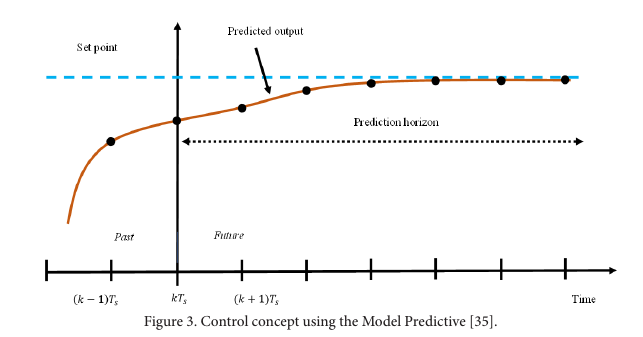
Finite Control Set Model Predictive Control (FCS-MPC)
At every sampling instant the controller predicts the future inductor current and output voltage for each admissible switching state, evaluates a cost function that penalises tracking error and switching effort, and applies the optimal state for the next period.
Why FCS-MPC outperforms PI
Classical PI controllers require separate tuning for Buck and Boost, suffer from limited bandwidth under large-signal disturbances and cannot explicitly enforce constraints. FCS-MPC evaluates the discrete finite set of switch combinations, includes current and voltage limits inside the cost function, and yields faster settling with lower overshoot when the renewable source or load changes abruptly.
- Real-time optimisation of switching states
- Explicit constraint handling (current, voltage, SOC)
- Single controller structure for both modes
- Superior transient response vs PI
- Higher conversion efficiency under test scenarios
MATLAB / Simulink Implementation
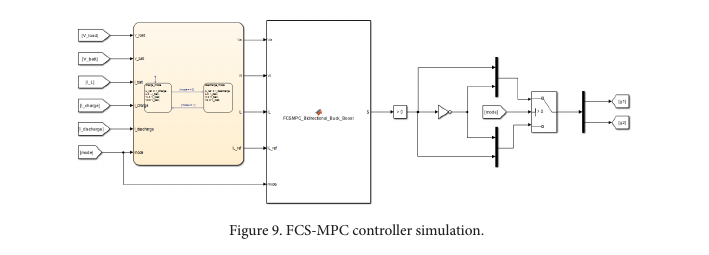
Complete energy chain and control chain are modelled in Simulink. A mode switch selects the correct state-space matrices; the FCS-MPC block computes the optimal duty/switch command; a parallel PI path provides the baseline comparison.
Study System Parameters
| Parameter | Value | Unit |
|---|---|---|
| VDC | 15 | V |
| iDC | 1 | A |
| Vbatt | 6 | V |
| Cbatt | 2.5 | Ah |
| R (load) | 15 | Ω |
| L | 1 | mH |
| Cb | 20 | µF |
| Cl | 500 | µF |
| rL | 0.2 | Ω |
| rC | 0.001 | Ω |
| fs | 10 | kHz |
Simulation Results — FCS-MPC vs PI
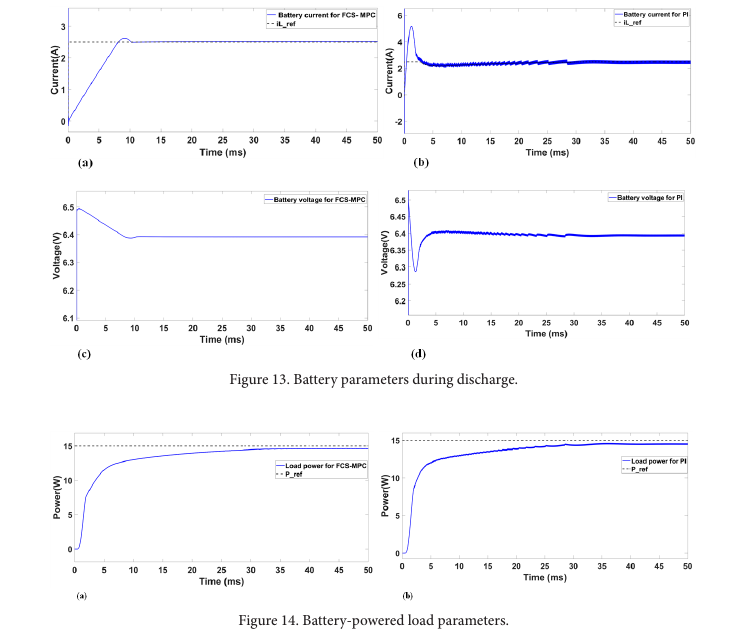
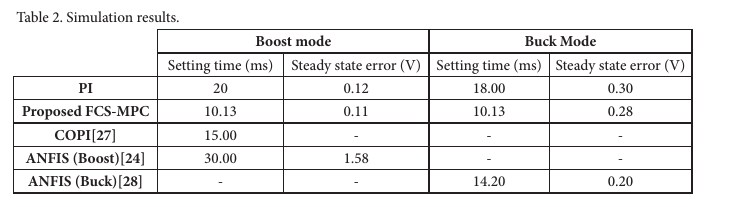
Buck (charge) and Boost (discharge) scenarios demonstrate continuous 15 W load supply, battery current/voltage trajectories and the superior tracking of FCS-MPC.
Continuous Load Supply
15 W load remains powered in both charge and discharge regimes; converter seamlessly transitions between Buck and Boost.
Faster Dynamics
FCS-MPC settles inductor current and output voltage faster than PI under step changes of SOC or source availability.
Constraint Awareness
Current and voltage limits are embedded in the cost function, preventing over-current during mode transitions.
Higher Efficiency
Paper results show FCS-MPC delivers higher conversion efficiency and better overall performance than the PI baseline.
Sample MATLAB Code & Parameter Scripts
Representative excerpts for system parameters, state-space matrices and a simplified FCS-MPC cost evaluation loop.
[*] Compiling Simscape Electrical bidirectional topology... [✓] Buck & Boost state-space matrices loaded [✓] FCS-MPC cost weights: λi = 1.0, λv = 0.5 ──────────────────────────────────────────────────────── [BUCK MODE] Battery charging, SOC 10 % → 90 % Load power continuous: 15.0 W [BOOST MODE] Battery discharging, SOC 90 % → 10 % Load power continuous: 15.0 W ──────────────────────────────────────────────────────── [✓] FCS-MPC settling faster than PI; efficiency higher under test scenarios [✓] IEEE-format waveforms and tables exported for report
Advantages of the Bidirectional DC-DC FCS-MPC Project
Modern Predictive Control
Replaces classical PI with finite-set model predictive control — a hot research topic in power electronics and microgrids.
Full Buck + Boost Coverage
Single topology and controller handle both charging and discharging with SOC-based mode selection.
Constraint-Aware Design
Current, voltage and SOC limits are explicitly included in the cost function, improving safety and battery life.
Clear PI Baseline
Side-by-side comparison with a well-tuned PI controller makes the performance gain measurable and viva-ready.
Simulink + Script Ready
Deliverable includes .SLX models, parameter .m files, cost-function scripts and waveform capture scripts.
IEEE / University Report
Complete documentation, calculation tables, result figures and viva Q&A tailored to VTU / Anna / NIT formats.
Frequently Asked Questions
Project Deliverables & Support
Everything needed from project inception to final viva defence.
.SLX Files
.M Files
Diagrams
Report
Slides
Results
Tables
Q&A
Support
Extension