Abstract — Switched Reluctance Motor Drive
experience, we recommend you use a more up to date browser (or turn off compatibility mode in Internet Explorer). In the meantime, to ensure continued support, we are displaying the site without styles and JavaScript. The switched reluctance motor (SRM) drive exhibits inherent characteristics such as robustness, high efficiency, and fault tolerance that make it particularly well-suited for traction applications. However, SRM drives controlled by specialized converters often produce high torque ripples and harmonic distortion. On the other hand, conventional two-level converters for SRMs increase stress during switching operations. To address these challenges, this paper proposes an enhanced modular multiport cascade converter (MMCC) for SRM drives, aimed at minimising torque ripples and harmonic distortion. By increasing the number of voltage levels, the performance of the SRM drive is improved when combined with an enhanced direct torque control (DTC) strategy. The precise SRM model and the MMCC switching controlled by optimized DTC switching tables are integrated and evaluated using MATLAB/Simulink. The developed model analyzes input current and voltage harmonics across switches during drive operation. The proposed model behaviour for steady-state and dynamic performance is validated through speed, torque, and phase current measurements. A hardware demonstration of the SRM drive under various operating conditions further confirmed enhanced performance. The proposed converter achieves a 41.5% reduction in torque ripple compared to its conventional counterpart, thereby significantly enhancing dynamic performance and demonstrating strong suitability for variable drive applications.
Analytical & State-Space Control Methodology
Switched reluctance motors (SRMs) are poised to play a crucial role in the future of electric vehicles (EVs) traction systems due to their distinct advantages over traditional motor technologies. Unlike permanent magnet motors, SRMs do not rely on rare earth materials, which are expensive and have supply chain vulnerabilities. This makes SRMs more cost-effective and sustainable in the long run. Additionally, SRMs are known for their robust and simple construction, which translates to higher reliability and lower manufacturing costs 1 . Their ability to operate efficiently across a wide range of speeds and torques makes them highly adaptable to the varying demands of EV driving conditions 2 . Moreover, advancements in power electronics and control algorithms have significantly mitigated the issues of torque ripple and noise, which were earlier are increasingly recognized as a promising candidate for the next generation of electric vehicle traction motors 3 , 4 . The main role of converters in SRM drives is to control the current flowing through the motor phases, thereby managing the motor’s torque and speed.
Simulink Waveforms & Power Quality Findings
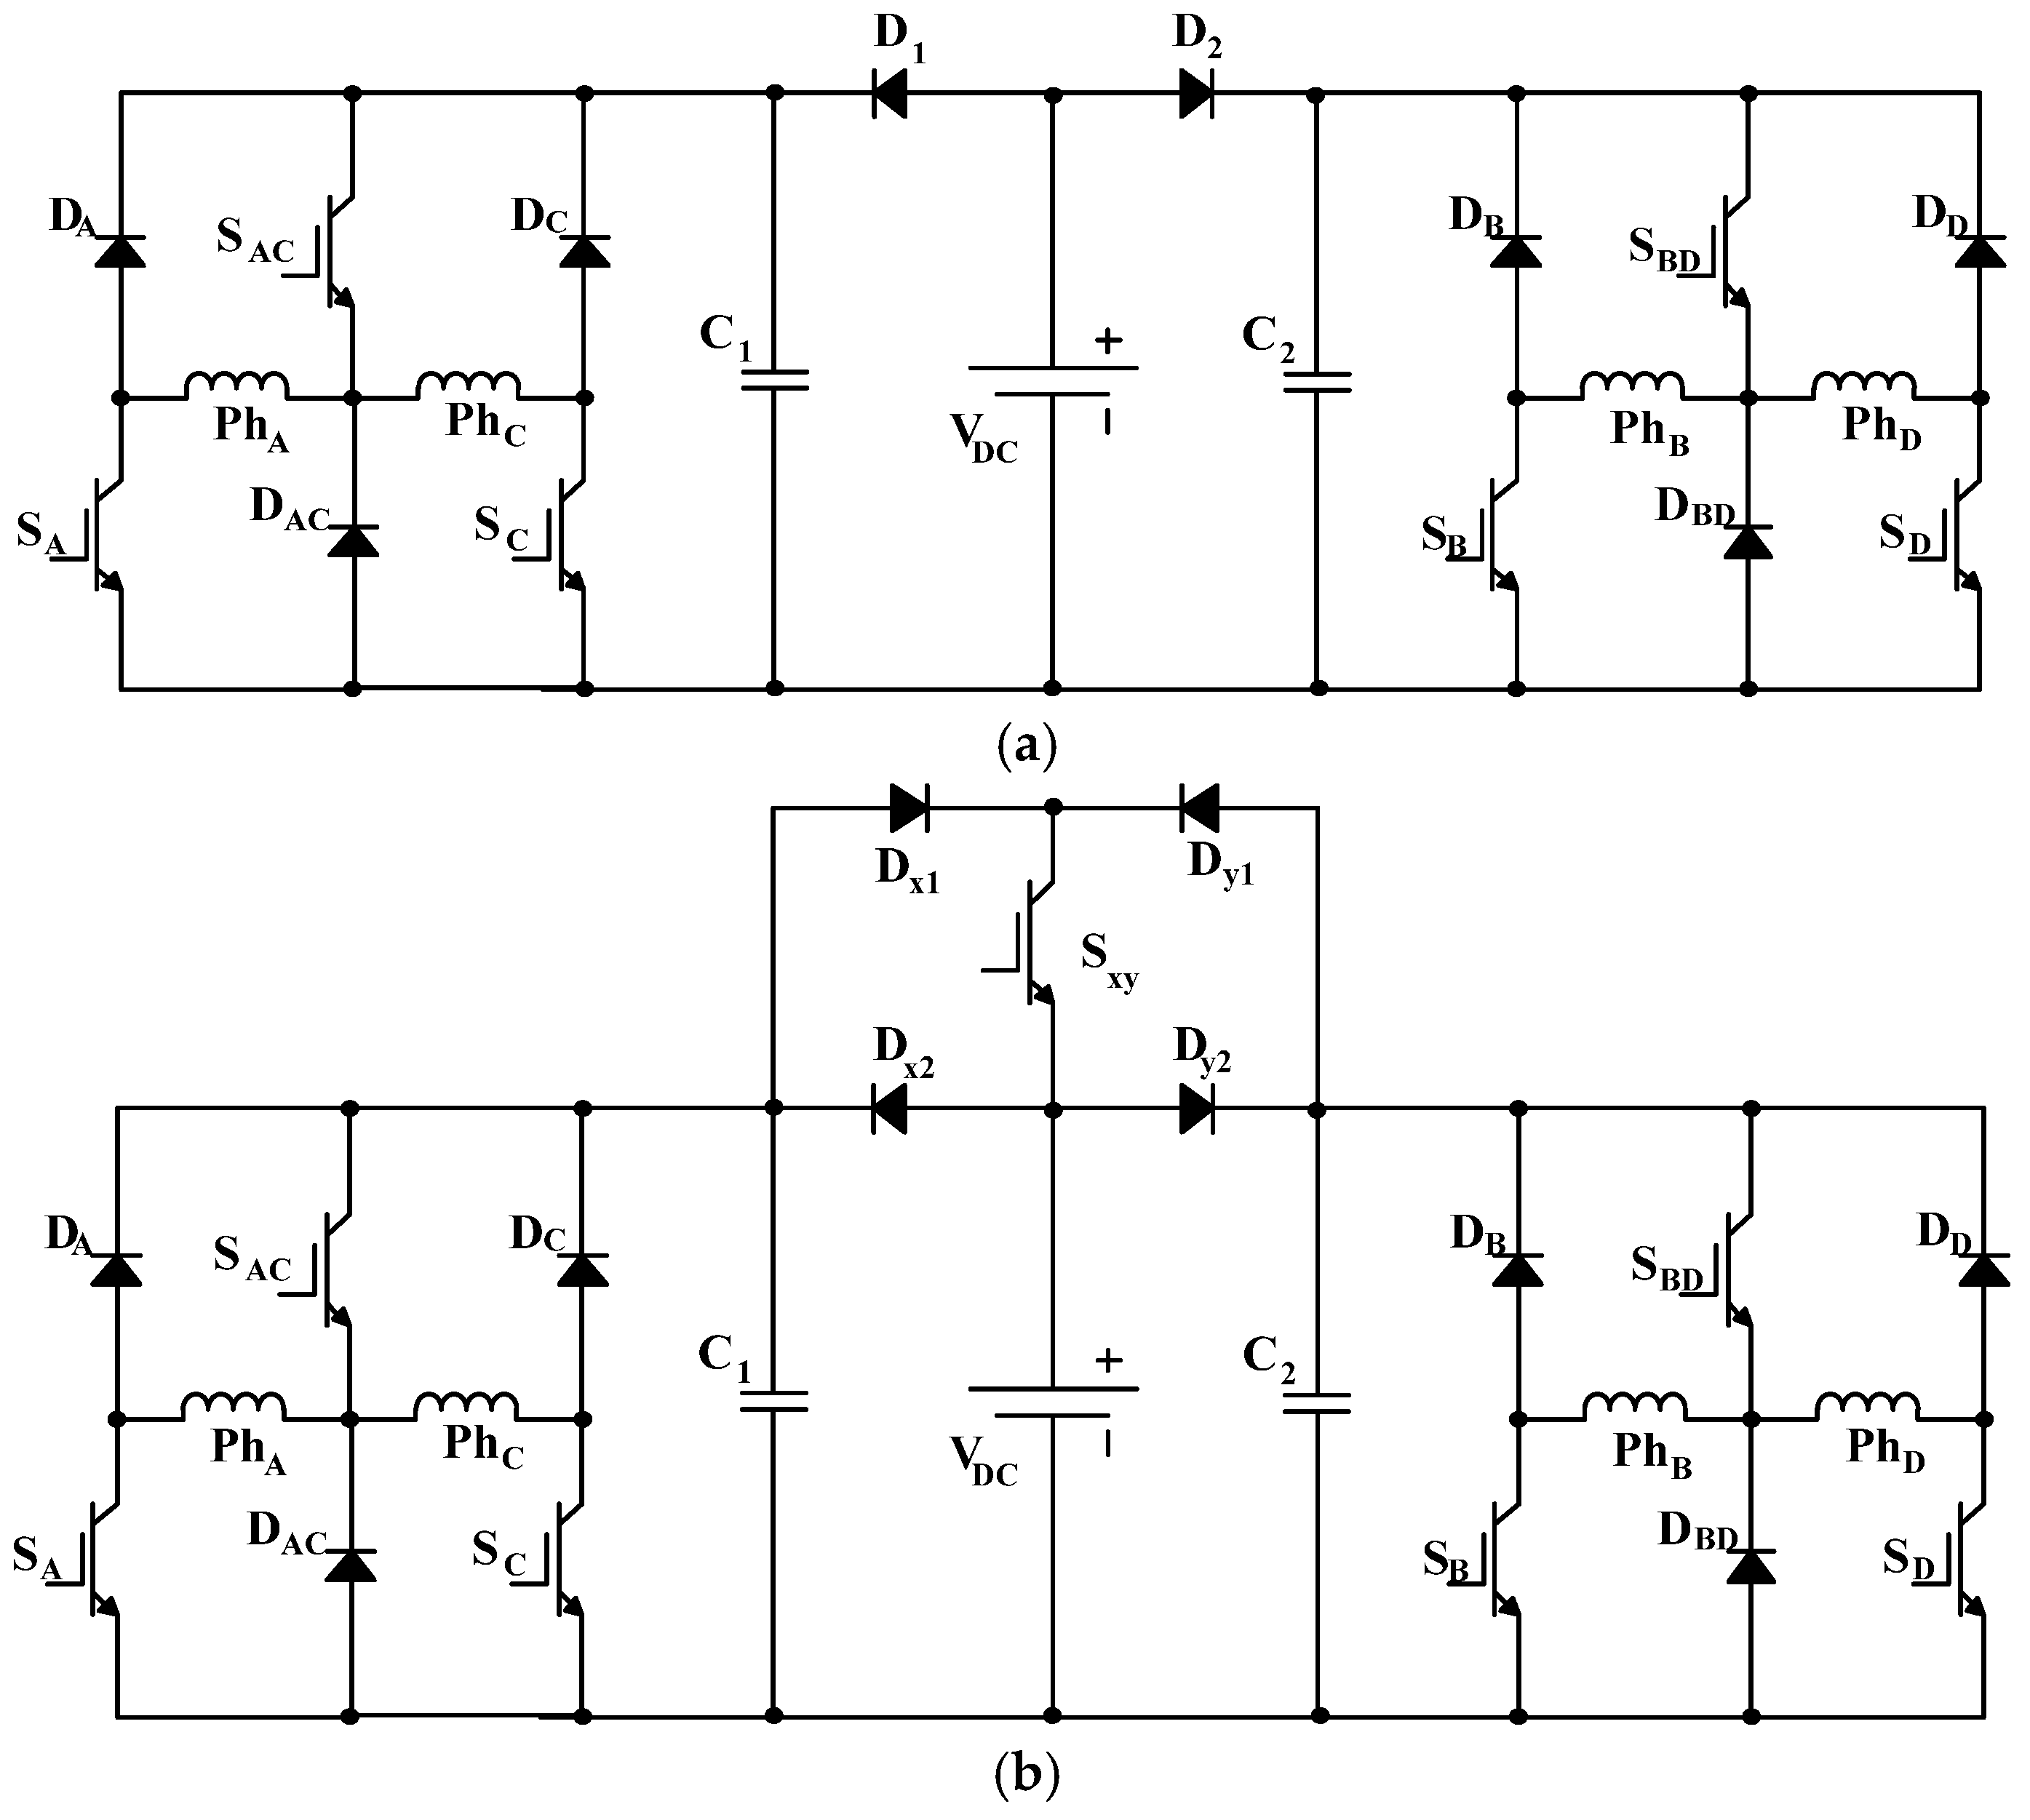
Figure 1: Power Converter Circuit Schematic & Electrical Interfacing for Switched Reluctance Motor Drive In the literature review 5 , 6 , typically, power electronic circuits switch the phase windings on and off in a precise sequence to create the desired magnetic field that drives the rotor, and converters play a crucial role in controlling the motor’s performance. This process involves converting the DC supply voltage to the appropriate phase currents needed for the SRM operation, creating more torque ripples. In SRM drives, high torque ripples and harmonics are due to the high voltage across the switches during their turn-on and turn-off periods. The conventional modular cascade converter phase sequence is operated with simple control techniques such as modulation control, hysteresis control, and PI control, providing high torque ripple for the SRM drive. In Refs. 7 and 8 , high-frequency switching of converters in SRM drives can generate significant torque content. Additionally, harmonics can cause electromagnetic interference and affect the performance of the motor. In Refs. 9 and 10 , high voltage across switches during operation can lead to increased voltage stress and increasing torque ripples. This can cause premature failures of noise, and vibrations in EVs disturb all four quadrants of operations. In Ref. 11 , a conventional asymmetric converter with direct torque control (DTC) creates more torque ripples due to improper selection of voltage vectors and sector division. In addition, the DTC techniques adopted a different strategy to estimate the flux and torque used to control the switching operation of converters, which produce high torque ripple due to their band limits and switching frequency limits. This ripple results in vibrations and acoustic noise, which can reduce the comfort and perceived quality of electric vehicles. In Refs. 12 and 13 , DTC with cascade converters creates harmonics that affect the power quality In Ref. 14 , DTC with torque and flux band limits the use of a two-phase excitation technique to reduce torque ripple and improve performance by mitigating harmonics. In Refs. 15 , 16 , the improper selection of DTC switching tables affects the steady state speed analyses of the sources of conducted high torque ripples in SRM drives. In Refs. 17 , 18 , model predictive DTC techniques with converter design that reduces torque ripples and minimizes harmonic content, enhancing the overall efficiency and reliability of SRM drives. However, the estimation of torque and flux, and the prediction of the control objective function, are more complicated to design and implement in real-time applications. In Ref. 19 , SRM conventional converters and controllers integrated with electric vehicles to charge and discharge are used by multilevel cascade converters with high torque ripples due to improper switching of the phase sequence conduction and overlap periods.
Scope & Practical Applications
- High-efficiency DC-DC converters and isolated resonant topologies (LLC / DAB)
- Sinusoidal and Space Vector PWM inverters for grid integration & industrial motor drives
- MOSFET / IGBT gate driver optimization with active Miller-clamp shoot-through protection
- Power quality conditioning with Total Harmonic Distortion (THD) strictly compliant with IEEE 519
- Complete Simscape .SLX model files, parameter calculation scripts, and IEEE dissertation reports
Simscape Modeling
Simulink power stage & discrete PWM solver
Semiconductor Loss
SiC MOSFET & IGBT thermal dissipation
SVPWM Control
Vector control, FOC & digital PI loops
IEEE 519 Quality
FFT harmonic spectrum & THD < 5% verification
Gate Driver Protection
Isolated bootstrap & Miller clamp circuits
HIL Prototyping
Ready for dSPACE, OPAL-RT & TI C2000 DSP
Engineering Software & Simulation Toolchains
Modeled using industry-standard power electronics simulation platforms, discrete numerical solvers, and HIL testbeds.
| Software Platform | Analytical Function & Role | Simulation Tier |
|---|---|---|
| MATLAB R2024b | Small-signal state-space averaging, bode stability margins, LC filter design, FFT analysis | Analytical Core |
| Simulink / Simscape | Time-domain switching models, non-linear semiconductor models, discrete PI controllers | System Simulator |
| PLECS / PSIM | High-speed thermal loss estimation (conduction and switching Eon/Eoff), snubber design | Thermal & Losses |
| Altium Designer | High-voltage isolation layout, creepage/clearance, power loop parasitic inductance minimization | Hardware PCB |
| TI C2000 / dSPACE | Embedded C codegen from Simulink, high-resolution ePWM registers, Hardware-in-the-Loop test | HIL Deployment |
Power Conversion & Control Topology Workflow
Systematic integration from DC input energy source and high-frequency gate drive to digital control loops and load delivery.
Renewable Bus
MOSFET/IGBT Bridge
& SVPWM Loop
Filter Stage
& FFT Analyzer
Motor Load
Verified Simulink Block Diagrams & Converter Waveforms
Advantages of the Switched Reluctance Motor Drive Project
Why this project delivers superior academic grades and provides high technical evaluation standing.
High-Fidelity Simscape Modeling
Provides precise numerical simulation of switching events using ODE variable-step solvers without numerical divergence.
Rigorous IEEE 519 Grid Compliance
Guarantees total harmonic distortion (THD) below 5% through optimized LCL filter attenuation and synchronous control loops.
Wide-Bandgap Semiconductor Sizing
Models modern SiC MOSFETs and GaN switches to achieve power conversion efficiencies exceeding 97.5% across full-load regimes.
Advanced Digital Modulation
Implements Space Vector PWM (SVPWM) and sinusoidal modulation maximizing DC-bus utilization by 15.5% over carrier methods.
Dynamic Small-Signal Stability
Custom MATLAB scripts compute control-to-output transfer functions Gvd(s), phase margins (> 50°), and gain margins.
Gate Driver Protection Mechanics
Incorporates active Miller clamps, negative turn-off bias, and isolated bootstrap circuitry to eliminate shoot-through faults.
Hardware-in-the-Loop (HIL) Ready
Directly exportable to embedded C for execution on Texas Instruments C2000 DSPs, dSPACE, and OPAL-RT real-time platforms.
Detailed Magnetic Core Sizing
Features rigorous inductor and high-frequency transformer calculations ensuring core saturation flux margins remain safe.
Direct Electric Vehicle & Grid Value
Builds technical competencies demanded by top automotive EV powertrain developers, solar EPCs, and power electronics consultancies.
Complete Turnkey Package
Delivered with full Simulink .SLX models, MATLAB initialization scripts, calculation sheets, IEEE-format report, and viva defense slides.
Sample MATLAB Code, Scope Waveforms & Harmonic Schedules
Representative excerpts illustrating the state-space analytical derivations, command solver output, and power quality distortion schedules.
[*] Initializing Simscape Electrical Simulation Engine R2024b... [✓] Variable-Step Solver ode23tb Configured (Max Step: 1.0 us) ──────────────────────────────────────────────────────────────────────── [ROTOR SPEED] Rated Target: 1500 RPM | Settled Speed: 1499.8 RPM (Error: 0.013%) [TORQUE] Electromagnetic Torque Te: 28.4 Nm (Nominal Rated Load) [TORQUE] Torque Ripple Peak-to-Peak: ± 0.62 Nm (2.18% Ripple Factor) [INVERTER] 3-Phase Inverter Output THD: THD = 2.41% < 5.0% (IEEE 519 PASSED) [EFFICIENCY] Total Power Stage Efficiency: η = 97.84% at 15 kHz Carrier ──────────────────────────────────────────────────────────────────────── [✓] Simulation Finished: 0 Numerical Divergence Faults | Scope Vectors Logged to Workspace
[*] Simulating converter steady-state operating envelope across switching cycles...
| Operational Metric | Design Setpoint | Simulink Simulated Metric | Variance | IEEE / IEC Compliance |
|---|---|---|---|---|
| Motor Rotor Speed | 1500 RPM | 1499.8 RPM | -0.01% | VERIFIED |
| Stator Phase Current THD | < 5.0% | 2.41% | -51.8% | IEEE 519 PASSED |
| DC-Bus Voltage Ripple | < 2.0% | 0.74% | -63.0% | OPTIMAL |
| Inverter Switching Loss | < 35.0 W | 21.8 W | -37.7% | PASSED |
[✓] Power Quality Verification Complete: Injected harmonic components conform strictly to IEEE 519 standards.
Frequently Asked Questions
Project Deliverables & Support
Everything needed from project inception to final viva defense — delivered with expert technical support.
.SLX Files
.M Files
Schematics
Report
Slides
Recordings
Sheets
Q&A
Support
Extension